| Citation: | Xue S,Yang W D,Li Q G,et al. Object detection method for anti-UAV systems in complex backgrounds based on YOLOv11-drone[J]. Journal of Beijing University of Aeronautics and Astronautics,2026,52(9):3001-3010 (in Chinese)

|
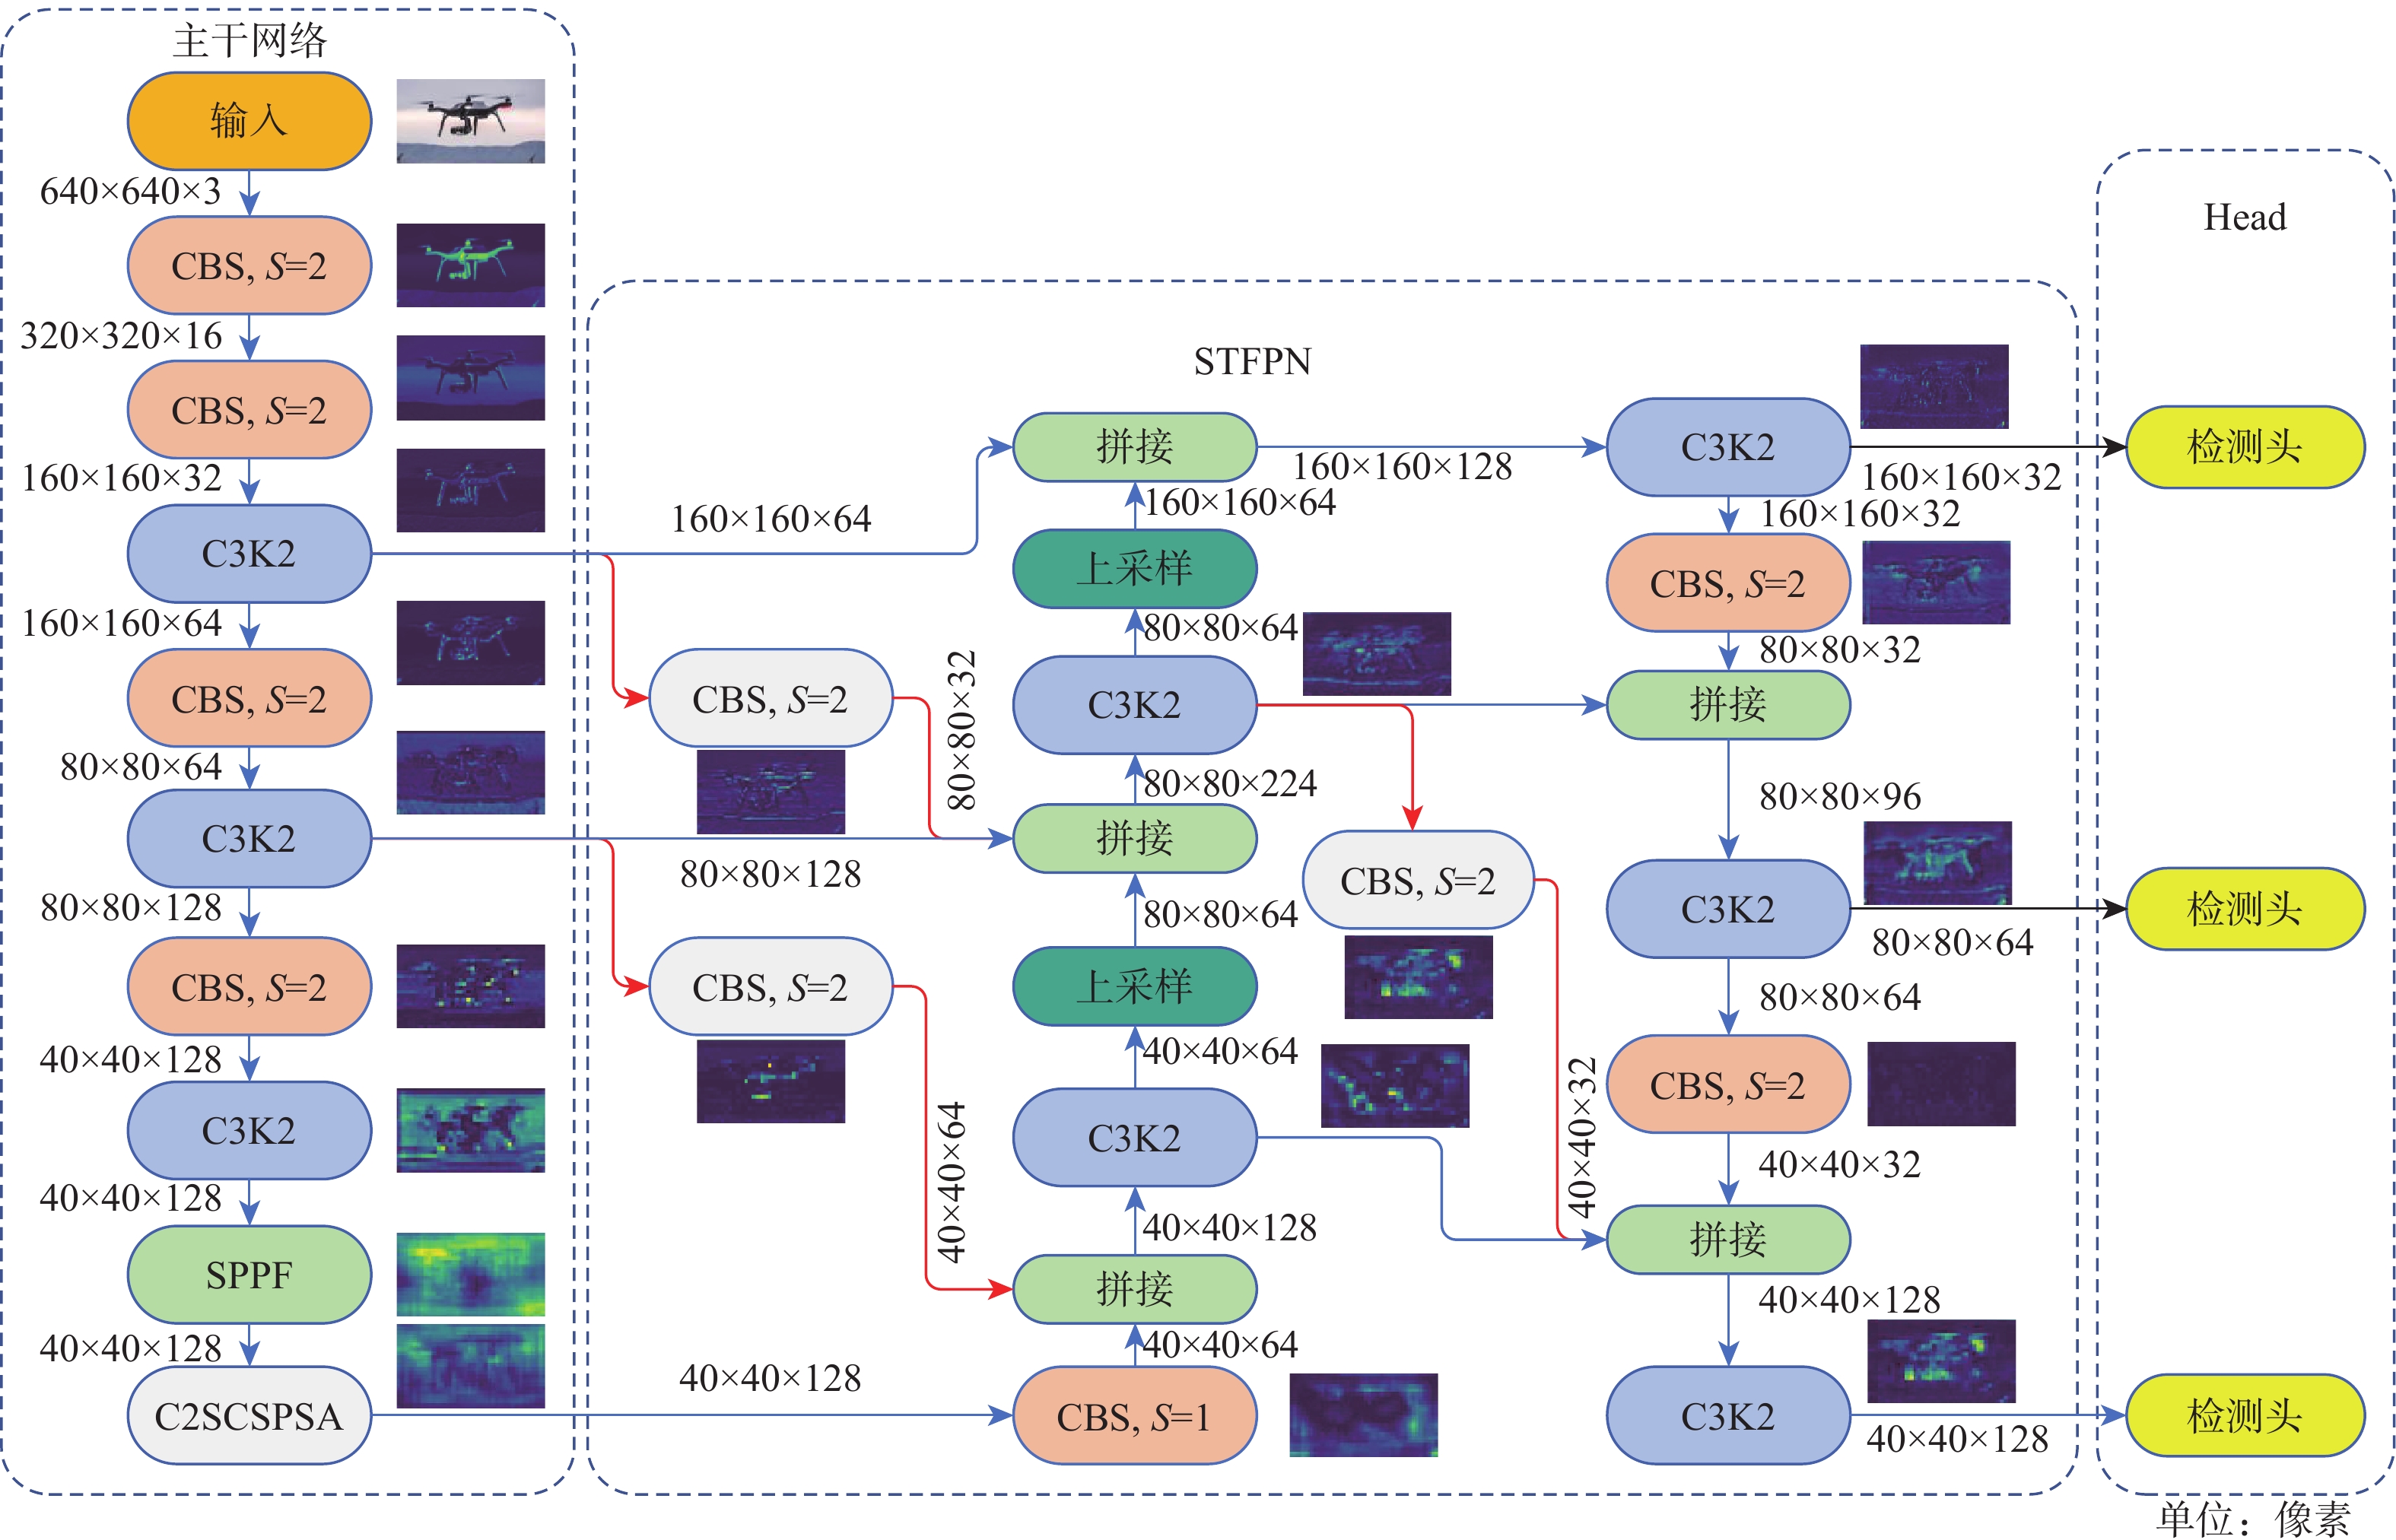
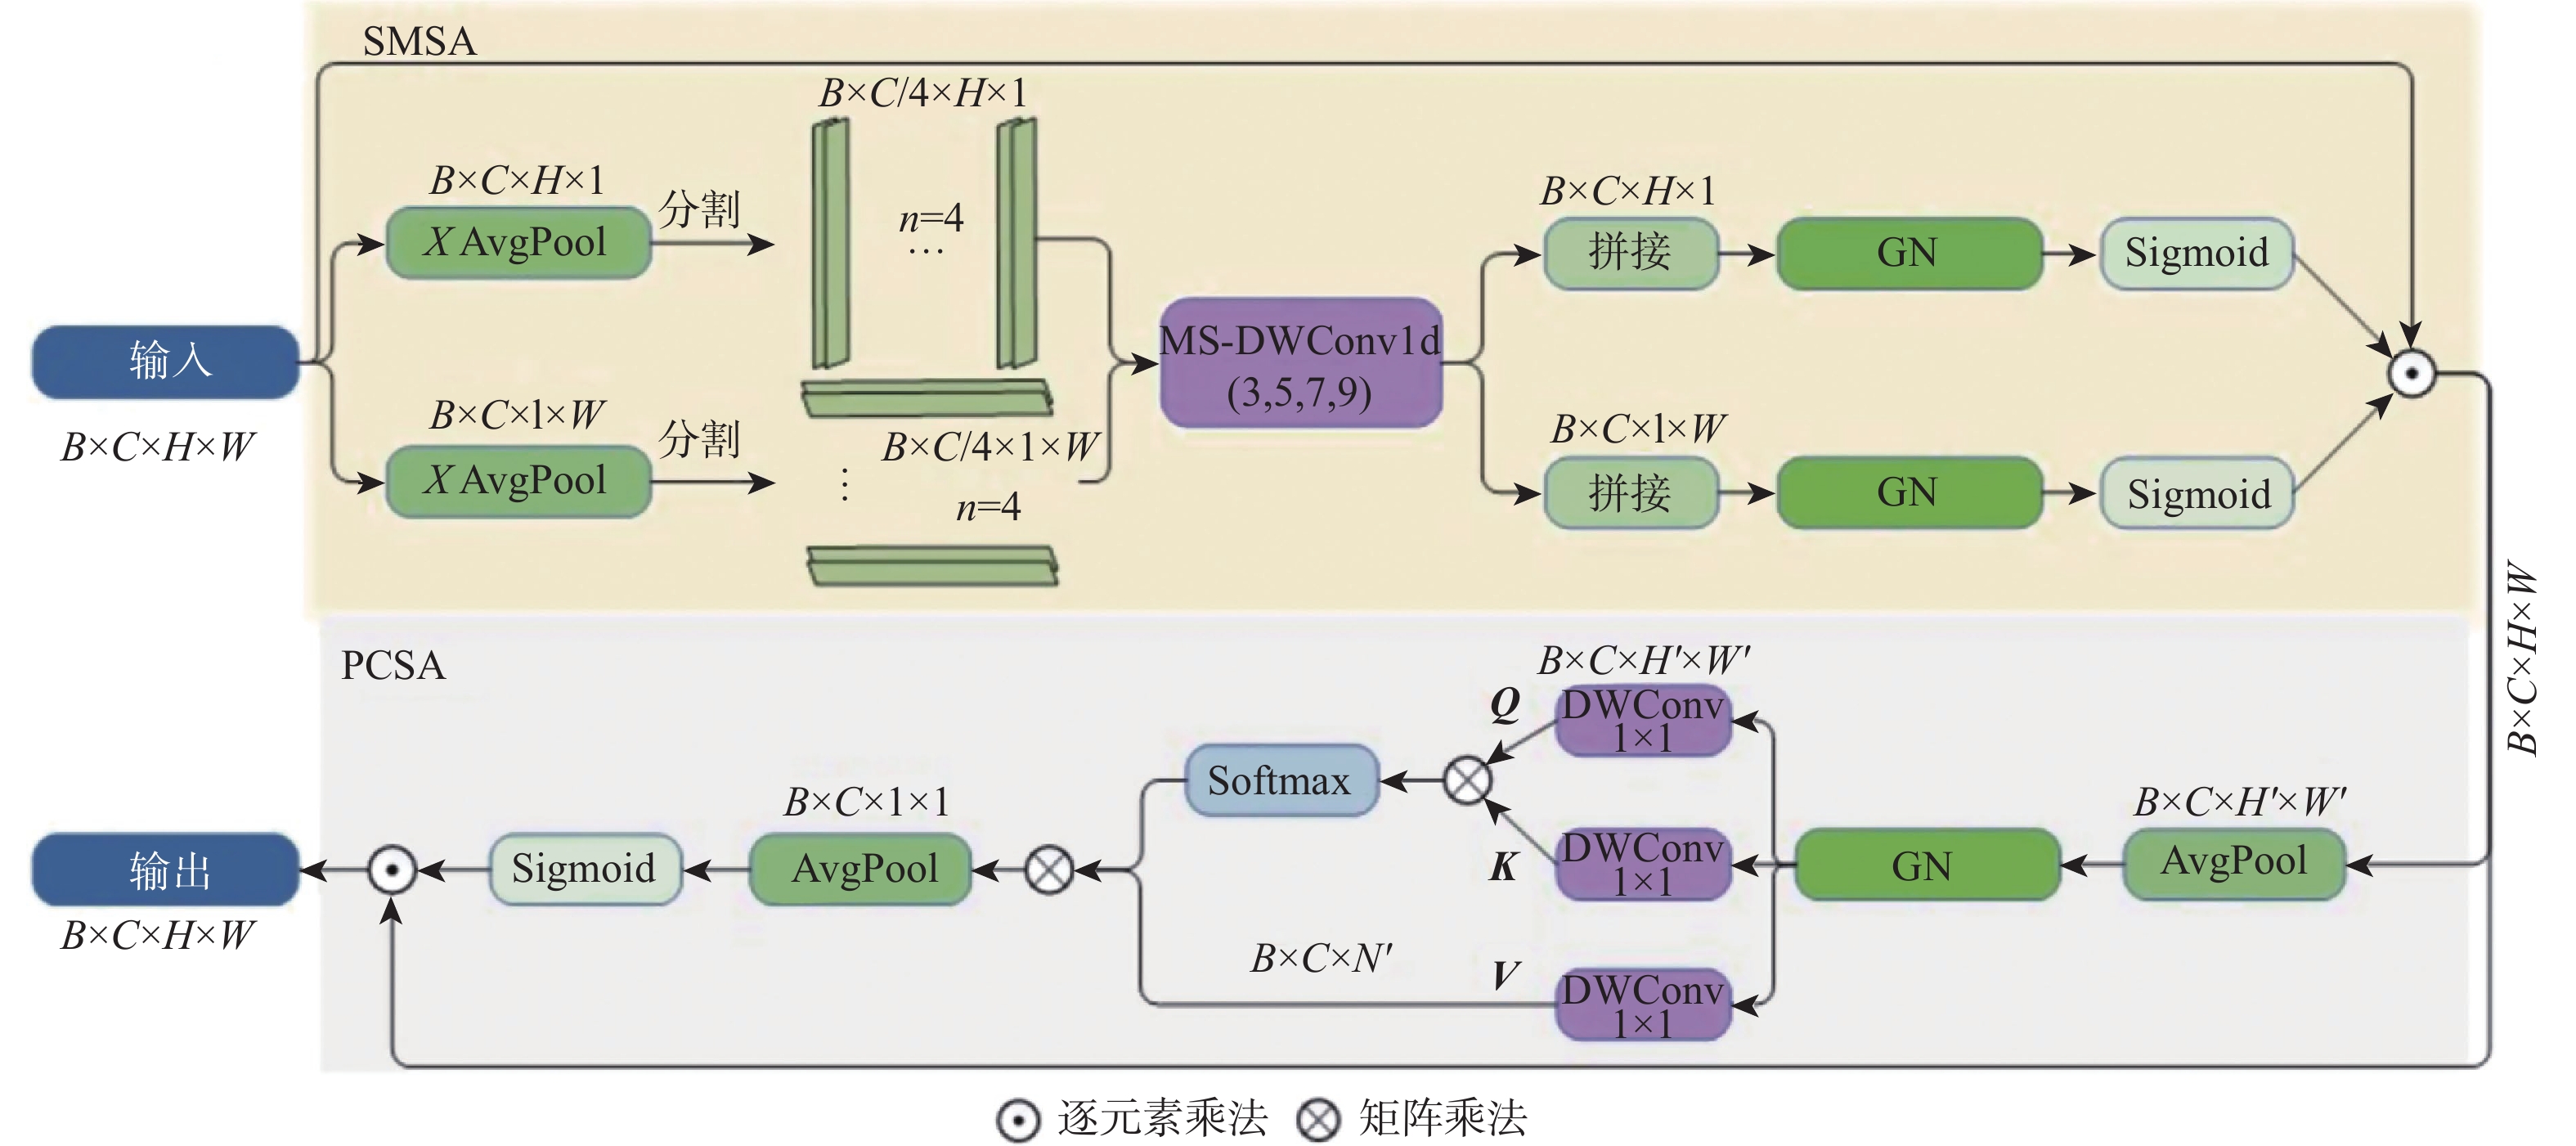
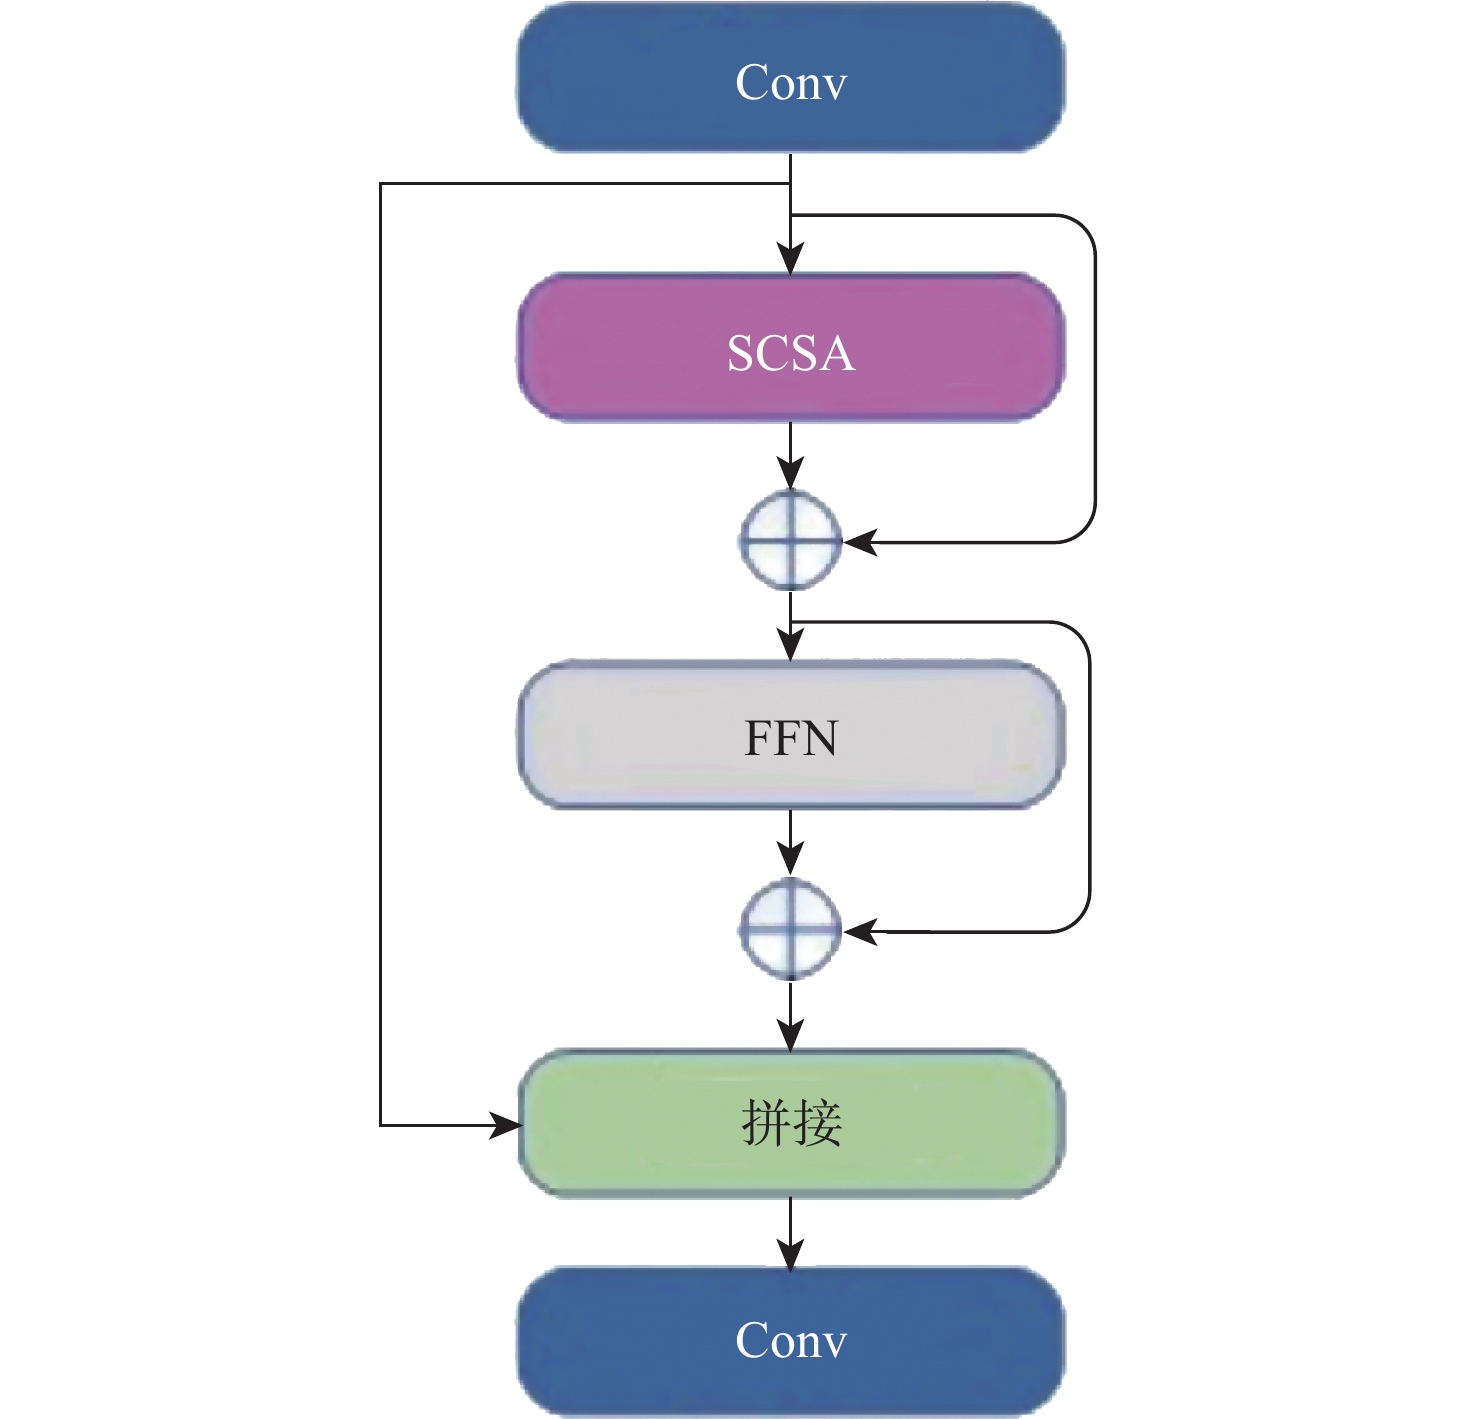
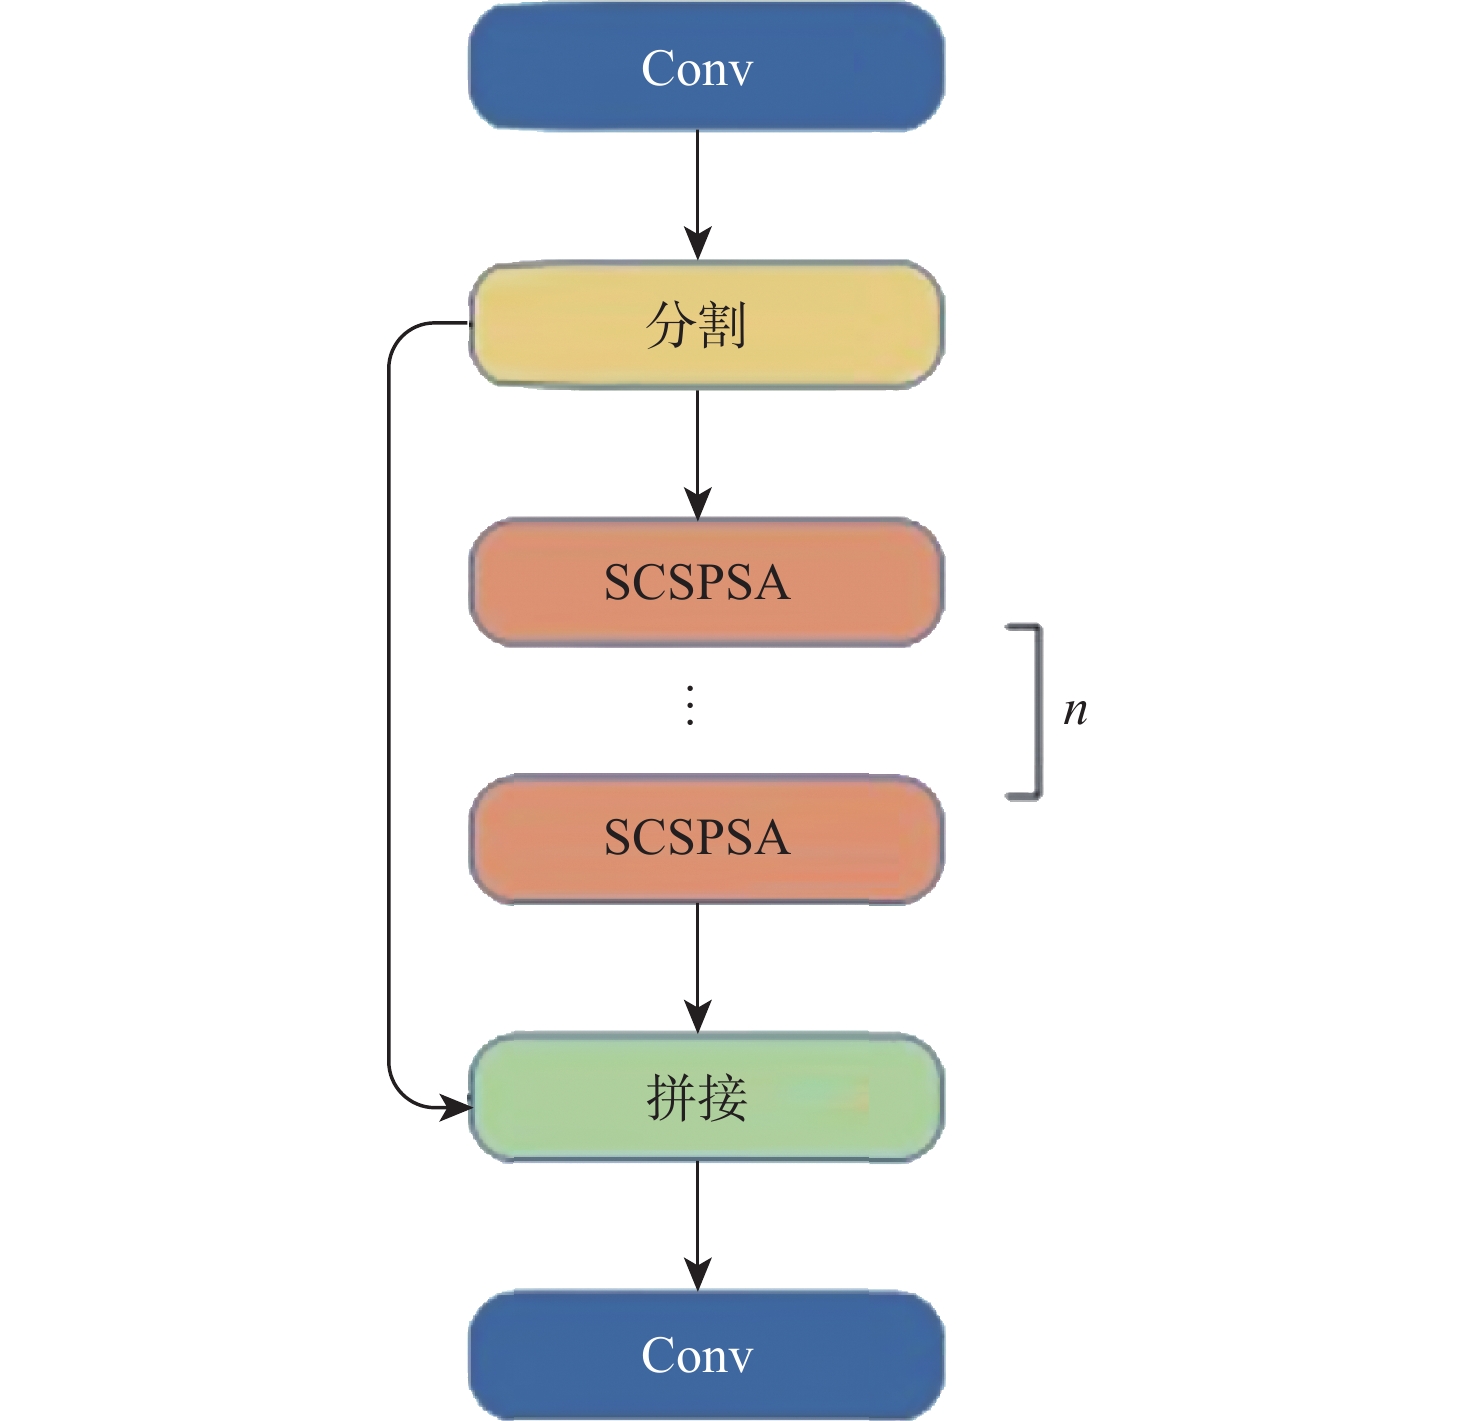
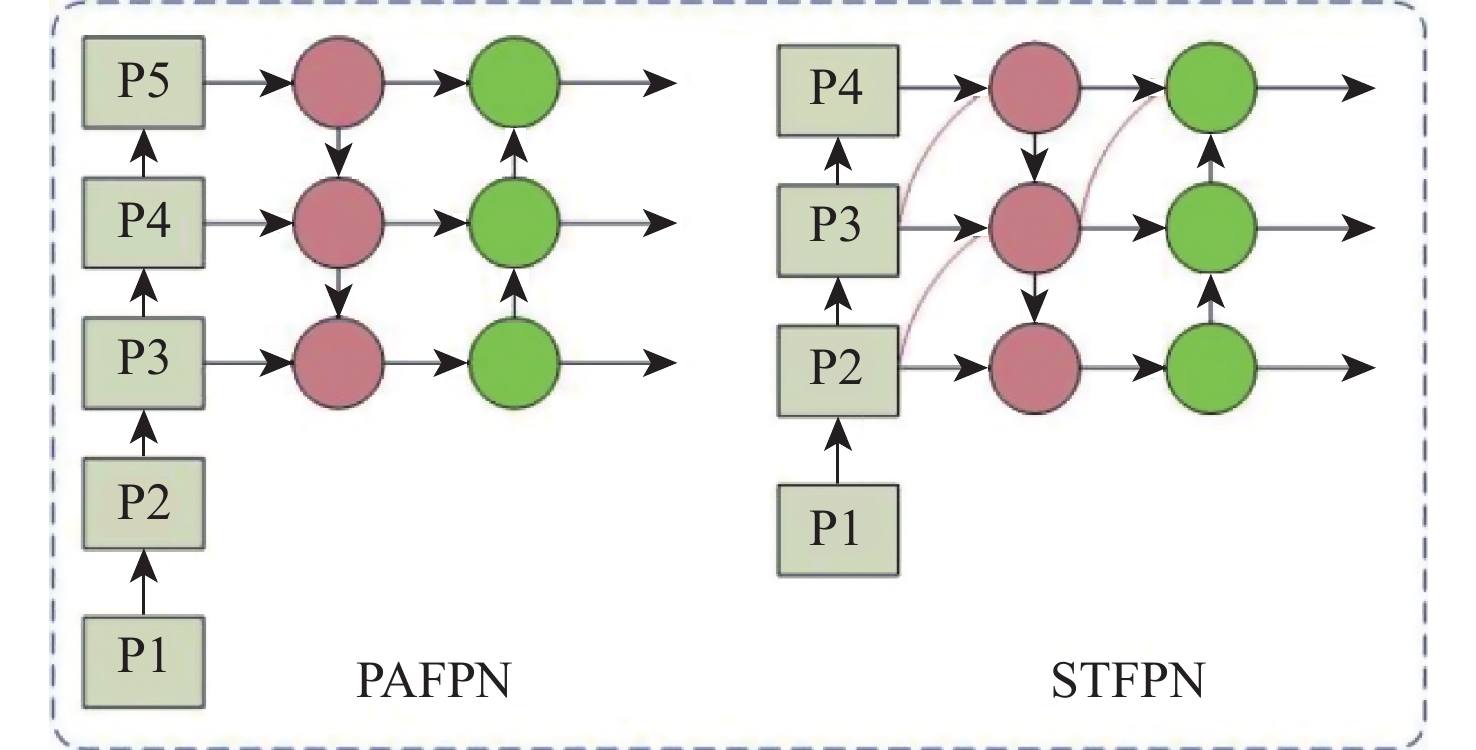
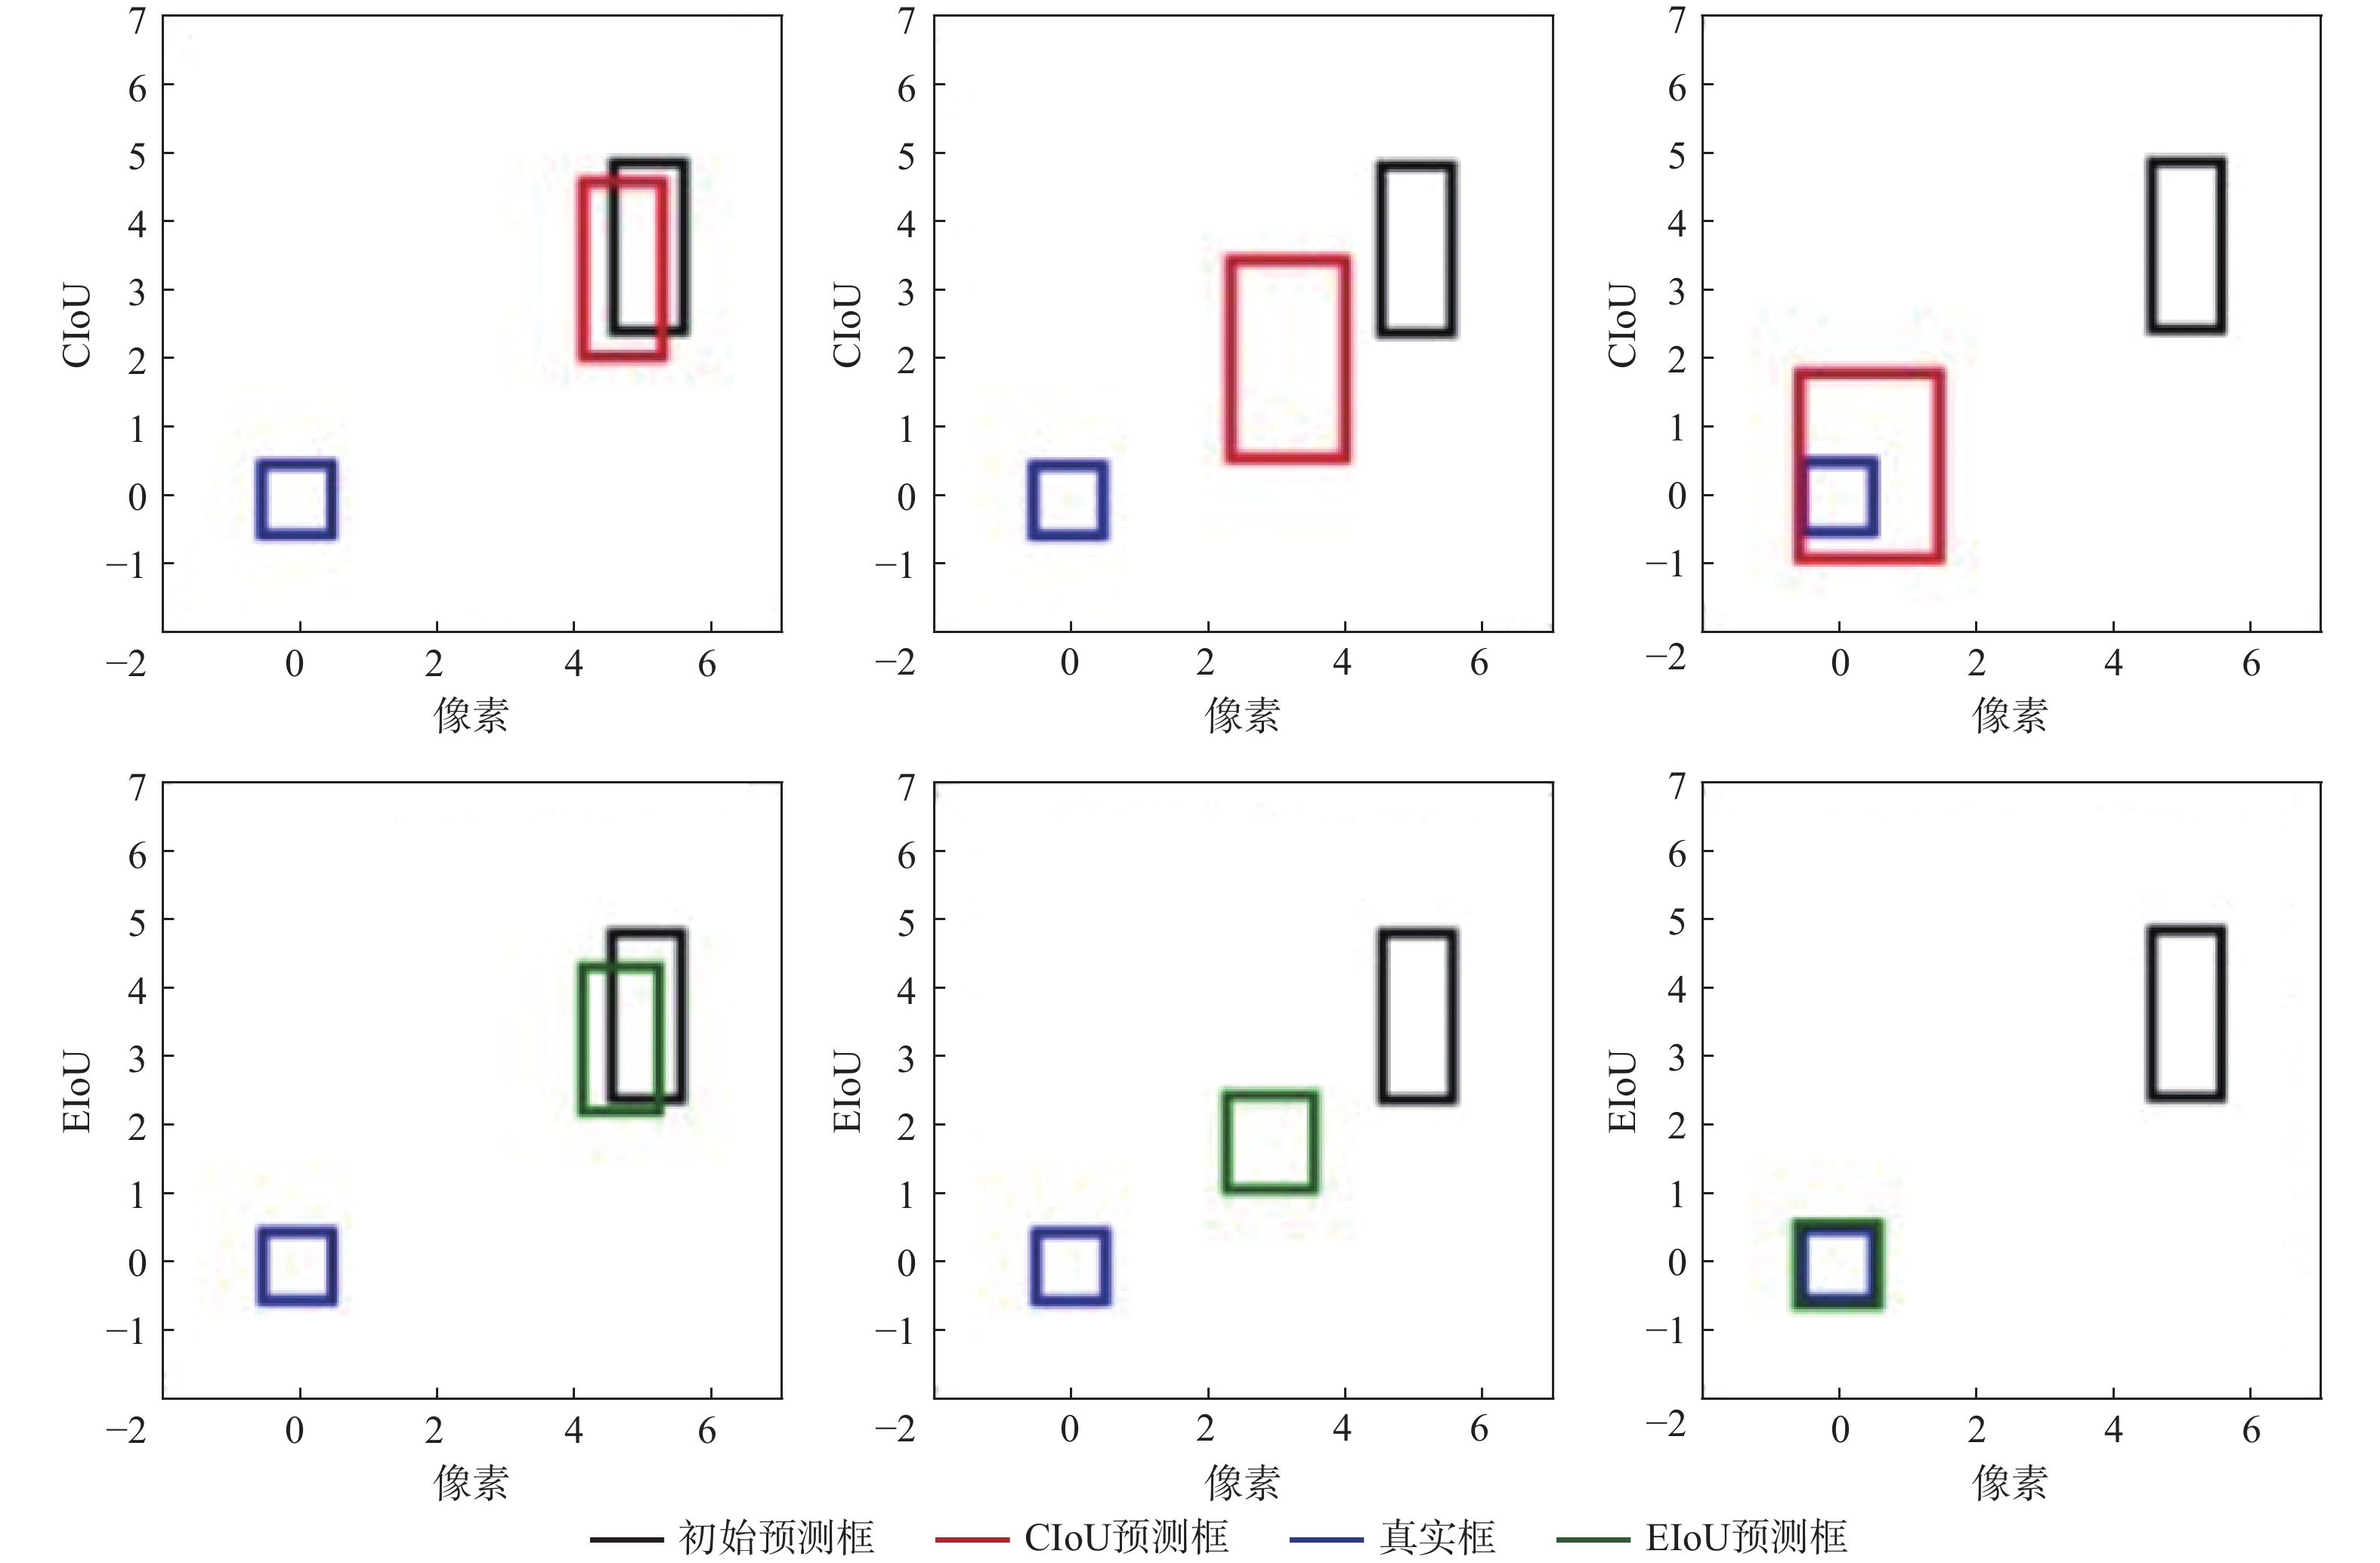
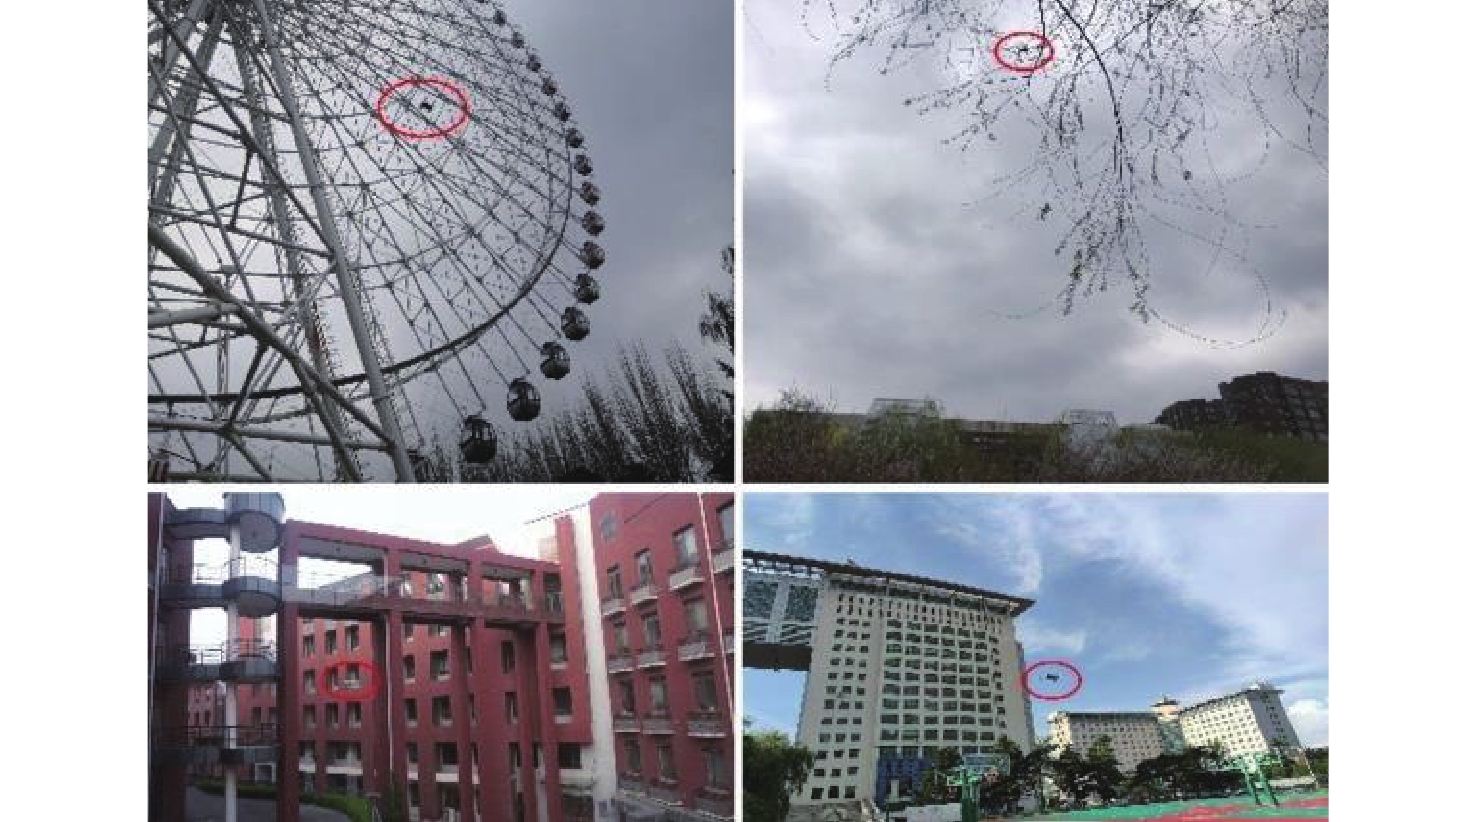
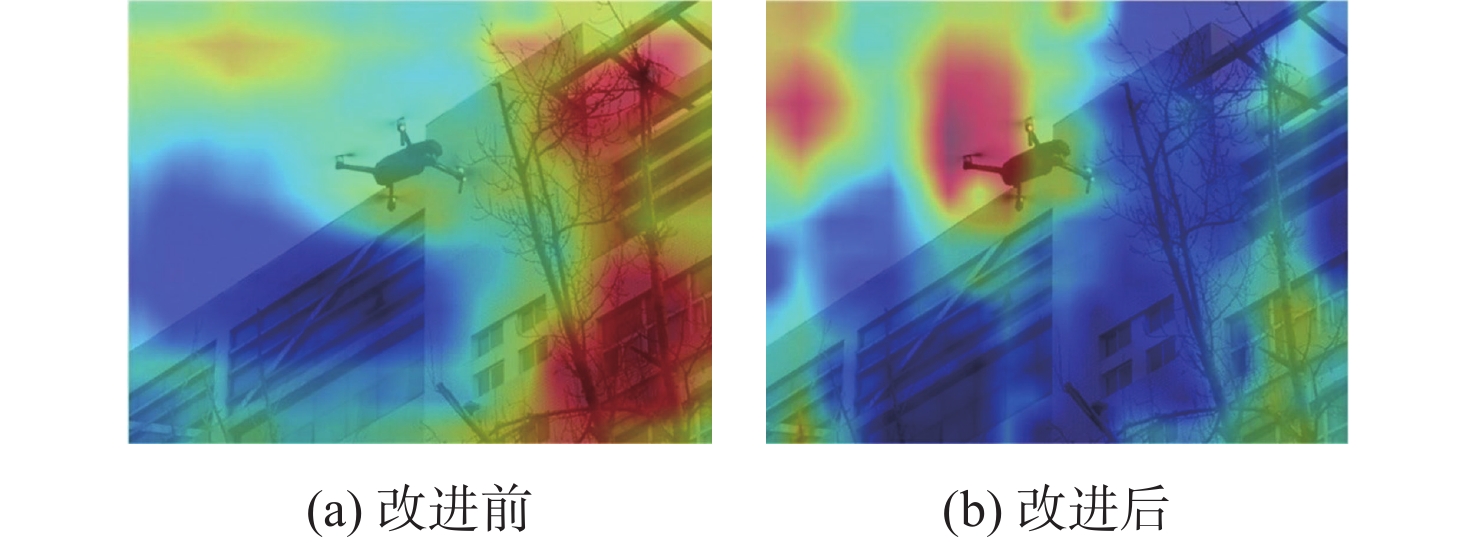
Amid the rapid expansion of the low-altitude economy, UAVs present escalating security threats to large-scale public spaces. Accurate and rapid target detection of drones has become the primary and critical component in anti-drone systems. To address the critical challenges of low detection accuracy, high miss rate, and false positives in small UAV detection within complex environments, this study proposes YOLOv11-drone, an optimized object detection framework based on an enhanced YOLOv11 architecture specifically designed for counter-UAV applications. First, an autonomous dataset of small-target drones in complex backgrounds was constructed. Second, to improve the model’s ability to extract features for drone targets, a partial spatial-channel cooperative attention module C2SCSPSA was created that combines channel attention with spatial attention processes. Furthermore, a small-target-oriented multi-level feature pyramid network (STFPN) was proposed. By fully leveraging shallow semantic information, this architecture significantly reduces the model’s parameter count while improving its focus on small targets. Finally, the model’s loss function was replaced with the EIoU metric, which simultaneously enhances regression accuracy and accelerates convergence speed. The proposed improved algorithm was evaluated on the self-constructed dataset. Experimental results demonstrate that the YOLOv11-drone model achieves a detection accuracy of 95.5%, representing a 4.1% improvement over the baseline algorithm. Additionally, the model reduces parameter count by 62% while attaining an inference speed of 83 frames per second. These advancements confirm its efficacy for small-target drone detection in complex backgrounds. To further evaluate generalization capability, experiments were conducted on the public VisDrone2019 benchmark. The suggested technique shows strong cross-domain applicability and generalization performance, achieving a 0.6% improvement in mAP@0.5 while using just 38% of the baseline model’s parameters.

| [1] |
邱小剑, 骆博雅, 付珍, 等. 国内外反无人机技术发展综述[J]. 战术导弹技术, 2024(5): 63-73.
Qiu X J, Luo B Y, Fu Z, et al. An overview on development of domestic and foreign anti-UAV technology[J]. Tactical Missile Technology, 2024(5): 63-73(in Chinese).
|
| [2] |
谢学立, 席建祥, 卢瑞涛, 等. 动态区域聚焦的反无人机红外长时跟踪算法[J]. 北京航空航天大学学报, 2025, 51(9): 3039-3051.
Xie X L, Xi J X, Lu R T, et al. Long-term infrared object tracking algorithm based on dynamic region focusing for anti-UAV[J]. Journal of Beijing University of Aeronautics and Astronautics, 2025, 51(9): 3039-3051(in Chinese).
|
| [3] |
薛珊, 张亚亮, 吕琼莹, 等. 复杂背景下的反无人机系统目标检测算法[J]. 吉林大学学报(工学版), 2023, 53(3): 891-901.
Xue S, Zhang Y L, Lyu Q Y, et al. Anti-unmanned aerial vehicle system object detection algorithm under complex background[J]. Journal of Jilin University (Engineering and Technology Edition), 2023, 53(3): 891-901(in Chinese).
|
| [4] |
薛珊, 卢涛, 吕琼莹, 等. 基于多尺度融合和轻量化网络的无人机目标检测算法[J]. 湖南大学学报(自然科学版), 2023, 50(8): 82-93.
Xue S, Lu T, Lü Q Y, et al. Drone target detection algorithm based on multi-scale fusion and lightweight network[J]. Journal of Hunan University (Natural Sciences), 2023, 50(8): 82-93(in Chinese).
|
| [5] |
薛珊, 王亚博, 吕琼莹, 等. 基于YOLOX-drone的反无人机系统抗遮挡目标检测算法[J]. 工程科学学报, 2023, 45(9): 1539-1549.
Xue S, Wang Y B, Lü Q Y, et al. Anti-occlusion target detection algorithm for anti-UAV system based on YOLOX-drone[J]. Chinese Journal of Engineering, 2023, 45(9): 1539-1549(in Chinese).
|
| [6] |
白宇, 周艳媛, 安胜彪. 改进YOLOv5的无人机小目标检测方法研究[J]. 计算机工程与应用, 2024, 60(10): 276-284.
Bai Y, Zhou Y Y, An S B. Research on UAV small object detection method improved by YOLOv5[J]. Computer Engineering and Applications, 2024, 60(10): 276-284(in Chinese).
|
| [7] |
刘玉萍, 尚翠娟, 李明明. 改进YOLOv11的无人机小目标检测算法[J]. 计算机工程与应用, 2025, 61(15): 124-131.
Liu Y P, Shang C J, Li M M. Improved YOLOv11 algorithm for small target detection in UAVs[J]. Computer Engineering and Applications, 2025, 61(15): 124-131(in Chinese).
|
| [8] |
李彬, 李生林. 改进YOLOv11n的无人机小目标检测算法[J]. 计算机工程与应用, 2025, 61(7): 96-104.
Li B, Li S L. Improved YOLOv11n small object detection algorithm in UAV view[J]. Computer Engineering and Applications, 2025, 61(7): 96-104(in Chinese).
|
| [9] |
Girshick R. Fast R-CNN[C]//Proceedings of the IEEE International Conference on Computer Vision. Piscataway: IEEE Press, 2016: 1440-1448.
|
| [10] |
Ren S Q, He K M, Girshick R, et al. Faster R-CNN: towards real-time object detection with region proposal networks[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2017, 39(6): 1137-1149.
|
| [11] |
He K M, Gkioxari G, Dollár P, et al. Mask R-CNN[C]//Proceedings of the IEEE International Conference on Computer Vision. Piscataway: IEEE Press, 2017: 2980-2988.
|
| [12] |
Liu W, Anguelov D, Erhan D, et al. SSD: single shot MultiBox detector[C]//Proceedings of the 14th European Conference on Computer Vision. Berlin: Springer, 2016: 21-37.
|
| [13] |
Redmon J, Divvala S, Girshick R, et al. You only look once: unified, real-time object detection[C]//Proceedings of the 14th IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2016: 779-788.
|
| [14] |
Wang C Y, Bochkovskiy A, Liao H M. YOLOv7: trainable bag-of-freebies sets new state-of-the-art for real-time object detectors[C]//Proceedings of the 14th IEEE/CVF Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2023: 7464-7475.
|
| [15] |
陈金林, 吴一全, 苑玉彬. 无人机视角下目标检测的YOLO系列算法研究进展[J/OL]. 北京航空航天大学学报, 2024(2024-08-26)[2025-06-20]. https://doi.org/10.13700/j.bh.1001-5965.2024.0420.
Chen J L, Wu Y Q, Yuan Y B. Research progress of YOLO series algorithms for object detection from UAV perspective[J/OL]. Journal of Beijing University of Aeronautics and Astronautics, 2024(2024-08-26)[2025-06-20]. https://doi.org/10.13700/j.bh.1001-5965.2024.0420(in Chinese).
|
| [16] |
Si Y Z, Xu H Y, Zhu X Z, et al. SCSA: exploring the synergistic effects between spatial and channel attention[EB/OL]. (2024-11-12)[2025-06-20]. https://arxiv.org/abs/2407.05128.
|
| [17] |
徐慧智, 郝东升, 徐小婷, 等. 基于深度学习的高速公路小目标检测算法[J]. 吉林大学学报(工学版), 2025, 55(6): 2003-2014.
Xu H Z, Hao D S, Xu X T, et al. Expressway small object detection algorithm based on deep learning[J]. Journal of Jilin University (Engineering and Technology Edition), 2025, 55(6): 2003-2014(in Chinese).
|
| [18] |
Zhang Y F, Ren W Q, Zhang Z, et al. Focal and efficient IOU loss for accurate bounding box regression[J]. Neurocomputing, 2022, 506: 146-157.
|
| [19] |
Zhao J, Zhang J S, Li D D, et al. Vision-based anti-UAV detection and tracking[EB/OL]. (2022-05-22)[2025-06-20]. https://arxiv.org/abs/2205.10851.
|
| [20] |
薛珊, 张振, 吕琼莹, 等. 基于卷积神经网络的反无人机系统图像识别方法[J]. 红外与激光工程, 2020, 49(7): 20200154.
Xue S, Zhang Z, Lv Q Y, et al. Image recognition method of anti UAV system based on convolutional neural network[J]. Infrared and Laser Engineering, 2020, 49(7): 20200154(in Chinese).
|
| [21] |
侯公羽, 陈钦煌, 杨振华, 等. 基于改进YOLOv5的安全帽检测算法[J]. 工程科学学报, 2024, 46(2): 329-342.
Hou G Y, Chen Q H, Yang Z H, et al. Helmet detection method based on improved YOLOv5[J]. Chinese Journal of Engineering, 2024, 46(2): 329-342(in Chinese).
|
Figures(11) / Tables(4)
Copyright © Journal of Beijing University of Aeronautics and Astronautics
Address: Editorial Department of Journal of Beijing University of Aeronautics and Astronautics, 37 Xueyuan Road, Haidian District, Beijing Post Code: 100191 Email: jbuaa@buaa.edu.cn
Supported by:
Beijing Renhe Information Technology Co., Ltd.



 DownLoad: