


Design of operational security guarantee method for DAA system based on runtime assurance
-
摘要:
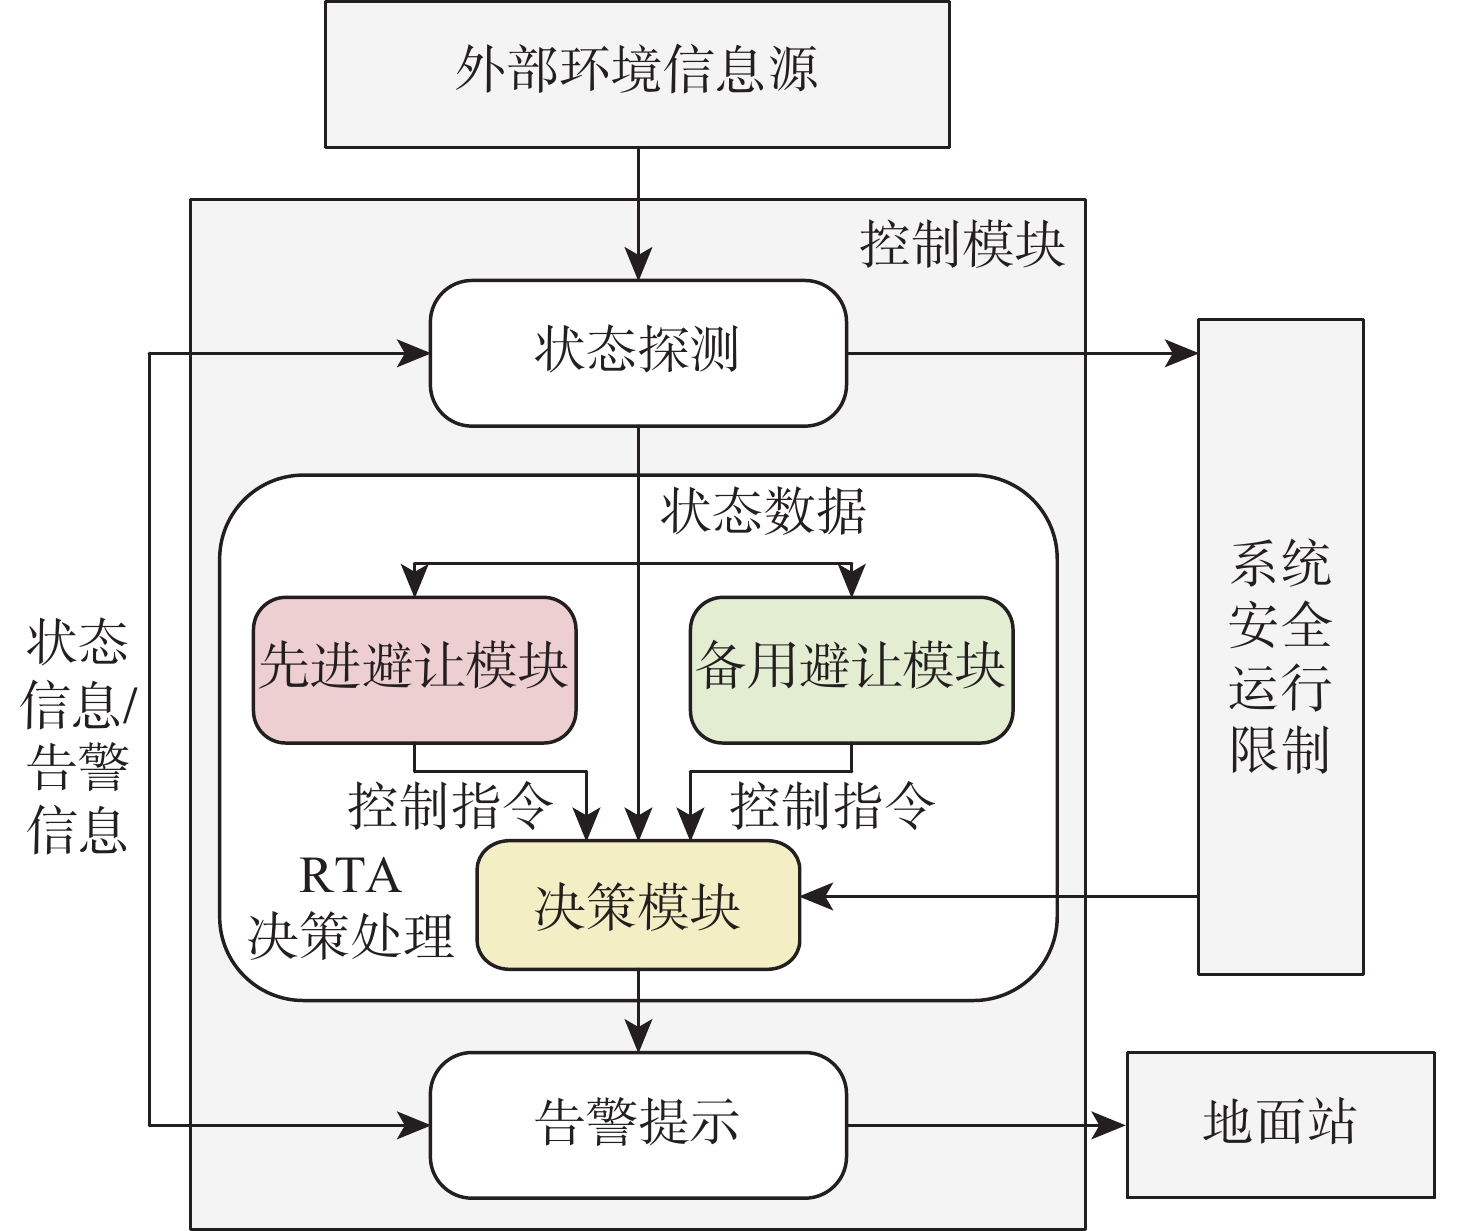
针对无人驾驶航空器在城市空中交通(UAM)场景下的避让问题,提出了一个基于运行时保证的探测与避让模块(RTA-DAAM),通过探测外部环境信息源判断航空器状态,并提供控制指令和告警信息,保证航空器在UAM场景下执行任务的高效性和安全性。对RTA-DAAM中的先进避让模块和备用避让模块的控制方法进行设计,同时考虑探测、决策和告警功能协同配合的重要性,定义航空器自身的净空边界、预防边界、障碍物的安全边界,划分不同的航空器状态,完成决策与告警逻辑的设计。仿真实验结果表明,RTA-DAAM可使航空器在仅损失3.40%效率的基础上,确保其始终存在期望分离距离,以保障DAA系统运行安全。小型无人机的实飞结果表明,RTA技术的引入可提升无人机的安全时间占比至96.9%,最大限度地确保了无人机的运行安全。
Abstract:A runtime assurance-detect and avoid module (RTA-DAAM) is proposed to address the avoidance issue of unmanned aerial vehicles in the urban air mobility (UAM) scenario. It does this by identifying external environmental information sources and providing control commands and alarm information to guarantee the effectiveness and safety of aircraft in the UAM scenario. The control methods of advanced and standby collision avoidance modules in RTA-DAAM are designed. Considering the importance of coordination of detection, decision-making and warning functions, defining the aircraft’s own clearance boundaries, prevention boundaries, and obstacle safety boundaries, and dividing the different aircraft states so as to complete the design of the decision-making and warning logics. The simulation results show that RTA-DAAM can ensure the desired separation distance of the aircraft at a loss of only 3.40% of efficiency, so as to ensure the safety of the DAA system. The implementation of RTA technology can increase UAV safety time to 96.9%, providing UAV safety to the greatest extent possible, according to the real flight results of tiny UAVs.
-
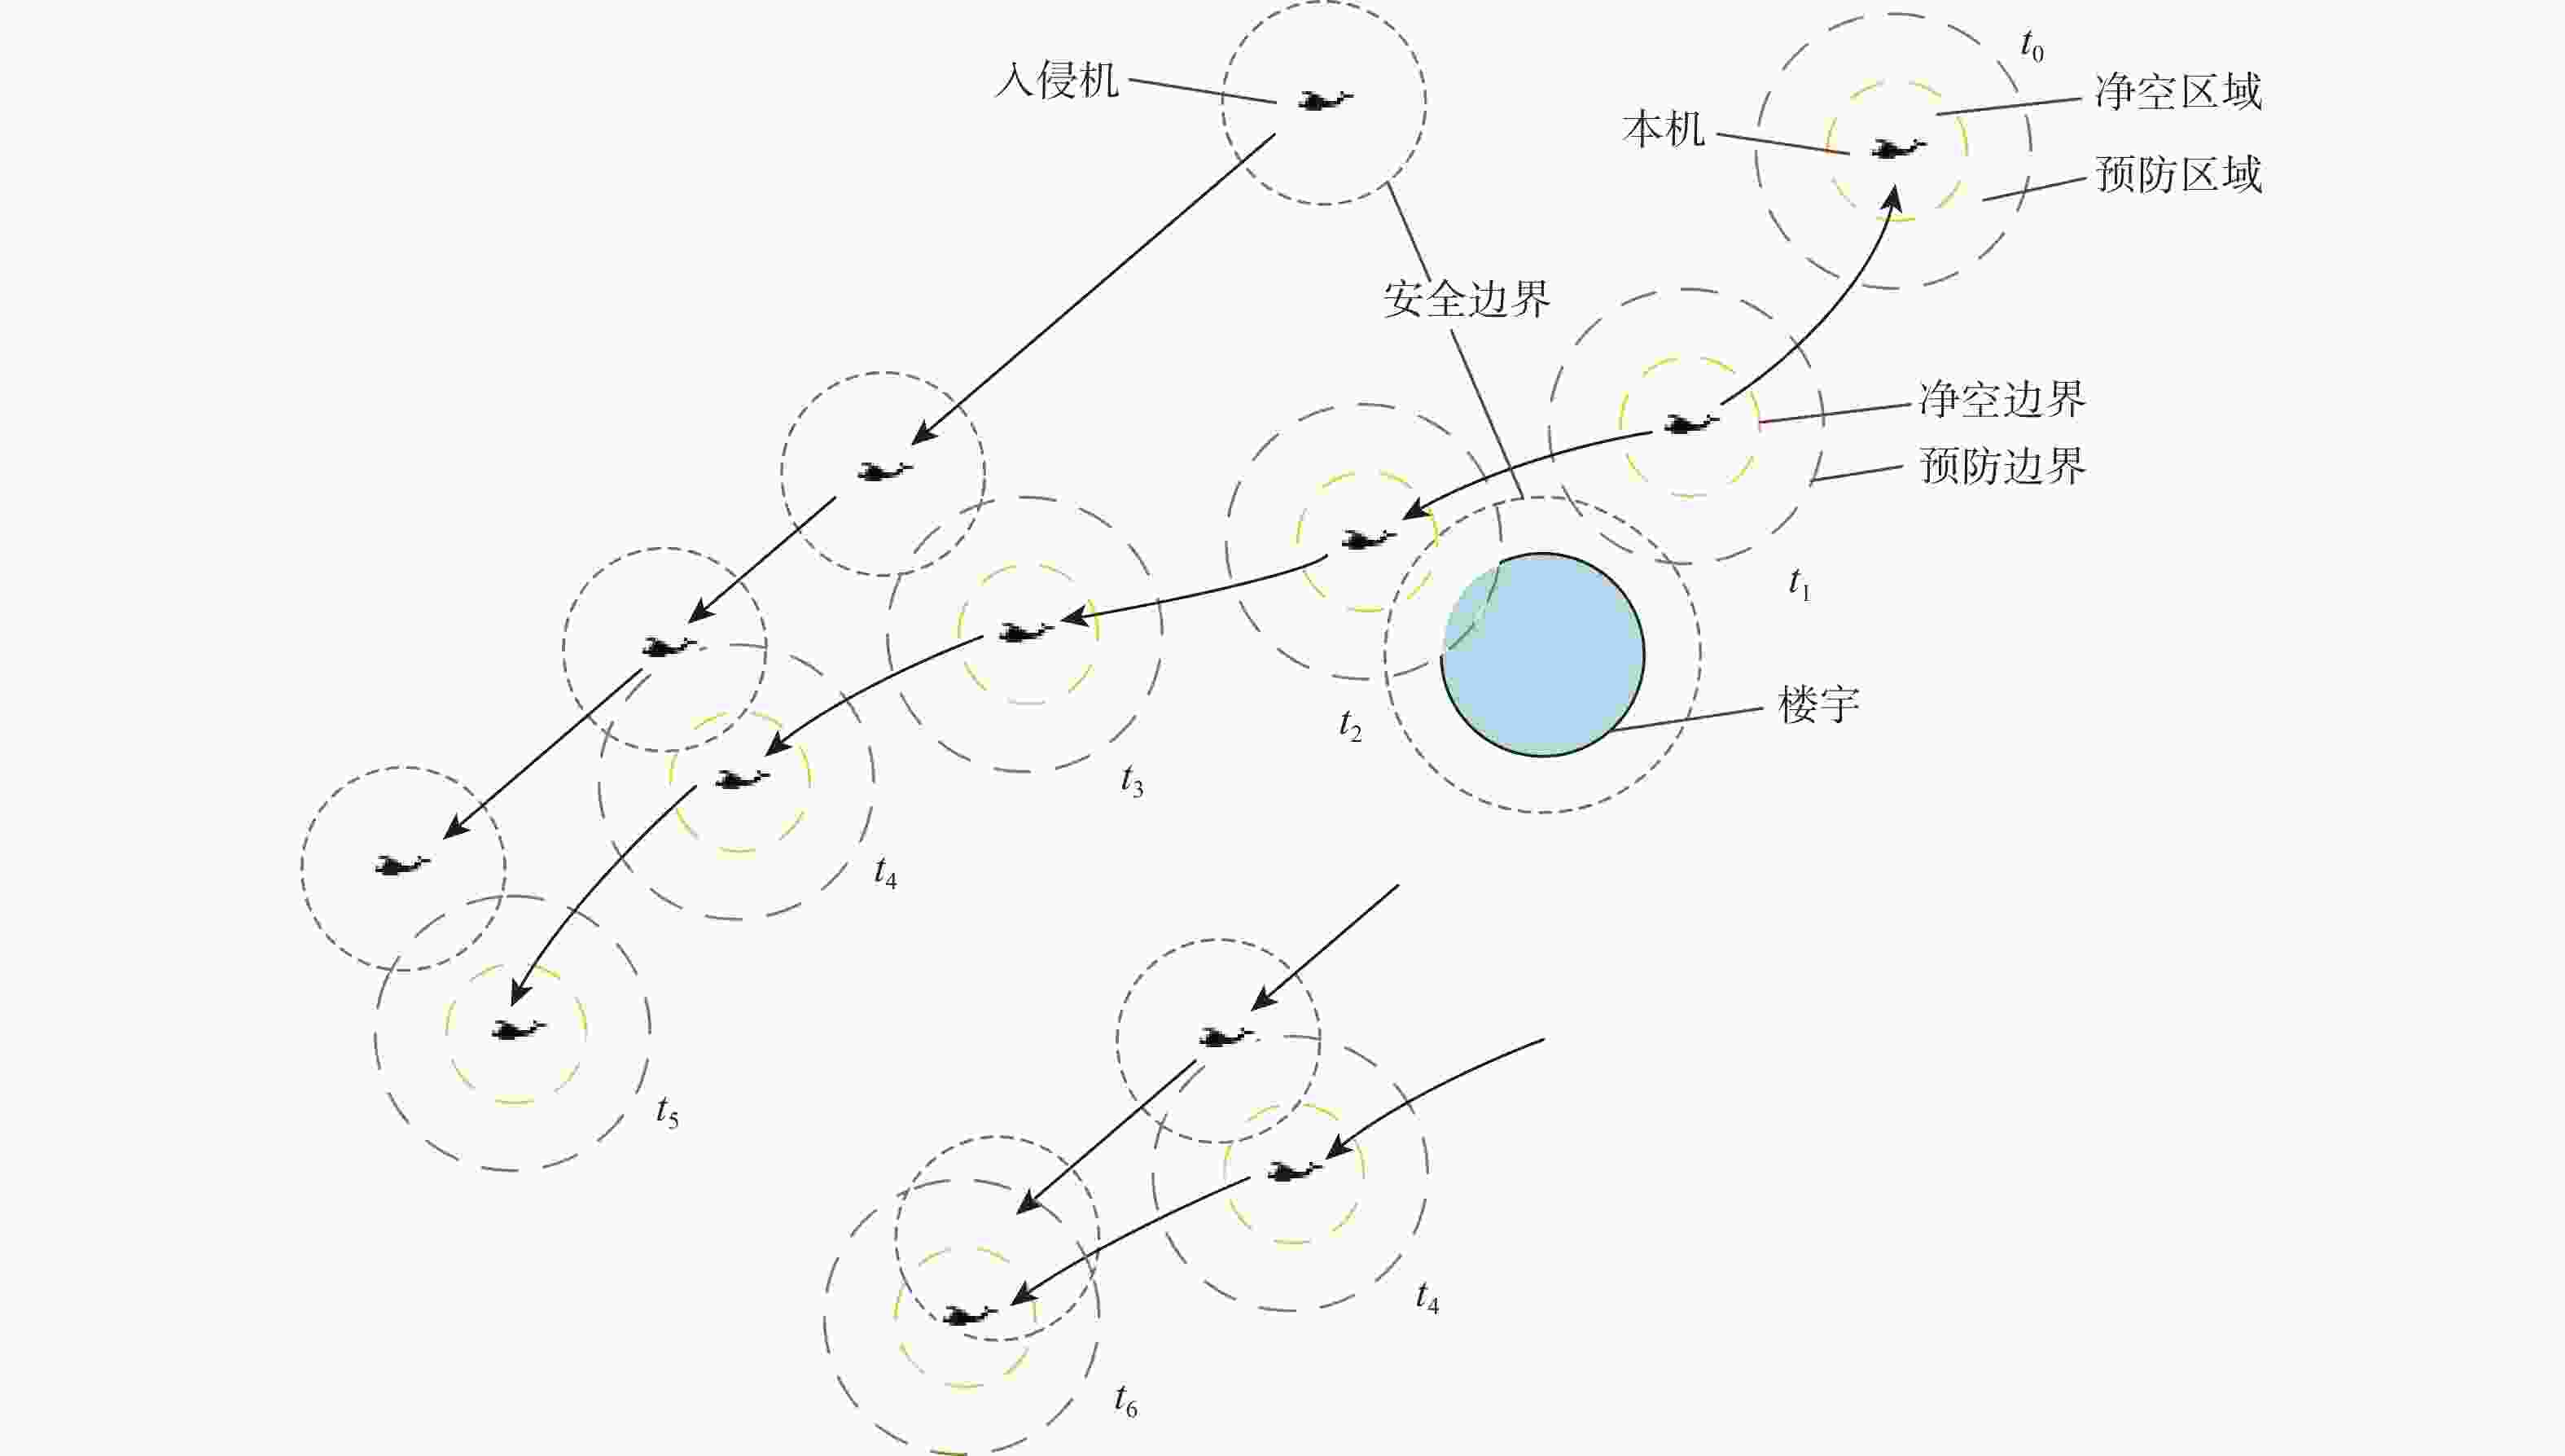
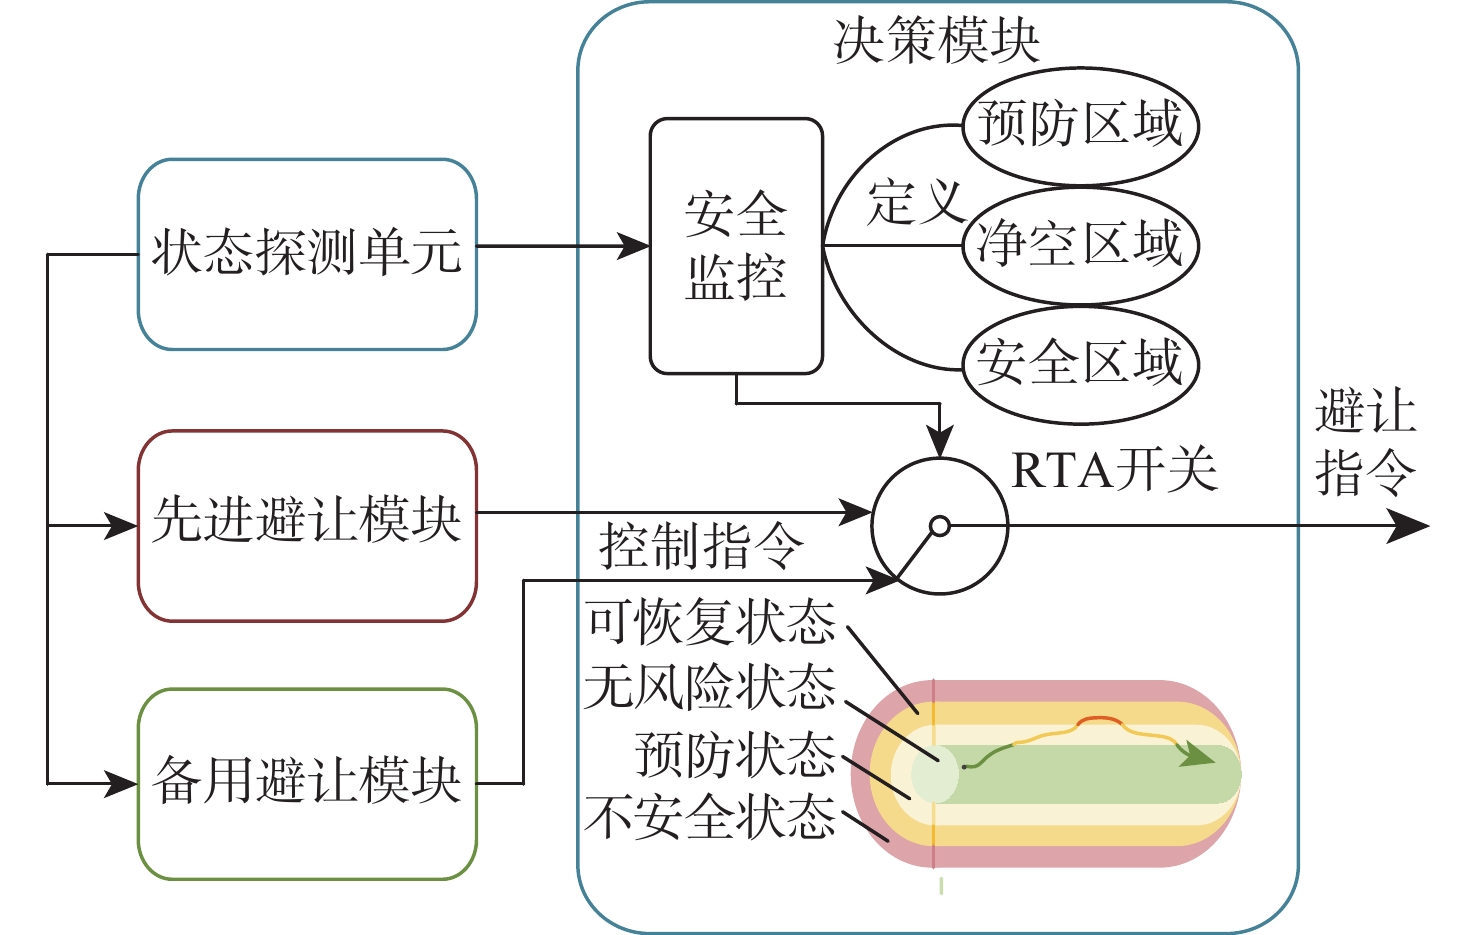
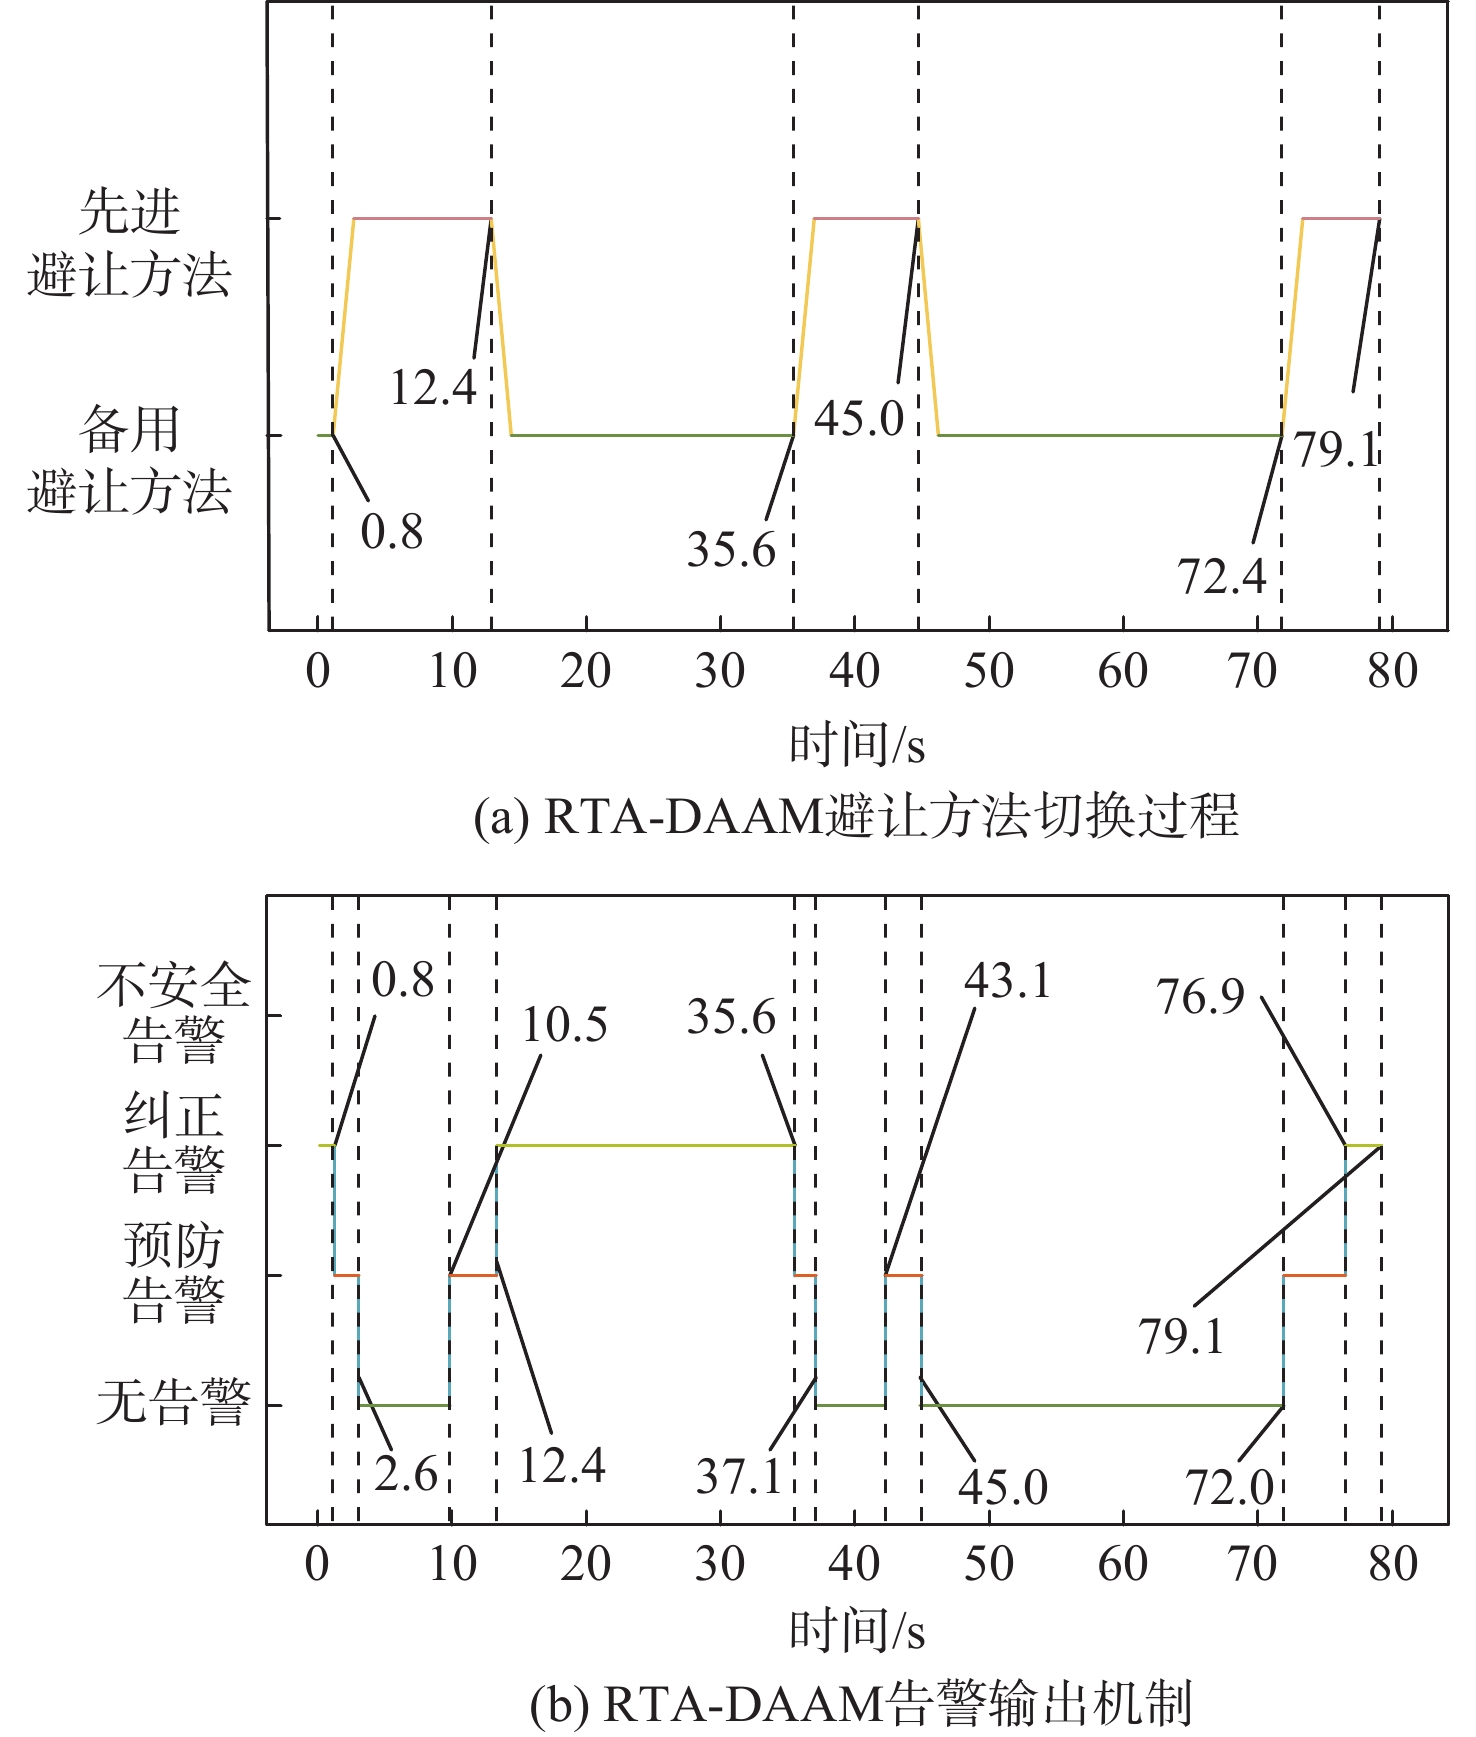
图 9 基于RTA的决策与告警逻辑示意图
Figure 9. Schematic diagram of RTA-based decision-making and alerting logic
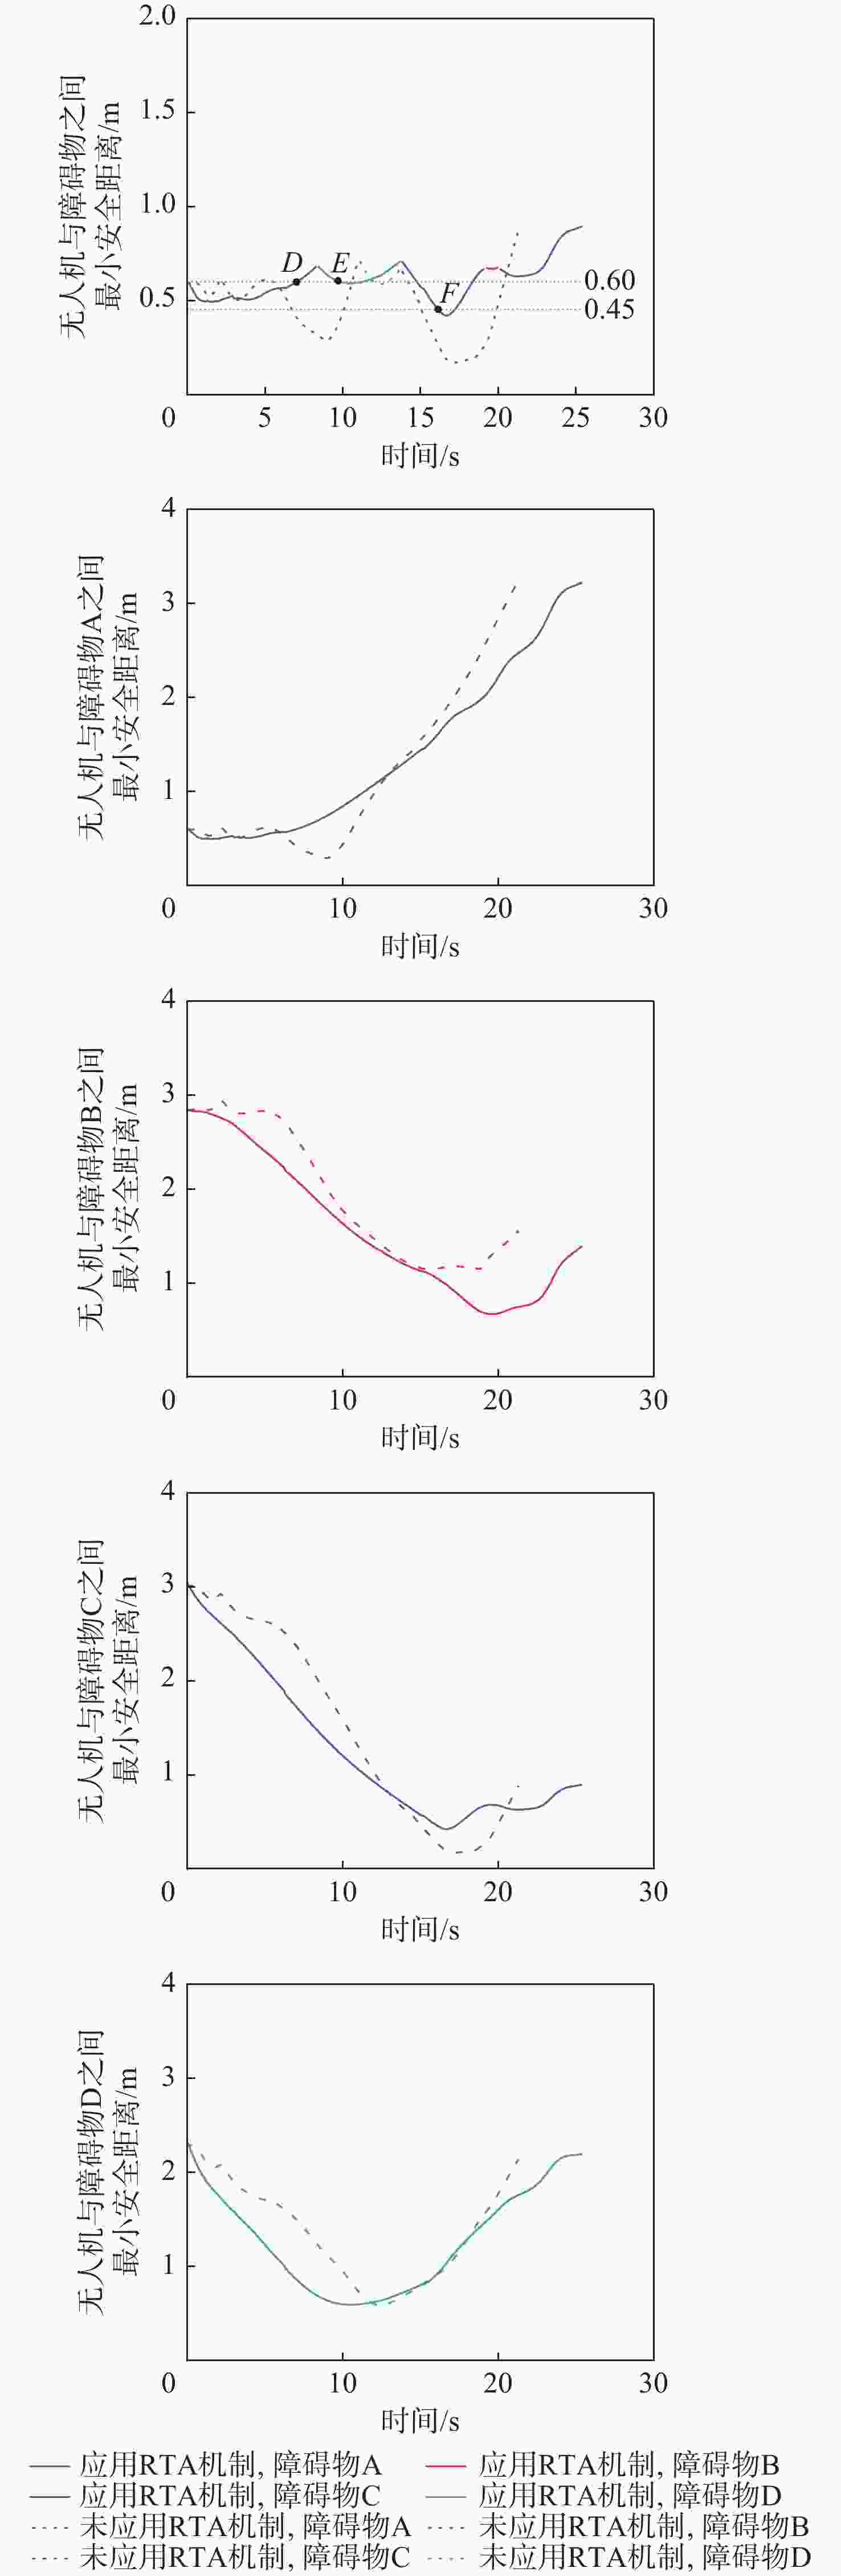
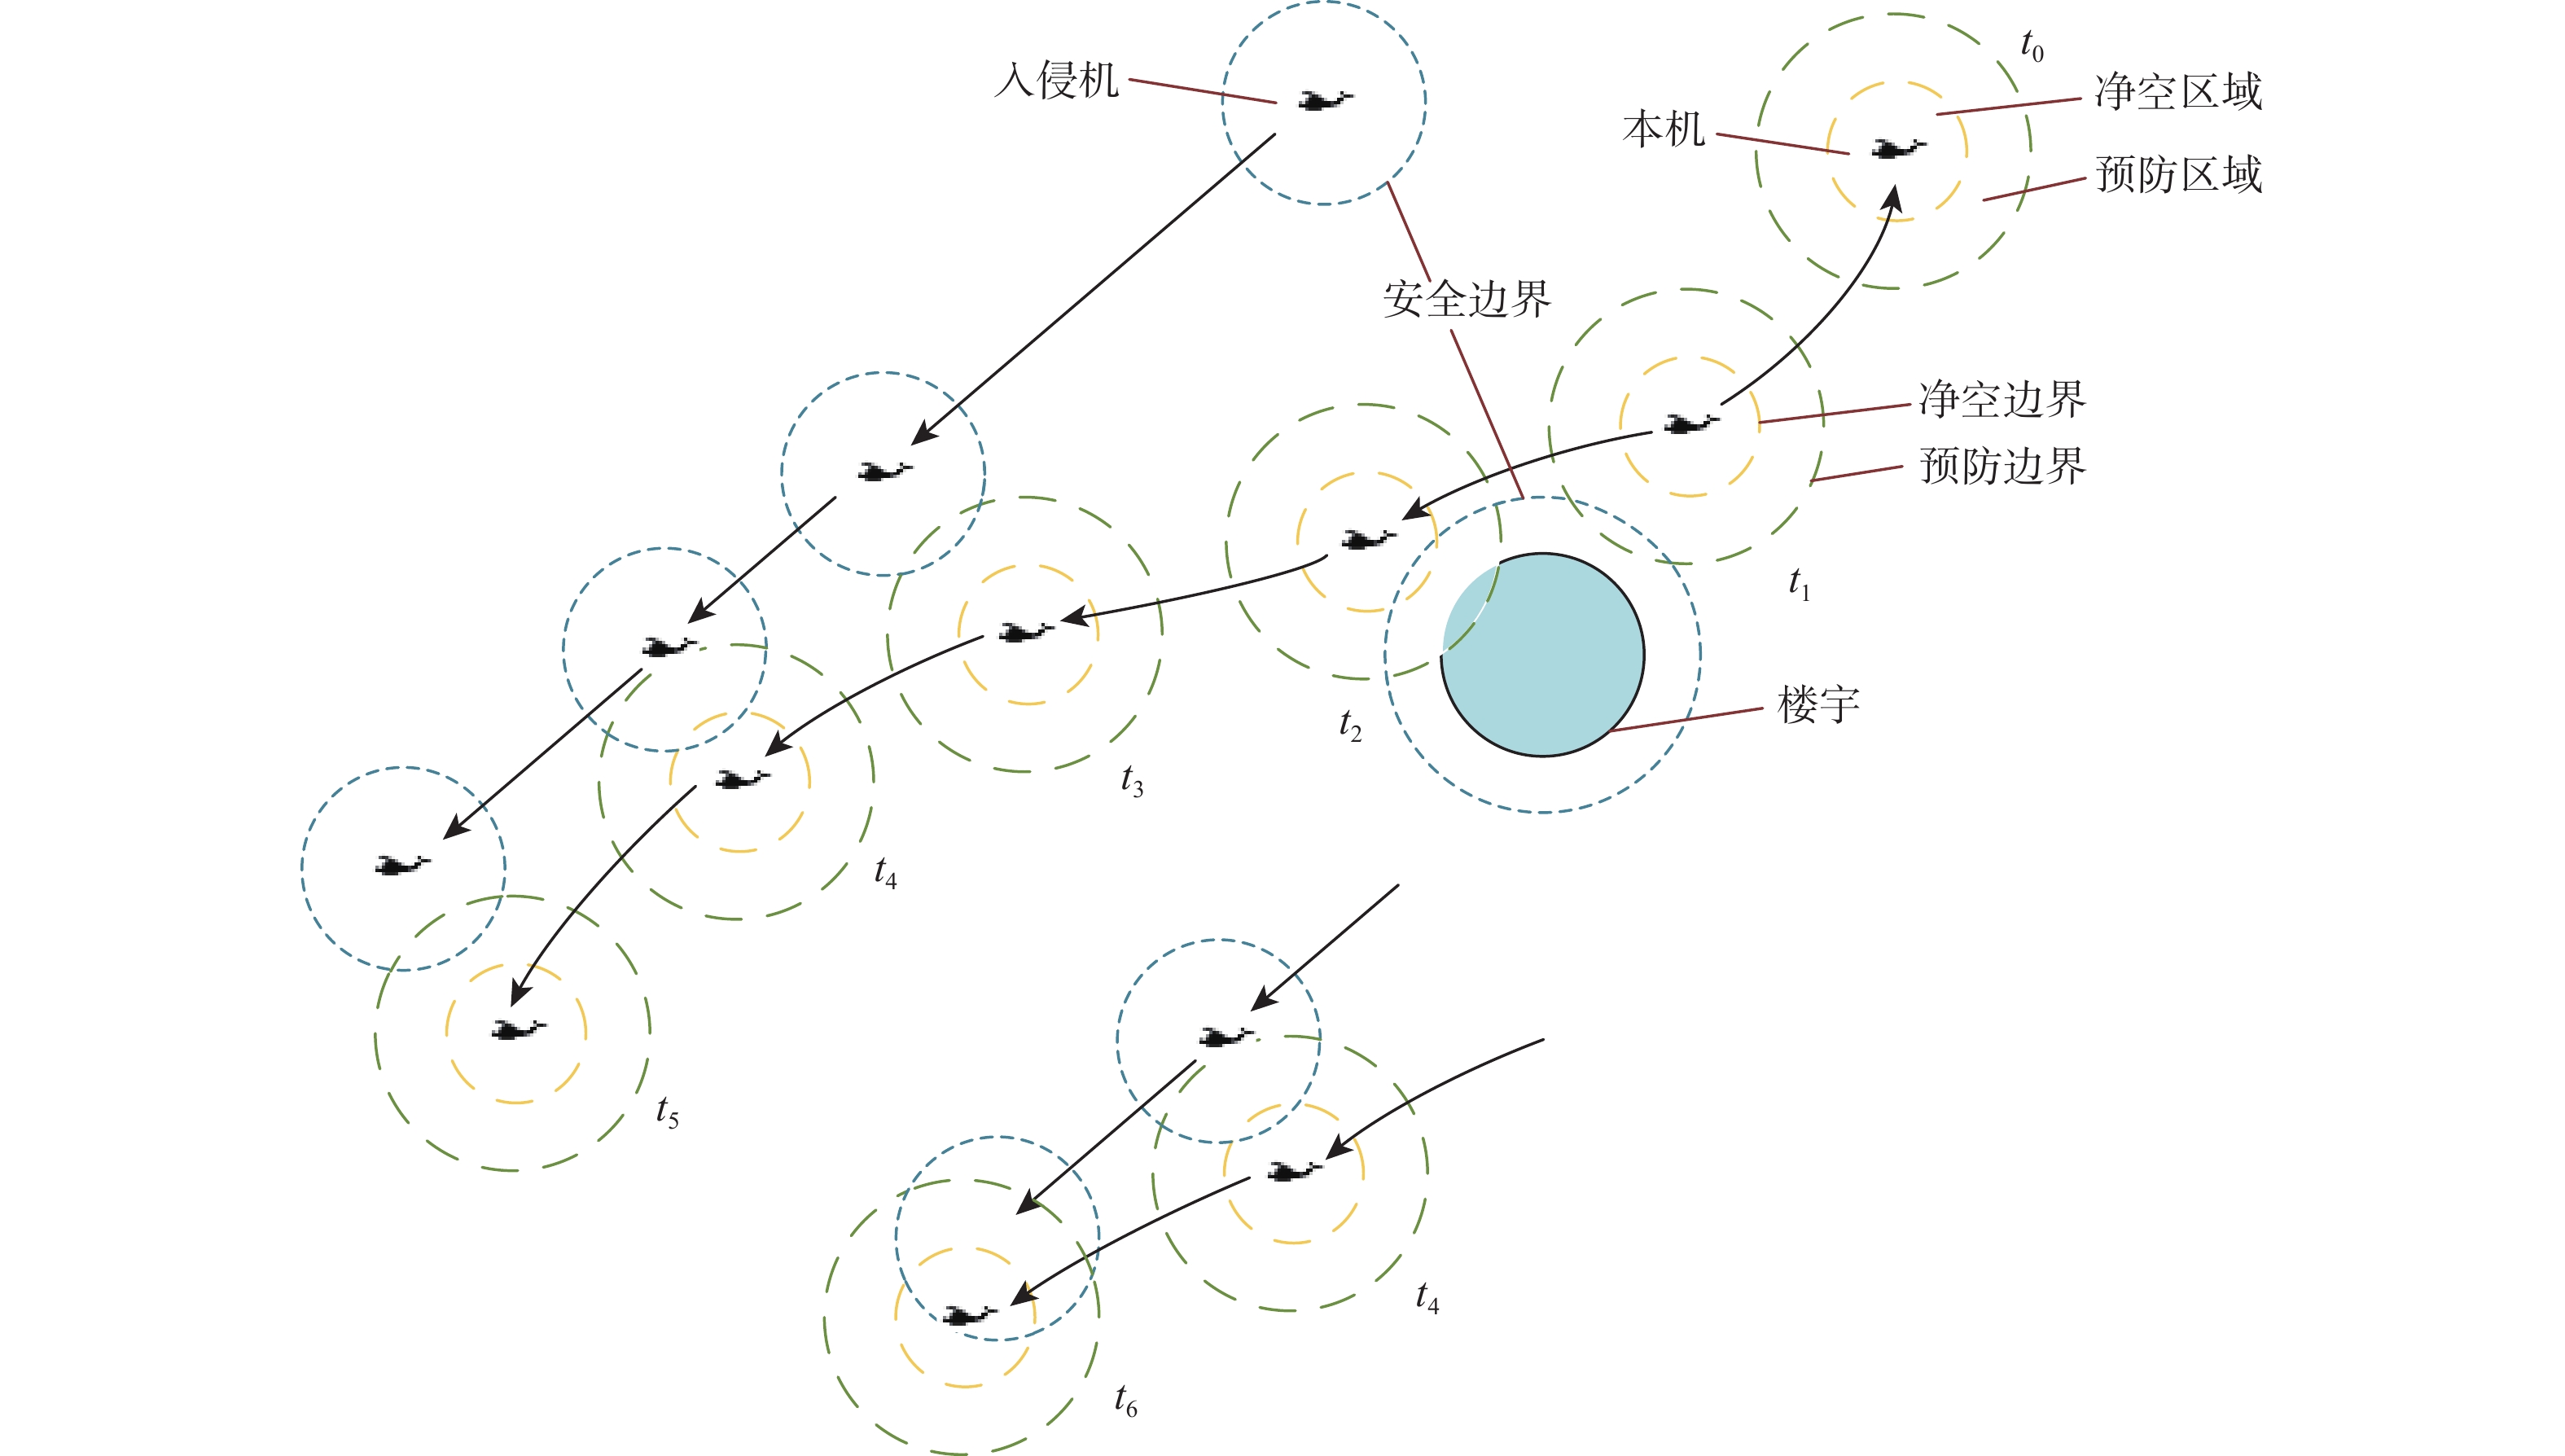
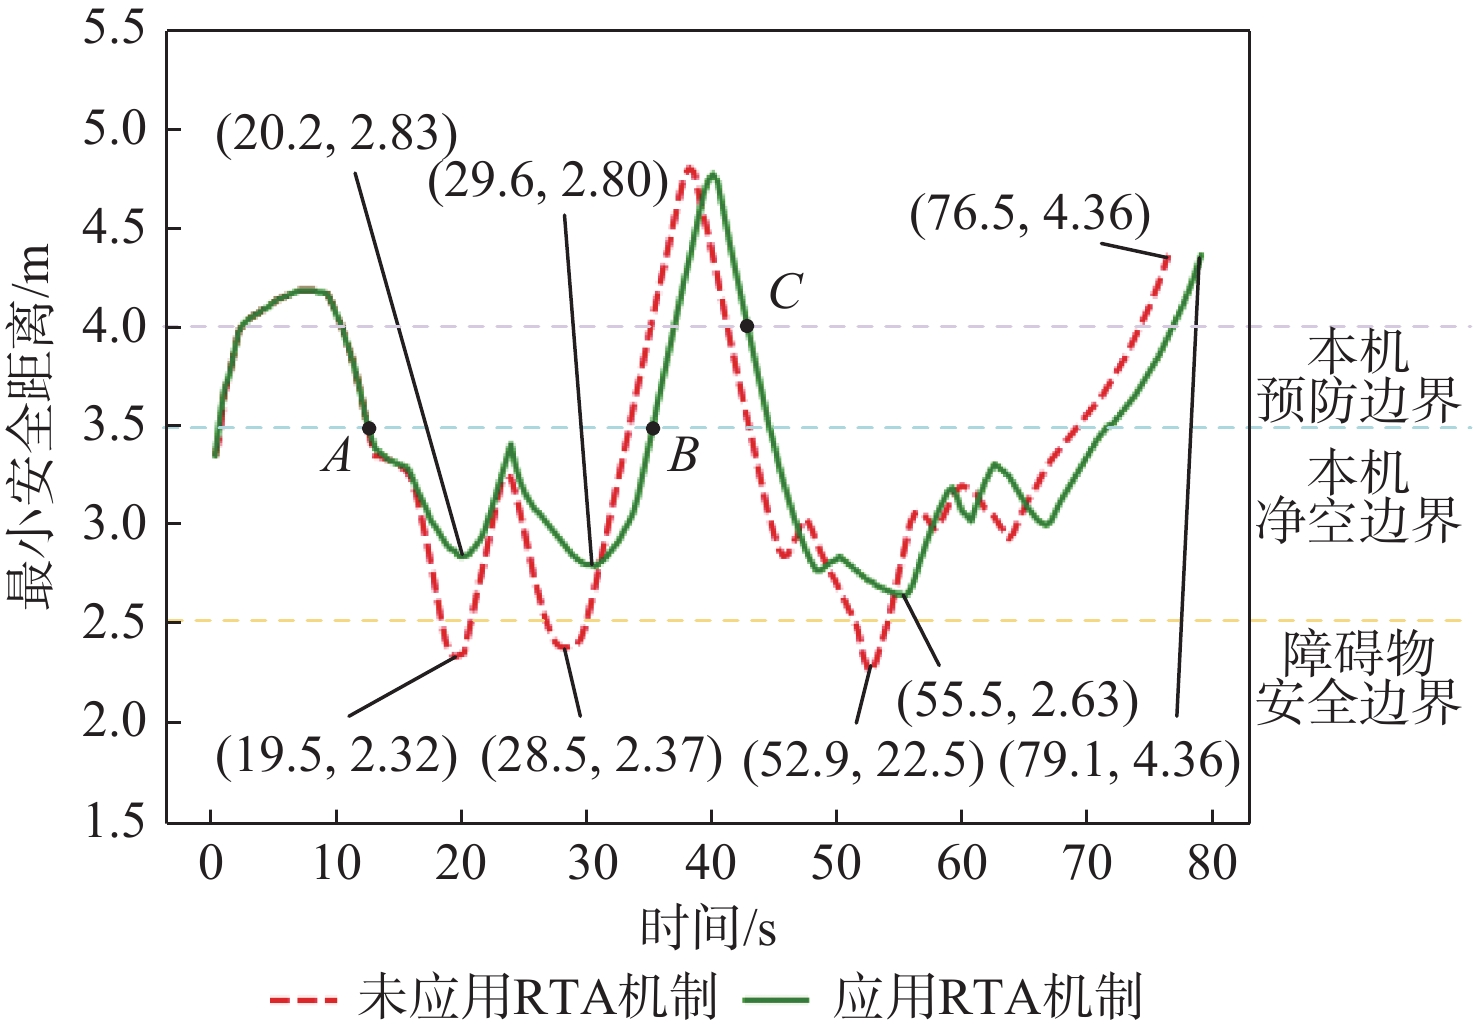
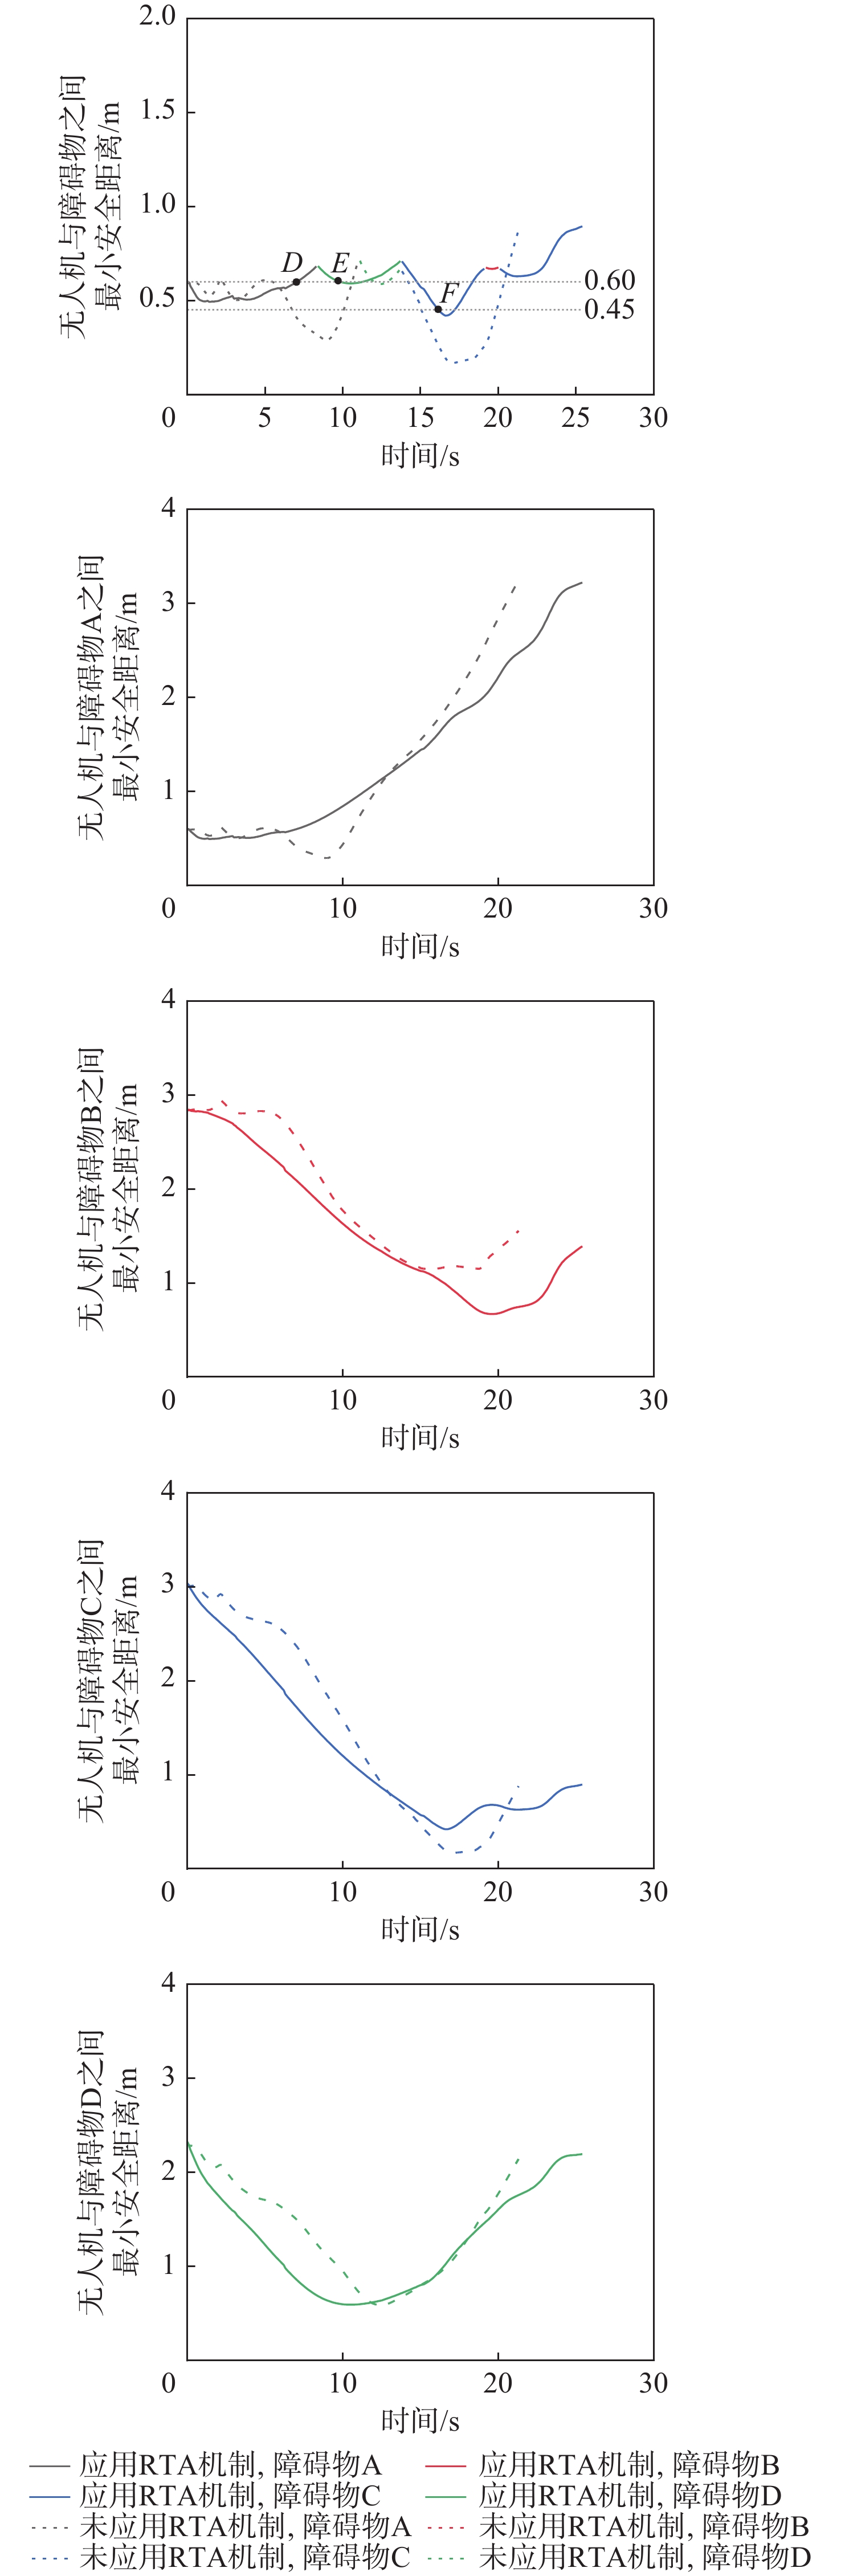
图 20 无人机与障碍物之间的最小安全距离
Figure 20. Minimum safe distance between a drone and an obstacle
表 1 告警等级
Table 1. Alarm levels
告警等级 告警名称 采取措施 0 无告警 地面站可选择性干预 Ⅰ 预防告警 地面站可选择性干预 Ⅱ 纠正告警 地面站可选择性干预 Ⅲ 危险告警 地面站干预  下载: 导出CSV
表 2 参数设置
Table 2. Parameter settings
参数 数值 本机速度/(m·s−1) 0.8 入侵机速度/(m·s−1) 0.8 障碍物安全边界宽度/m 2.5 本机净空边界半径/m 1 本机预防边界半径/m 1.5 Actor学习率 2×10⁻⁴ Critic学习率 1×10⁻³ 训练轮数/回合数 5000 批次大小/个 256 经验池容量/个 1×10⁶ 折扣因子 0.99 噪声截断值 0.5 策略噪声 0.2
下载: 导出CSV
表 3 CIFDS与IFDS算法路径规划对比
Table 3. Comparison of path planning under CIFDS and IFDS algorithms
障碍环境 最大飞行角度变化/(°) 路径长度/m CIFDS IFDS CIFDS IFDS E1 26.8 27.2 22.1 23.4 E2 28.5 32.4 23.7 26.6 E3 27.3 30.9 22.9 25.5
下载: 导出CSV
表 4 避让方法效率对比
Table 4. Comparison of efficiency of avoidance methods
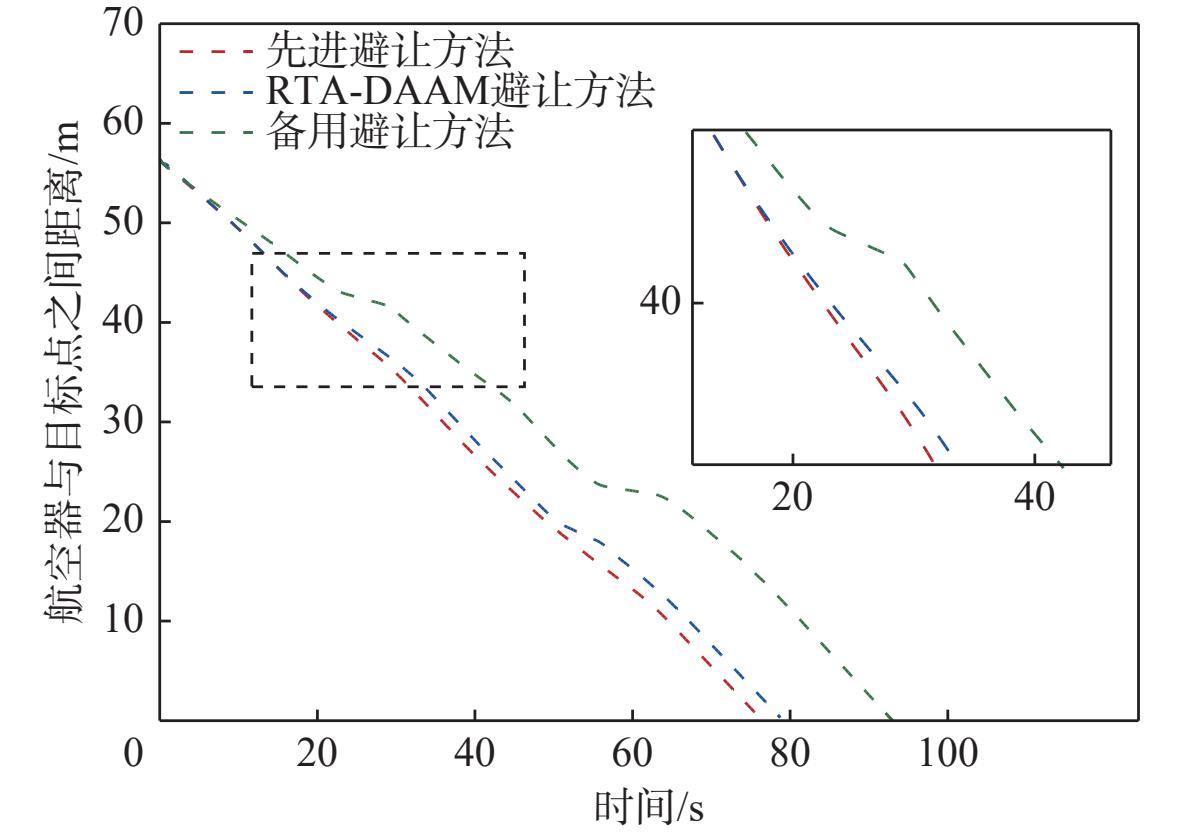
避让方法 任务执行时间/s 路径长度/m 先进避让方法 76.5 61.2 RTA-DAAM避让方法 79.1 63.3 备用避让方法 93.0 74.4
下载: 导出CSV
表 5 不同密度场景下的航空器路径规划对比
Table 5. Comparison of aircraft path planning in different density scenarios
场景类型 安全时间占比/% 路径长度/m 先进
避让方法RTA-DAAM
避让方法先进
避让方法RTA-DAAM
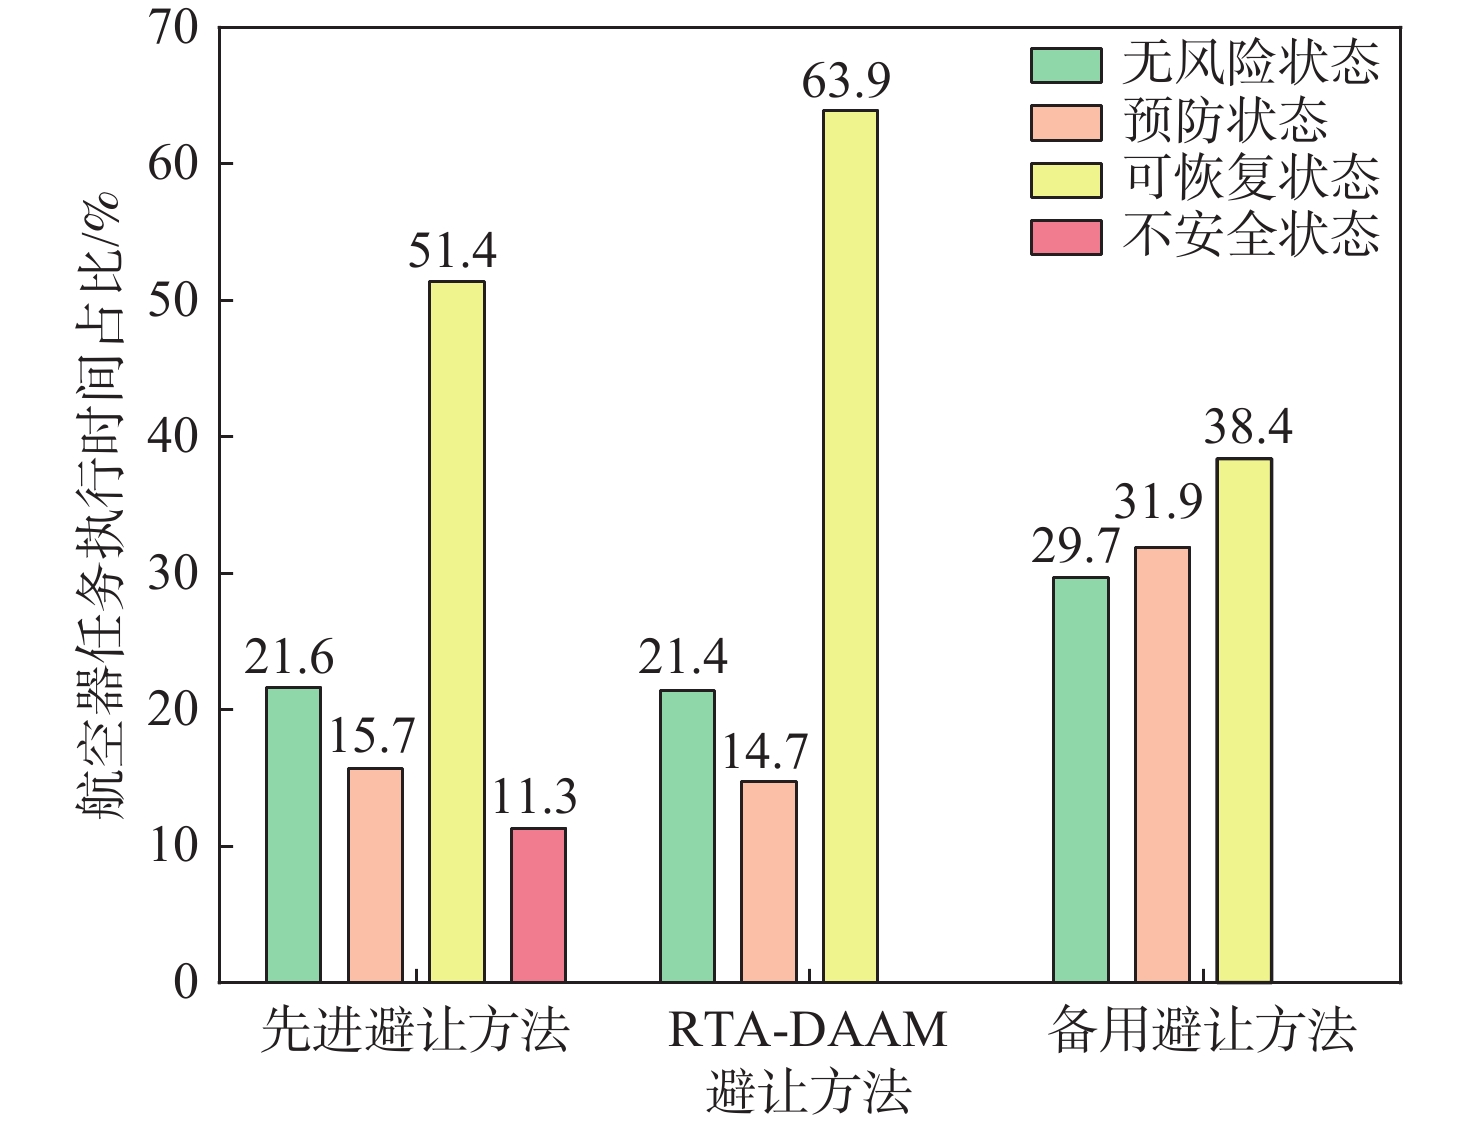
避让方法低密集度 100.0 100.0 60.8 61.4 中密集度 91.9 98.5 62.1 65.8 高密集度 77.2 93.8 65.6 74.7
下载: 导出CSV
-
[1] Huang X. The small-drone revolution is coming: scientists need to ensure it will be safe[J]. Nature, 2025, 637(8044): 29-30. [2] Thipphavong D P, Apaza R, Barmore B, et al. Urban air mobility airspace integration concepts and considerations[C]//Proceedings of the Aviation Technology, Integration, and Operations Conference. Reston: AIAA, 2018: 3676. [3] Michelmann J, Straubinger A, Al Haddad C, et al. Urban air mobility 2030+: pathways for UAM–a scenario-based analysis[EB/OL]. [2025-03-01]. https://www.semanticscholar.org/paper/URBAN-AIR-MOBILITY-2030%2B%3A-PATHWAYS-FOR-UAM-%E2%80%93-A-Michelmann-Straubinger/dde5cd91a5cd19fd5cec68241fb59bc954e2eed0. [4] Cheng A W, Witzberger K E, Phojanamongkolkij N, et al. Urban air mobility (UAM) airspace research roadmap-systems engineering approach to managing airspace evolution towards UML-4[C]//AIAA Aviation 2022 Forum. Reston: AIAA, 2022. [5] Muñoz C, Narkawicz A, Hagen G, et al. DAIDALUS: detect and avoid alerting logic for unmanned systems[C]//Proceedings of the IEEE/AIAA 34th Digital Avionics Systems Conference. Piscataway: IEEE Press, 2015. [6] Davies J, Wu M H. Comparative analysis of ACAS-Xu and DAIDALUS detect-and-avoid systems: NASA/TM-2018-219773[R]. Washington, D. C. : NASA, 2018. [7] Ryu J Y, Lee H, Lee H T. Detect and avoid AI system model using a deep neural network[C]//Proceedings of the IEEE/AIAA 41st Digital Avionics Systems Conference. Piscataway: IEEE Press, 2022: 1-8. [8] 工业和信息化部, 科学技术部, 财政部, 中国民用航空局. 绿色航空制造业发展纲要(2023—2035年)[R]. 北京: 工业和信息化部, 科学技术部, 财政部, 中国民用航空局, 2023.Ministry of Industry and Information Technology, Ministry of Science and Technology, Ministry of Finance, Civil Aviation Administration of China. Guideline for green aviation manufacturing development (2023—2035)[R]. Beijing: Ministry of Industry and Information Technology, Ministry of Science and Technology, Ministry of Finance, Civil Aviation Administration of China, 2023(in Chinese). [9] 曹宏业, 刘潇, 董绍康, 等. 面向强化学习的可解释性研究综述[J]. 计算机学报, 2024, 47(8): 1853-1882.Cao H Y, Liu X, Dong S K, et al. A survey of interpretability research methods for reinforcement learning[J]. Chinese Journal of Computers, 2024, 47(8): 1853-1882(in Chinese). [10] Castelvecchi D. Can we open the black box of AI?[J]. Nature, 2016, 538(7623): 20-23. [11] Perez-Cerrolaza J, Abella J, Borg M, et al. Artificial intelligence for safety-critical systems in industrial and transportation domains: a survey[J]. ACM Computing Surveys, 2024, 56(7): 1-40. [12] 董磊, 刘嘉琛, 陈曦, 等. 面向适航符合性的智能航电系统认证研究进展[J]. 航空工程进展, 2023, 14(3): 26-40.Dong L, Liu J C, Chen X, et al. Research progress of AI-based avionics system certification for airworthiness compliance[J]. Advances in Aeronautical Science and Engineering, 2023, 14(3): 26-40(in Chinese). [13] Fuller J G. Run-time assurance: a rising technology[C]//Proceedings of the AIAA/IEEE 39th Digital Avionics Systems Conference. Piscataway: IEEE Press, 2020: 1-9. [14] 董磊, 王琦, 陈曦, 等. 运行时保证技术的研究现状与发展综述[J]. 计算机应用, 2025, 45(3): 1003-1015.Dong L, Wang Q, Chen X, et al. Survey of research status and development of runtime assurance technology[J]. Journal of Computer Applications, 2025, 45(3): 1003-1015(in Chinese). [15] Cofer D, Amundson I, Sattigeri R, et al. Run-time assurance for learning-based aircraft taxiing[C]//Proceedings of the AIAA/IEEE 39th Digital Avionics Systems Conference. Piscataway: IEEE Press, 2020: 1-9. [16] He Y N, Schumann J, Yu H F. Toward runtime assurance of complex systems with AI components[J]. PHM Society European Conference, 2022, 7(1): 166-174. [17] Ghori S, Khamvilai T, Feron E, et al. Runtime assurance for distributed avionics architecture[C]//Proceedings of the IEEE/AIAA 41st Digital Avionics Systems Conference. Piscataway: IEEE Press, 2022: 1-6. [18] Abate M, Mote M, Dor M, et al. Run time assurance for spacecraft attitude control under nondeterministic assumptions[J]. IEEE Transactions on Control Systems Technology, 2024, 32(3): 862-873. [19] Avram R, Zhang X D, Muse J A, et al. Nonlinear adaptive control of quadrotor UAVs with run-time safety assurance[C]//Proceedings of the AIAA Guidance, Navigation, and Control Conference. Reston: AIAA, 2017: 1896. [20] Chen S D, Sun Y W, Li D C, et al. Runtime safety assurance for learning-enabled control of autonomous driving vehicles[C]//Proceedings of the International Conference on Robotics and Automation. Piscataway: IEEE Press, 2022: 8978-8984. [21] 高雅琪. 无人机系统中DAA模块的研究和设计实现[D]. 成都: 电子科技大学, 2022.Gao Y Q. Research design and implementation on DAA module of UAV system[D]. Chengdu: University of Electronic Science and Technology of China, 2022(in Chinese). [22] Owen M P, Panken A, Moss R, et al. ACAS Xu: integrated collision avoidance and detect and avoid capability for UAS[C]//Proceedings of the IEEE/AIAA 38th Digital Avionics Systems Conference. Piscataway: IEEE Press, 2020: 1-10. [23] Borshchova I, Ellis K. DAAMSIM: a simulation framework for establishing detect and avoid SYSTEM requirements[J]. Drone Systems and Applications, 2022, 10(1): 266-286. [24] ASTM International. Standard practice for methods to safely bound behavior of aircraft systems containing complex functions using run-time assurance: ASTM F3269-21[S]. West Conshohocken: ASTM International, 2021. [25] Torens C, Nagarajan P, Schirmer S, et al. Certification aspects of runtime assurance for urban air mobility: AIAA 2024-1464[R]. Reston: AIAA, 2024. [26] Wang H L, Lyu W T, Yao P, et al. Three-dimensional path planning for unmanned aerial vehicle based on interfered fluid dynamical system[J]. Chinese Journal of Aeronautics, 2015, 28(1): 229-239. [27] Yao P, Wang H L, Liu C. 3-D dynamic path planning for UAV based on interfered fluid flow[C]//Proceedings of the IEEE Chinese Guidance, Navigation and Control Conference. Piscataway: IEEE Press, 2015: 997-1002. [28] Li Y X. Deep reinforcement learning: an overview[EB/OL]. (2018-11-26)[2025-03-01]. https://arxiv.org/abs/1701.07274. [29] Szepesvári C. Algorithms for reinforcement learning[M]. Berlin: Springer, 2022. [30] 吴健发, 王宏伦, 王延祥, 等. 无人机反应式扰动流体路径规划[J]. 自动化学报, 2023, 49(2): 272-287.Wu J F, Wang H L, Wang Y X, et al. UAV reactive interfered fluid path planning[J]. Acta Automatica Sinica, 2023, 49(2): 272-287(in Chinese). [31] 顾雪平, 刘彤, 李少岩, 等. 基于改进双延迟深度确定性策略梯度算法的电网有功安全校正控制[J]. 电工技术学报, 2023, 38(8): 2162-2177.Gu X P, Liu T, Li S Y, et al. Active power correction control of power grid based on improved twin delayed deep deterministic policy gradient algorithm[J]. Transactions of China Electrotechnical Society, 2023, 38(8): 2162-2177(in Chinese). [32] Zhou X, Wang Z P, Ye H K, et al. EGO-Planner: an ESDF-free gradient-based local planner for quadrotors[J]. IEEE Robotics and Automation Letters, 2021, 6(2): 478-485. -

 下载:

 点击查看大图
计量
- 文章访问数: 256
- HTML全文浏览量: 117
- PDF下载量: 19
- 被引次数: 0
