


Extended low-altitude aircraft tracking via navigation-assisted radar measurement augmentations
-
摘要:
合作式浮低空飞行器飞行测试中,单站高分辨雷达对飞行器表面部分观测时存在雷达量测稀疏(乃至缺失)、空间完备性差,致使飞行器跟踪精度欠佳的问题,对此,提出一种融合飞行器导航信息辅助雷达量测增强的飞行器跟踪方法。根据飞行器结构扩展特点,利用随机矩阵模型建模其近似为椭圆体的三维扩展形态;分别建立飞行器部分观测模型及雷达测量模型,进一步设计多种利用飞行器导航信息辅助雷达稀疏量测数据增强策略,以提升量测数据量及空间完备性;基于贝叶斯滤波框架实现部分观测下的飞行器状态估计。仿真实验结果表明:所提方法不仅提升了受试飞行器的跟踪精度及飞行态势感知精度,还兼有多源测控信息融合利用度高及计算成本低等优点。
Abstract:In the flight test of cooperative aircraft floating at low altitudes, a single-station high-resolution radar can get sparse (even missing) and spatially incomplete measurements, while the radar observes a partial surface of the aircraft. This will lead to poor tracking accuracy for the tested aircraft. To solve this problem, this paper proposes a tracking method using augmented radar measurements by fusing aircraft navigation information. First, a symmetric positive definite random matrix is used to approximate the aircraft’s three-dimensional extension shape, which is roughly ellipsoidal, based on the structurally extended characteristic of the aircraft identified by the high-resolution radar. Subsequently, the partially observed aircraft model and the radar measurement model are both established. Further, multiple strategies are designed to augment sparse radar measurements using assisted aircraft navigation information, such that the radar measurement data is improved in both amount and spatial completeness. Finally, an implementation of aircraft state estimation under partial observation is given within the Bayesian filtering framework. The outcomes of the simulation experiment show that the proposed method improves the tested aircraft’s tracking accuracy and, consequently, awareness accuracy for its flight condition. Moreover, the proposed method has the advantages of high fusion usage of multi-source measurement information and a low computational cost.
-
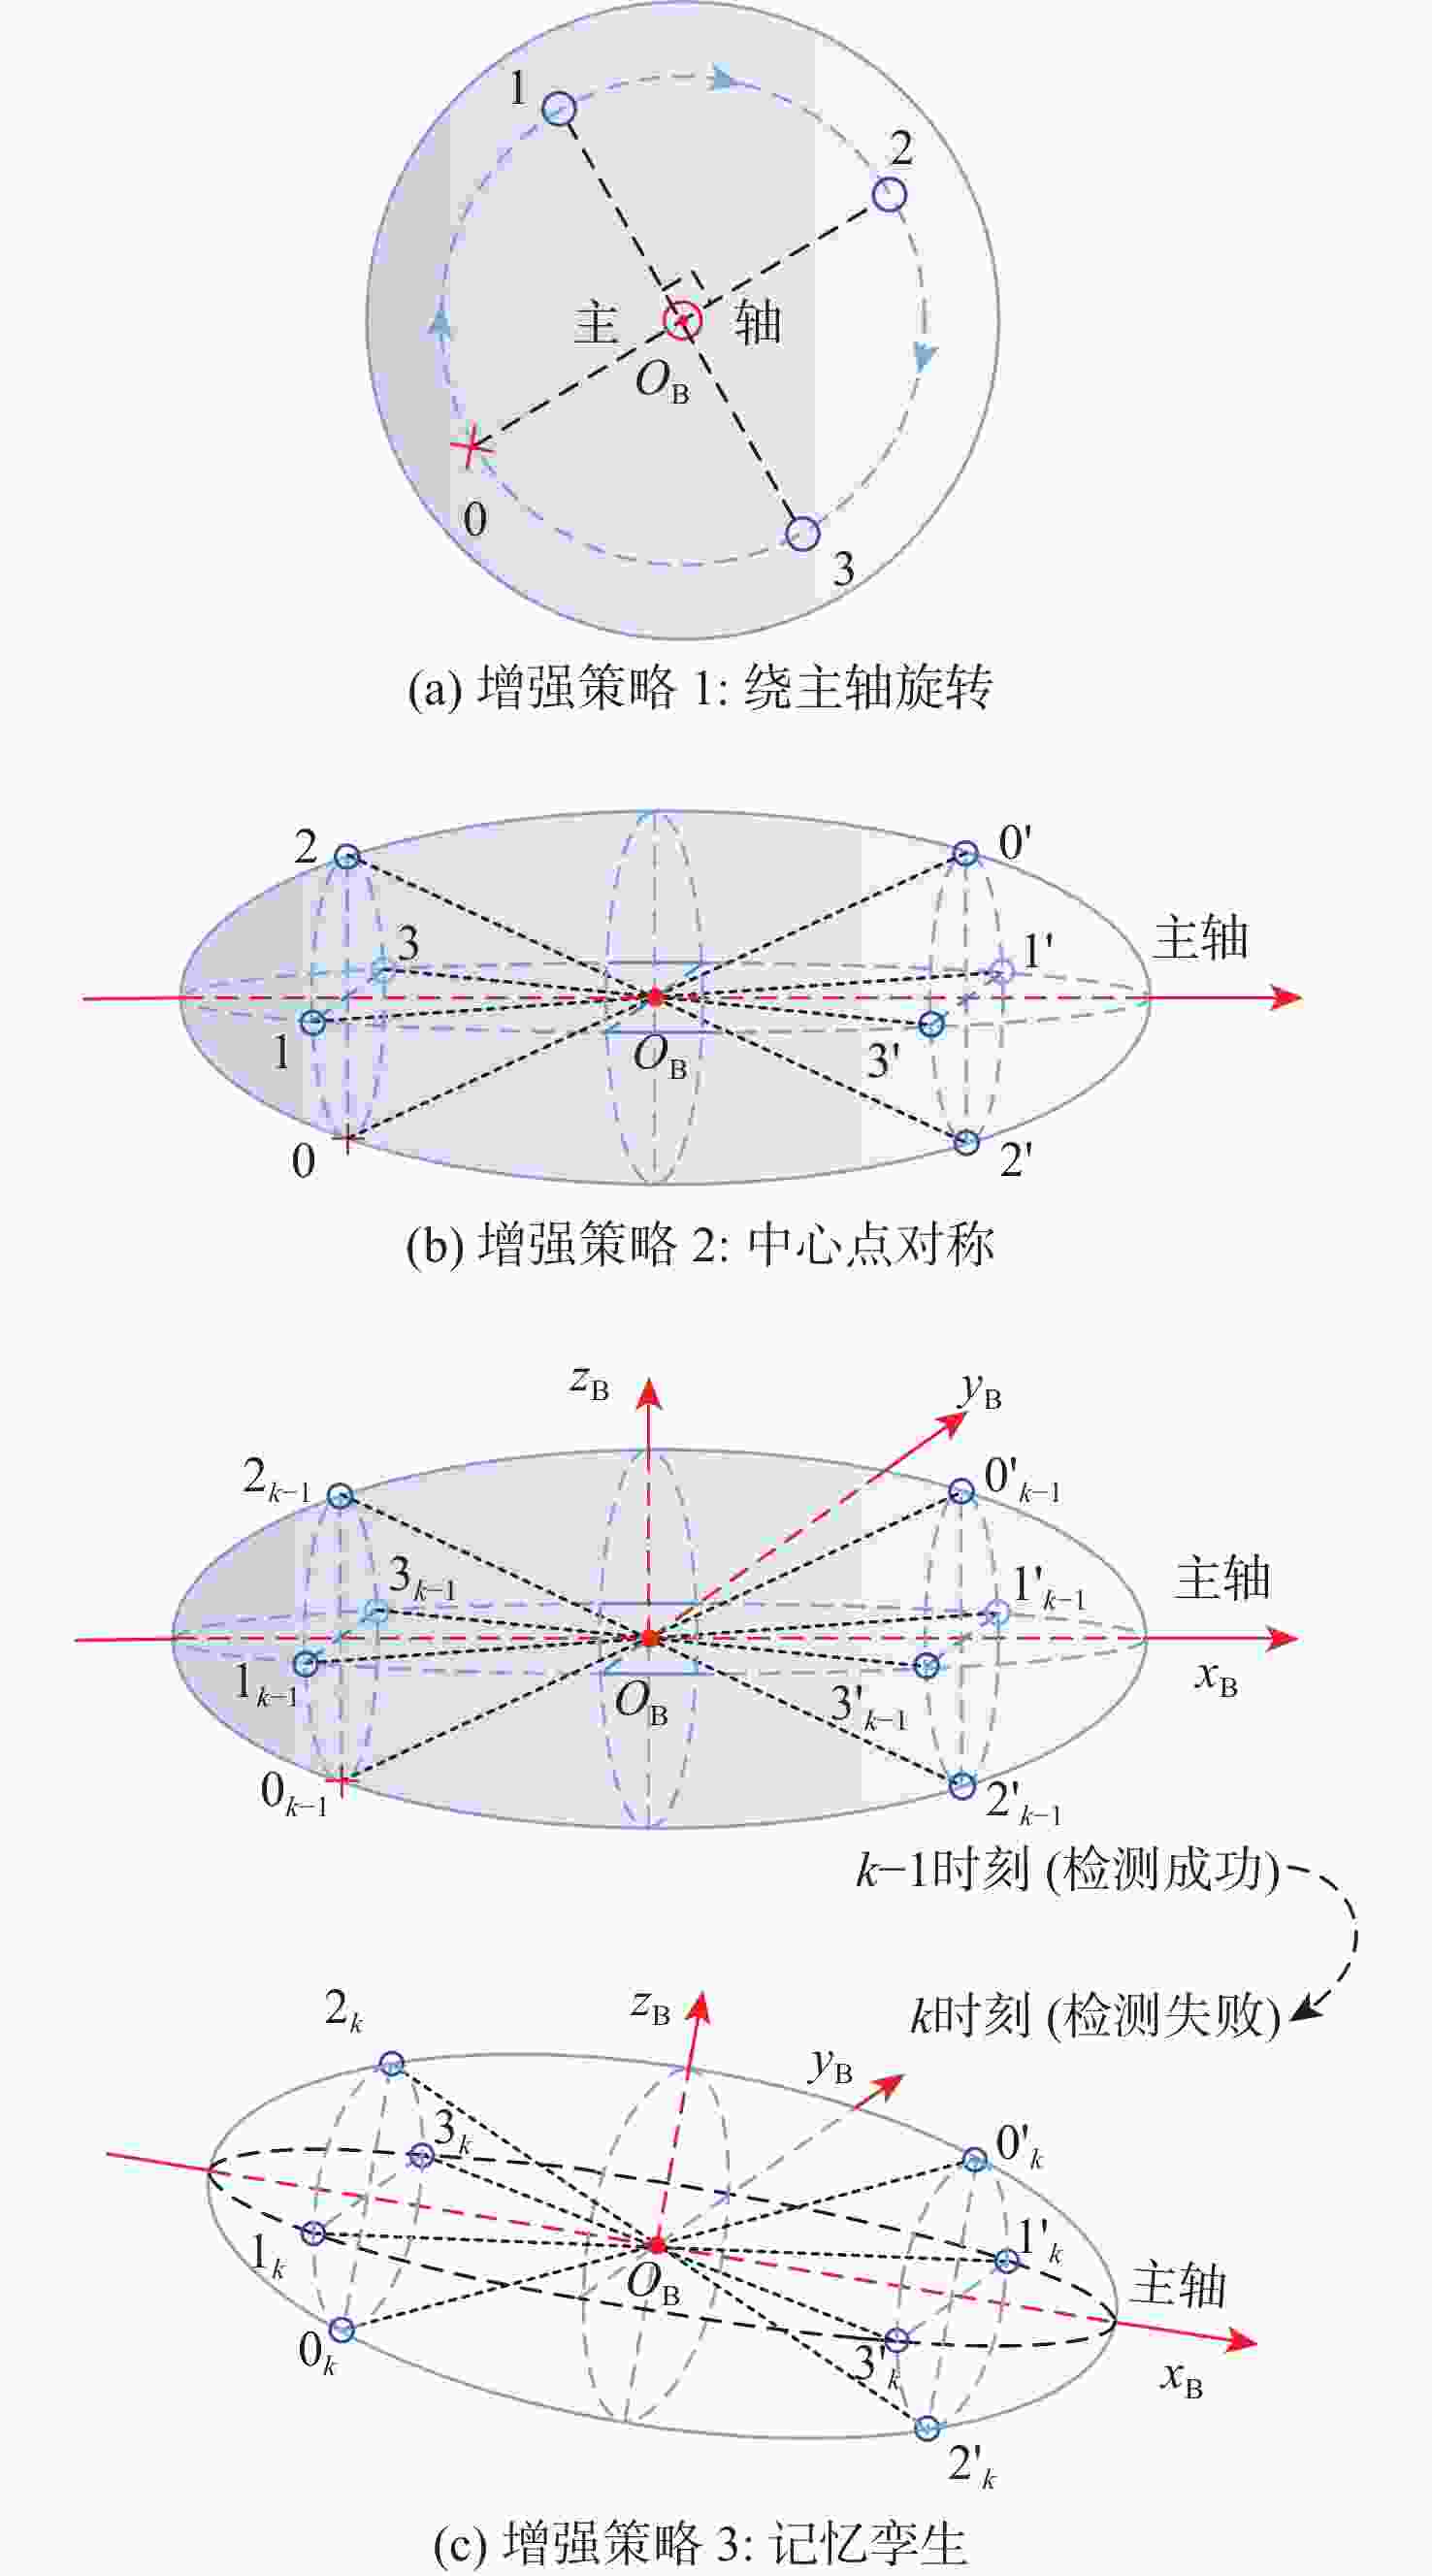
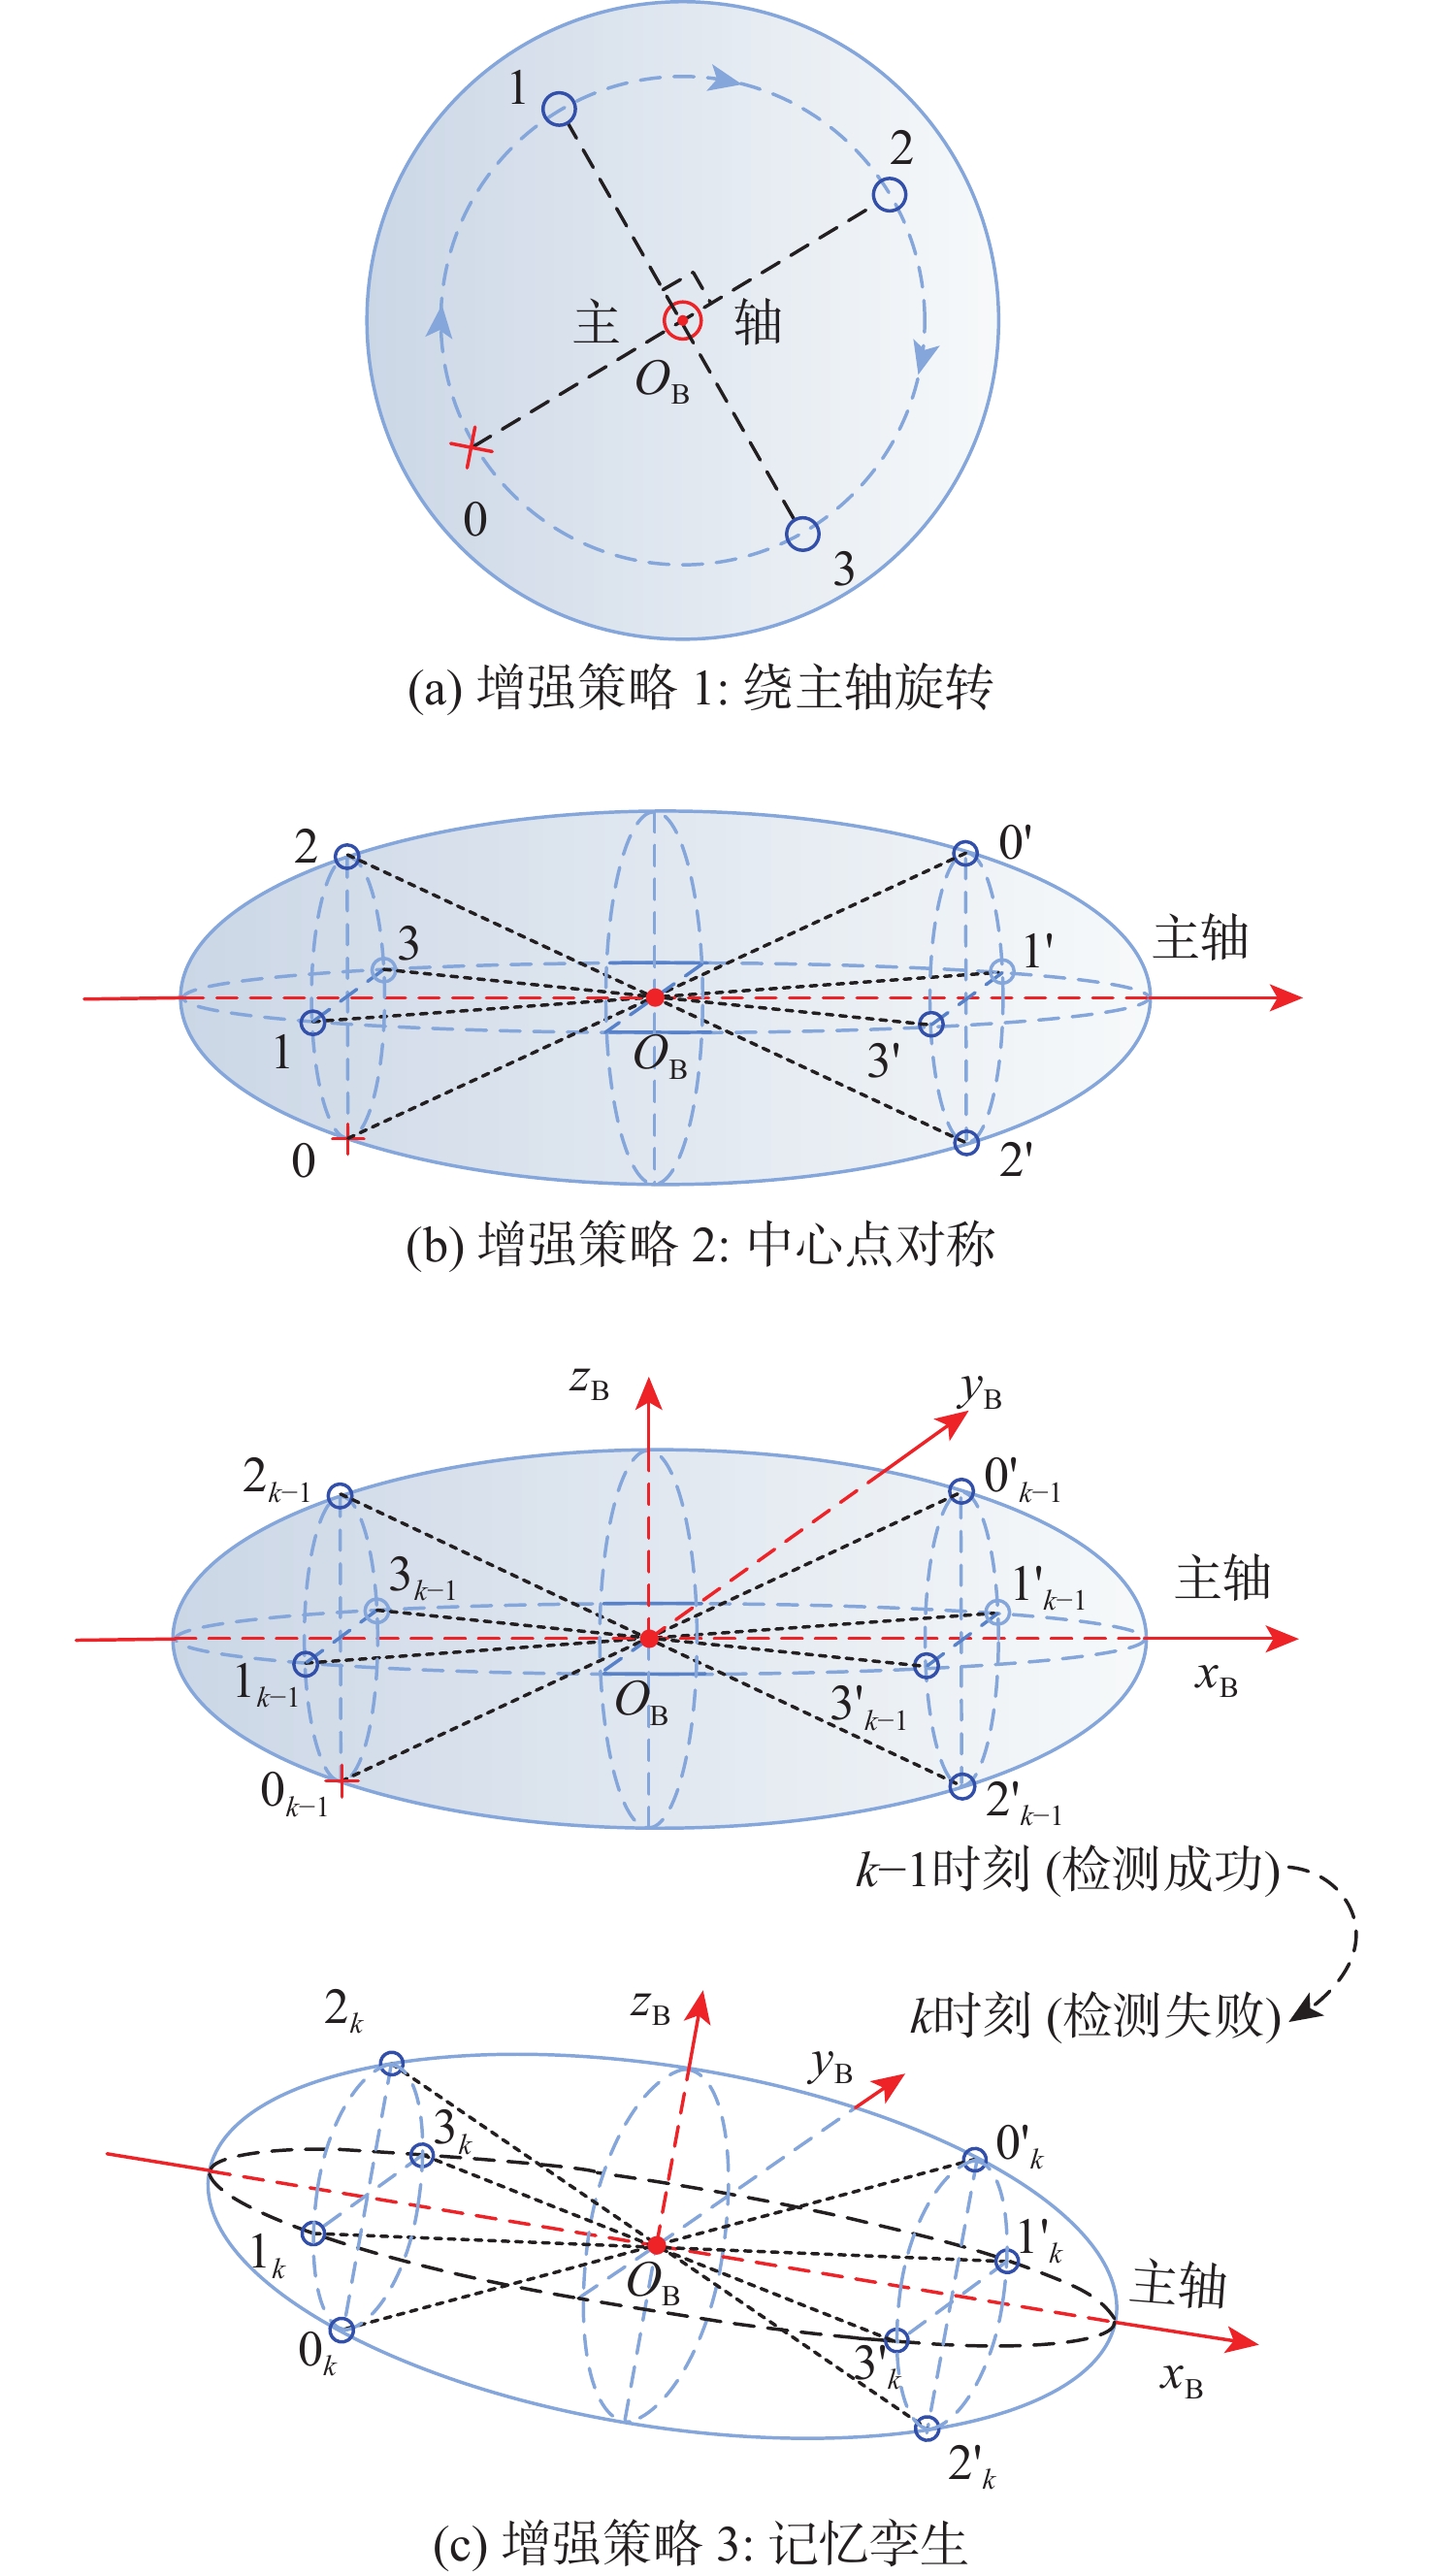
图 2 3种雷达量测数据增强策略示意图
Figure 2. Schematic diagrams of three augmentation strategies for radar measurements
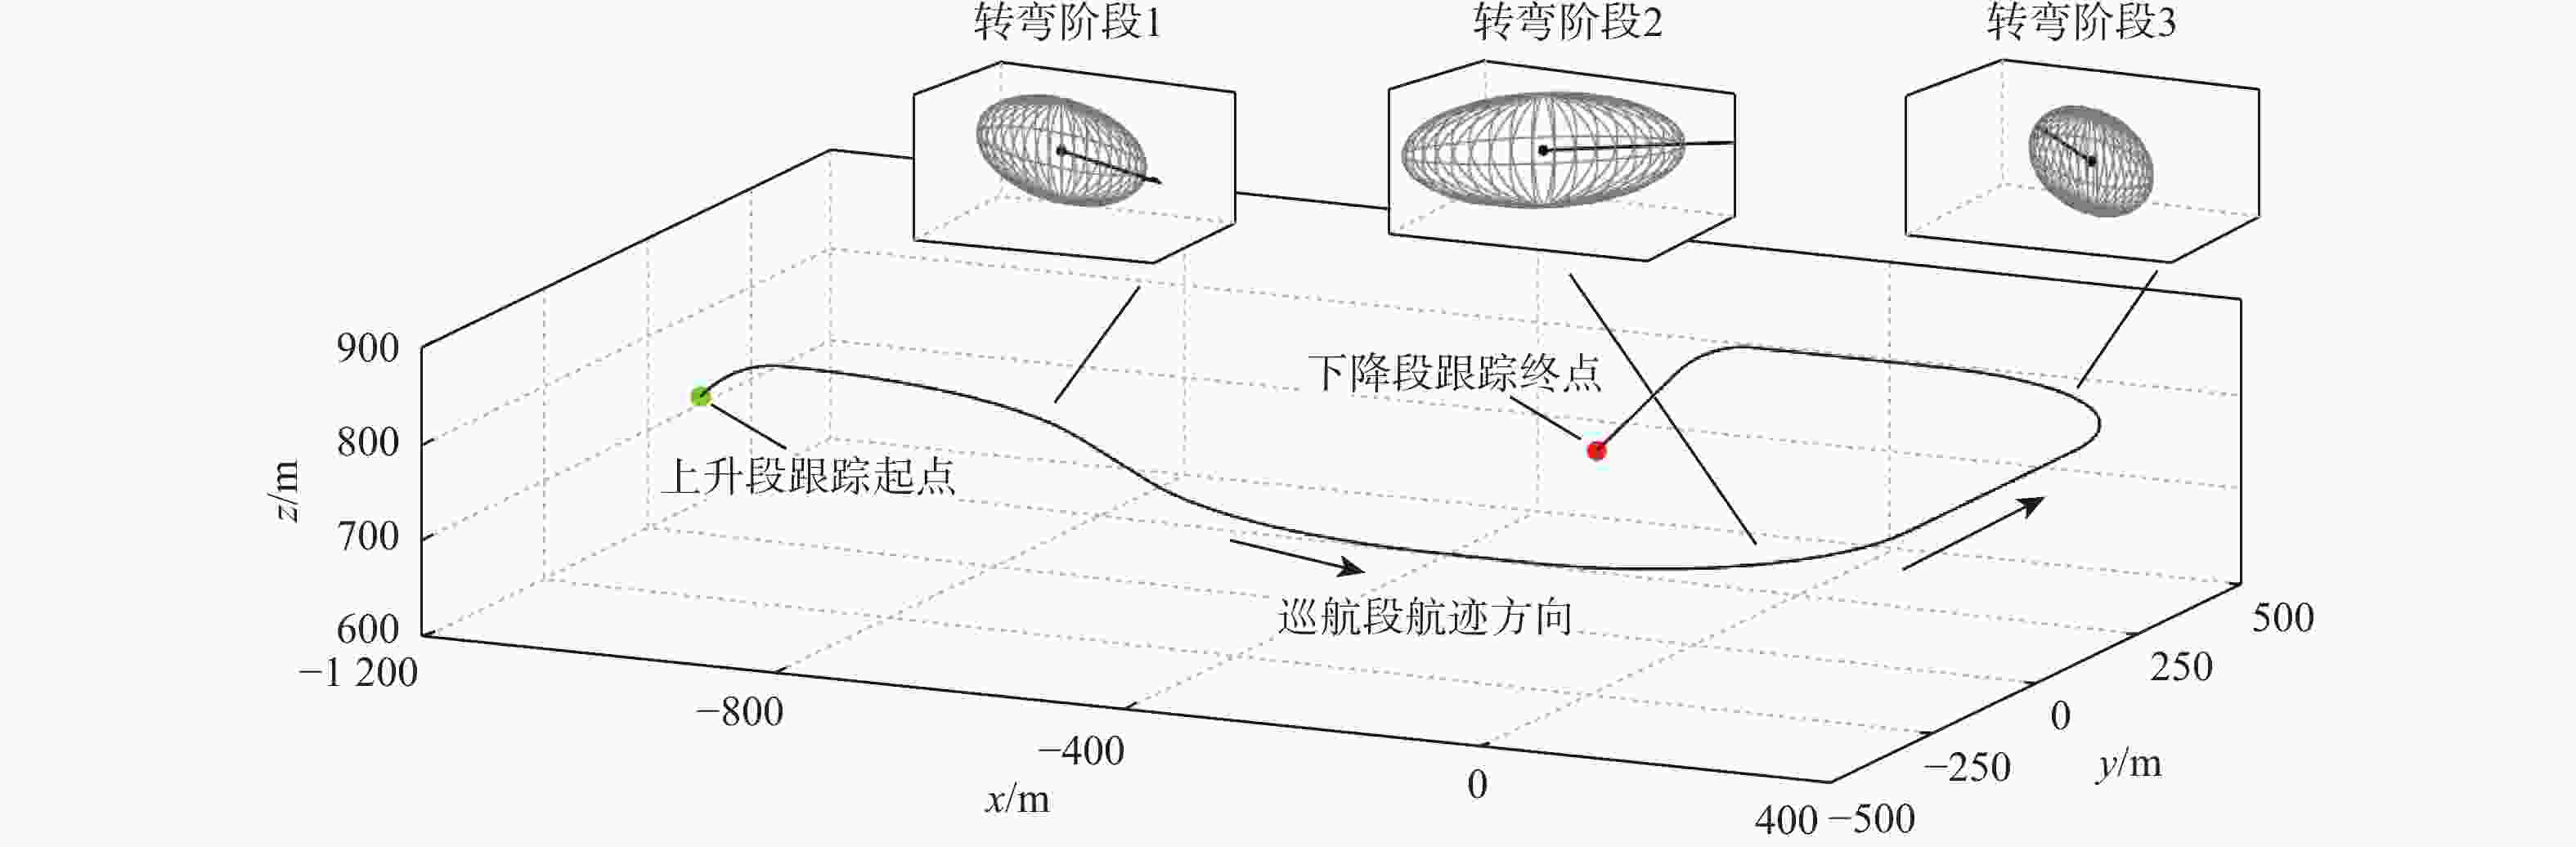
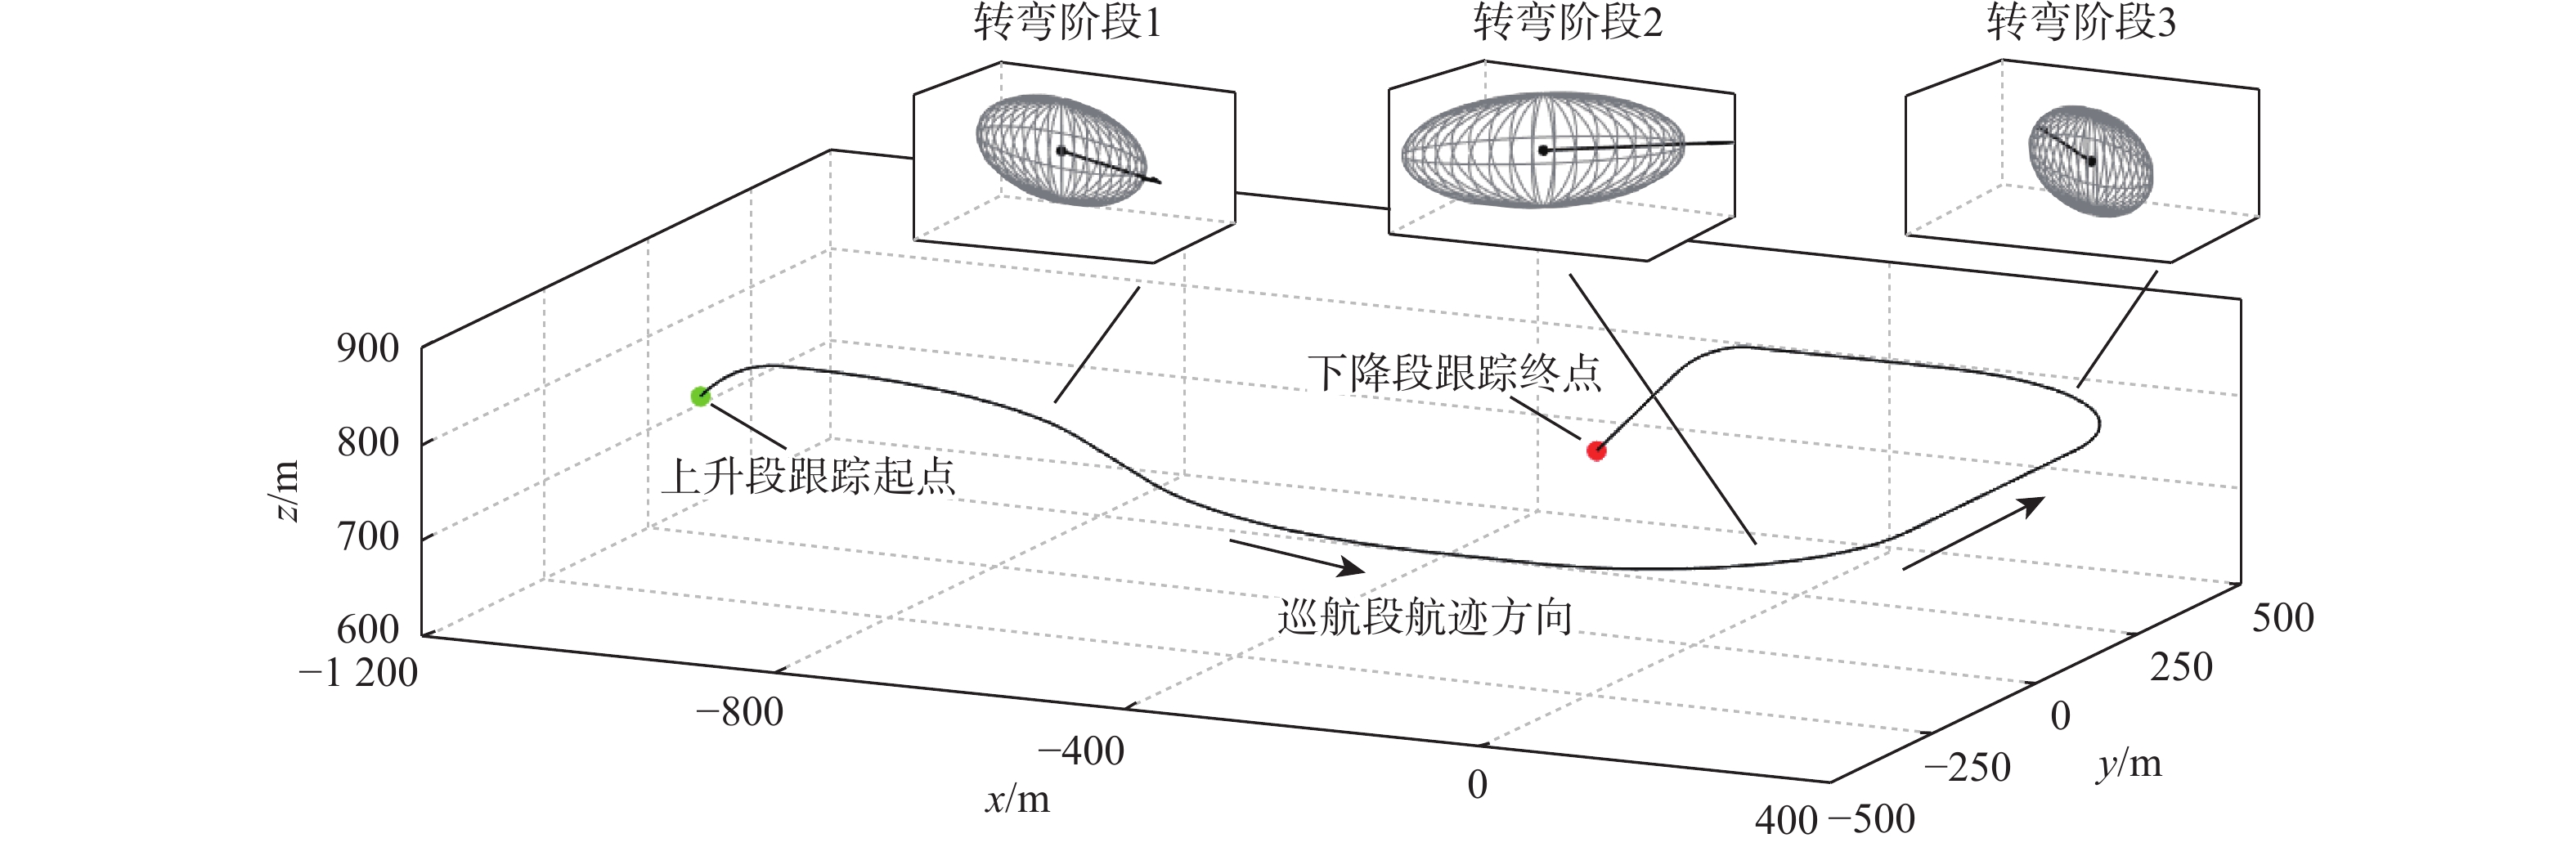
图 3 受试飞行器典型低空测试航迹示意图
Figure 3. Schematic diagram of typical test trajectory of low-altitude aircraft
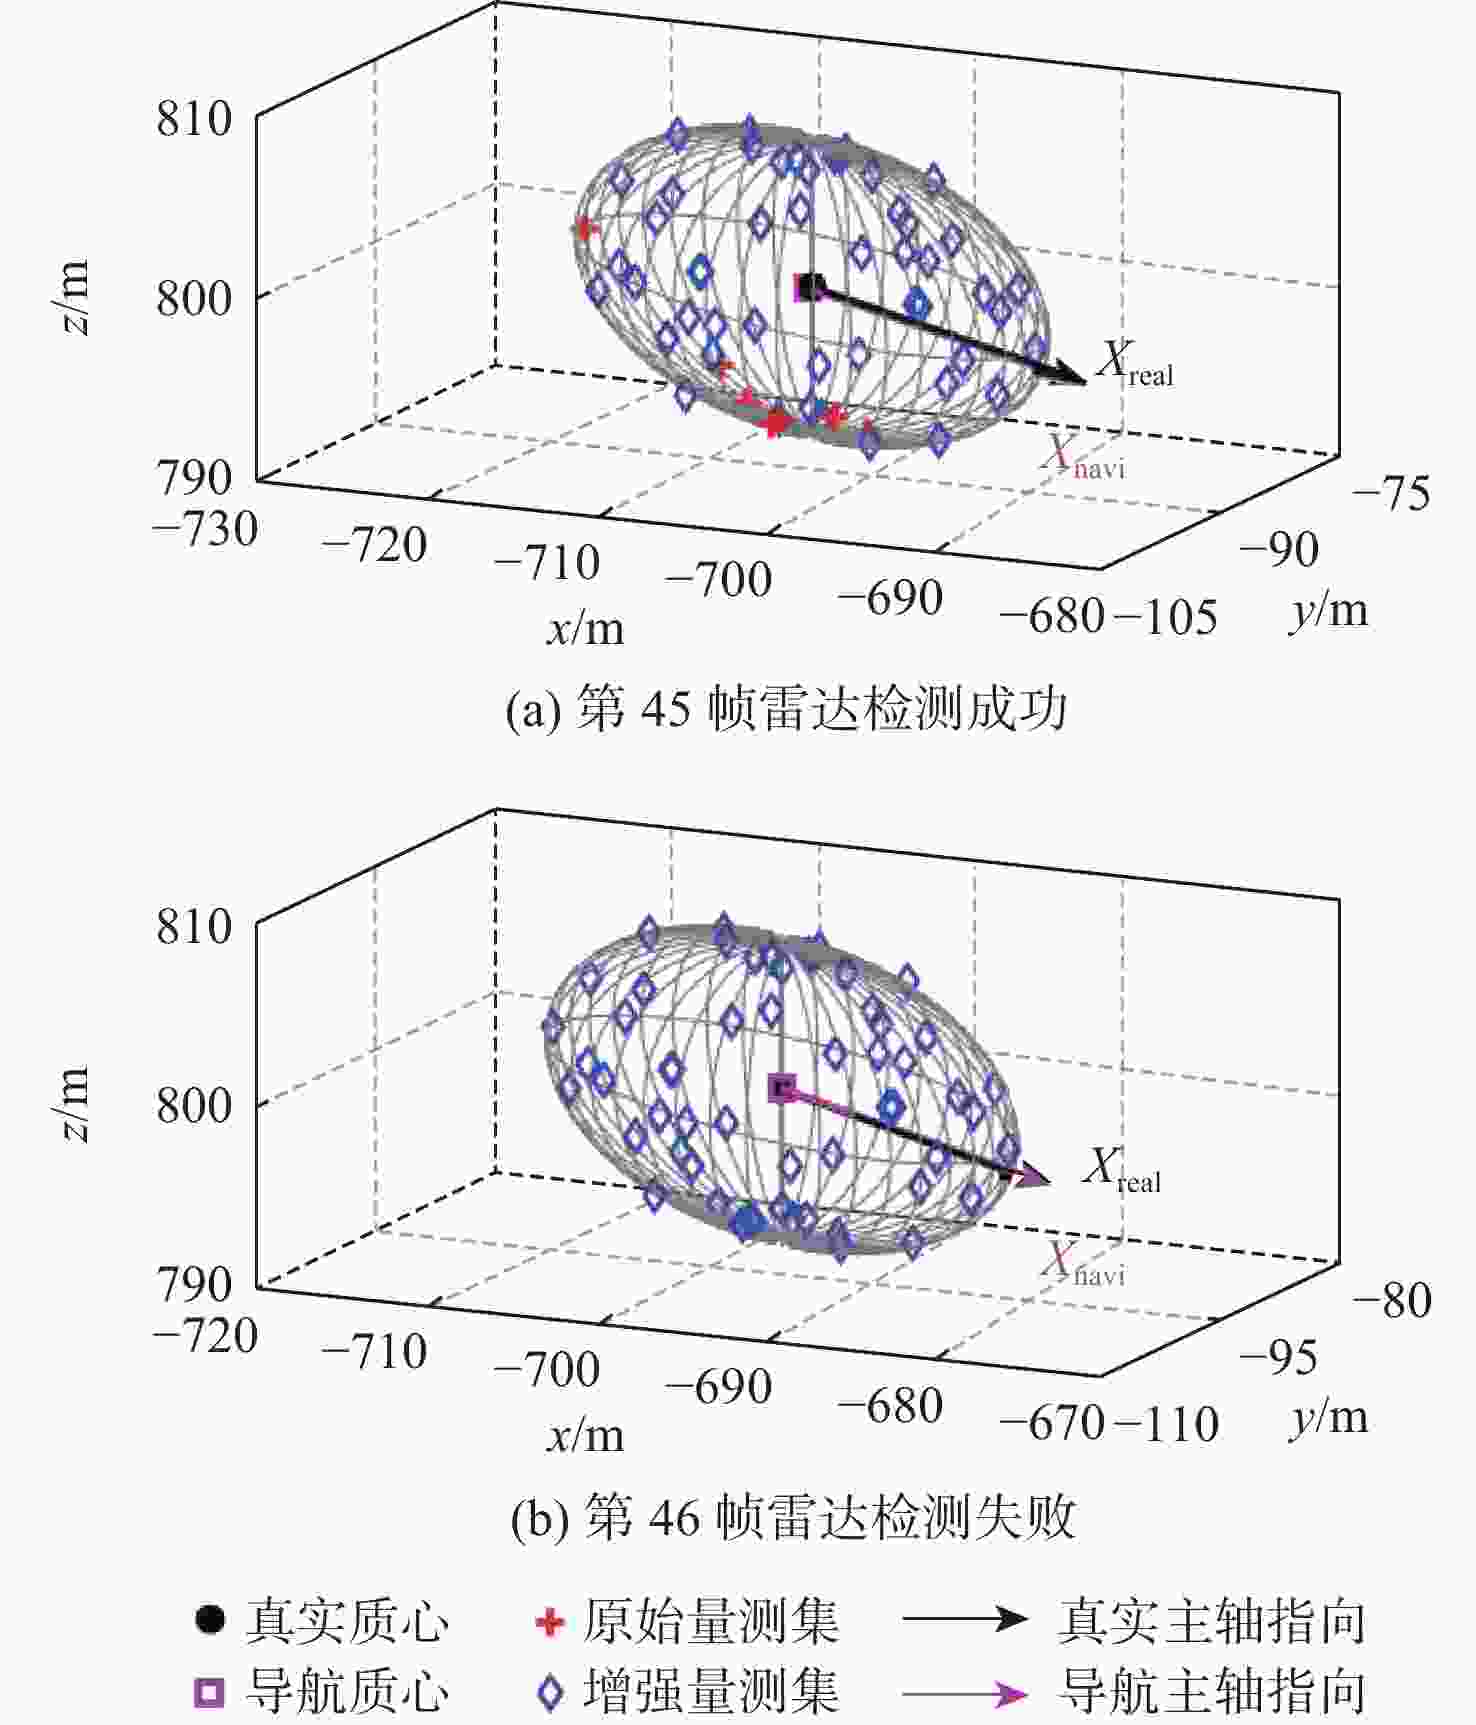
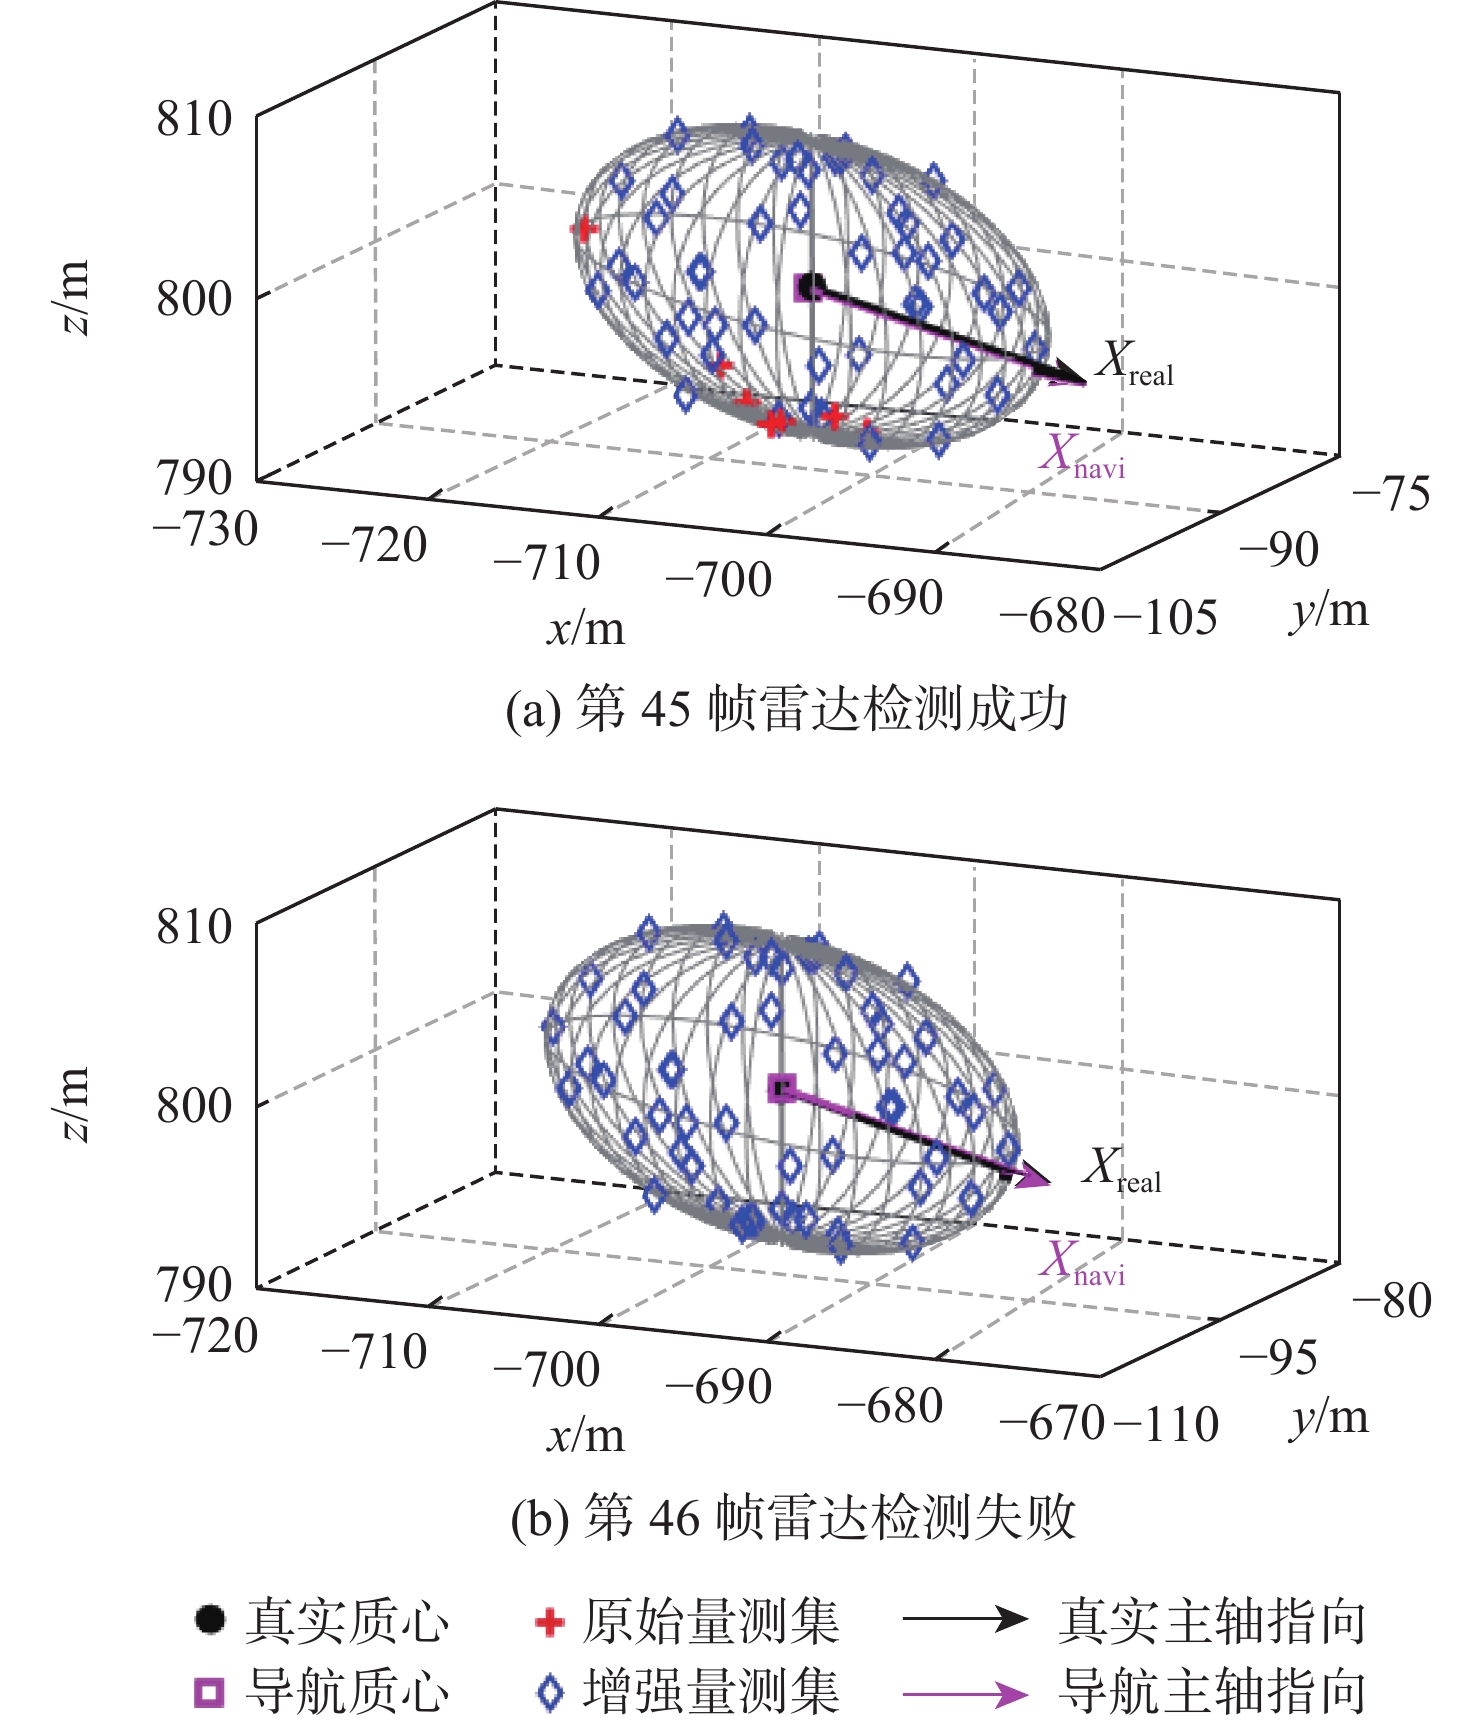
图 4 转弯阶段1雷达稀疏量测数据增强结果
Figure 4. Augmentation results for sparse radar measurements in turning phase 1
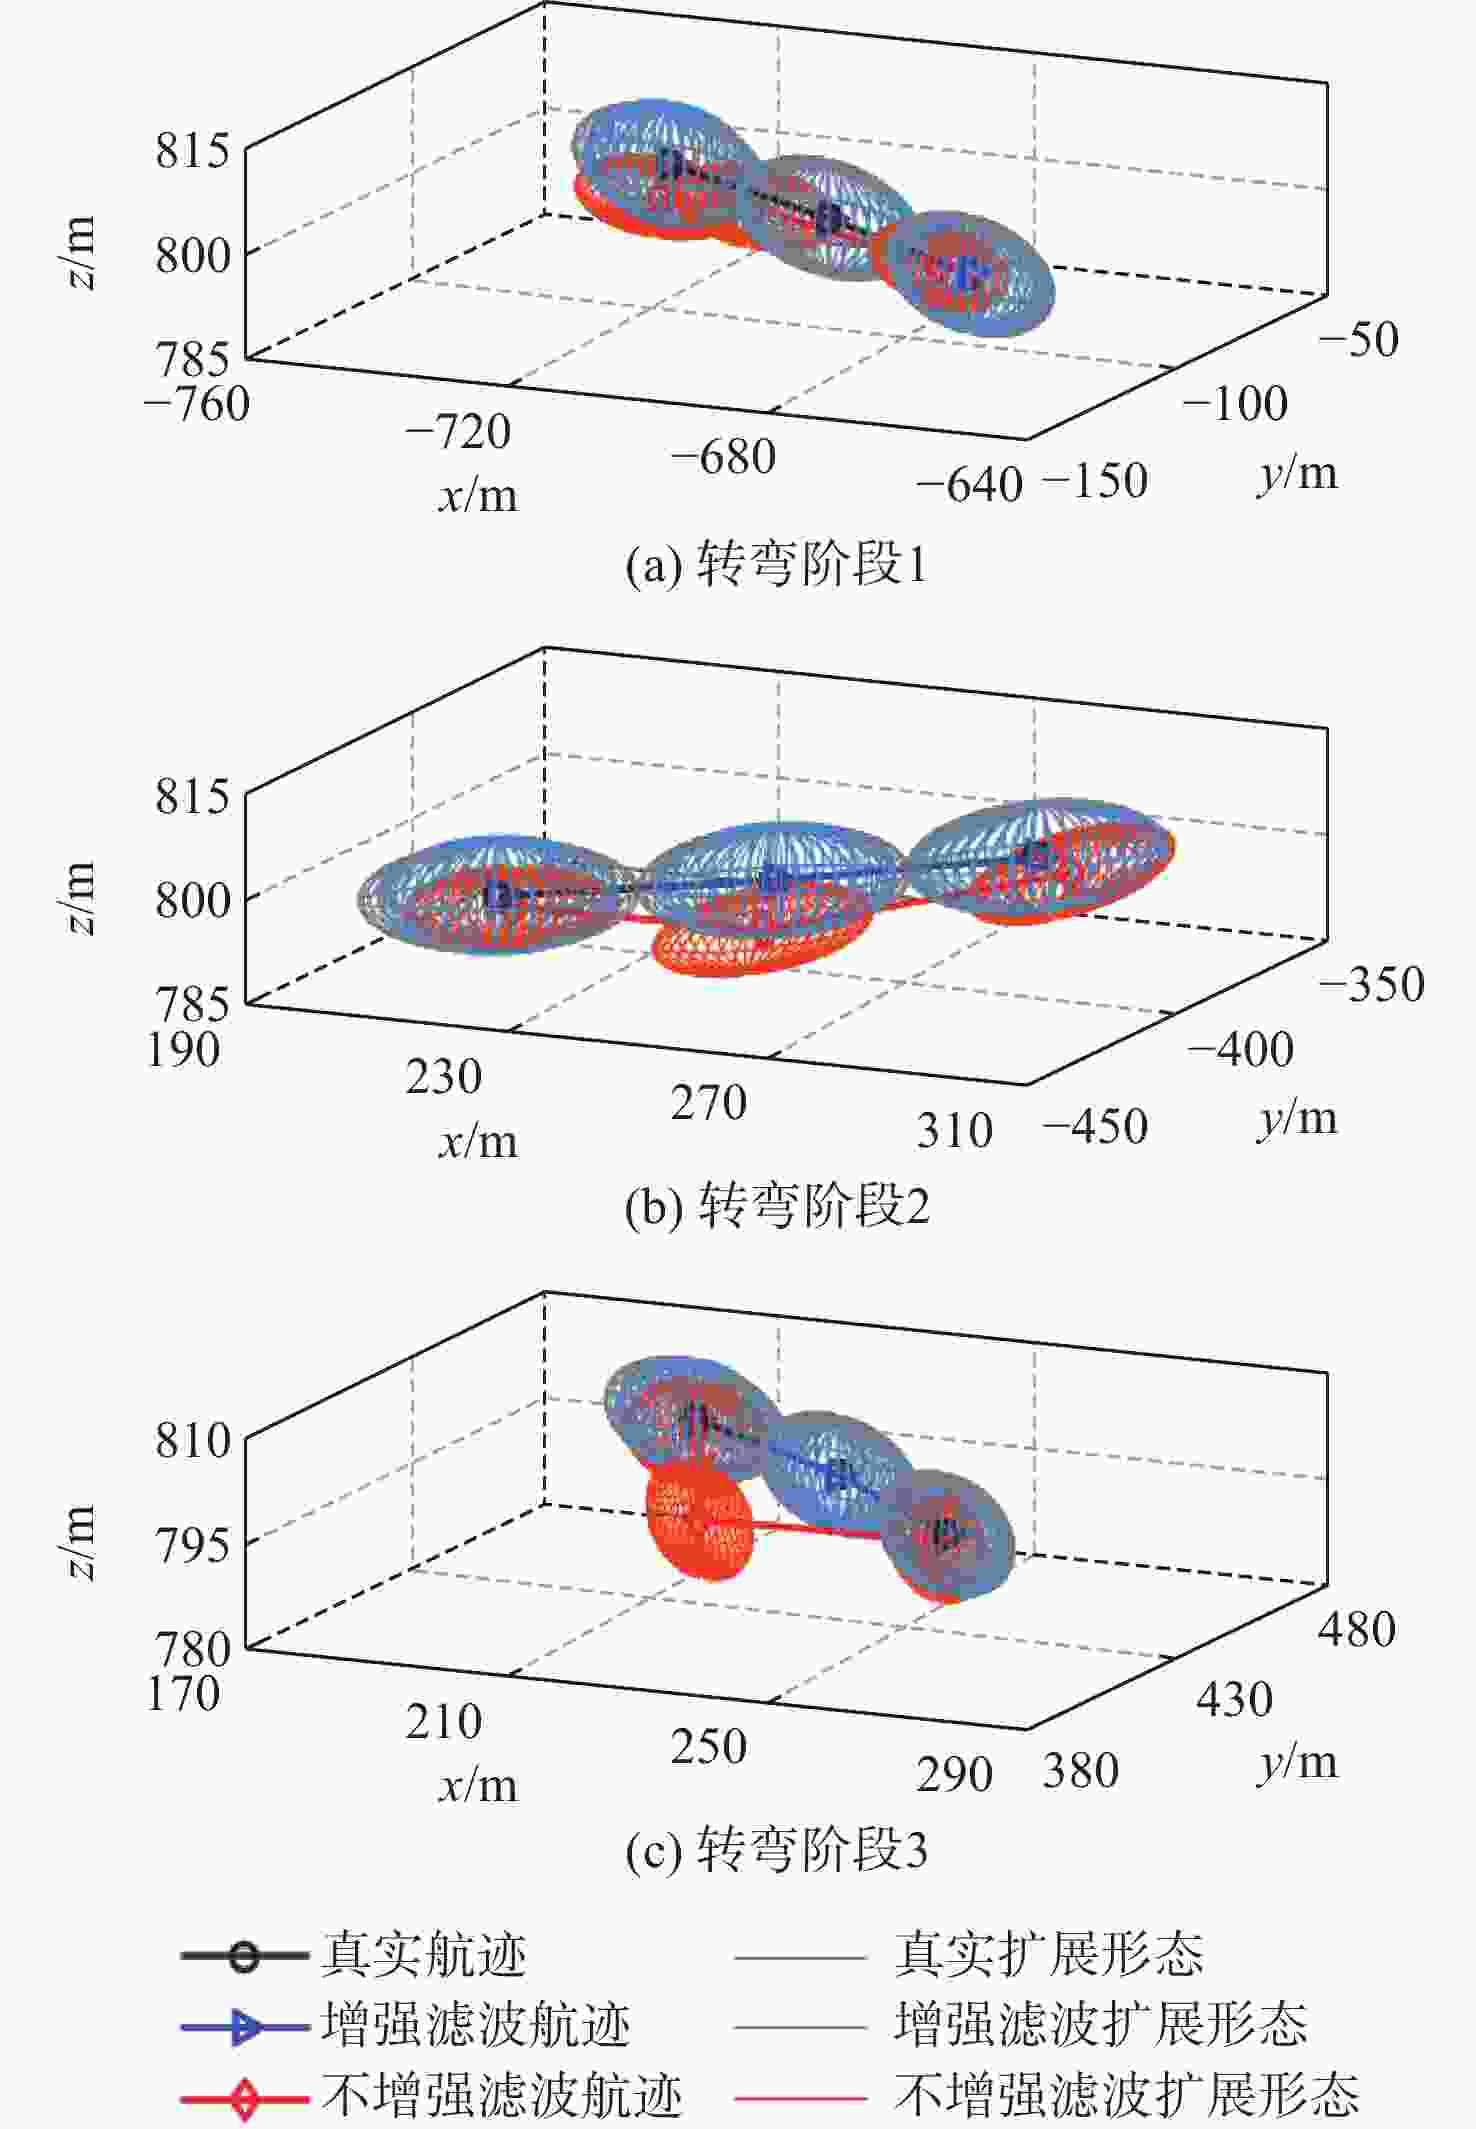
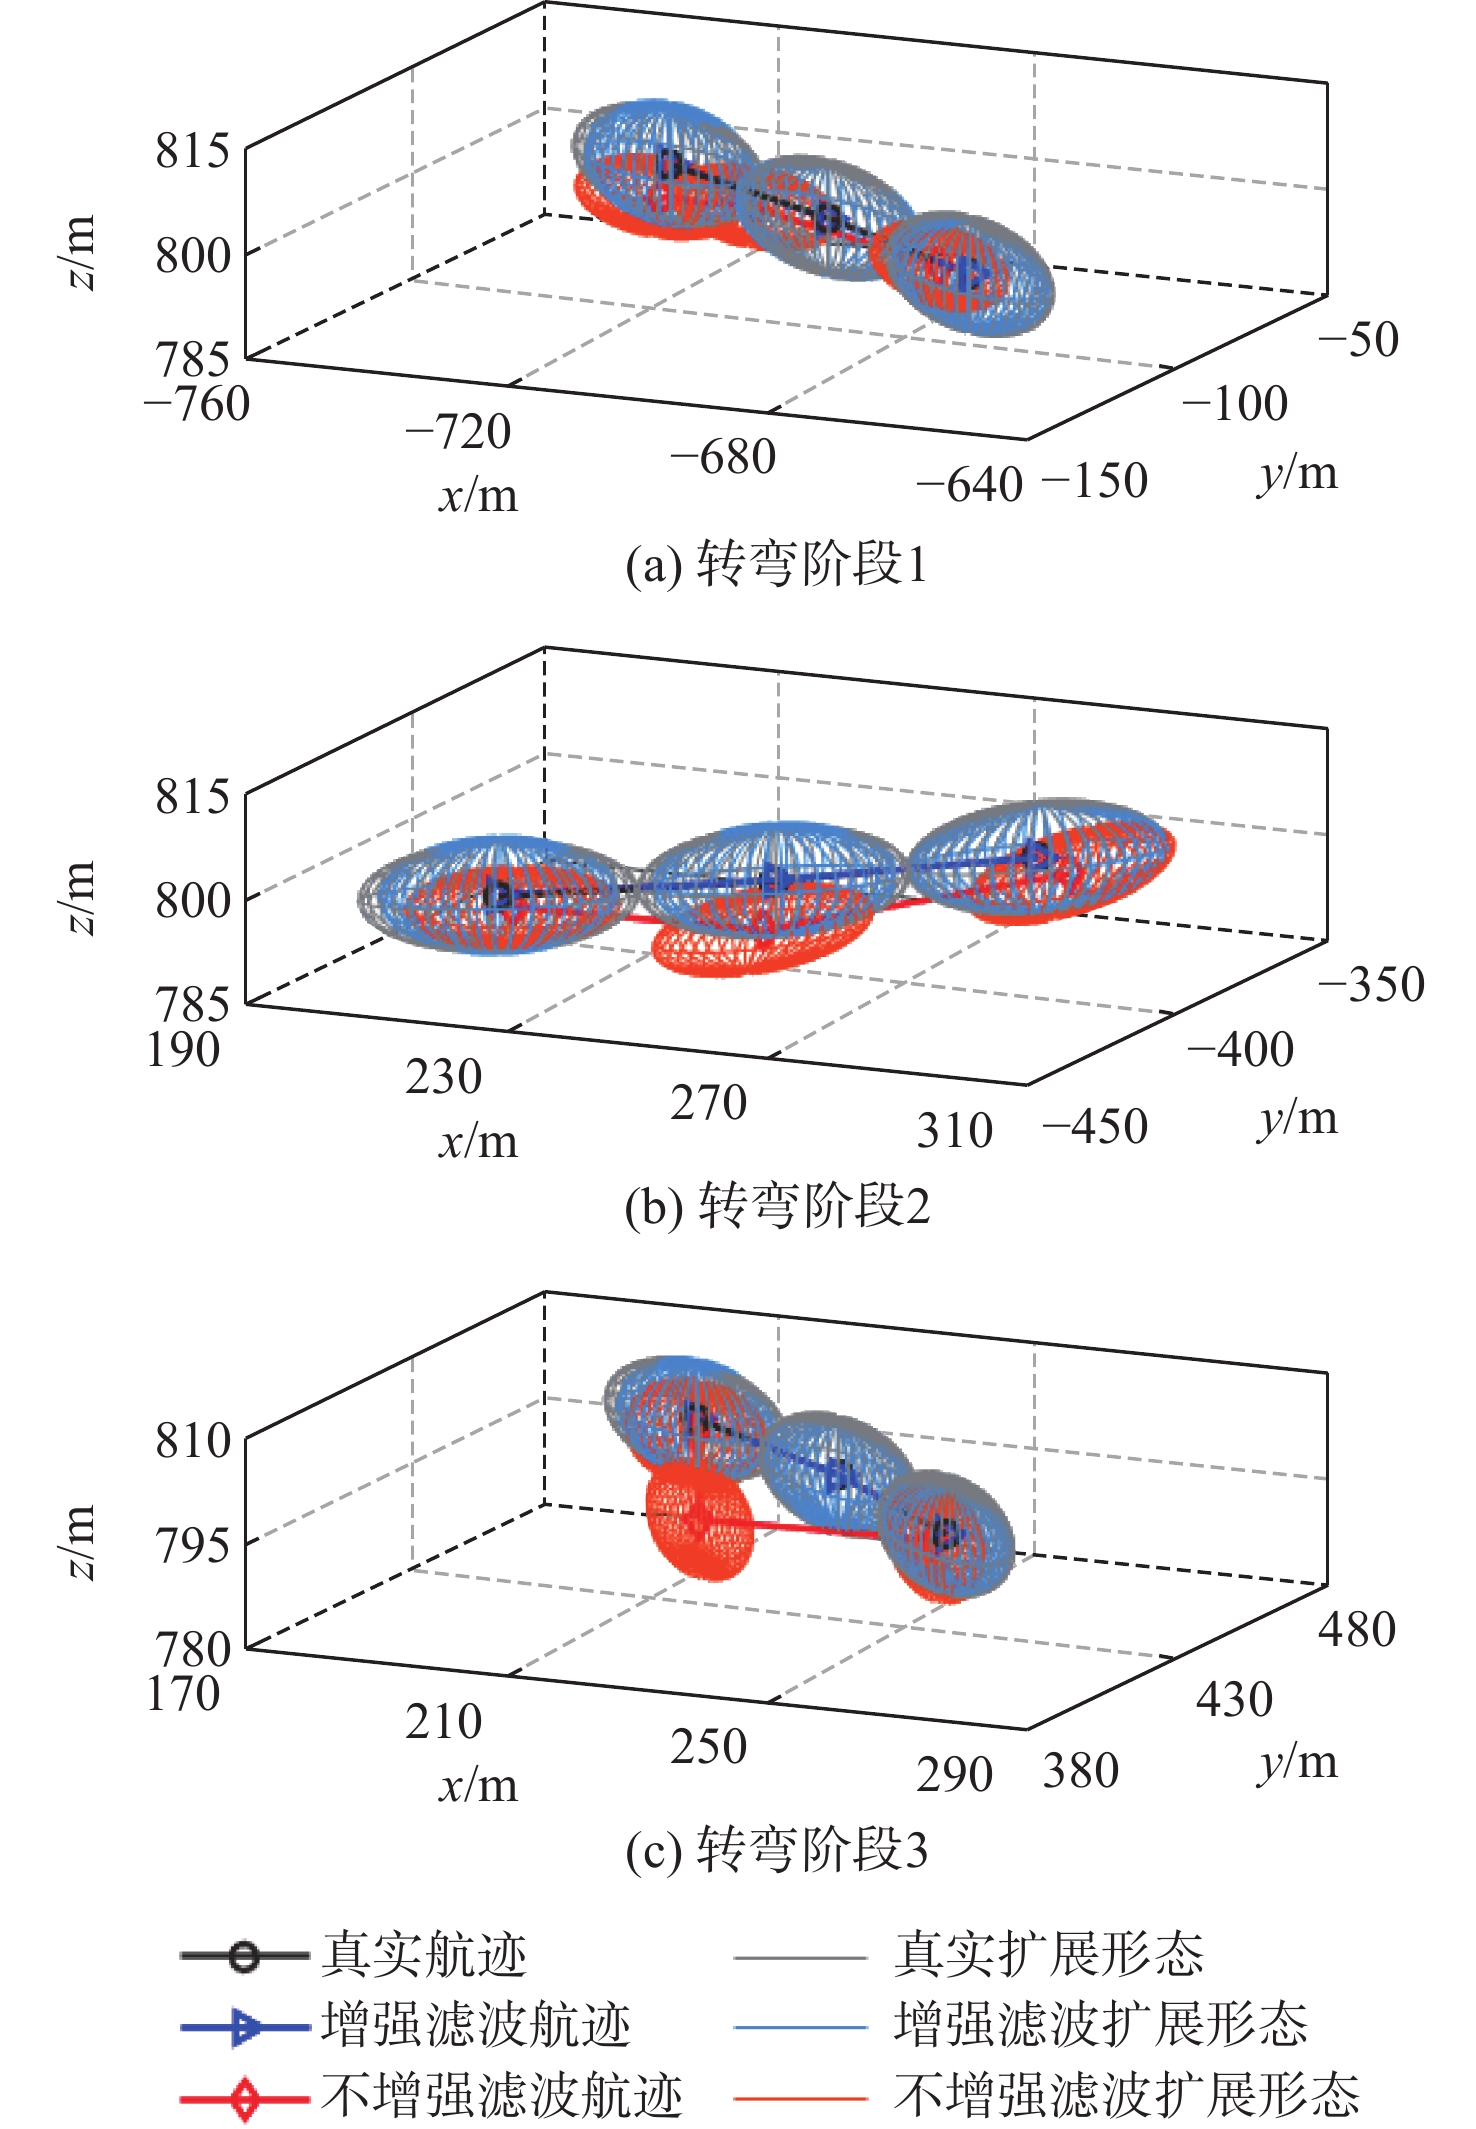
图 5 飞行器位置、扩展形态估计局部结果
Figure 5. Partial estimation results for position, and extension shape of aircraft
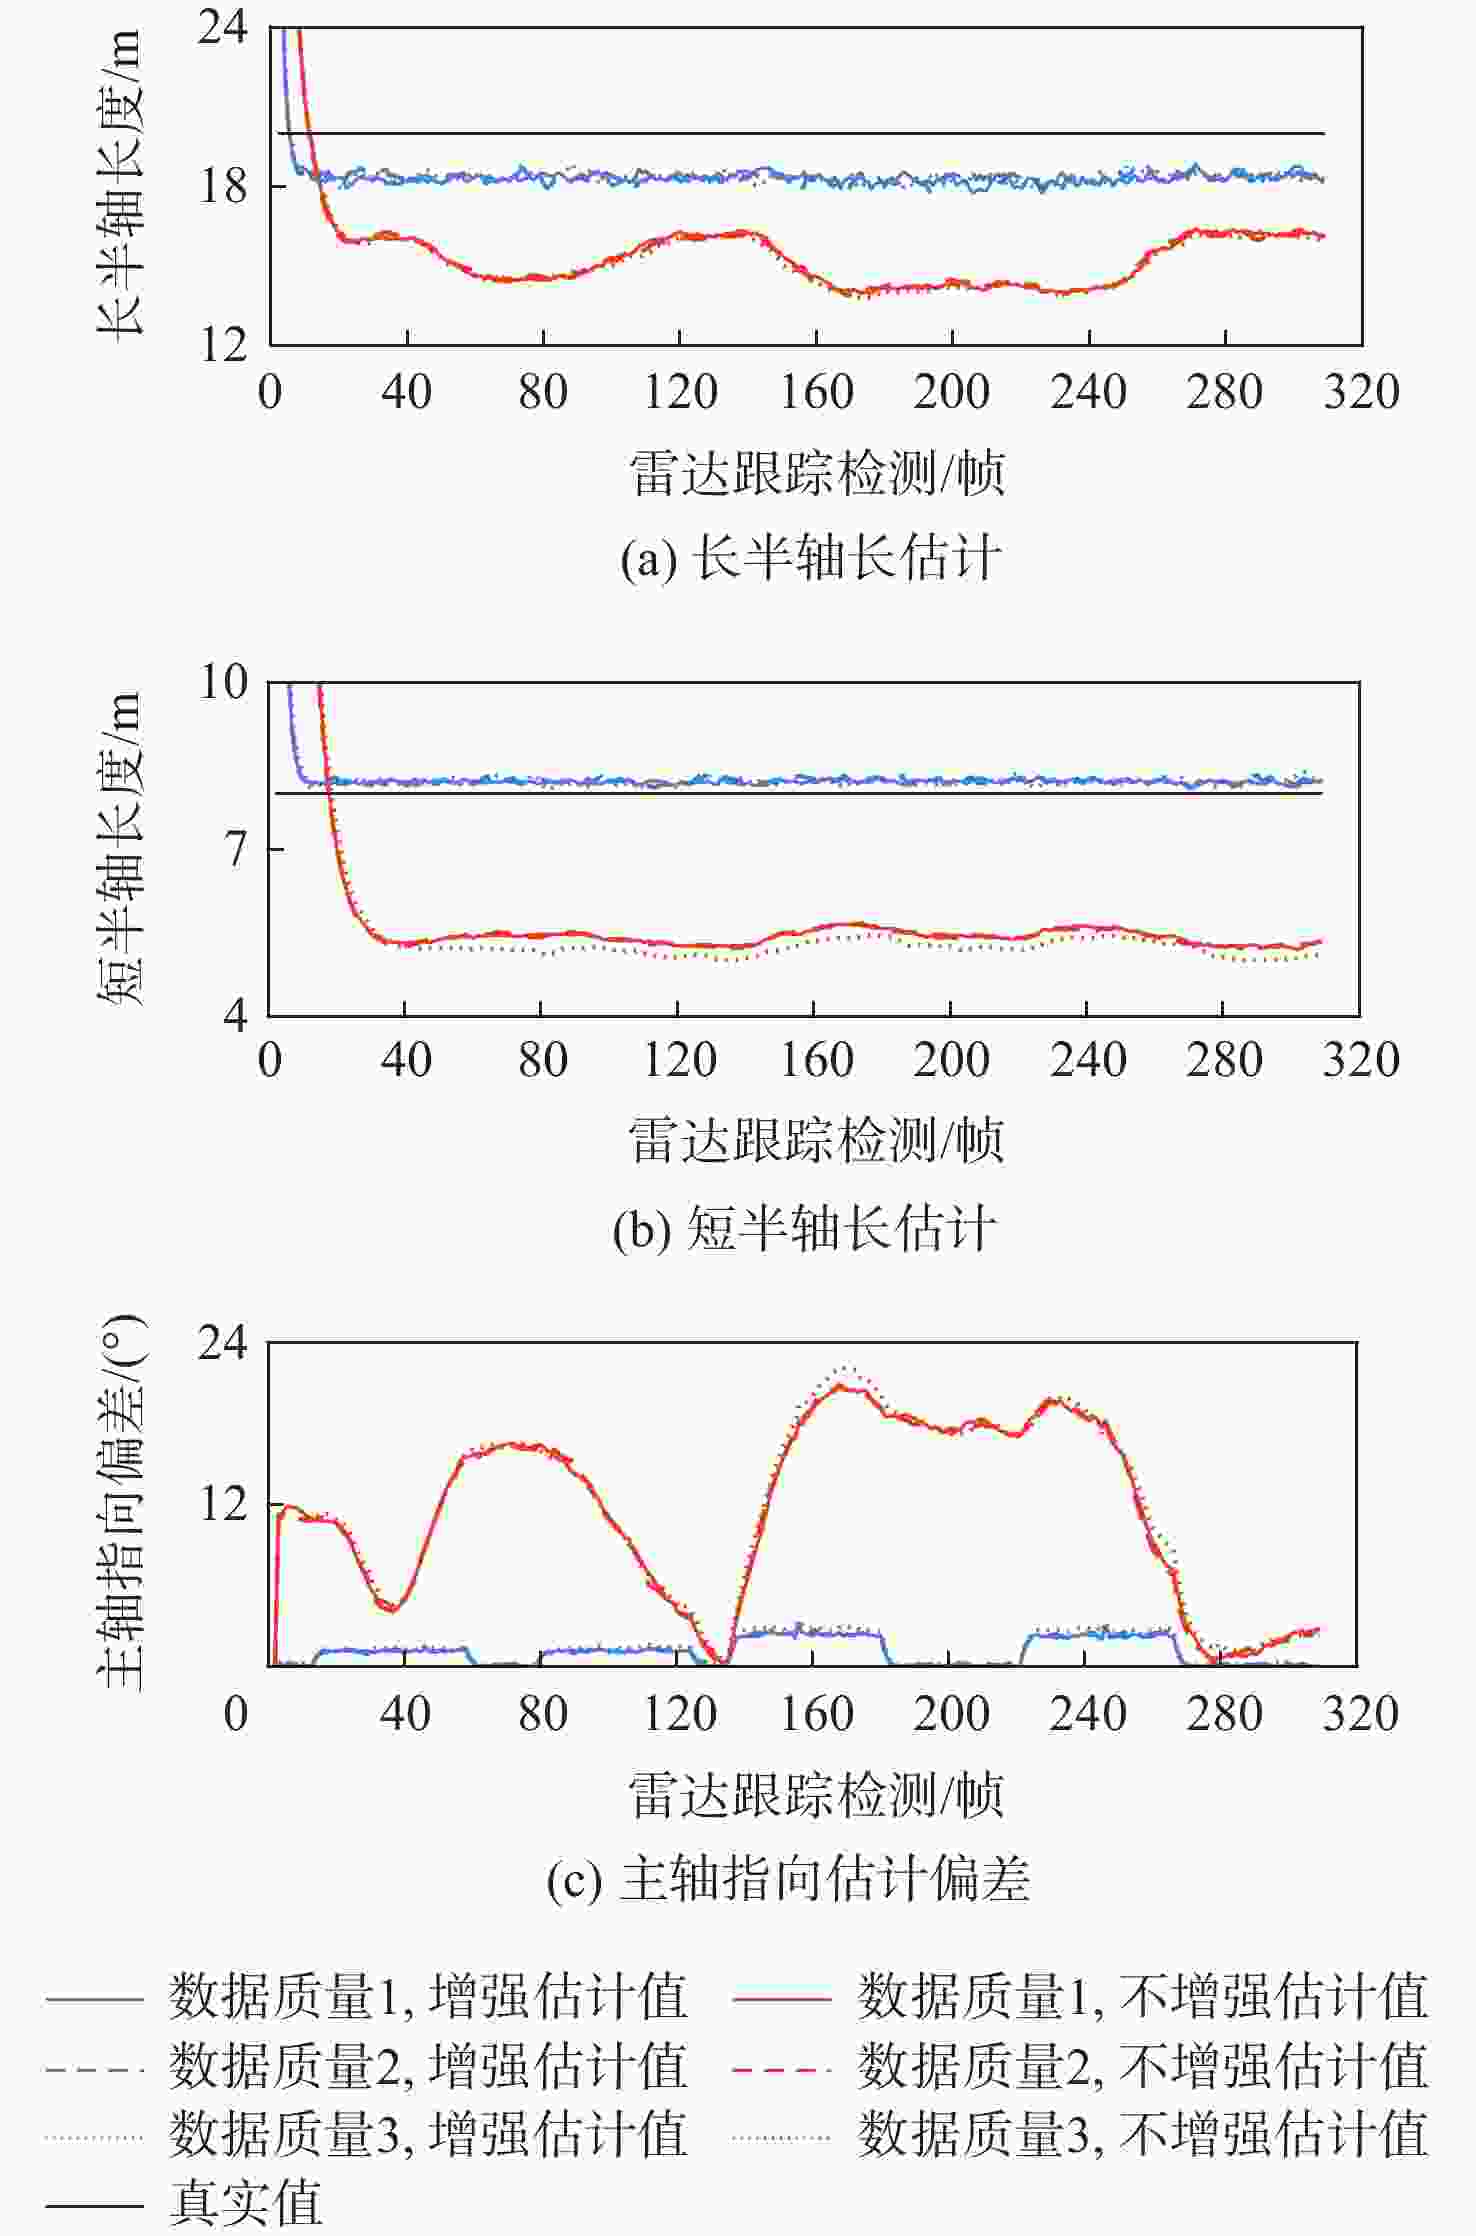
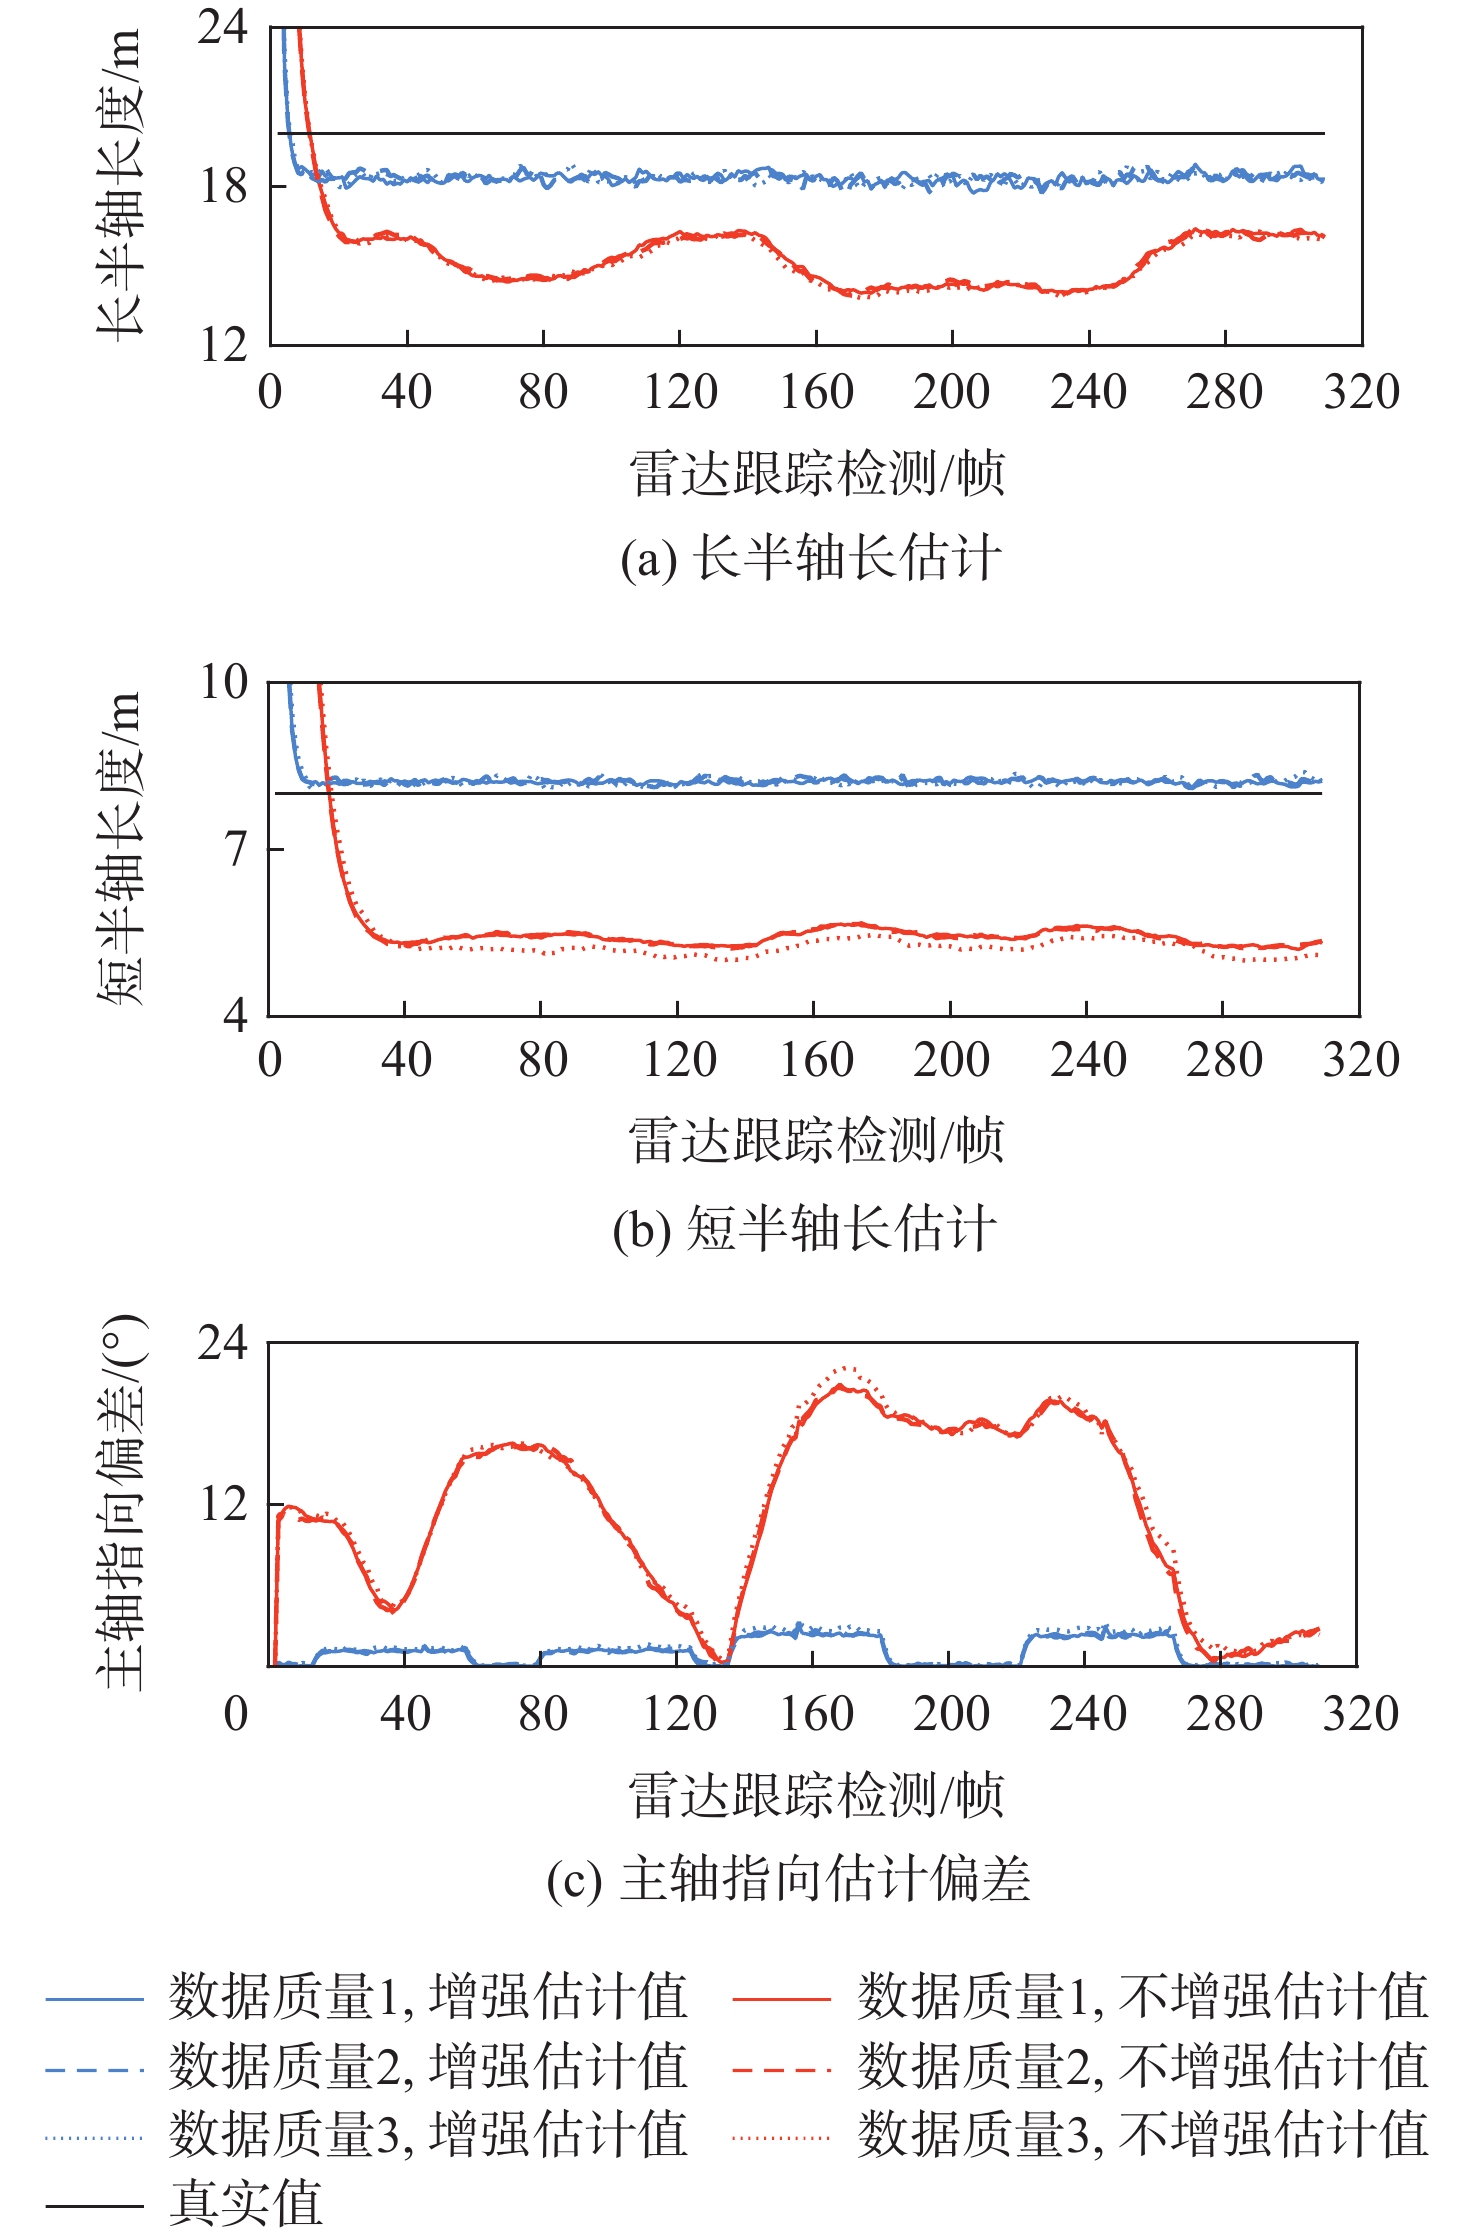
图 8 飞行器扩展形态参数估计平均结果
Figure 8. Average estimation results for extension shape parameters of aircraft
矩阵运算 示例矩阵对象 浮点运算数 加减法 $ {\boldsymbol{M}}_{1}\in {\bf{R}}^{n\times m} $,$ {\boldsymbol{M}}_{2}\in {\bf{R}}^{n\times m} $ $ {O}(nm) $ 乘法 $ {\boldsymbol{M}}_{1}\in {\bf{R}}^{n\times m} $,$ {\boldsymbol{M}}_{2}\in {\bf{R}}^{m\times l} $ $ {O}(2nml-nl) $ 求逆 $ {\boldsymbol{M}}_{1}\in {\bf{R}}^{n\times n} $ $ {O}({n}^{3}) $ Cholesky分解 $ {\boldsymbol{M}}_{1}\in {\bf{R}}^{n\times n} $ $ {O}({n}^{3}/3) $  下载: 导出CSV
表 2 3种量测数据增强策略的复杂度
Table 2. Flops of three kinds of measurements data augmentation strategy
增强策略 浮点运算量 1 $ {O}(51{n}_{k}) $ 2 $ {O}(12{n}_{k}) $ 3 $ {O}(51{n}_{k}) $
下载: 导出CSV
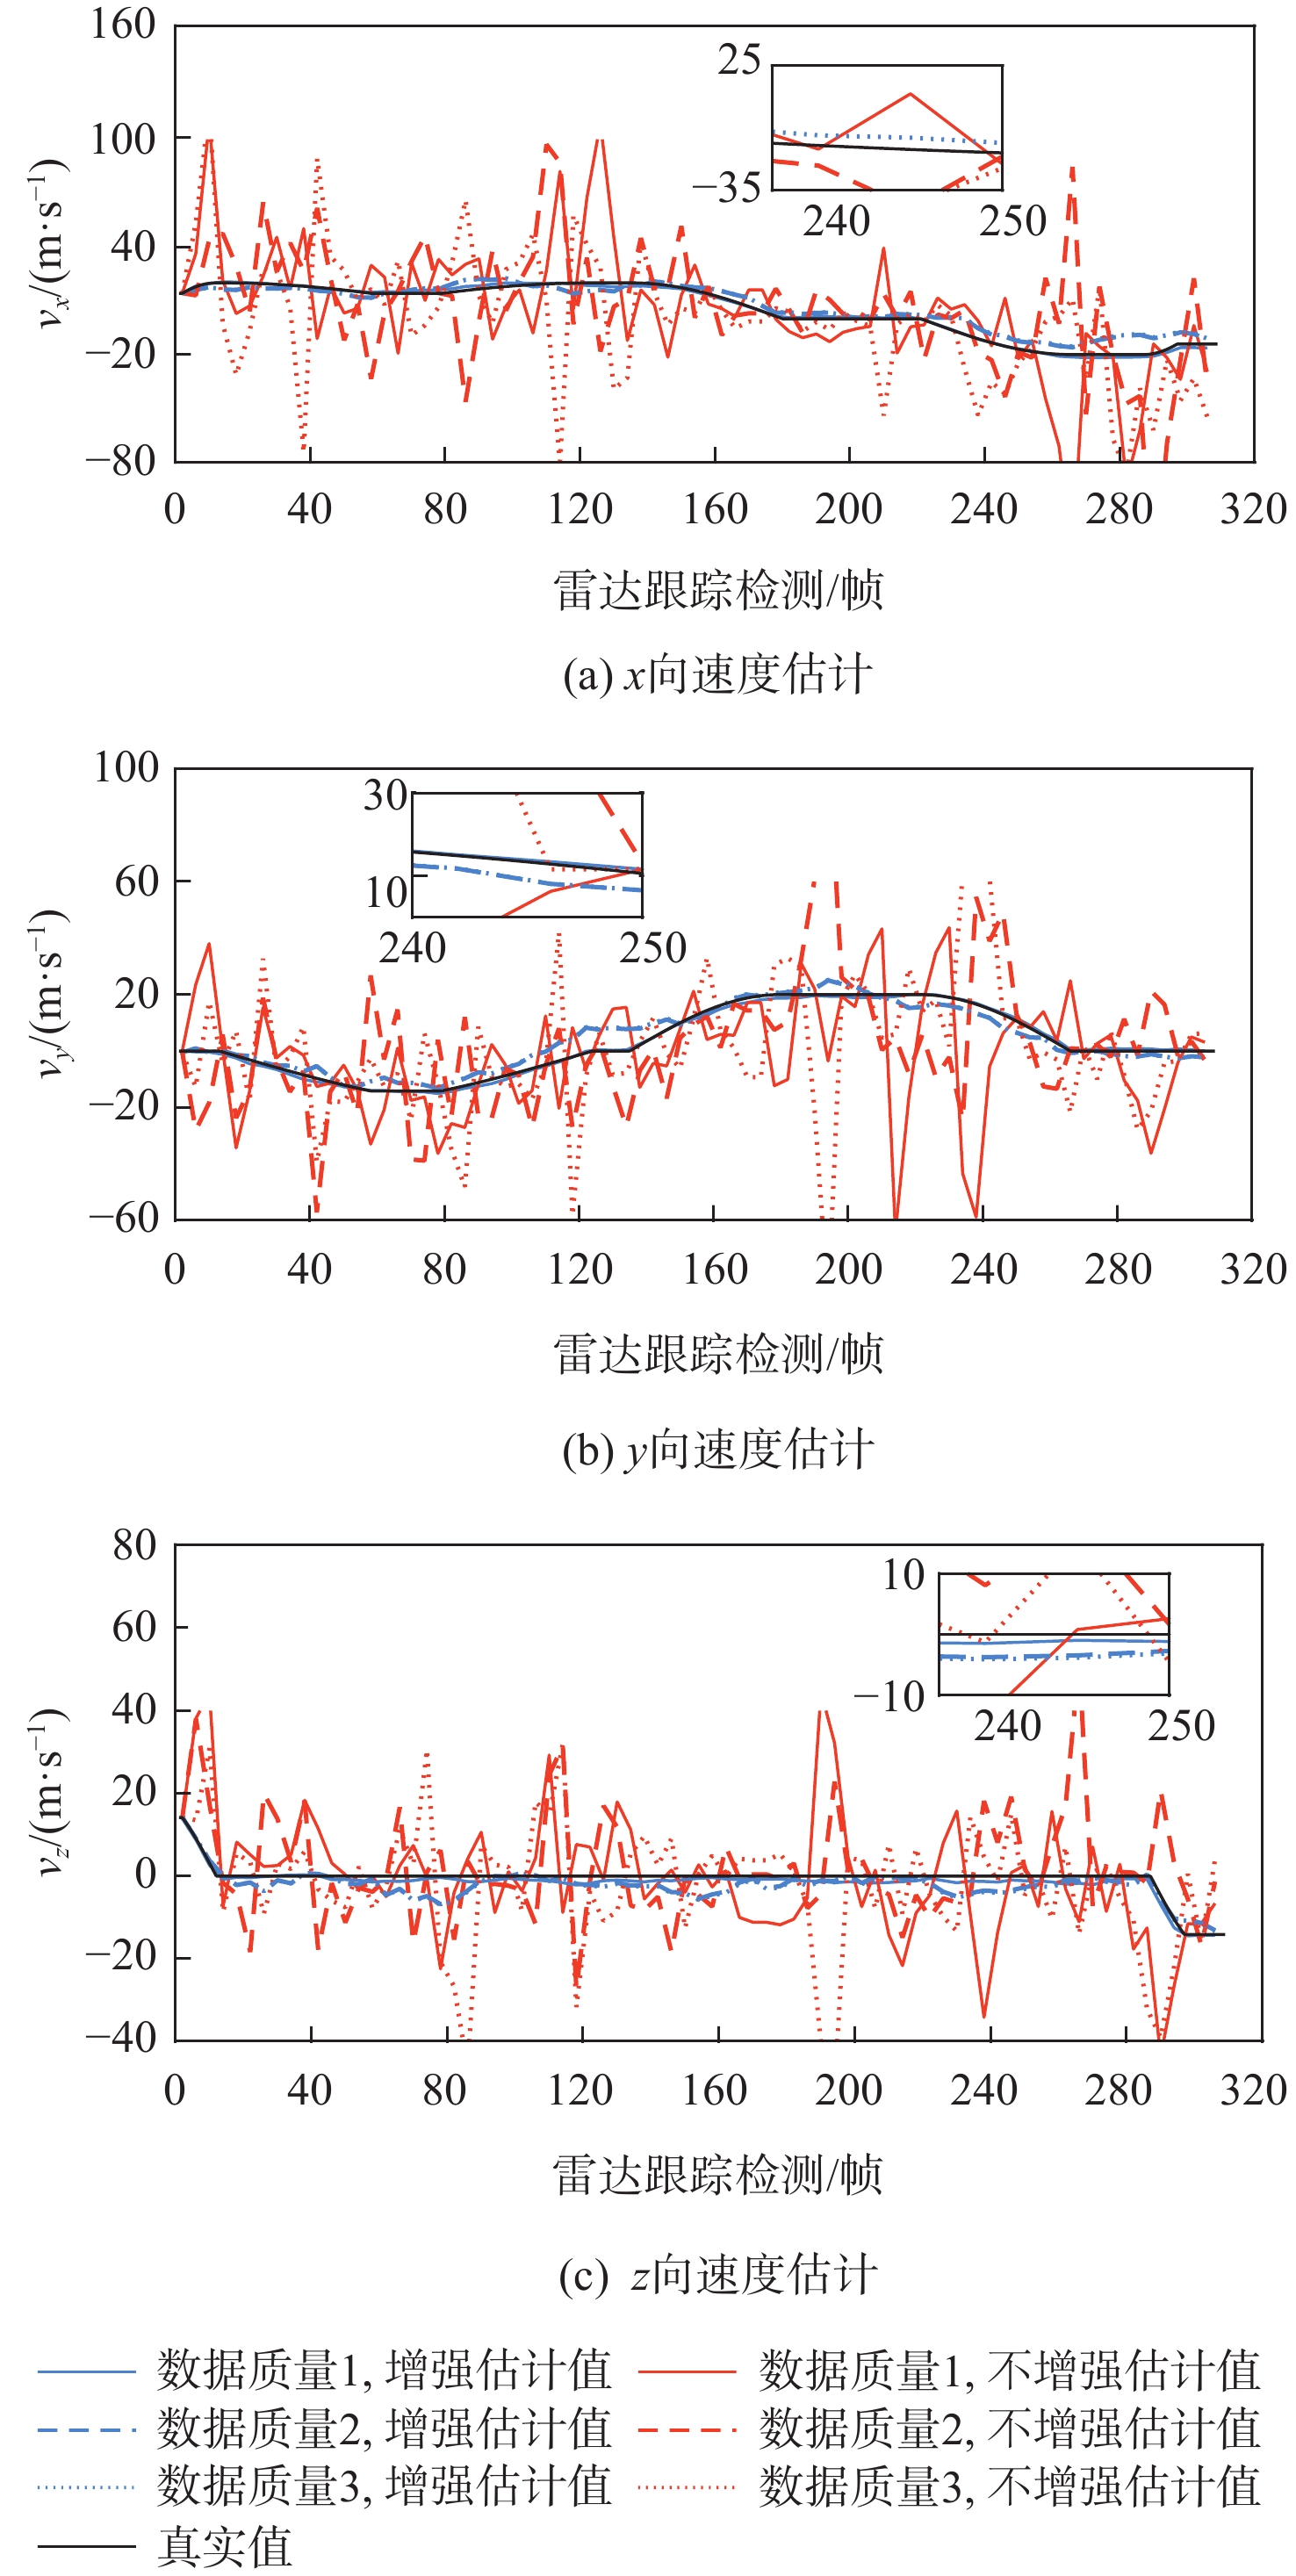
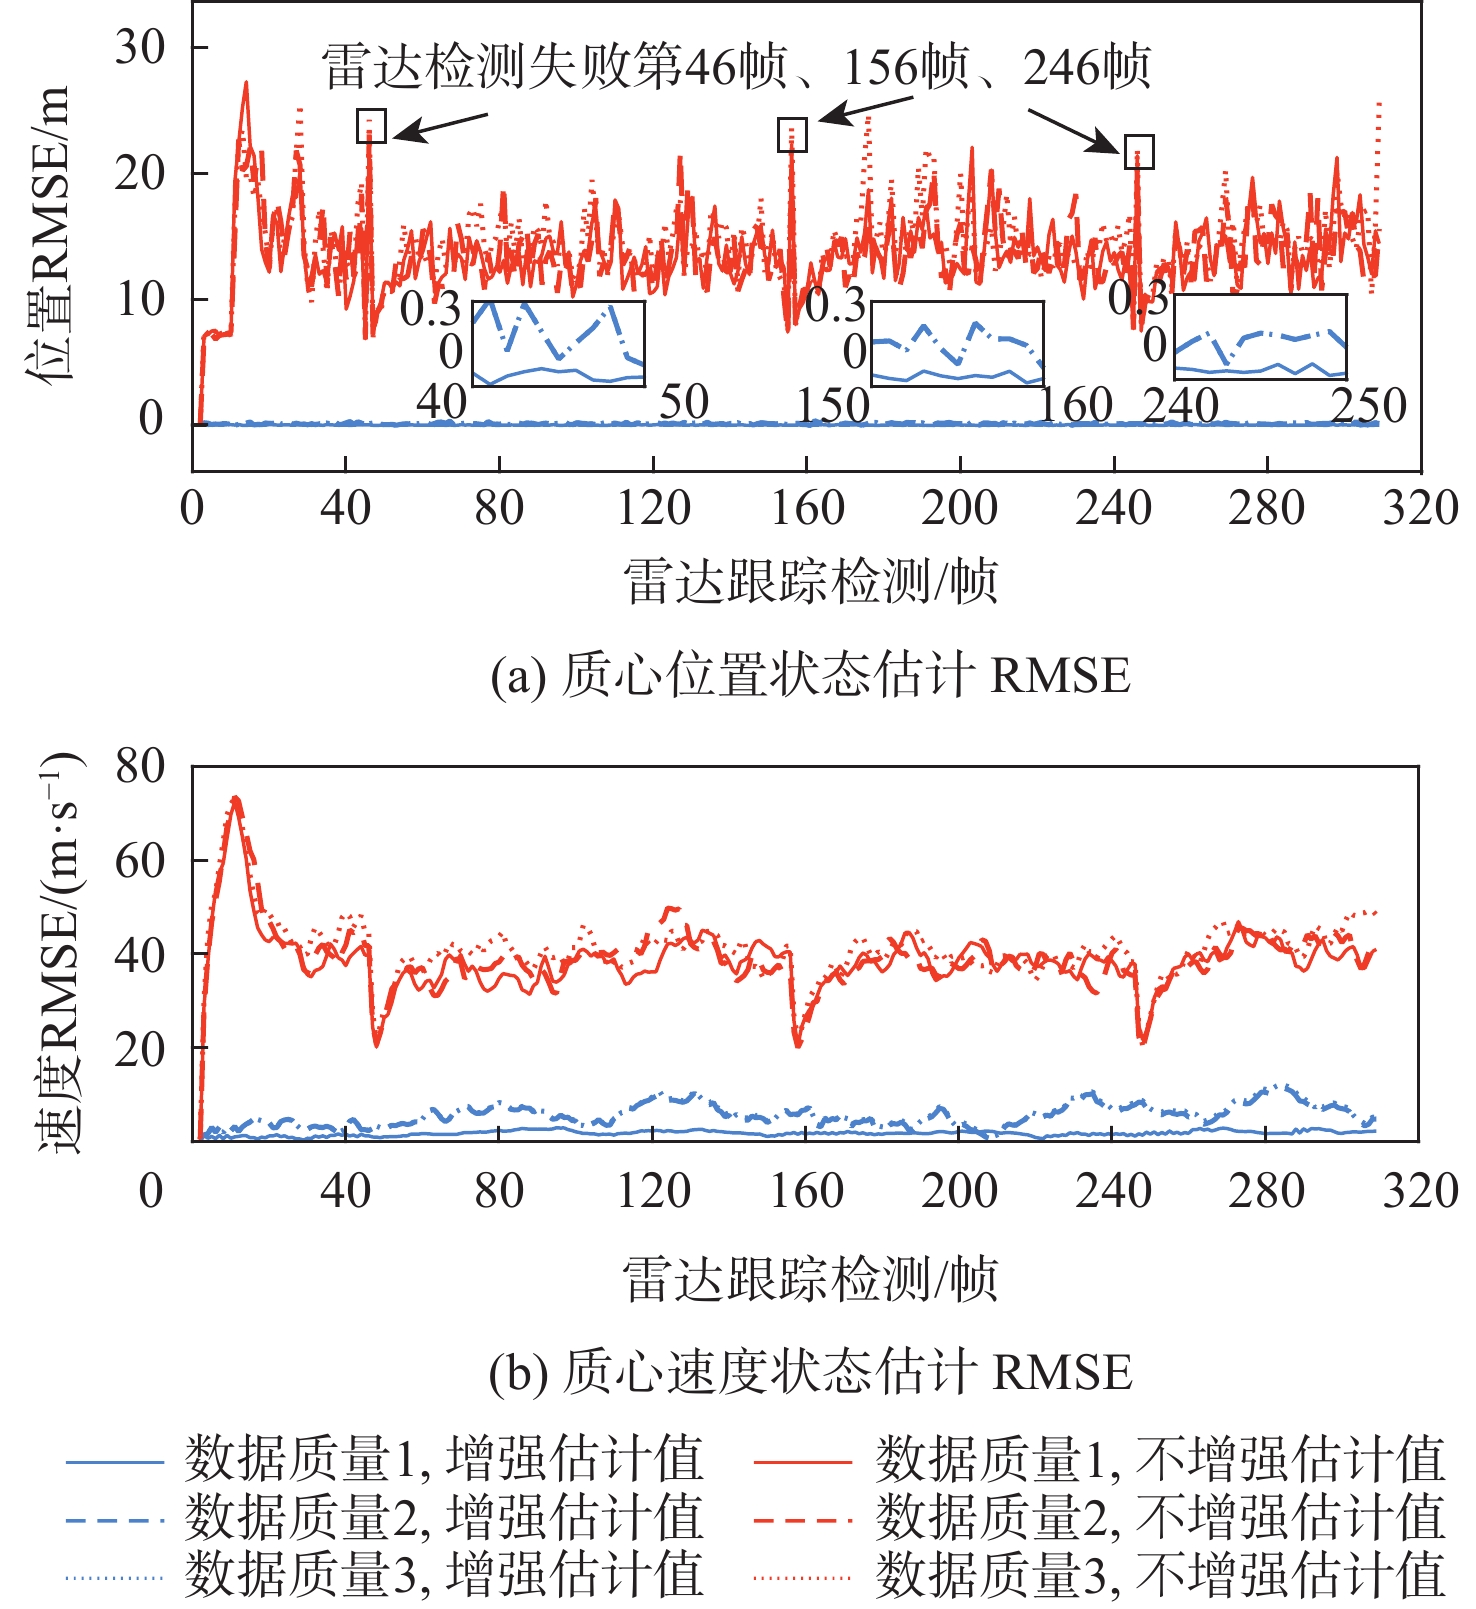
表 3 飞行器运动状态估计RMSE比较
Table 3. Comparison of estimation RMSE for kinematic state of aircraft
数据质量 位置RMSE/m 位置RMSE提升/% 速度RMSE/(m·s−1) 速度RMSE提升/% 不增强 增强 不增强 增强 1 13.668 0.039 99.71 38.392 1.468 96.18 2 13.926 0.151 98.92 38.607 5.683 85.28 3 14.304 0.152 98.94 40.515 6.023 85.13
下载: 导出CSV
表 4 飞行器扩展形态参数估计AED比较
Table 4. Comparison of estimation AED for extension shape parameters of aircraft
数据质量 长半轴长/m 减少比/% 短半轴长/m 减少比/% 主轴指向/(°) 减少比/% 不增强 增强 不增强 增强 不增强 增强 1 −4.847 −1.686 65.22 −1.135 0.217 80.88 11.623 1.082 90.69 2 −4.848 −1.698 64.98 −1.130 0.219 80.62 11.655 1.117 90.42 3 −4.904 −1.705 65.23 −1.254 0.206 83.57 11.909 1.278 89.27
下载: 导出CSV
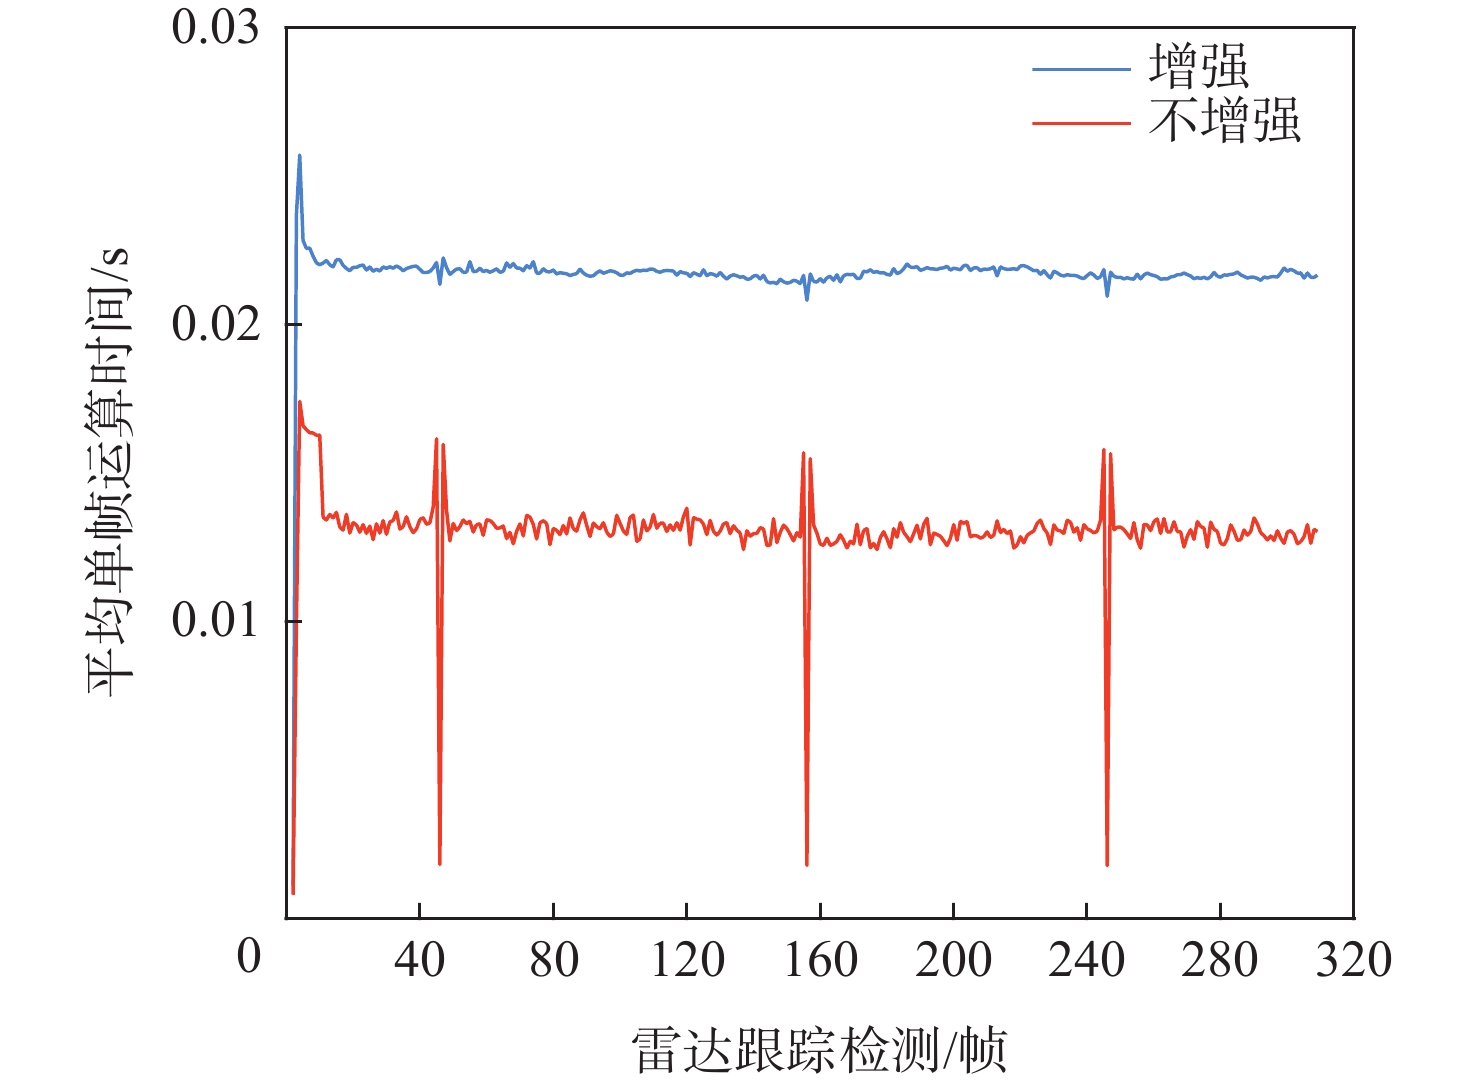
表 5 平均单帧运算时间和平均单帧量测数比较
Table 5. Comparison of average single-frame computational times and average single-frame measurement count
方法 平均单帧运算时间/s 平均单帧量测数/个 不增强 0.013 6.419 增强 0.021 63.853
下载: 导出CSV
-
[1] Huang X. The small-drone revolution is coming: scientists need to ensure it will be safe[J]. Nature, 2025, 637(8044): 29-30. [2] 杨雪榕, 杨雅君, 朱俊. 飞行器试验及数据统计处理方法[M]. 北京: 国防工业出版社, 2024: 7-8.Yang X R, Yang Y J, Zhu J. Aircraft experiment and data statistical processing method[M]. Beijing: National Defense Industry Press, 2024: 7-8(in Chinese). [3] 翟嘉琪, 杨希祥, 邓小龙, 等. 不确定风场下平流层浮空器全局路径规划[J]. 北京航空航天大学学报, 2023, 49(5): 1116-1126.Zhai J Q, Yang X X, Deng X L, et al. Global path planning of stratospheric aerostat in uncertain wind field[J]. Journal of Beijing University of Aeronautics and Astronautics, 2023, 49(5): 1116-1126(in Chinese). [4] Mahler R. PHD filters for nonstandard targets, I: extended targets[C]//Proceedings of the 12th International Conference on Information Fusion. Piscataway: IEEE Press, 2009: 915-921. [5] Granström K, Natale A, Braca P, et al. Gamma Gaussian inverse Wishart probability hypothesis density for extended target tracking using X-band marine radar data[J]. IEEE Transactions on Geoscience and Remote Sensing, 2015, 53(12): 6617-6631. [6] Du H C, Xie W X, Liu Z X, et al. Track-oriented marginal Poisson multi-Bernoulli mixture filter for extended target tracking[J]. Chinese Journal of Electronics, 2023, 32(5): 1106-1119. [7] Koch J W. Bayesian approach to extended object and cluster tracking using random matrices[J]. IEEE Transactions on Aerospace and Electronic Systems, 2008, 44(3): 1042-1059. [8] Feldmann M, Fränken D, Koch W. Tracking of extended objects and group targets using random matrices[J]. IEEE Transactions on Signal Processing, 2011, 59(4): 1409-1420. [9] Lan J, Li X R. Tracking of extended object or target group using random matrix: new model and approach[J]. IEEE Transactions on Aerospace and Electronic Systems, 2016, 52(6): 2973-2989. [10] Hu Q, Ji H B, Zhang Y Q. Tracking of maneuvering non-ellipsoidal extended target with varying number of sub-objects[J]. Mechanical Systems and Signal Processing, 2018, 99: 262-284. [11] Tuncer B, Orguner U, Özkan E. Multi-ellipsoidal extended target tracking with variational Bayes inference[J]. IEEE Transactions on Signal Processing, 2022, 70: 3921-3934. [12] Baum M, Hanebeck U D. Random hypersurface models for extended object tracking[C]//Proceedings of the IEEE International Symposium on Signal Processing and Information Technology. Piscataway: IEEE Press, 2010: 178-183. [13] Zea A, Faion F, Baum M, et al. Level-set random hypersurface models for tracking nonconvex extended objects[J]. IEEE Transactions on Aerospace and Electronic Systems, 2016, 52(6): 2990-3007. [14] Sun L F, Liu Z Y, Zhang D K, et al. Maneuvering extended object tracking based on generalized conversion nonlinear filtering with random weight cubature rule sampling[J]. Measurement, 2025, 251: 117231. [15] Ma T L, Sun H Y, Wang K X, et al. A novel set-member filter for maneuver non-ellipsoid extended target tracking with unknown but bounded noises[J]. IEEE Sensors Journal, 2025, 25(8): 13708-13718. [16] Baum M, Faion F, Hanebeck U D. Modeling the target extent with multiplicative noise[C]//Proceedings of the 15th International Conference on Information Fusion. Piscataway: IEEE Press, 2012: 2406-2412. [17] Yang S S, Baum M. Tracking the orientation and axes lengths of an elliptical extended object[J]. IEEE Transactions on Signal Processing, 2019, 67(18): 4720-4729. [18] Kumru M, Ozkan E. Three-dimensional extended object tracking and shape learning using Gaussian processes[J]. IEEE Transactions on Aerospace and Electronic Systems, 2021, 57(5): 2795-2814. [19] Xu M D, Yang C Q, Cao X M, et al. Irregular extended target tracking with unknown measurement noise covariance[J]. Signal Processing, 2024, 225: 109600. [20] Garcia N, Fascista A, Coluccia A, et al. Cramér-Rao bound analysis of radars for extended vehicular targets with known and unknown shape[J]. IEEE Transactions on Signal Processing, 2022, 70: 3280-3295. [21] 陈振, 李翠芸, 李想. B样条曲面三维扩展目标跟踪算法[J]. 西安电子科技大学学报(自然科学版), 2023, 50(2): 101-111.Chen Z, Li C Y, Li X. Algorithm for tracking the 3D extended target based on the B-spline surface[J]. Journal of Xidian University (Natural Science), 2023, 50(2): 101-111(in Chinese). [22] 陈辉, 边斌超, 连峰, 等. 基于Transformer复杂运动辨识的机动星凸形扩展目标跟踪方法[J]. 雷达学报, 2024, 13(3): 629-645.Chen H, Bian B C, Lian F, et al. A novel method for tracking complex maneuvering star convex extended targets using Transformer network[J]. Journal of Radars, 2024, 13(3): 629-645(in Chinese). [23] Chen H, Bian B C, Lian F, et al. Maneuvering extended target tracking method based on transformer network[J]. Measurement, 2025, 240: 115474. [24] Jiao H, Yan J K, Pu W Q, et al. Wideband sensor resource allocation for extended target tracking and classification[J]. IEEE Transactions on Signal Processing, 2025, 73: 55-66. [25] Zhang X X, Lan J. Measurement combination estimator for multisensor extended object tracking using random matrix[J]. IEEE Transactions on Aerospace and Electronic Systems, 2024, 60(1): 698-715. [26] Hoher P, Wirtensohn S, Baur T, et al. Extended target tracking with a lidar sensor using random matrices and a virtual measurement model[J]. IEEE Transactions on Signal Processing, 2022, 70: 228-239. [27] Cao X M, Lan J, Liu Y S, et al. Tracking of rectangular object using key points with regionally concentrated measurements[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(6): 5312-5327. [28] 梁苑, 戚国庆, 陈烨, 等. 不完全量测下事件触发水面扩展目标跟踪[J]. 兵工学报, 2024, 45(4): 1219-1228.Liang Y, Qi G Q, Chen Y, et al. Event-triggered surface extended target tracking with intermittent measurements[J]. Acta Armamentarii, 2024, 45(4): 1219-1228(in Chinese). [29] Granstrom K, Bramstang J. Bayesian smoothing for the extended object random matrix model[J]. IEEE Transactions on Signal Processing, 2019, 67(14): 3732-3742. [30] Wang S H, Men C K, Li R X, et al. Extended target-tracking algorithm based on variational Bayes and axis estimation theory[J]. IEEE Transactions on Instrumentation and Measurement, 2025, 74: 8507216. [31] 张晔, 侯毅, 欧阳克威, 等. 单变量序列数据分类方法综述[J]. 系统工程与电子技术, 2023, 45(2): 313-335.Zhang Y, Hou Y, Ouyang K W, et al. Survey of univariate sequence data classification methods[J]. Systems Engineering and Electronics, 2023, 45(2): 313-335(in Chinese). [32] 李春辉, 马健, 杨永建, 等. 低复杂度自适应容积卡尔曼滤波算法[J]. 北京航空航天大学学报, 2022, 48(4): 716-724.Li C H, Ma J, Yang Y J, et al. Low-complexity adaptive cubature Kalman filter algorithm[J]. Journal of Beijing University of Aeronautics and Astronautics, 2022, 48(4): 716-724(in Chinese). -

 下载:

 点击查看大图
计量
- 文章访问数: 224
- HTML全文浏览量: 142
- PDF下载量: 19
- 被引次数: 0
