


-
摘要:
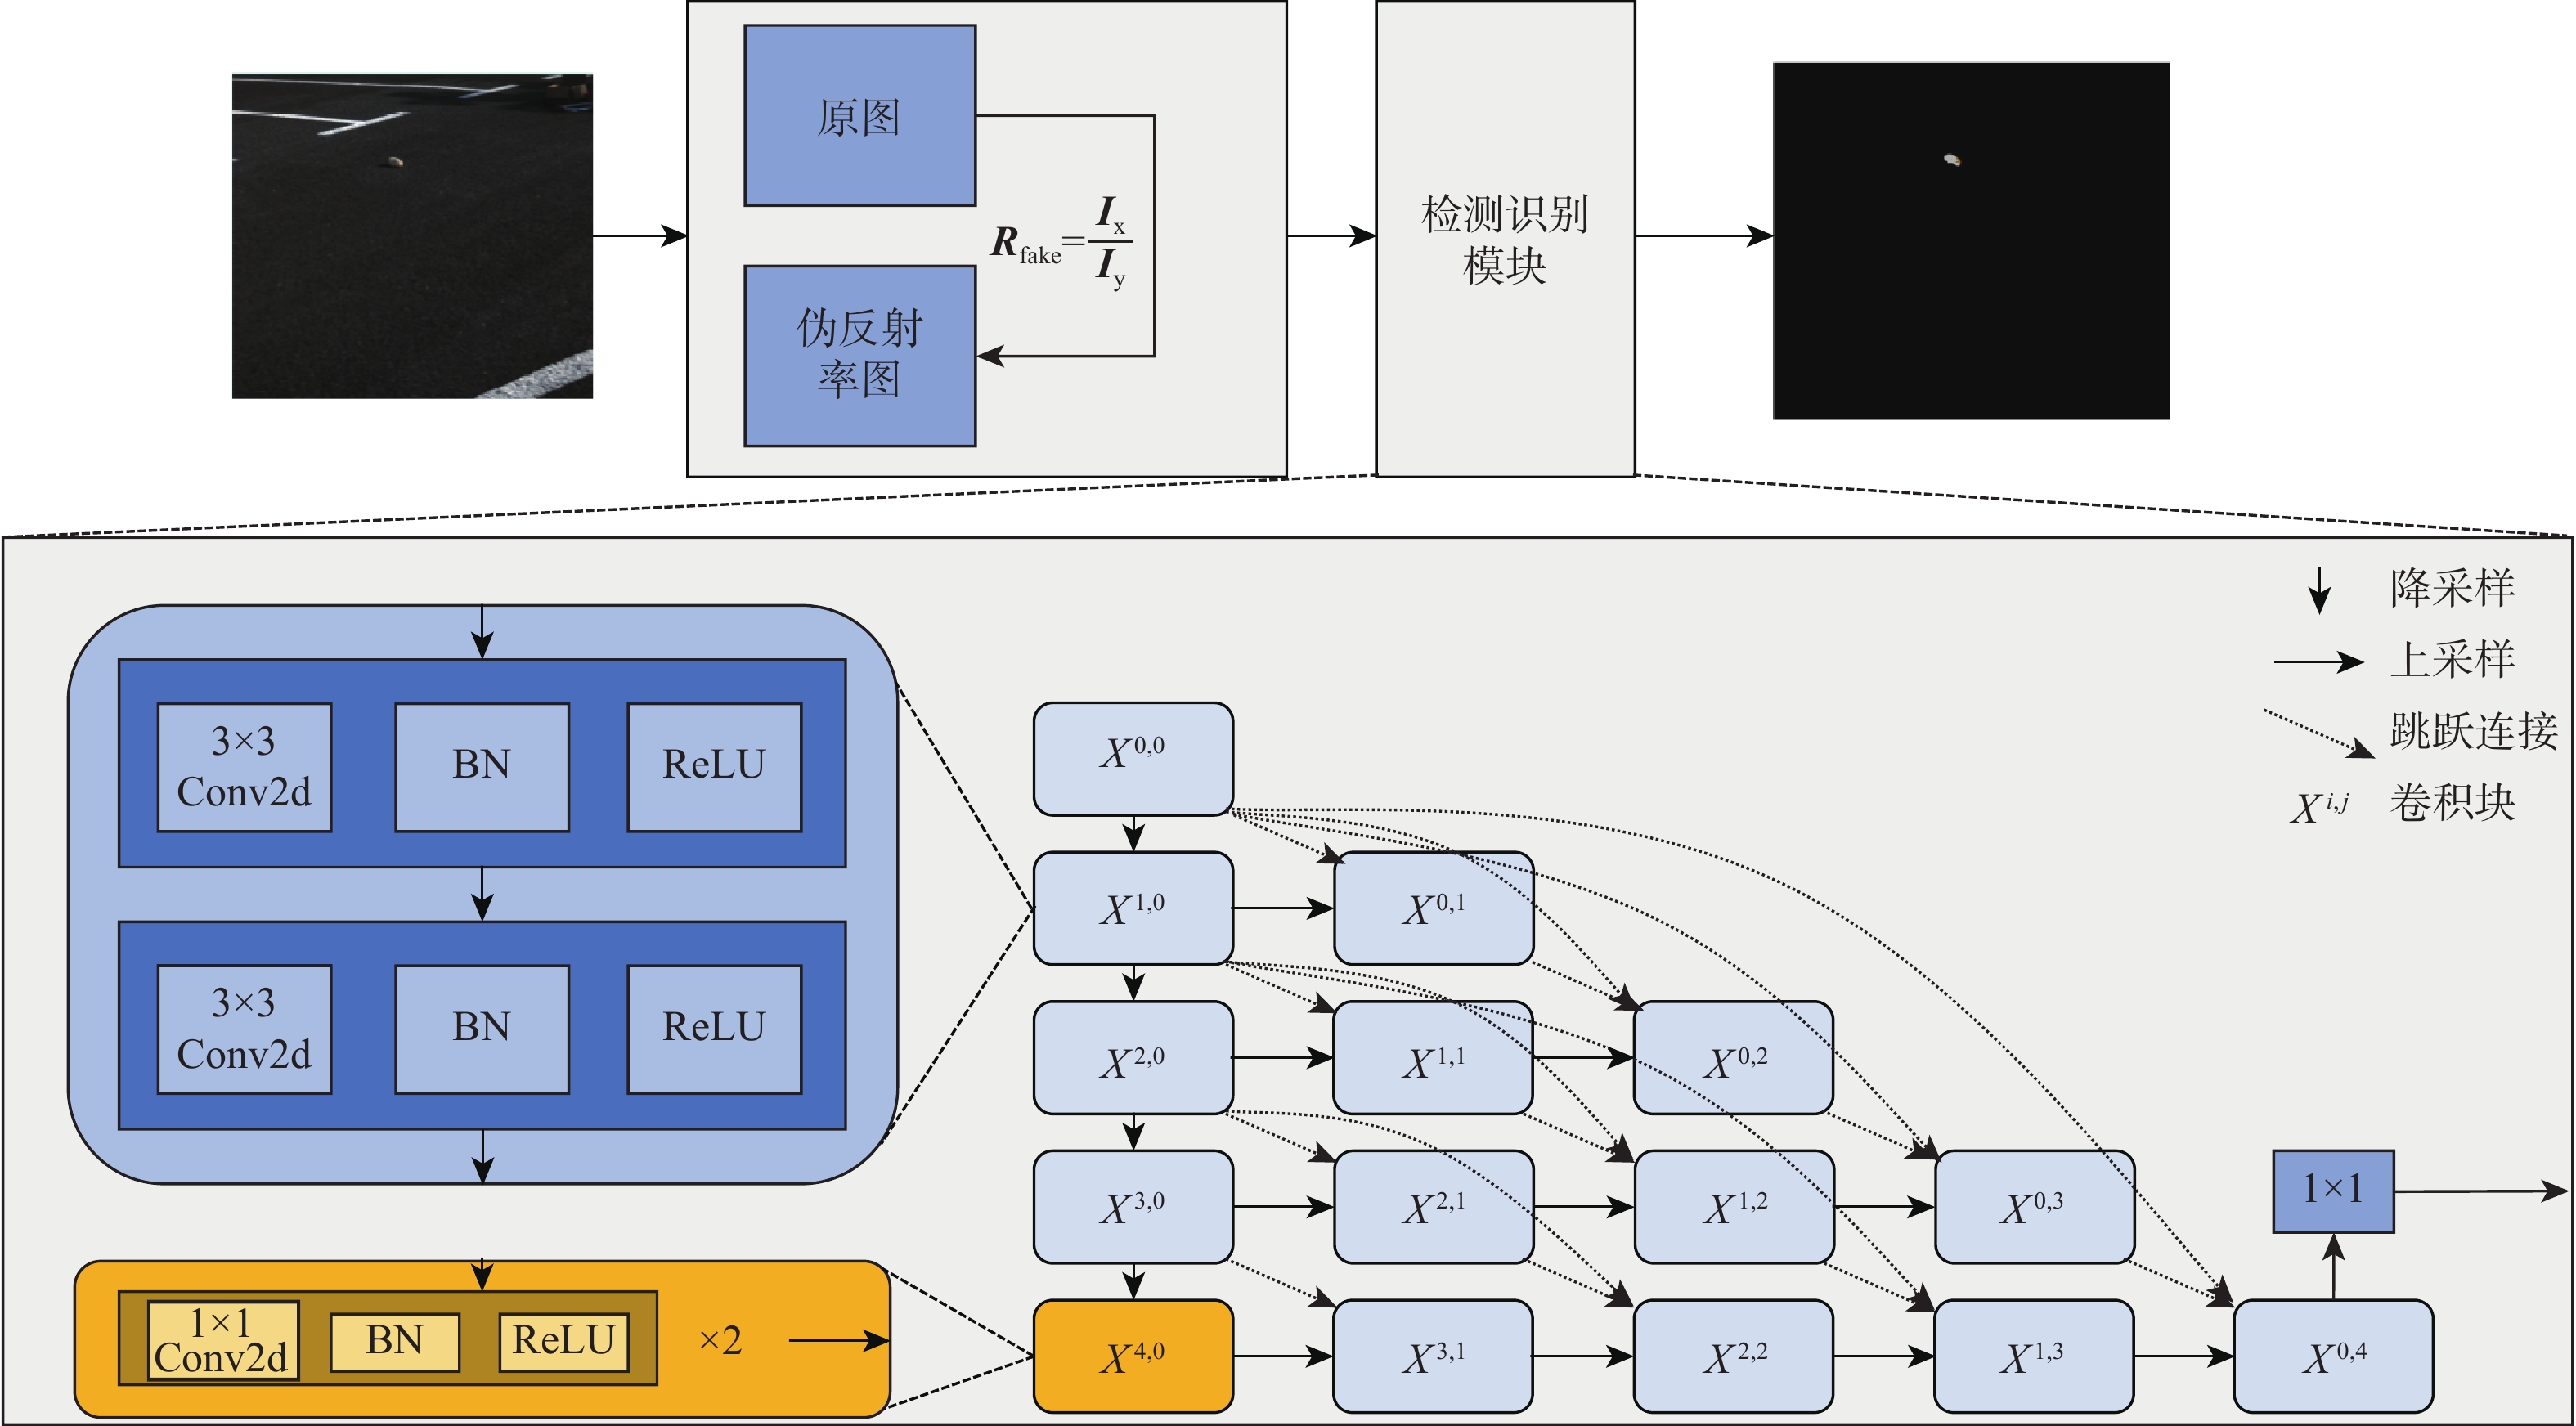
低空起降场跑道外来物(FOD)的检测与识别对于飞机飞行性能与机场运行安全具有重要意义。针对FOD目标尺寸小、无表观特征的特点及公开数据少的问题,构建FOD数据集,并提出一种基于物理特性的FOD检测与识别方法。采集常见FOD材质的多光谱图像,构建FOD的多光谱数据集。基于该数据集,对常见FOD (包括金属的锈迹与强反射现象)进行属性分析。基于沥青背景反射率,得到材质相对沥青的伪反射率。通过多种统计量,初步验证了不同材质的可分性,进而提出了使用密集嵌套连接的编码器-解码器结构神经网络,将伪反射率作为输入进行材质识别,在所构建数据集的测试集中,准确率为
0.9993 ,Macro-F1分数为0.7749 ,优于同模型大小等级的其他材质识别和分割模型。Abstract:The detection and recognition of foreign object debris (FOD) on low-altitude takeoff and landing runways are of critical importance to aircraft performance and airport operational safety. A FOD dataset was created and a physics-based FOD detection and identification approach was suggested in order to address the issues caused by the small size, lack of distinctive visual traits, and restricted availability of public data for FOD. Initially, multispectral images of common FOD materials were collected to establish a multispectral FOD dataset. Based on this dataset, attribute analysis was conducted on common FOD types, including metal rust and strong reflection phenomena. Utilizing the reflectivity of asphalt backgrounds, a pseudo-reflectivity metric relative to asphalt was derived for different materials. Through various statistical measures, the separability of different materials was preliminarily validated. Subsequently, a neural network with an encoder-decoder architecture featuring densely nested connections was proposed, using pseudo-reflectivity as input for material identification. The suggested approach outperformed existing material identification and segmentation models with similar parameter ranges on the test set of this dataset, achieving an accuracy of
0.9993 and a Macro-F1 score of0.7749 . -
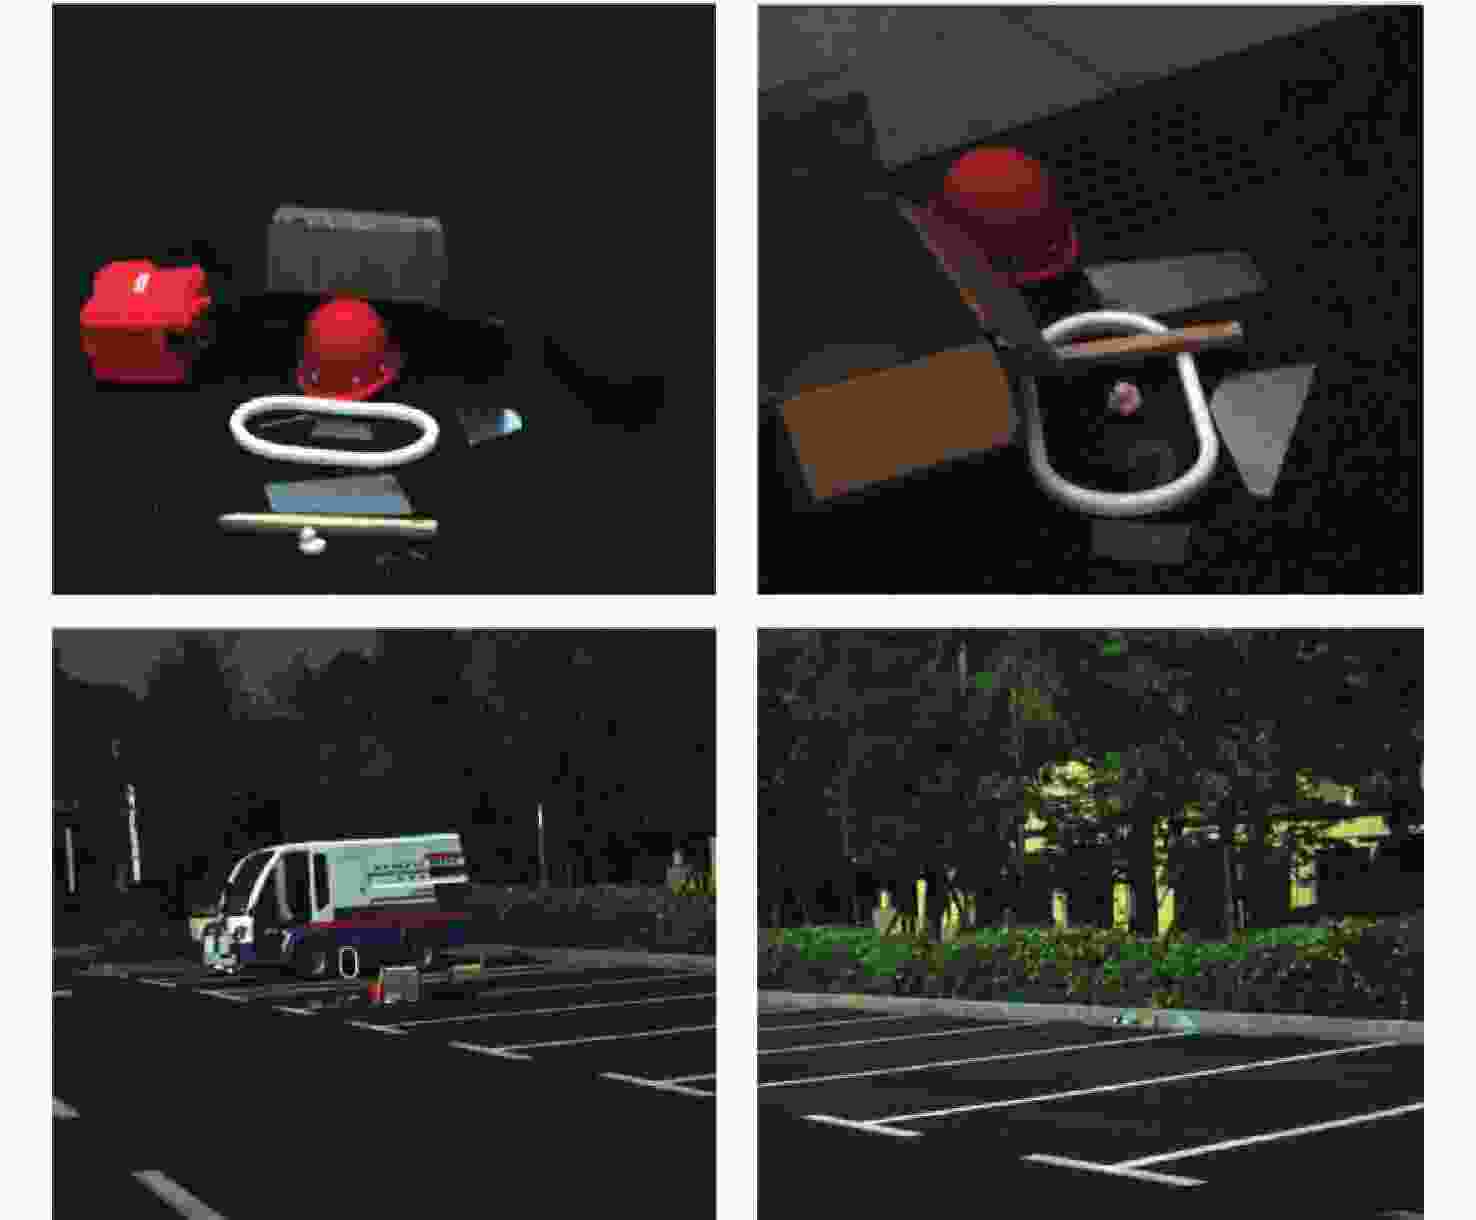
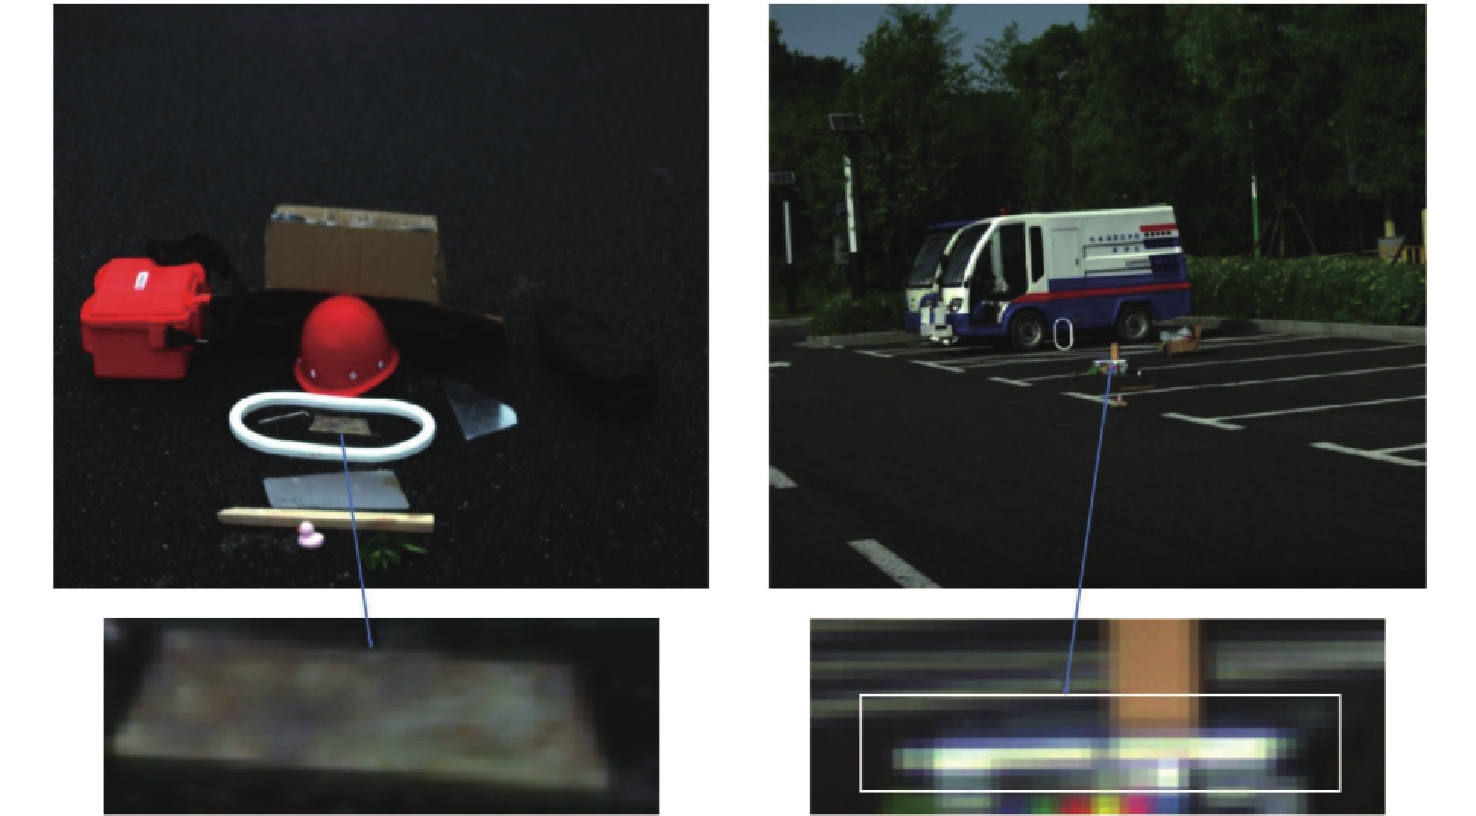
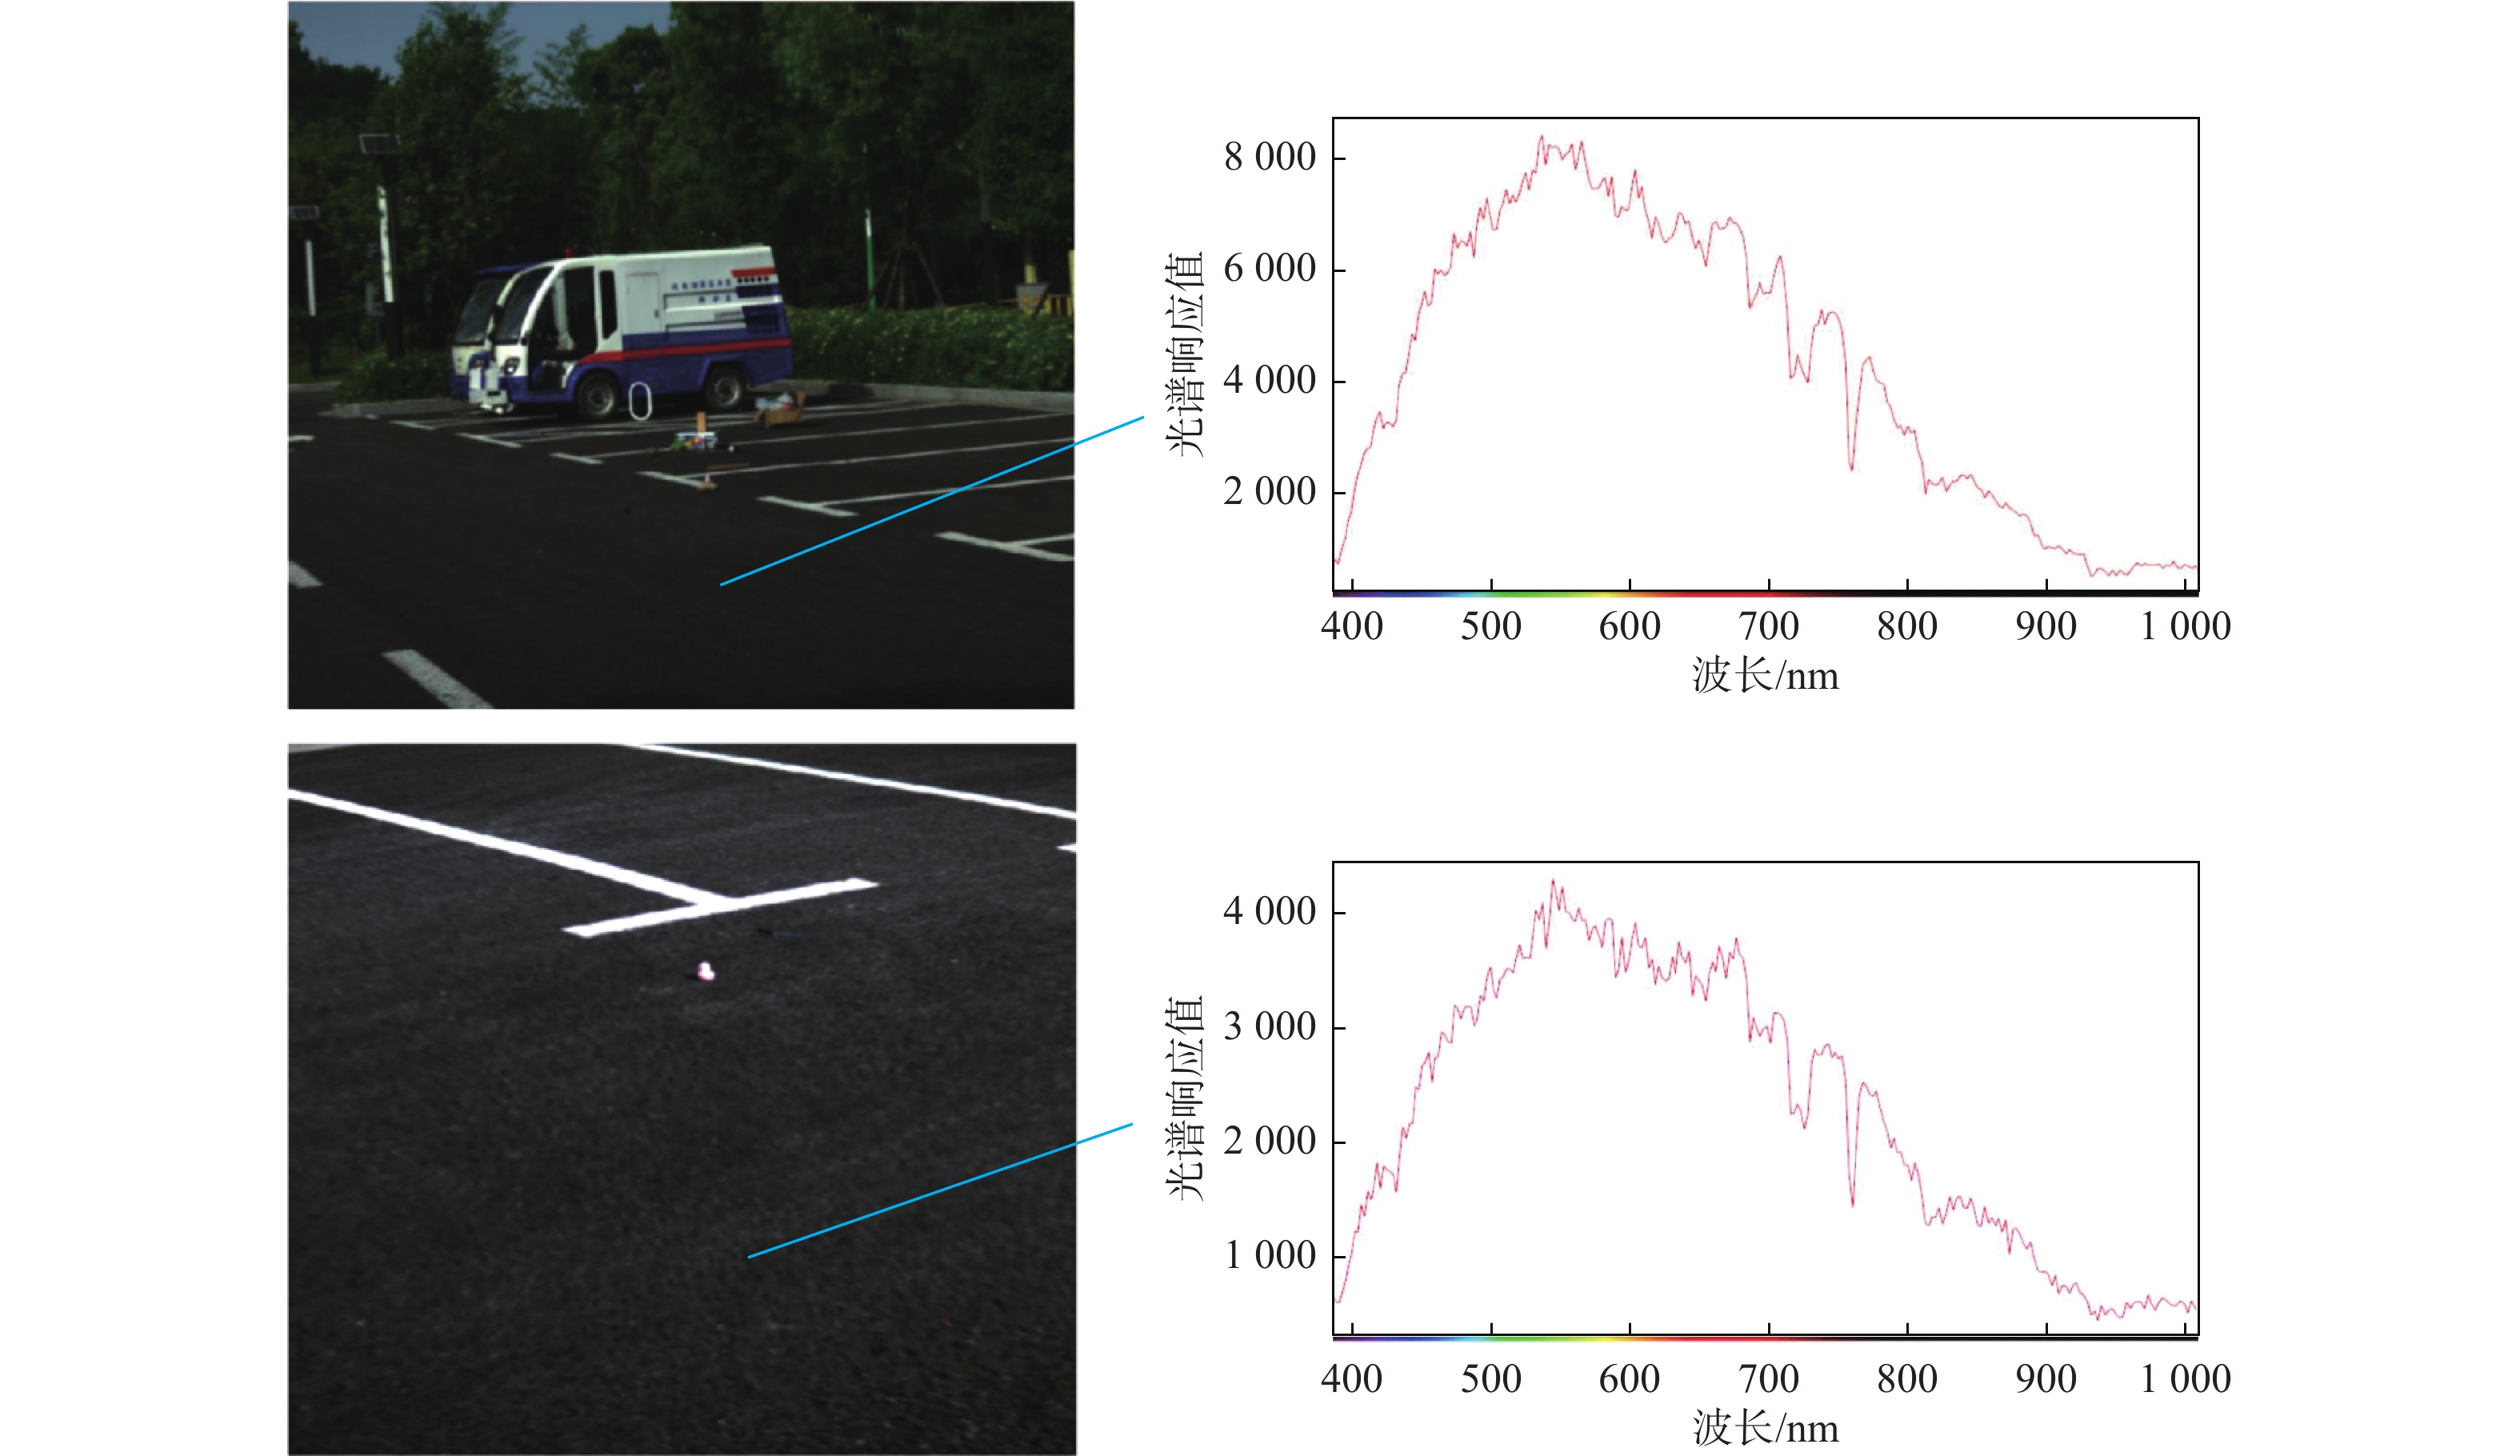
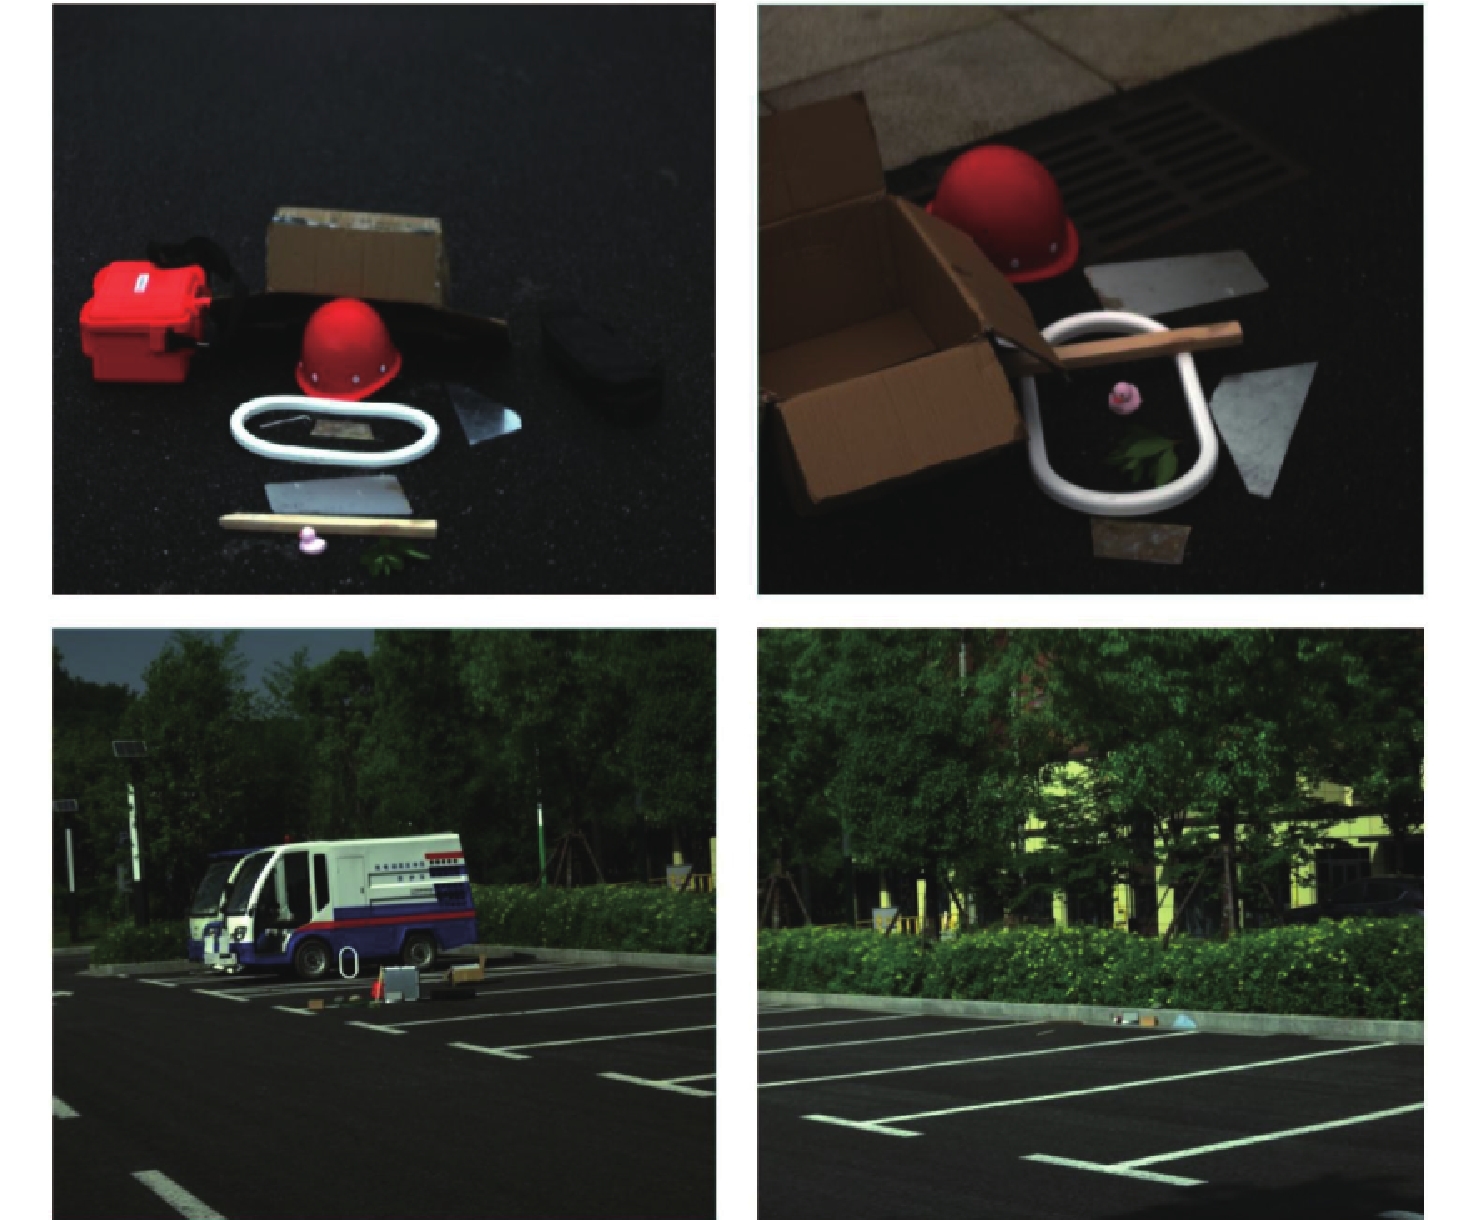
图 1 多光谱数据集中训练集示例(图片为使用红、绿、蓝3波段合成的伪RGB图像)
Figure 1. Training set examples in the multispectral dataset (images are pseudo-RGB images synthesized using red, green, and blue wavelengths)
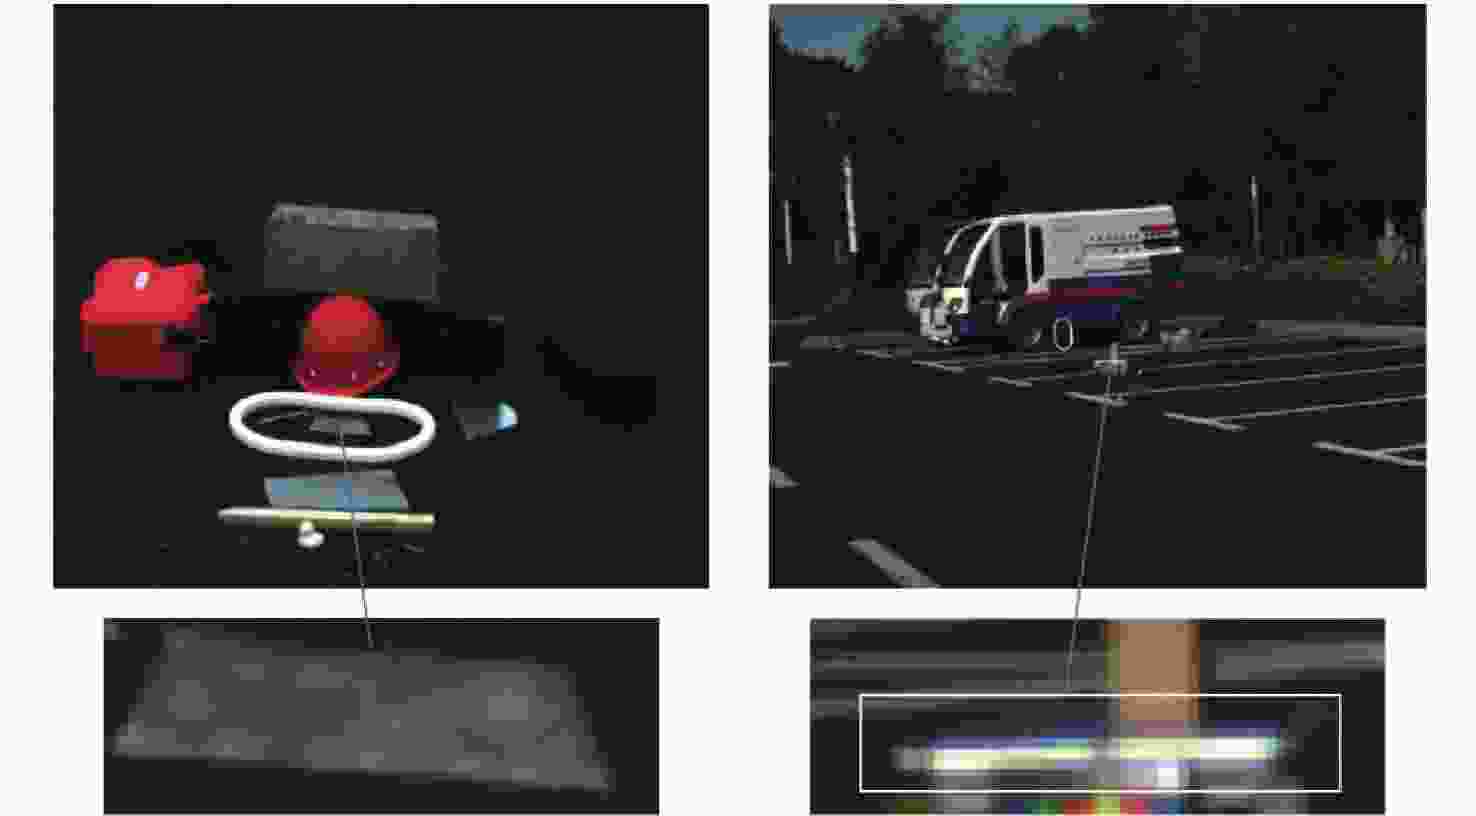
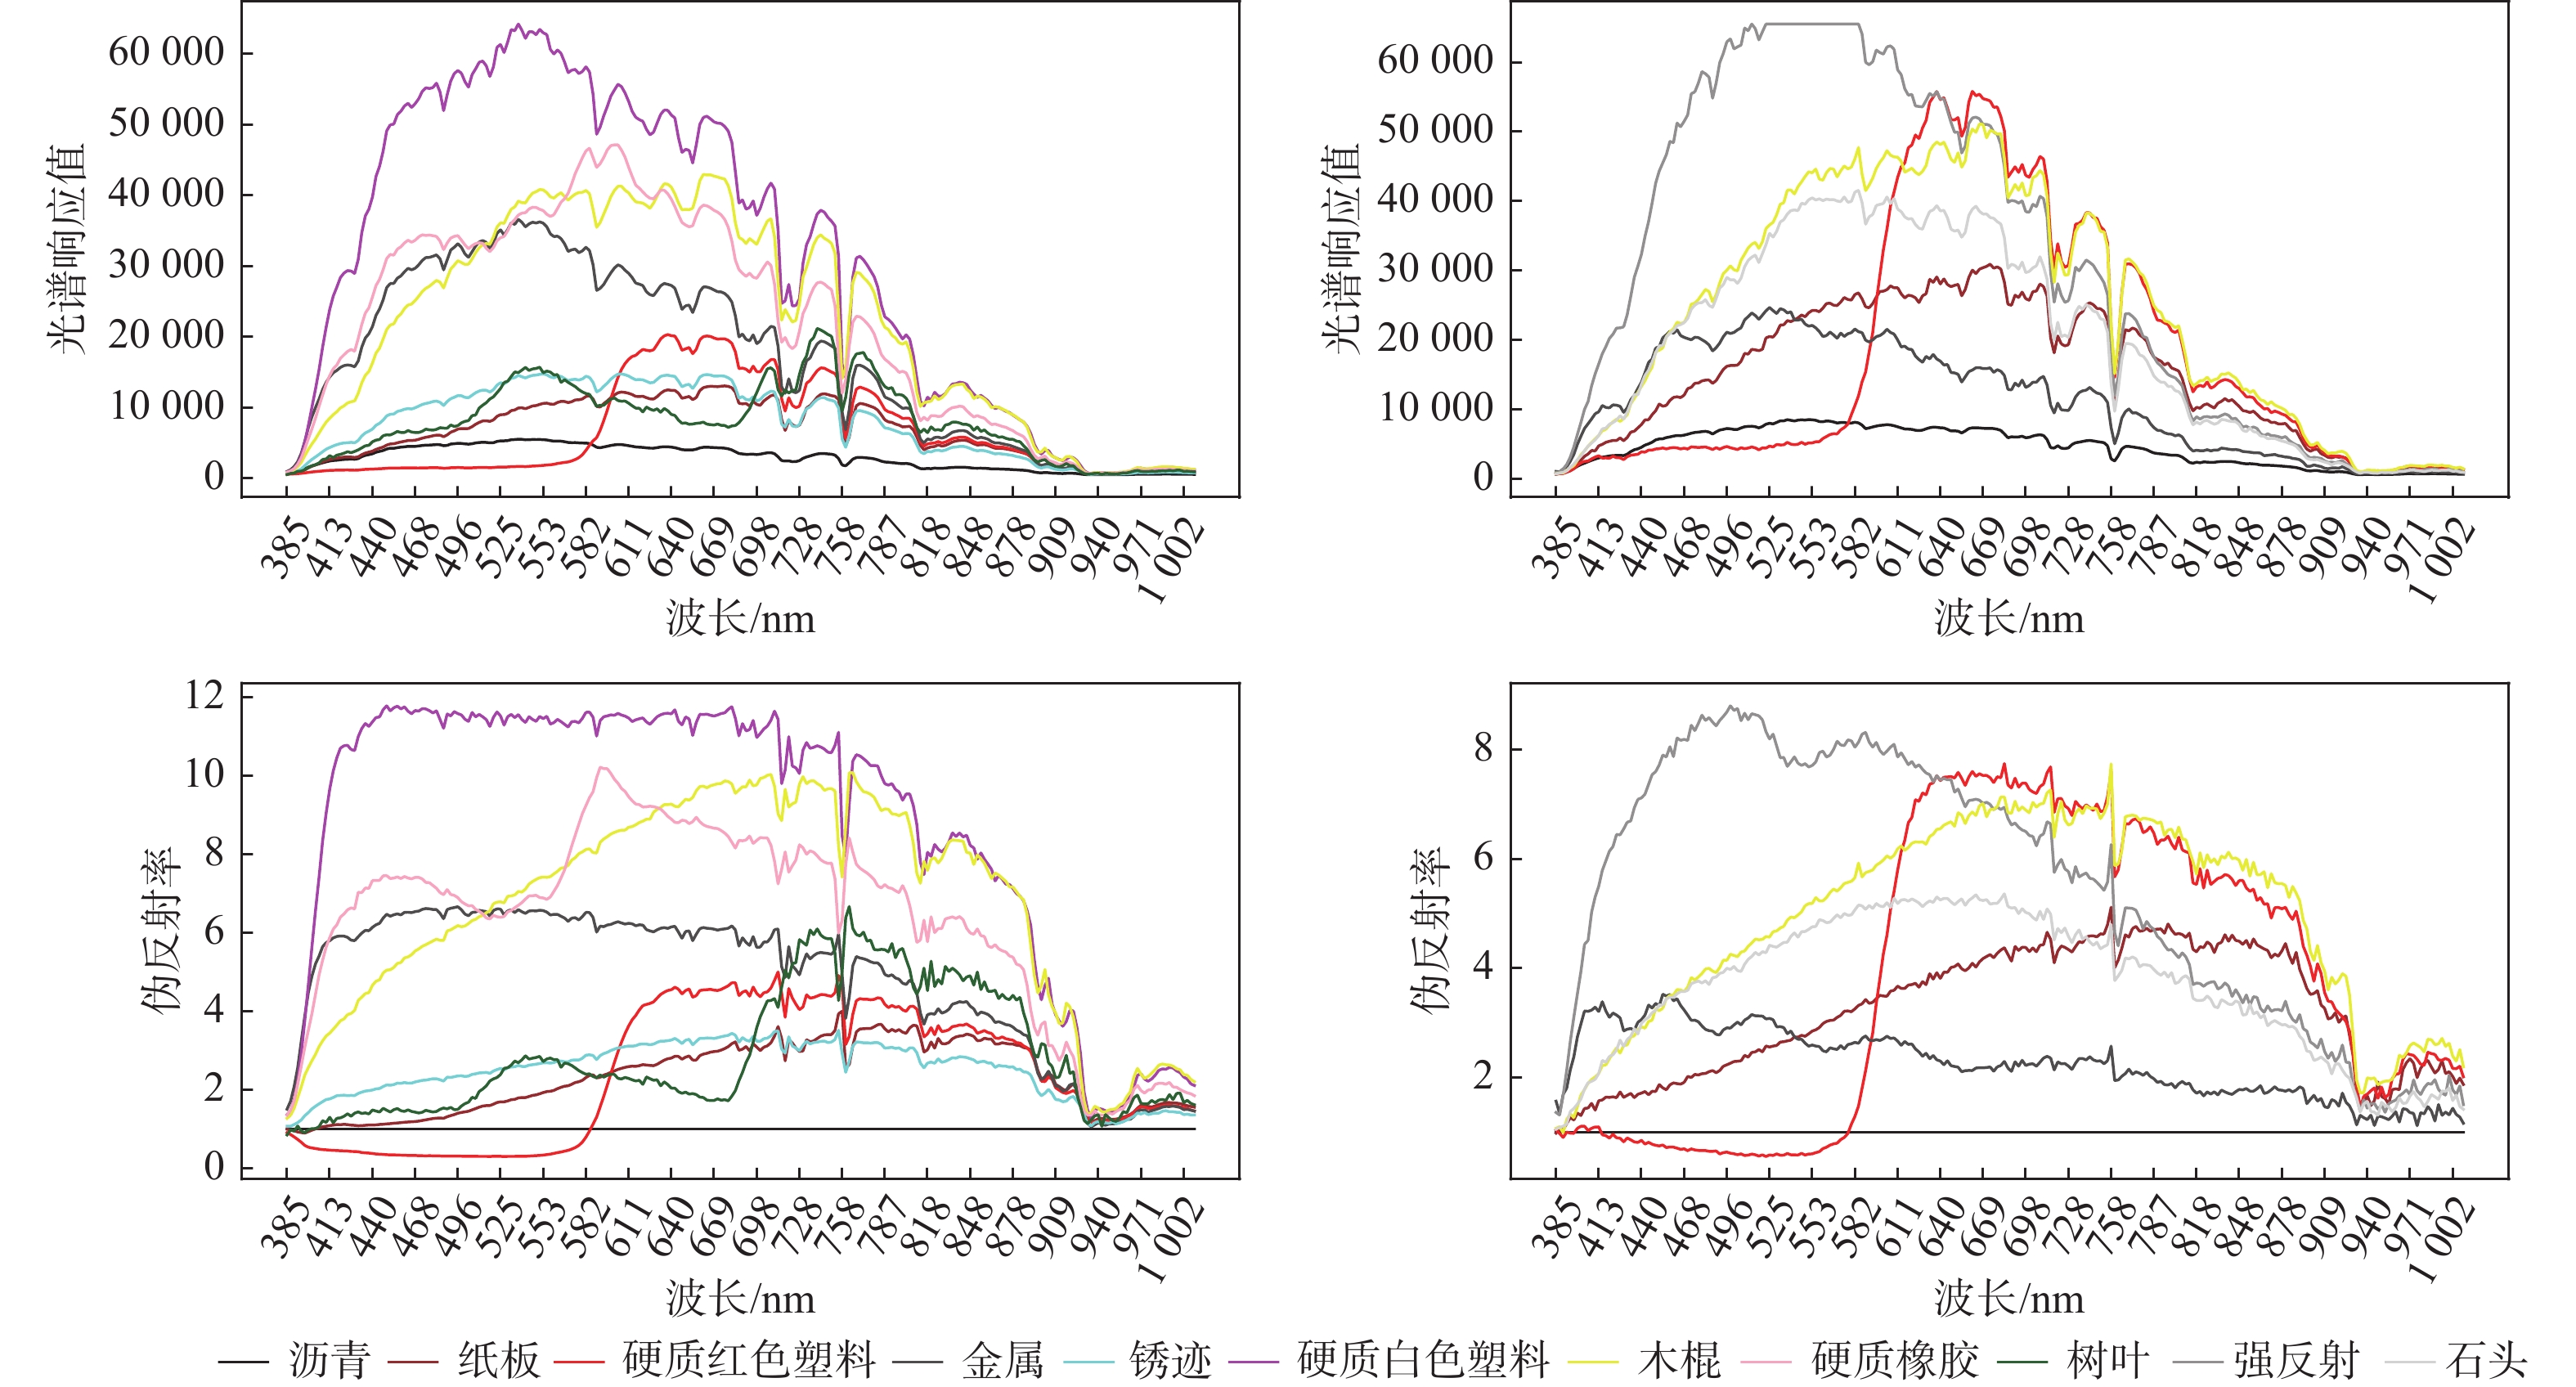
图 2 数据集中金属出现的锈迹与强反射现象
Figure 2. Rust stains and strong reflection phenomena appearing on metals in the dataset
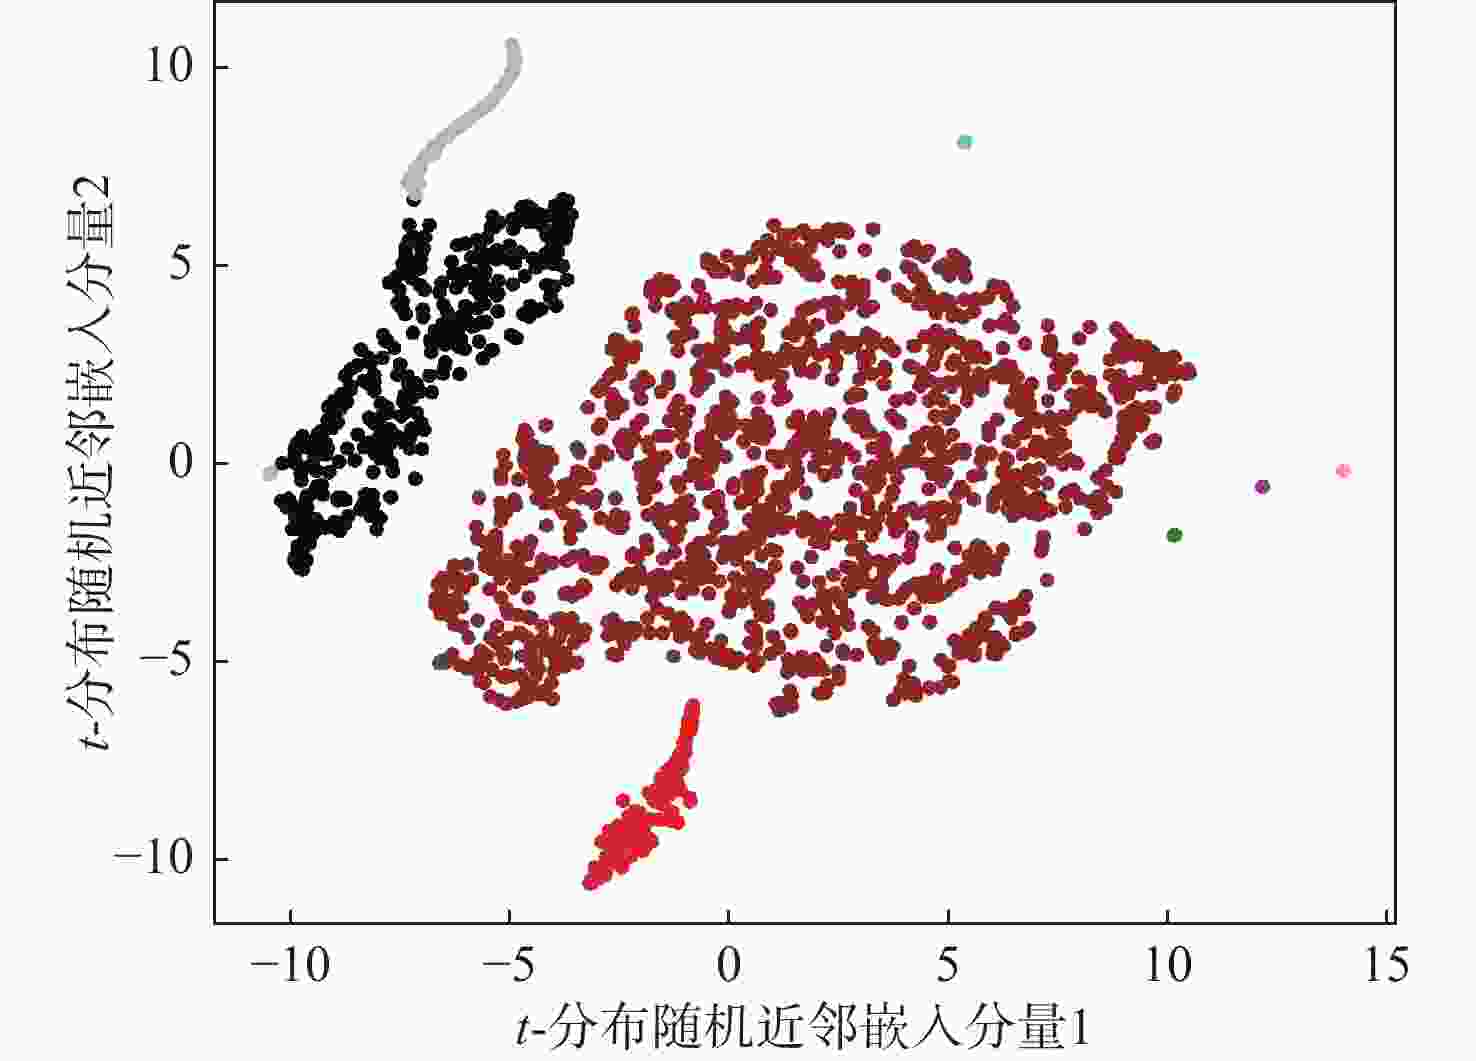
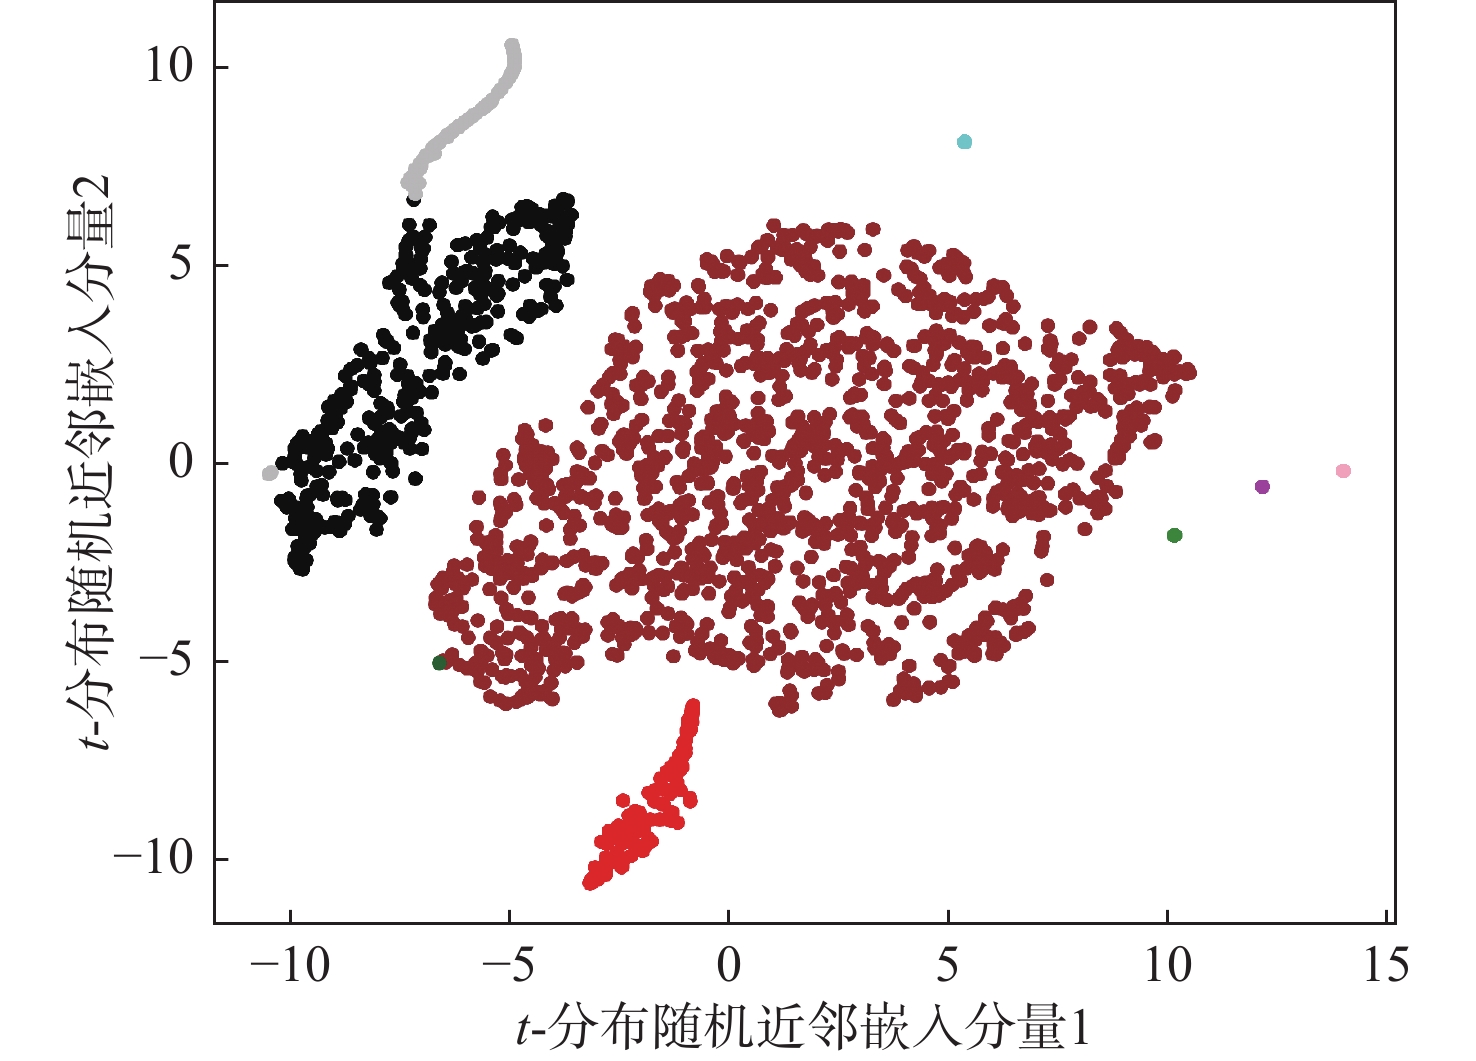
图 6 t-分布随机近邻嵌入可视化结果
Figure 6. t-distributed stochastic neighbor embedding visualization results
表 1 多种衡量尺度下FOD数据的可分性验证
Table 1. Verification of FOD data separability under multiple measurement scales
指标类别 指标 p值 衡量尺度 马氏距离 4.950 离散度 4.983 MANOVA统计量 Wilks’ Lambda 0 Pillai’s Trace 0 Hotelling’s Trace 0 Roy’s Largest Root 0  下载: 导出CSV
表 3 6波段与RGB下模型的测试指标值
Table 3. Test values for 6-band and RGB sub-models
波段数 准确率 Macro-F1 3(RGB) 0.7877 0.4884 6 0.9993 0.7749
下载: 导出CSV
表 4 Tversky指数加入与否的测试指标值
Table 4. Test values with or without Tversky index
损失函数 准确率 Macro-F1 Focal Loss 0.9991 0.6160 本文 0.9993 0.7749
下载: 导出CSV
-
[1] Federal Aviation Administration. Airport foreign object debris detection equipment: AC 150/5220-24—2009[S]. Washington, D. C. : USA Department of Transportation, 2010. [2] Ren S Q, He K M, Girshick R, et al. Faster R-CNN: towards real-time object detection with region proposal networks[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2017, 39(6): 1137-1149. [3] Redmon J, Divvala S, Girshick R, et al. You only look once: unified, real-time object detection[C]//Proceedings of the 2016 IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2016: 779-788. [4] Cao X G, Wang P, Meng C, et al. Region based CNN for foreign object debris detection on airfield pavement[J]. Sensors, 2018, 18(3): 737. [5] 韩松臣, 张比浩, 李炜, 等. 基于改进Faster-RCNN的机场场面小目标物体检测算法[J]. 南京航空航天大学学报, 2019, 51(6): 735-741.Han S C, Zhang B H, Li W, et al. Small target detection in airport scene via modified Faster-RCNN[J]. Journal of Nanjing University of Aeronautics & Astronautics, 2019, 51(6): 735-741(in Chinese). [6] Munyer T, Brinkman D, Zhong X, et al. Foreign object debris detection for airport pavement images based on self-supervised localization and vision Transformer[C]//Proceedings of the 2022 International Conference on Computational Science and Computational Intelligence. Piscataway: IEEE Press, 2023: 1388-1394. [7] 荆颖, 郑红, 郑文韬. 基于高斯混合特征改进的自编码器机场跑道FOD精准检测[J]. 计算机辅助设计与图形学学报, 2025, 37(9): 1593-1606.Jing Y, Zheng H, Zheng W T. Gaussian mixture feature improved autoencoder for FOD detection on airport runway[J]. Journal of Computer-Aided Design & Computer Graphics, 2025, 37(9): 1593-1606(in Chinese). [8] Bell S, Upchurch P, Snavely N, et al. Material recognition in the wild with the materials in context database[C]//Proceedings of the 2015 IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2015: 3479-3487. [9] Zhang H, Xue J, Dana K. Deep TEN: texture encoding network[C]//Proceedings of the 2017 IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2017: 2896-2905. [10] Dosovitskiy A, Beyer L, Kolesnikov A, et al. An image is worth 16×16 words: Transformers for image recognition at scale[EB/OL]. (2021-06-03)[2025-06-20]. https://arxiv.org/abs/2010.11929. [11] Radford A, Kim J W, Hallacy C, et al. Learning transferable visual models from natural language supervision[EB/OL]. (2021-02-26)[2025-06-20]. https://arxiv.org/abs/2103.00020. [12] Dhariwal P, Nichol A. Diffusion models beat GANs on image synthesis[EB/OL]. (2021-06-01)[2025-06-20]. http://arxiv.org/abs/2112.10752. [13] Taupik J, Alamsyah T, Wulandari A, et al. Airport runway foreign object debris (FOD) detection based on YOLOX architecture[C]//Proceedings of the 2023 International Conference on Computer Science, Information Technology and Engineering. Piscataway: IEEE Press, 2023: 40-43. [14] Tian Y, Li Z, Lin Y W, et al. Metal object detection for electric vehicle inductive power transfer systems based on hyperspectral imaging[J]. Measurement, 2021, 168: 108493. [15] Munyer T, Huang P C, Huang C Y, et al. FOD-A: a dataset for foreign object debris in airports[EB/OL]. (2022-01-26)[2025-06-20]. https://arxiv.org/abs/2110.03072. [16] Xu H Y, Han Z Q, Feng S L, et al. Foreign object debris material recognition based on convolutional neural networks[J]. EURASIP Journal on Image and Video Processing, 2018, 2018(1): 21. [17] Barrow H G, Tenenbaum J M. Recovering intrinsic scene characteristics from images[J]. Computer Vision Systems, 1978, 2: 3-26. [18] Liu F T, Ting K M, Zhou Z H. Isolation forest[C]//Proceedings of the 2008 Eighth IEEE International Conference on Data Mining. Piscataway: IEEE Press, 2009: 413-422. [19] Zhou Z W, Rahman Siddiquee M M, Tajbakhsh N, et al. UNet++: a nested U-Net architecture for medical image segmentation[C]//Proceedings of the Deep Learning in Medical Image Analysis and Multimodal Learning for Clinical Decision Support. Berlin: Springer, 2018: 3-11. [20] Ronneberger O, Fischer P, Brox T. U-Net: convolutional networks for biomedical image segmentation[C]//Proceedings of the Medical Image Computing and Computer-Assisted Intervention-MICCAI 2015. Berlin: Springer, 2015: 234-241. [21] Salehi S S M, Erdogmus D, Gholipour A. Tversky loss function for image segmentation using 3D fully convolutional deep networks[C]//Proceedings of the Machine Learning in Medical Imaging. Berlin: Springer, 2017: 379-387. [22] Lin T Y, Goyal P, Girshick R, et al. Focal loss for dense object detection[C]//Proceedings of the 2017 IEEE International Conference on Computer Vision. Piscataway: IEEE Press, 2017: 2999-3007. [23] Long J, Shelhamer E, Darrell T. Fully convolutional networks for semantic segmentation[C]//Proceedings of the 2015 IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2015: 3431-3440. [24] Wang Y, Yang L, Liu X Z, et al. An improved semantic segmentation algorithm for high-resolution remote sensing images based on DeepLabv3+[J]. Scientific Reports, 2024, 14: 9716. [25] Hu J, Shen L, Sun G. Squeeze-and-excitation networks[C]//Proceedings of the 2018 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2018: 7132-7141. [26] Weng W, Zhuo Z, Li H, et al. Semantic segmentation of remote sensing images based on dilated convolution and SegNet[J]. Journal of Applied Remote Sensing, 2020, 14(4): 046511. [27] Tao C X, Meng Y Z, Li J J, et al. MSNet: multispectral semantic segmentation network for remote sensing images[J]. GIScience & Remote Sensing, 2022, 59(1): 1177-1198. [28] Zhong Y F, Zhang L P, Huang B, et al. A spectral-spatial Transformer network for hyperspectral image classification[J]. IEEE Transactions on Geoscience and Remote Sensing, 2024, 62: 1-14 . [29] Wang L B, Li R, Zhang C, et al. UNetFormer: a UNet-like Transformer for efficient semantic segmentation of remote sensing urban scene imagery[J]. ISPRS Journal of Photogrammetry and Remote Sensing, 2022, 190: 196-214. -

 下载:

 点击查看大图
计量
- 文章访问数: 219
- HTML全文浏览量: 85
- PDF下载量: 21
- 被引次数: 0
