


Capacity model and collaborative scheduling of droneports for drone regional logistics
-
摘要:
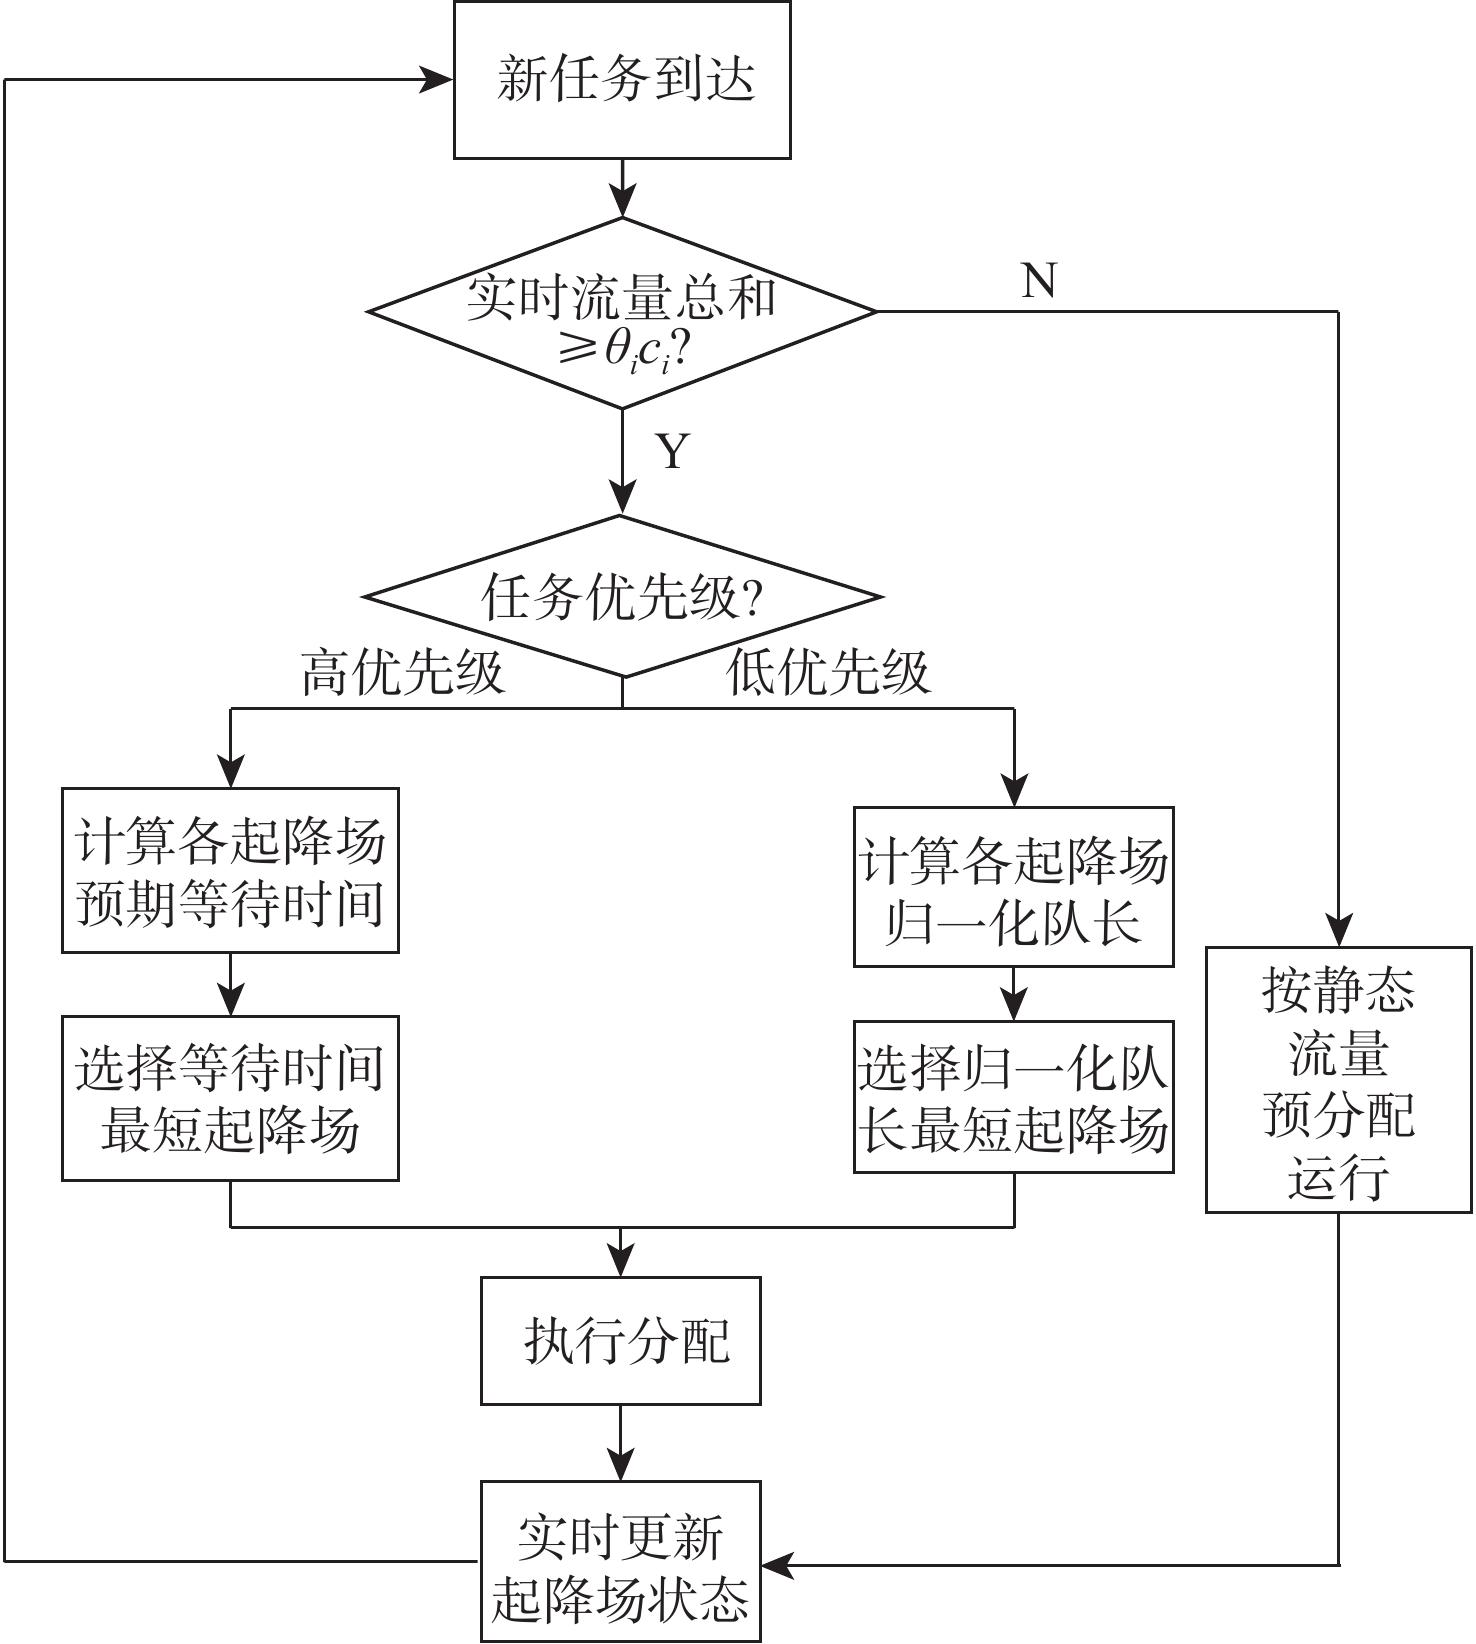
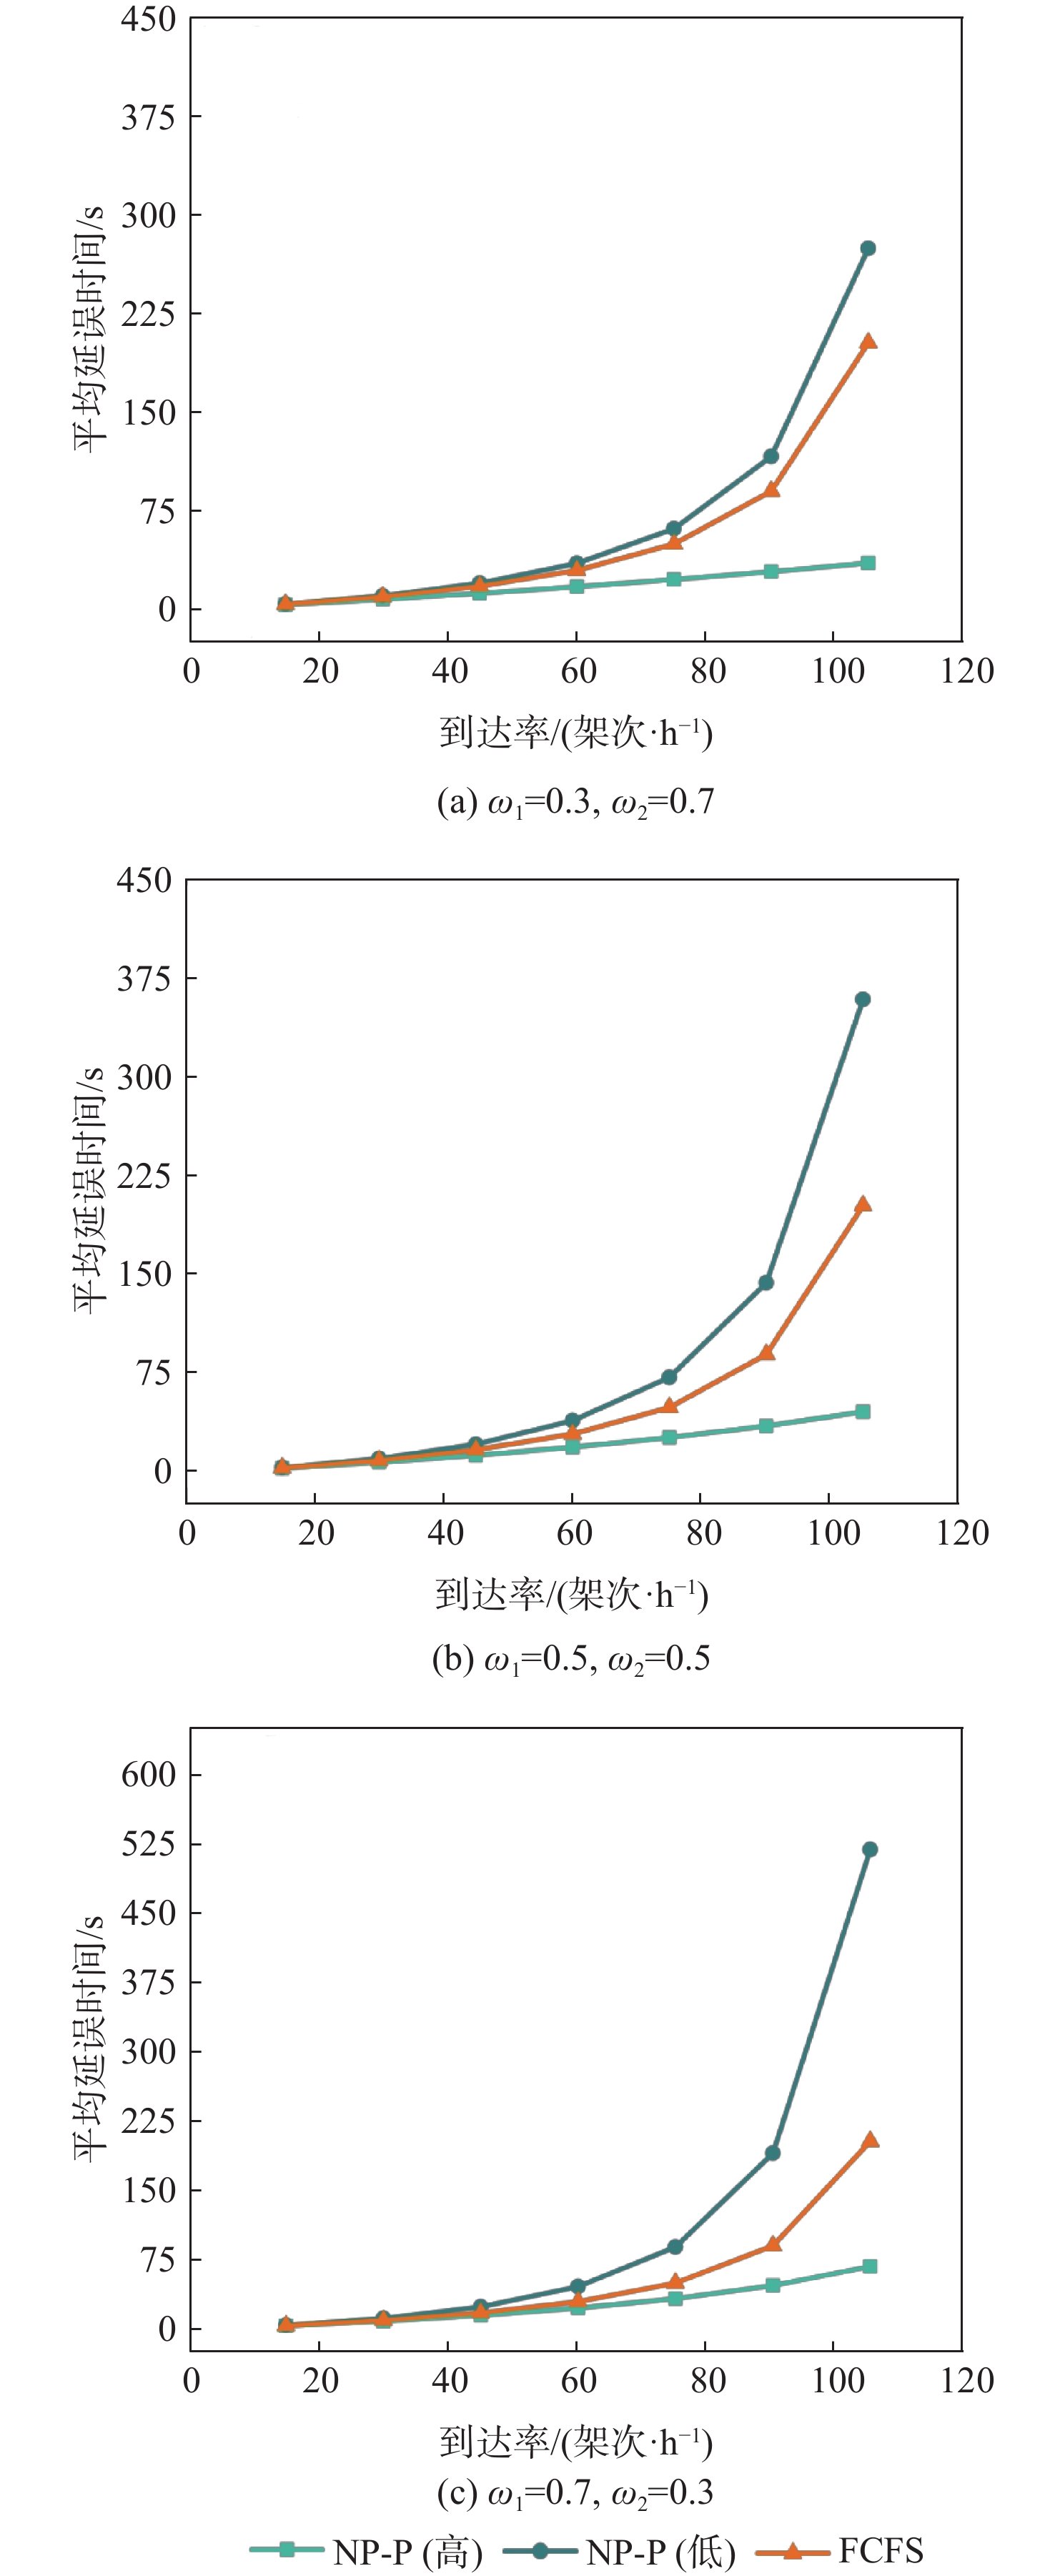
针对公共垂直起降场终端区空域资源紧张与运行效率不足的问题,考虑多场站协同调度机制缺失及支线物流区域的负载均衡性需求,以精准评估容量和优化区域协同调度能力为目标,提出一种串联耦合排队模型与静动态协同调度策略。构建差异化排队模型,刻画各环节阻塞效应,突破传统独立分析局限;在降落排队系统中引入非抢占式优先级策略,保障高优先级任务;设计“静态流量预分配+动态容流调配”策略,通过基于排队论的双路径决策实现多场站协同。仿真结果表明:所提串联耦合排队模型的整体容量评估偏差控制在6%以内,显著优于传统独立分析模型,且在等待层空域容量评估中,同样显著优于基于冲突阈值的模型;非抢占式优先级策略下,高优先级任务平均延误时间始终低于30 s,但随其在总任务中占比的增加,系统平均延误显著上升;静动态协同调度策略在突发流量下使区域负载均衡度提升至95.9%,无人机总延误时间平均减少39.49%。研究成果可为低空物流网络规划与实时调度提供理论支撑。
Abstract:Droneport terminal airspace faces the critical issues of scarce airspace resources and insufficient operational efficiency. A series-coupled queuing model and a static-dynamic collaborative scheduling strategy are established to achieve accurate capacity assessment and effective regional collaborative scheduling, taking into account the lack of collaborative scheduling mechanisms for multiple droneports and the need for load balancing in regional logistics areas. First, a differentiated queuing model is constructed to characterize blockage effects in each operational link, breaking through the limitations of traditional independent analysis. Second, a non-preemptive priority strategy is introduced into the landing system to safeguard high-priority tasks. Finally, a "static flow pre-allocation + dynamic capacity-flow regulation" mechanism is designed to achieve multi-droneport collaboration through dual-path decision-making based on queuing theory. The static results show that the overall capacity assessment deviation of the proposed series-coupled queuing model is controlled within 6%, which is significantly superior to the traditional independent analysis model. Moreover, in the capacity assessment of the waiting layer airspace, it also significantly outperforms the conflict threshold-based model. Under the non-preemptive priority strategy, the average delay time of high-priority tasks consistently stays below 30 seconds. However, with the increase in their proportion of total tasks, the system’s average delay rises significantly. Under surge traffic conditions, the cooperative scheduling approach lowers overall drone delay by 39.49% on average and increases regional load balance to 95.9%. The research results can provide theoretical support for low-altitude logistics network planning and real-time dispatch.
-
Key words:
- drone /
- regional logistics /
- droneport /
- queueing theory /
- capacity evaluation /
- collaborative scheduling
-
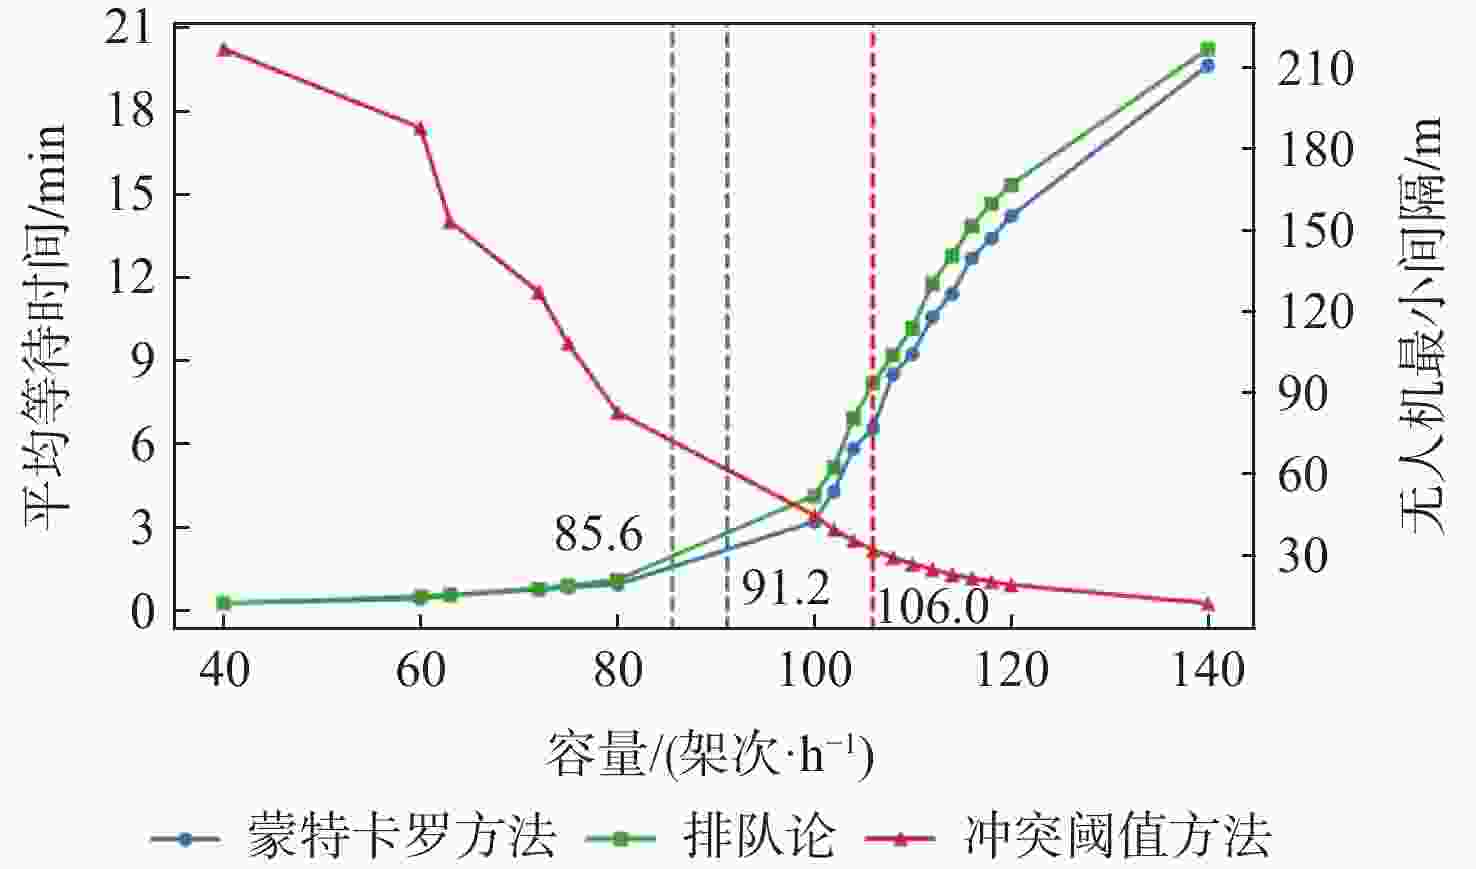
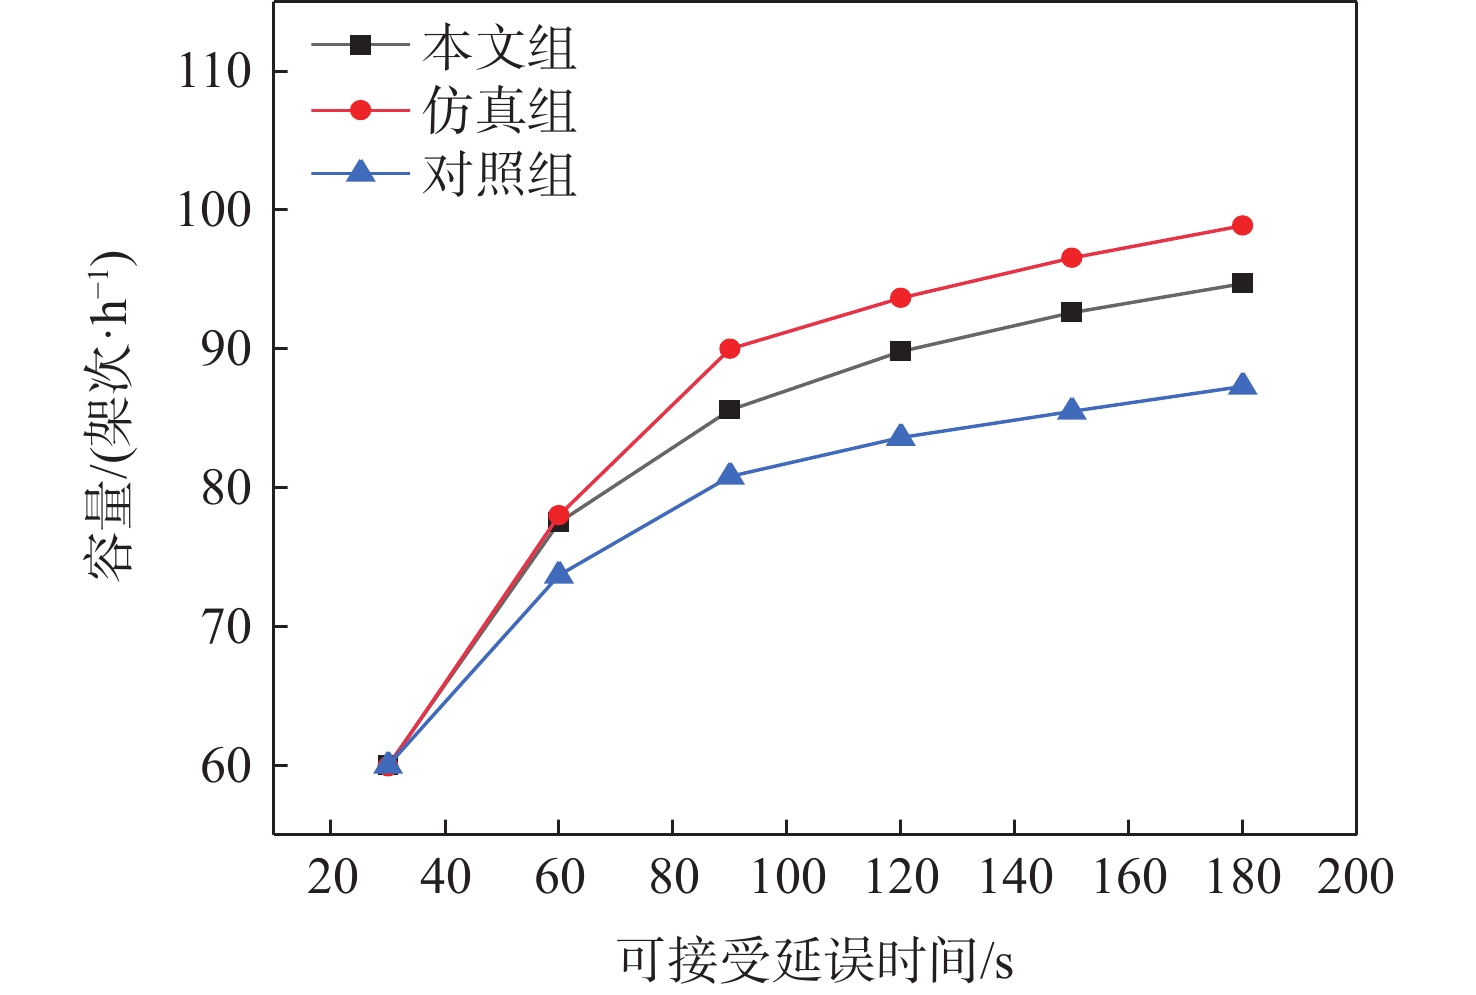
图 5 3种不同策略下的容量变化曲线
Figure 5. Capacity variation curves under three different strategies
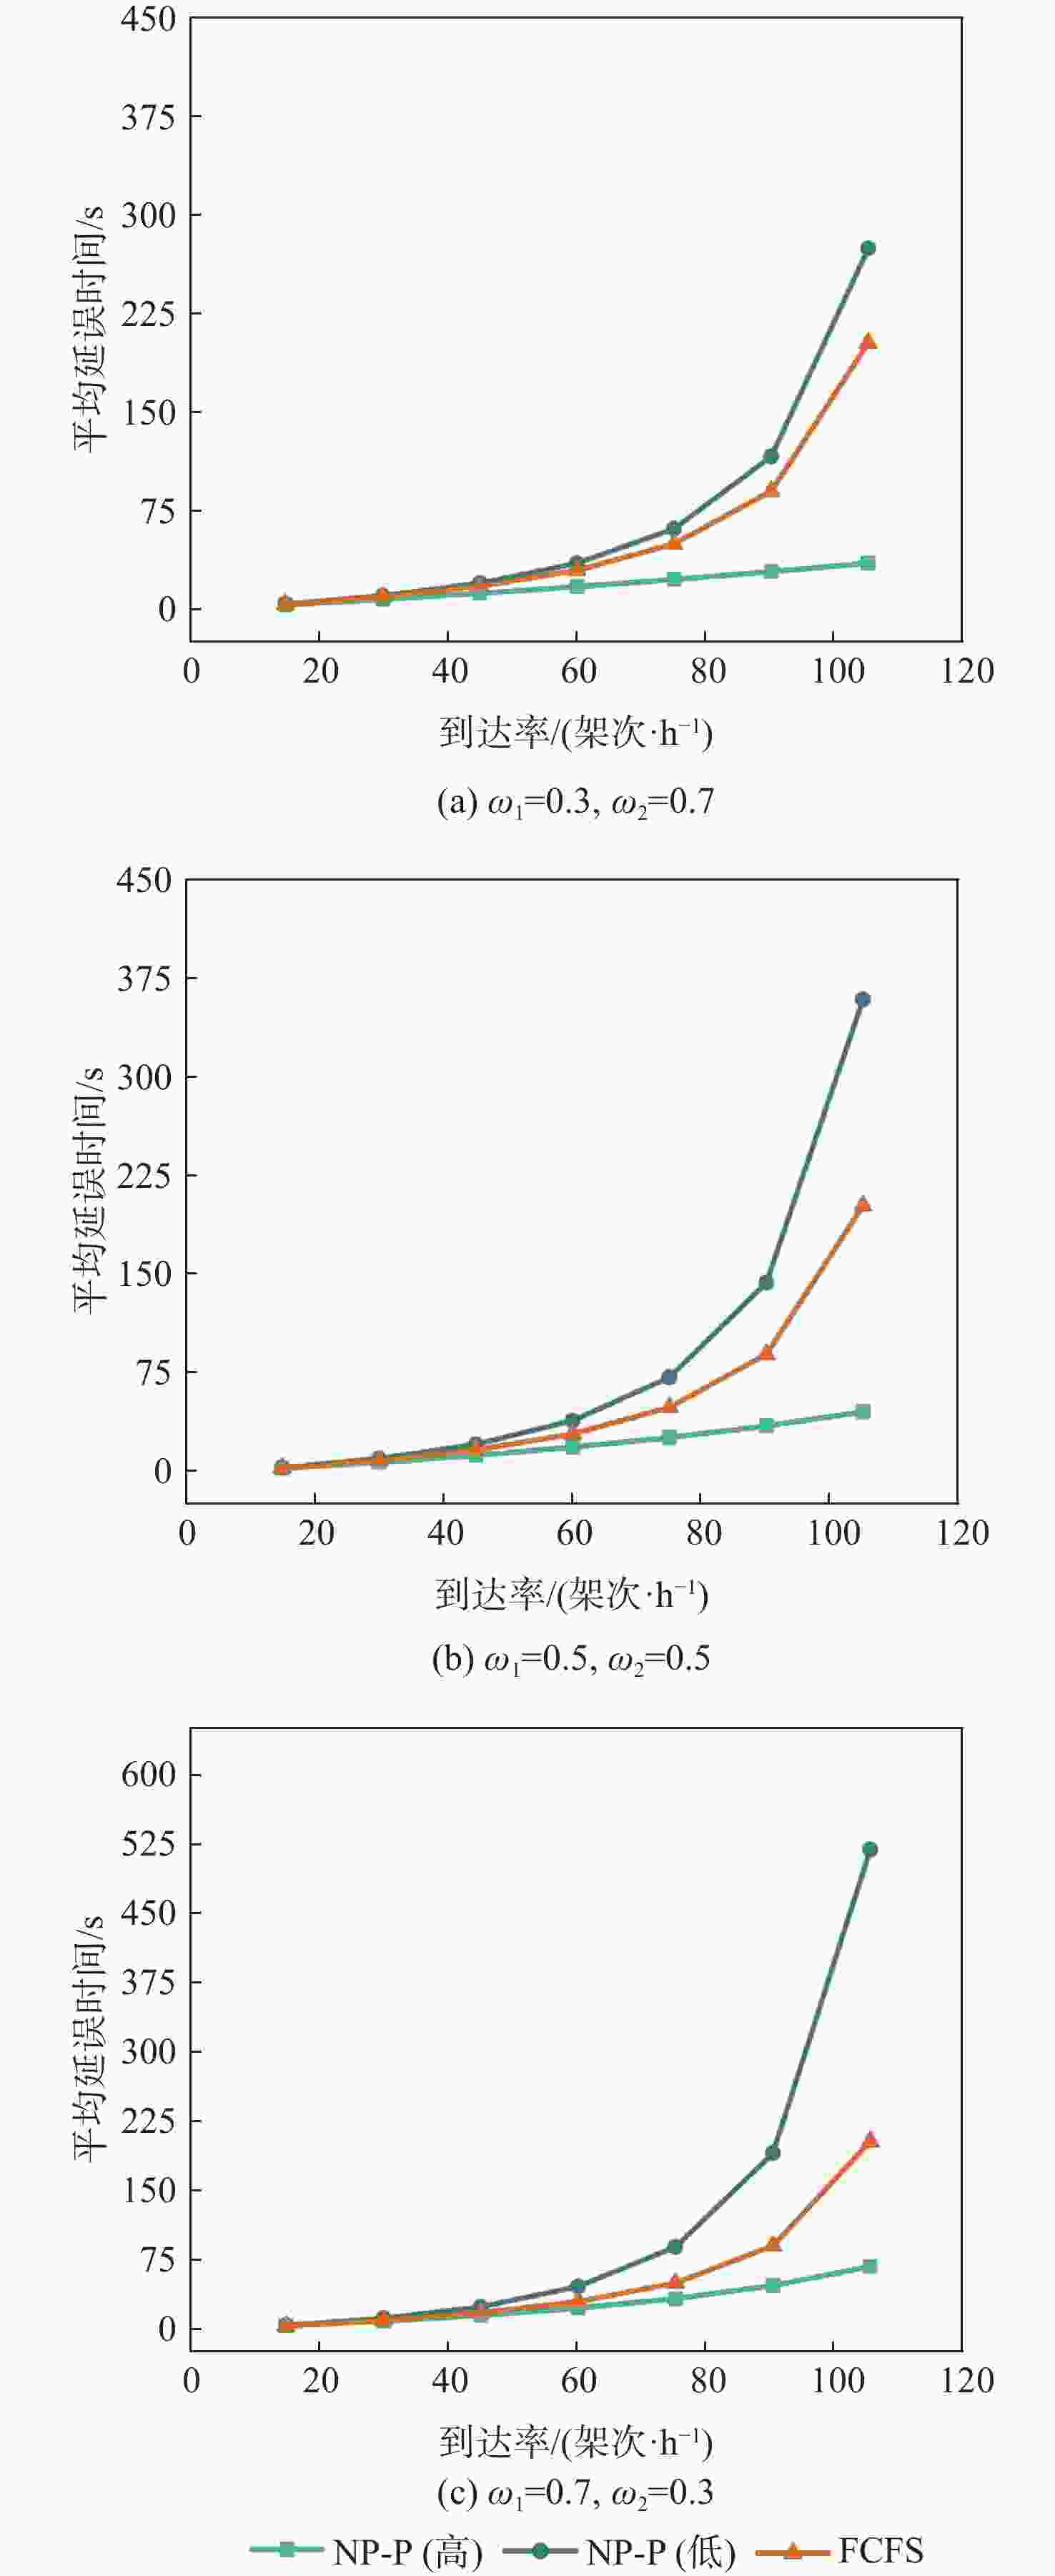
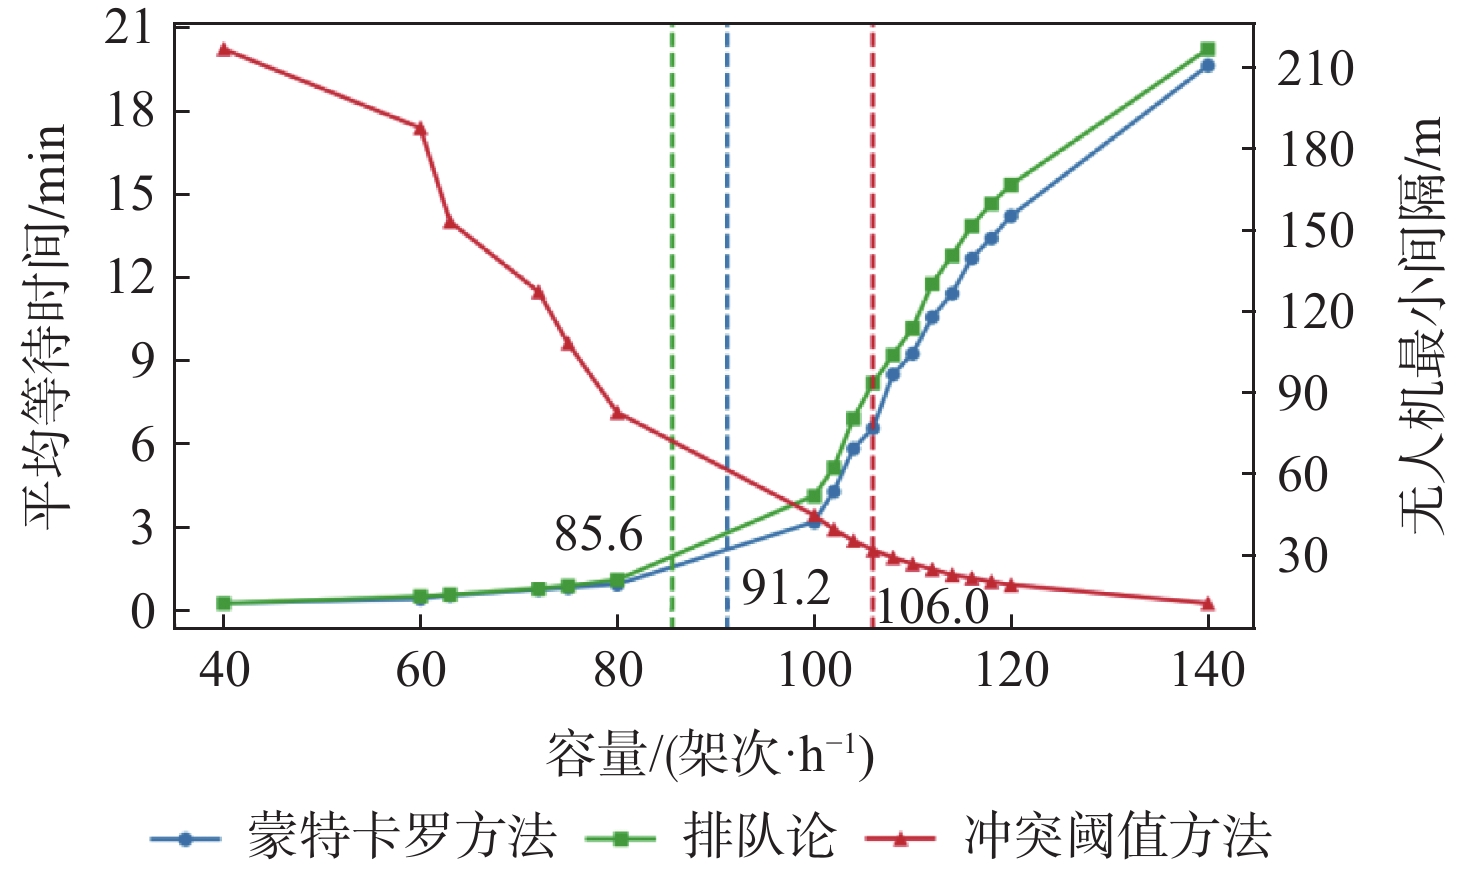
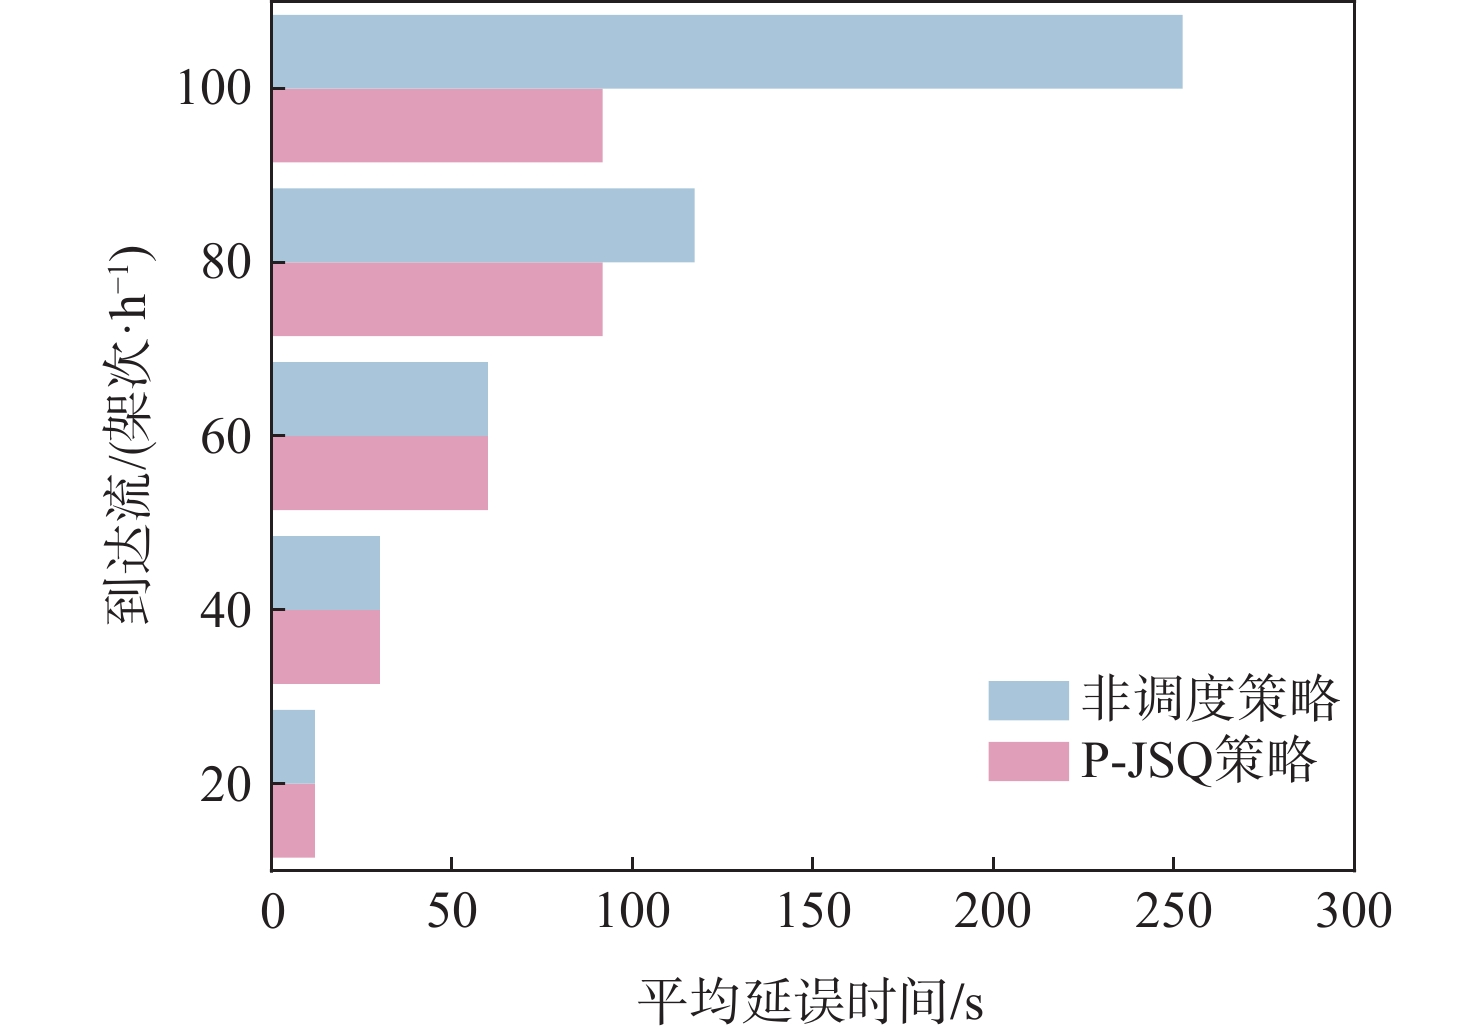
图 6 2种策略下的无人机平均延误时间曲线
Figure 6. Curves of average waiting duration of drones under two strategies
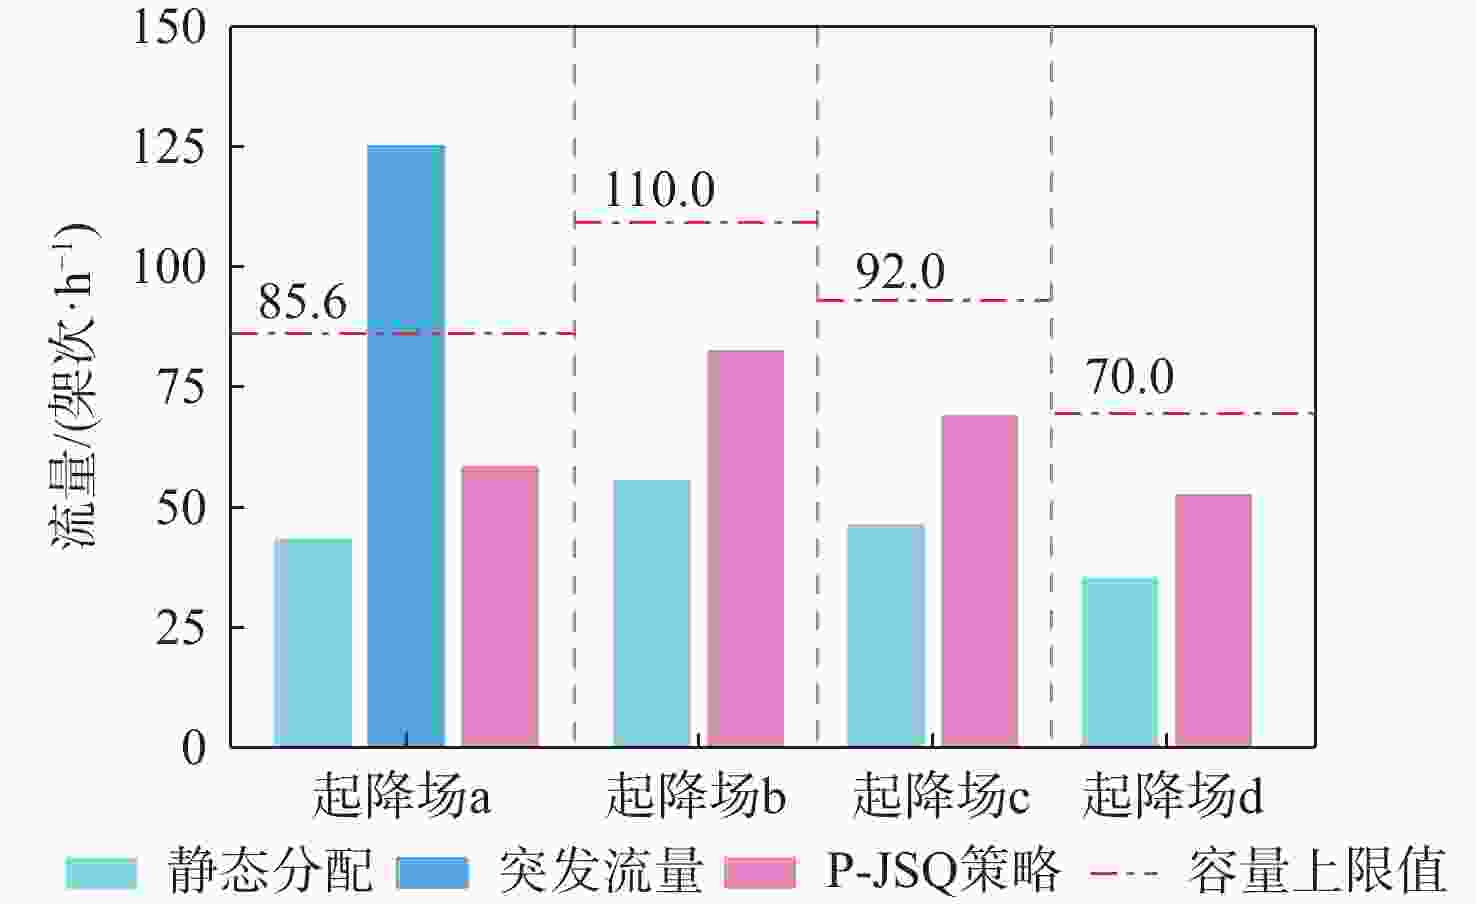
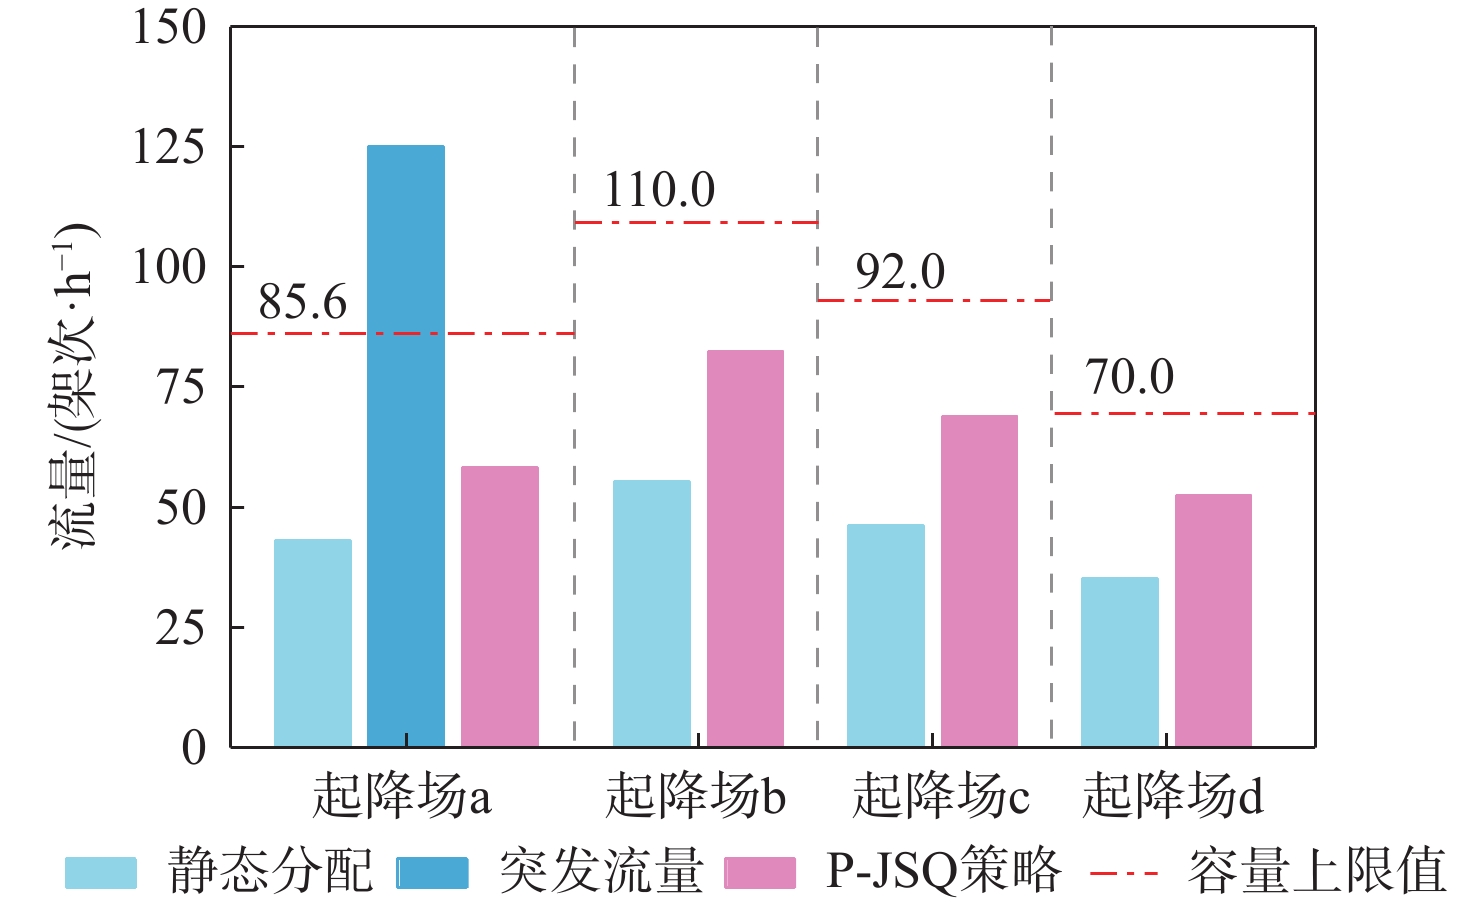
图 7 物流波次性突发需求下的多起降场协同调度
Figure 7. Multi-droneport coordinated scheduling under logistic wave-like sudden demands
表 1 本文在不同延时条件下的各排队系统容量
Table 1. Capacity of each queuing system under different delays in this research
可接受延误时间/s 容量/(架次·h−1) 降落 地面 起飞 30 60.0 68.8 61.1 60 77.5 84.6 86.0 90 85.6 95.4 105.0 120 89.8 115.2 115.0 150 92.6 129.6 119.4 180 94.7 155.4 120.0  下载: 导出CSV
表 2 对照组在不同延时条件下的各排队系统容量
Table 2. Capacity of each queuing system under different delays in control group
可接受延误时间/s 容量/(架次·h−1) 降落 地面 起飞 30 60.0 64.6 61.1 60 79.8 73.7 86.0 90 90.0 80.8 105.0 120 96.0 83.6 115.0 150 100.2 85.5 119.4 180 102.8 87.3 120.0
下载: 导出CSV
表 3 起降场终端区静态流量预分配
Table 3. Droneport terminal area static flow pre-allocation
架次/h 起降场 高优先级
任务总量低优先级
任务总量预分配任
务总量实际容量 起降场a 13.0 30.0 43.0 85.6 起降场b 17.0 39.0 56.0 110.0 起降场c 14.0 32.0 46.0 92.0 起降场d 10.0 25.0 35.0 70.0
下载: 导出CSV
-
[1] 中国民用航空局. 民航局颁发支线物流无人机商业试运行牌照[EB/OL]. (2022-01-25)[2025-04-17]. https://www.caac.gov.cn/XW-ZX/MHYW/202201/t20220125_211269.html.Civil Aviation Administration of China. CAAC issues commercial trial operation license for regional logistics drones[EB/OL]. (2022-01-25)[2025-04-17]. https://www.caac.gov.cn/XWZX/MHYW/202201/t20220125_211269.html(in Chinese). [2] 中国民用航空局. 民航局关于印发《“十四五”通用航空发展专项规划》的通知[EB/OL]. (2022-06-13)[2025-04-17]. https://www.caac.gov.cn/XXGK/XXGK/FZGH/202206/t20220613_213643.html.Civil Aviation Administration of China. Notice of the CAAC on issuing the "14th Five-Year Plan" special plan for general aviation development[EB/OL]. (2022-06-13) [2025-04-17]. https://www.caac.gov.cn/XXGK/XXGK/FZGH/202206/t20220613_213643.html(in Chinese). [3] 郑文娟. 低空物流发展前景与建议[J]. 空运商务, 2025(3): 16-21.Zheng W J. Development prospect and suggestion of low-altitude logistics[J]. Air Transport & Business, 2025(3): 16-21(in Chinese). [4] 许建华, 李权. 支线货运无人机的发展现状、运行方式与关键技术分析[J]. 航空工程进展, 2022, 13(4): 1-10.Xu J H, Li Q. Development, running mode and key technologies analysis of regional cargo drones[J]. Advances in Aeronautical Science and Engineering, 2022, 13(4): 1-10(in Chinese). [5] 袁于斐. 基于主从模式的支线-末端无人机协同物流调度方法研究[D]. 长沙: 中南大学, 2023: 22-23.Yuan Y F. Research on the method for logistics scheduling of collaborative feeder-end UAV based on master-slave mode[D]. Changsha: Central South University, 2023: 22-23(in Chinese) . [6] 张洪海, 夷珈, 李姗, 等. 低空空域容量评估研究综述[J]. 交通运输工程学报, 2023, 23(6): 78-93.Zhang H H, Yi J, Li S, et al. Review on research of low-altitude airspace capacity evaluation[J]. Journal of Traffic and Transportation Engineering, 2023, 23(6): 78-93(in Chinese). [7] Zhang H H, Fei Y H, Li J Y, et al. Method of vertiport capacity assessment based on queuing theory of unmanned aerial vehicles[J]. Sustainability, 2023, 15(1): 709. [8] Guerreiro N M, Hagen G E, Maddalon J M, et al. Capacity and throughput of urban air mobility vertiports with a first-come, first-served vertiport scheduling algorithm[C]//Proceedings of the AIAA Aviation 2020 Forum. Reston: AIAA, 2020: 2903. [9] Bulusu V, Polishchuk V, Sengupta R, et al. Capacity estimation for low altitude airspace[C]//Proceedings of the 17th AIAA Aviation Technology, Integration, and Operations Conference. Reston: AIAA, 2017: 4266. [10] 赵嶷飞, 张志玮. 基于冲突阈值的城市物流无人机空域容量评估[J]. 中国民航大学学报, 2021, 39(5): 1-6.Zhao Y F, Zhang Z W. Estimation of urban logistics UAV airspace capacity based on conflict threshold[J]. Journal of Civil Aviation University of China, 2021, 39(5): 1-6(in Chinese). [11] Hoekstra J M, Ellerbroek J, Sunil E, et al. Geovectoring: reducing traffic complexity to increase the capacity of UAV airspace[C]//Proceedings of the International Conference for Research in Air Transportation. Barcelona: ICRAT, 2018: 1-8. [12] Barnhart C, Bertsimas D, Caramanis C, et al. Equitable and efficient coordination in traffic flow management[J]. Transportation Science, 2012, 46(2): 262-280. [13] Jacquillat A, Odoni A R. Endogenous control of service rates in stochastic and dynamic queuing models of airport congestion[J]. Transportation Research Part E: Logistics and Transportation Review, 2015, 73: 133-151. [14] Chevalley E, Parke B, Kraut J, et al. Scheduling and delivering aircraft to departure fixes in the NY metroplex with controller-managed spacing tools: AIAA 2015-2428[R]. Reston: AIAA, 2015. [15] 万旅, 邵荃. 基于双层遗传编码的多机场航班调度优化研究[J]. 航空计算技术, 2023, 53(5): 39-43.Wan L, Shao Q. Research on multi-airport flight scheduling optimization based on two-layer coding genetic algorithm[J]. Aeronautical Computing Technique, 2023, 53(5): 39-43(in Chinese). [16] Chen S, Wei P, Krois P, et al. Arrival management for high-density vertiport and terminal airspace operations[C]//Proceedings of the 2023 Air Traffic Control Association Annual Conference. Washington, D. C.: Air Traffic Control Association, 2023. [17] 常静, 张启钱, 张洪海, 等. 城市物流无人机起飞时刻排序问题研究[J]. 武汉理工大学学报(交通科学与工程版), 2024, 48(3): 435-440.Chang J, Zhang Q Q, Zhang H H, et al. Research on the scheduling problem of urban logistics UAV’s take-off time[J]. Journal of Wuhan University of Technology (Transportation Science & Engineering), 2024, 48(3): 435-440(in Chinese). [18] 张洪海, 任真苹, 冯讴歌, 等. 城市低空物流无人机飞行计划预先调配[J]. 系统工程与电子技术, 2023, 45(9): 2802-2811.Zhang H H, Ren Z P, Feng O G, et al. Logistics unmanned aerial vehicle flight plan pre-allocation in urban low-altitude airspace[J]. Systems Engineering and Electronics, 2023, 45(9): 2802-2811(in Chinese). [19] Zheng Y, Li D, Shen Z, et al. Optimized airspace structures and sequencing method for urban logistics droneport[J]. Aerospace, 2025, 12(3): 257. [20] Bulusu V, Polishchuk V. A threshold based airspace capacity esti-mation method for UAS traffic management[C]//Proceedings of the Annual IEEE International Systems Conference. Piscataway: IEEE Press, 2017: 1-7. [21] 陆传赉. 排队论[M]. 北京: 北京邮电学院出版社, 1994.Lu C L. Queueing theory[M]. Beijing: Beijing Institute of Posts and Telecommunications Press, 1994(in Chinese). [22] Cui Q Q, Liu M, Huang X Y, et al. Coarse-to-fine visual autono-mous unmanned aerial vehicle landing on a moving platform[J]. Biomimetic Intelligence and Robotics, 2023, 3(1): 100088. [23] Xie H, Ji X H, Yin J N, et al. Standardization of safety separation for multi-category unmanned aerial vehicles in low-altitude airspace operations[J]. Applied Sciences, 2025, 15(13): 7501. [24] 刘聪, 孟庆昆, 张宗卫. 小型四旋翼无人机悬停状态气动干扰与安全间隔研究[J]. 中国安全生产科学技术, 2022, 18(11): 177-183.Liu C, Meng Q K, Zhang Z W. Research on aerodynamic interaction and safety separation of small quadcopter under hovering state[J]. Journal of Safety Science and Technology, 2022, 18(11): 177-183(in Chinese). -

 下载:

 点击查看大图
计量
- 文章访问数: 373
- HTML全文浏览量: 223
- PDF下载量: 7
- 被引次数: 0
