


Object detection method for anti-UAV systems in complex backgrounds based on YOLOv11-drone
-
摘要:
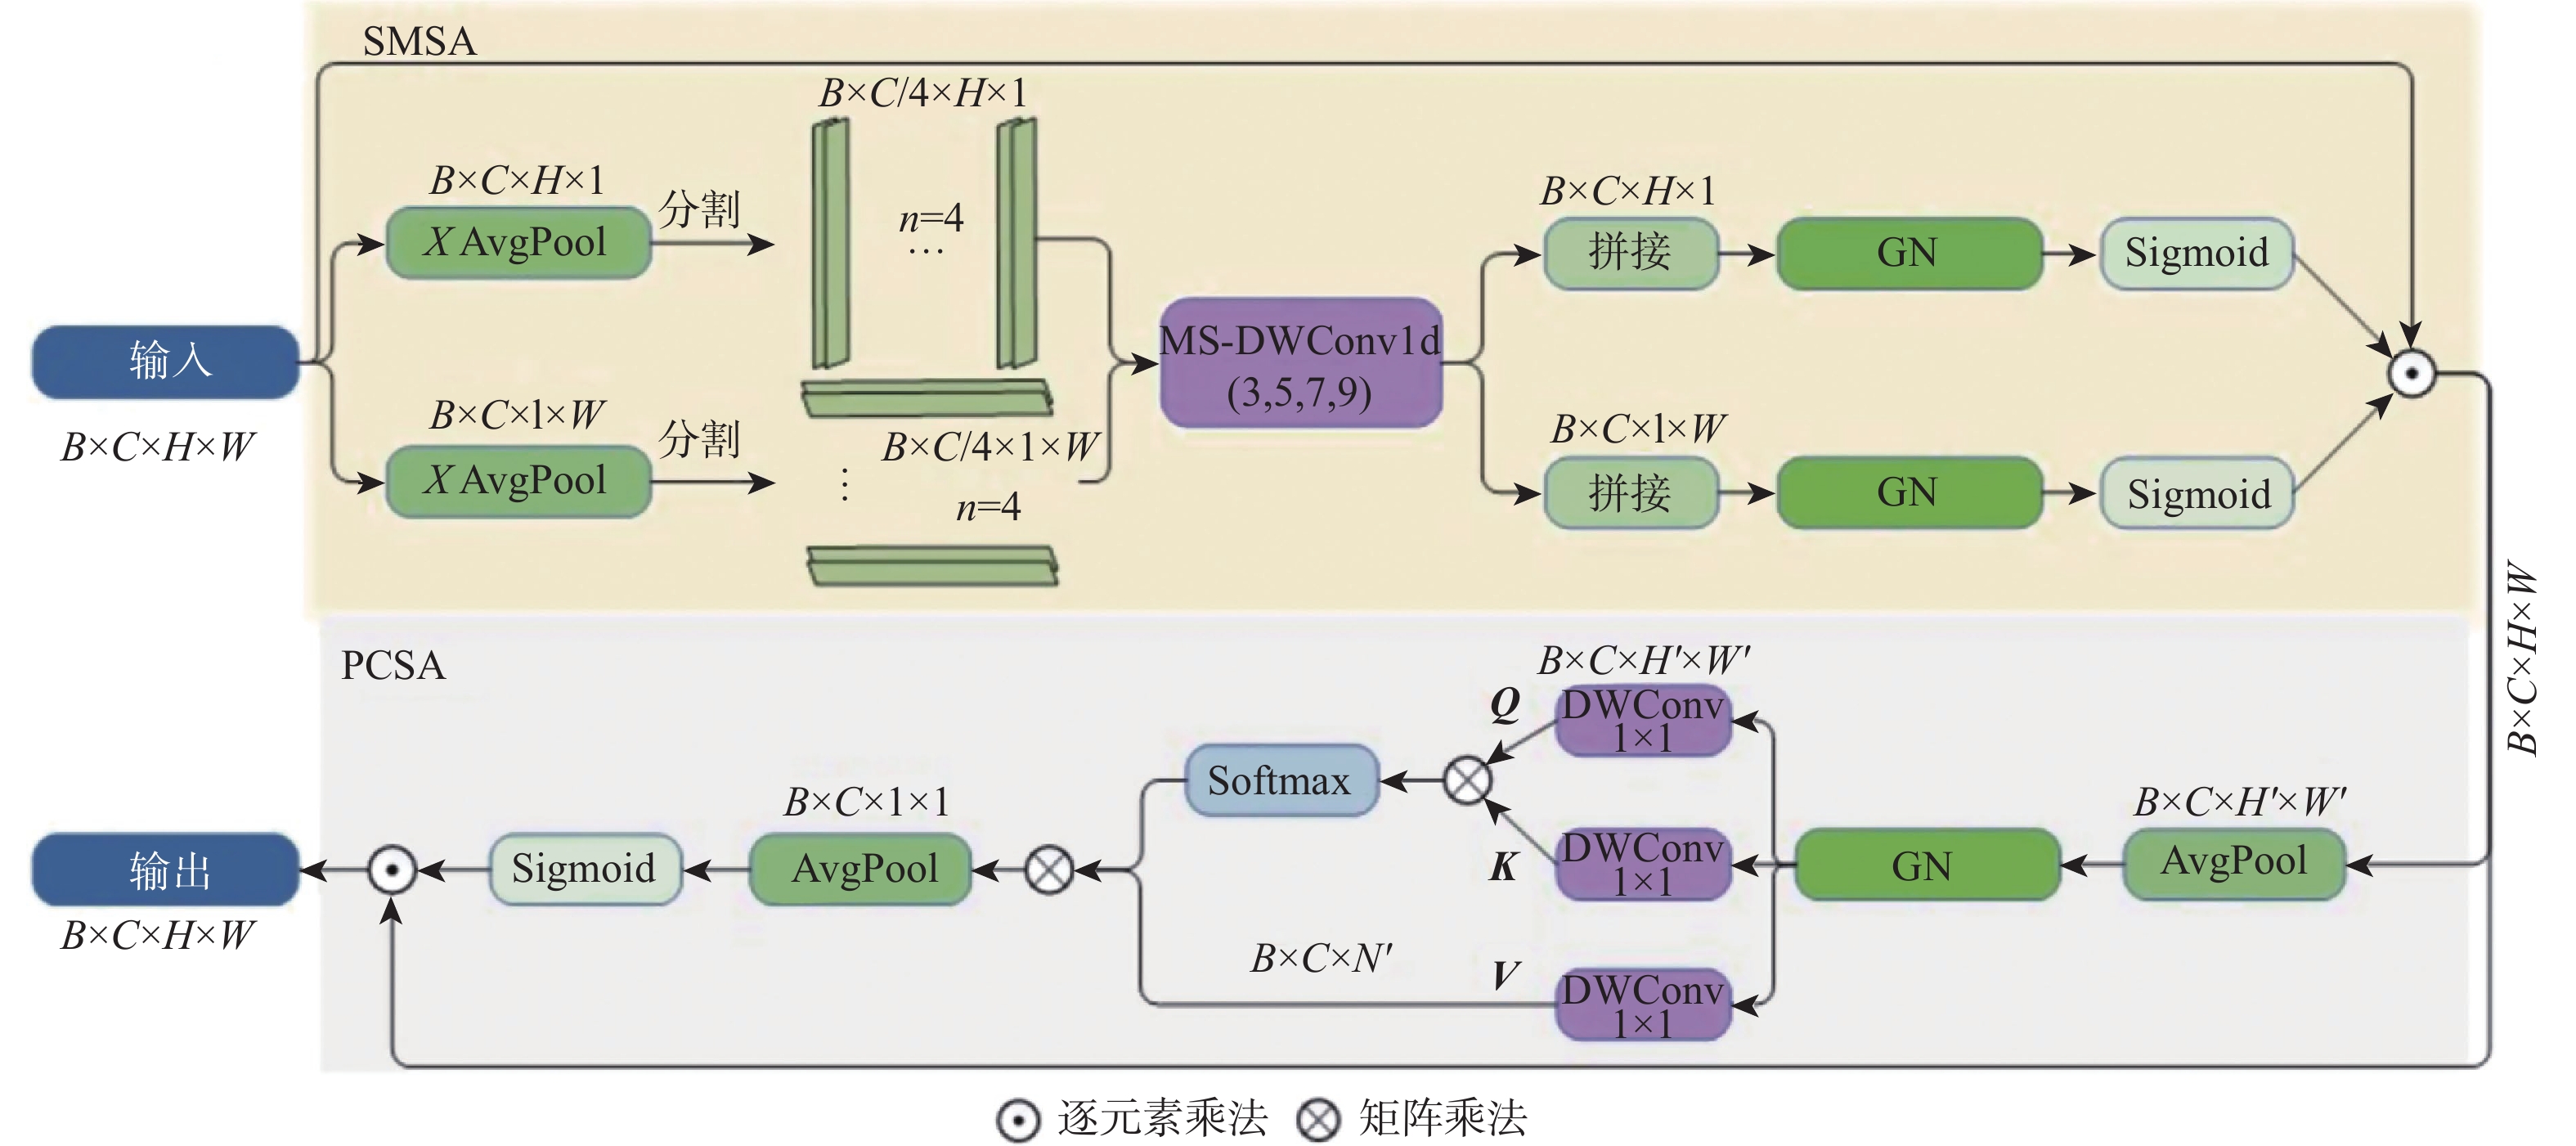
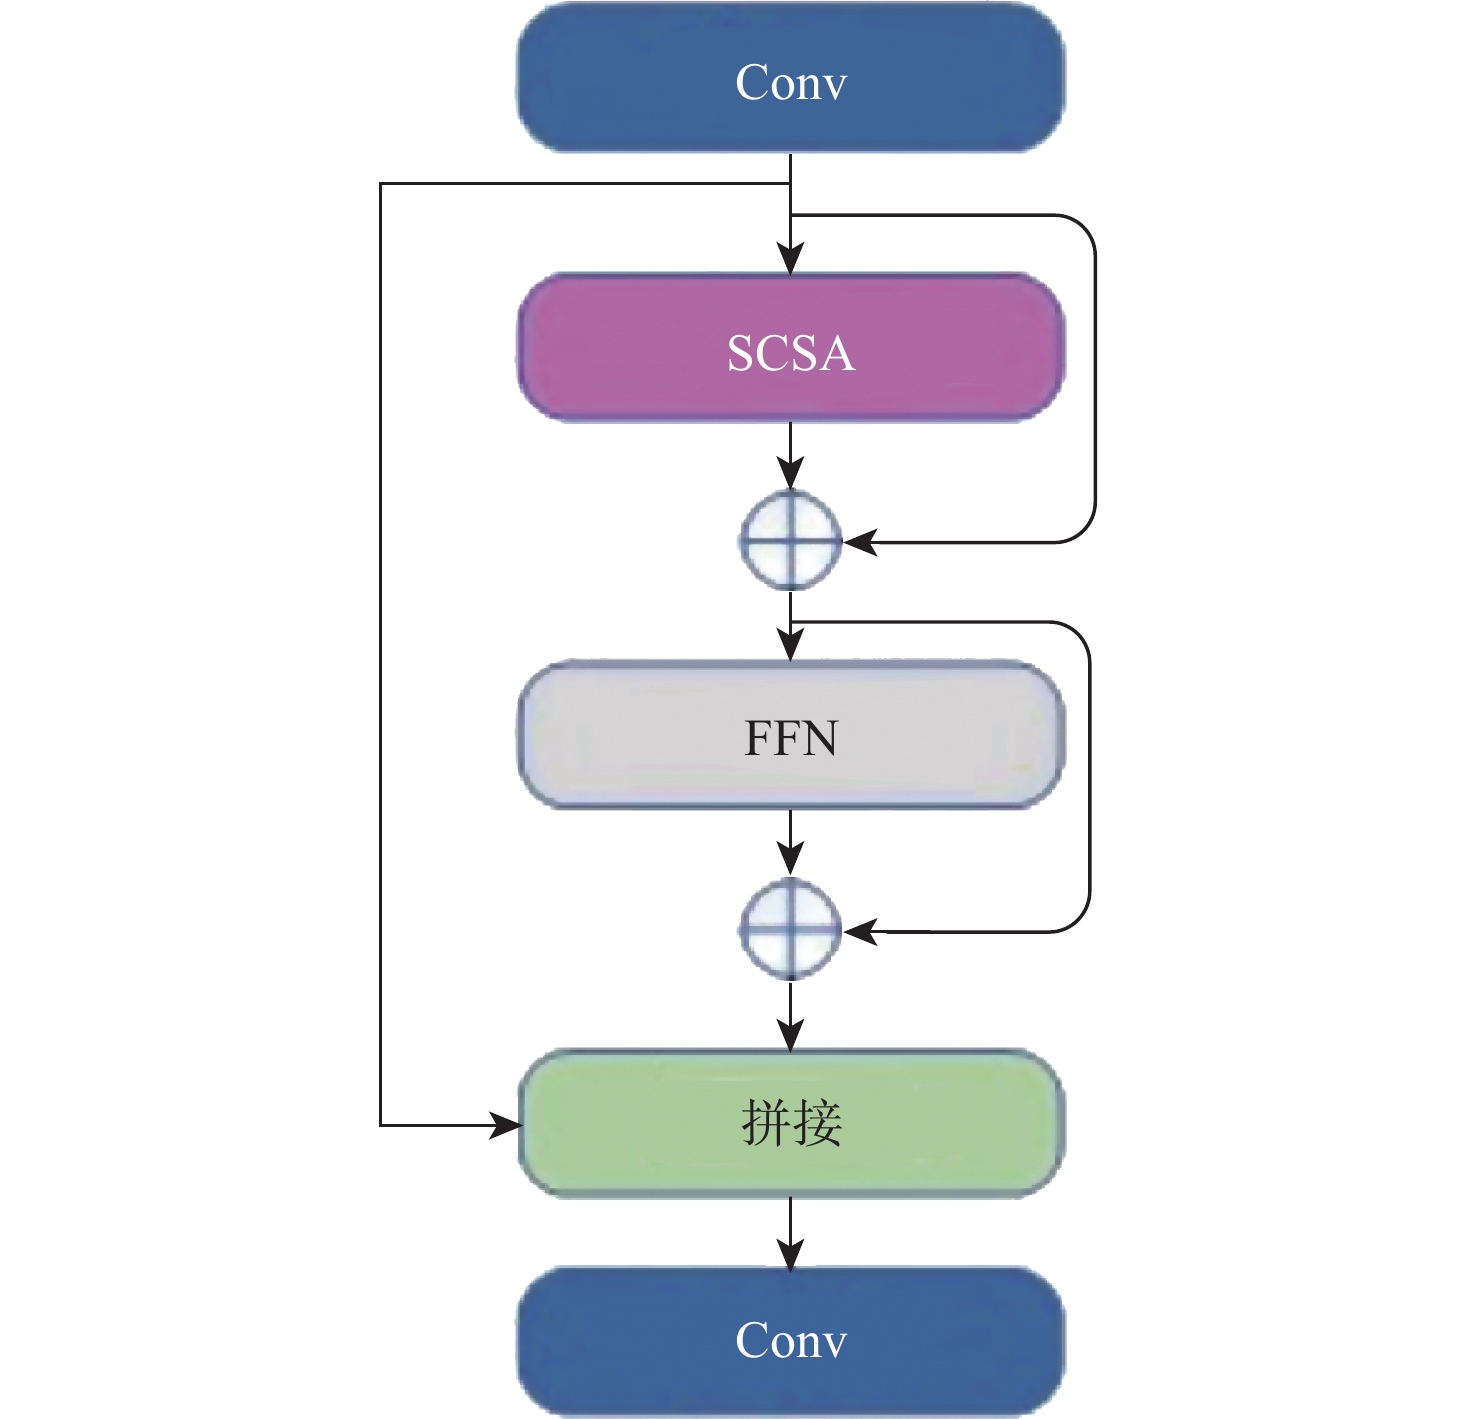
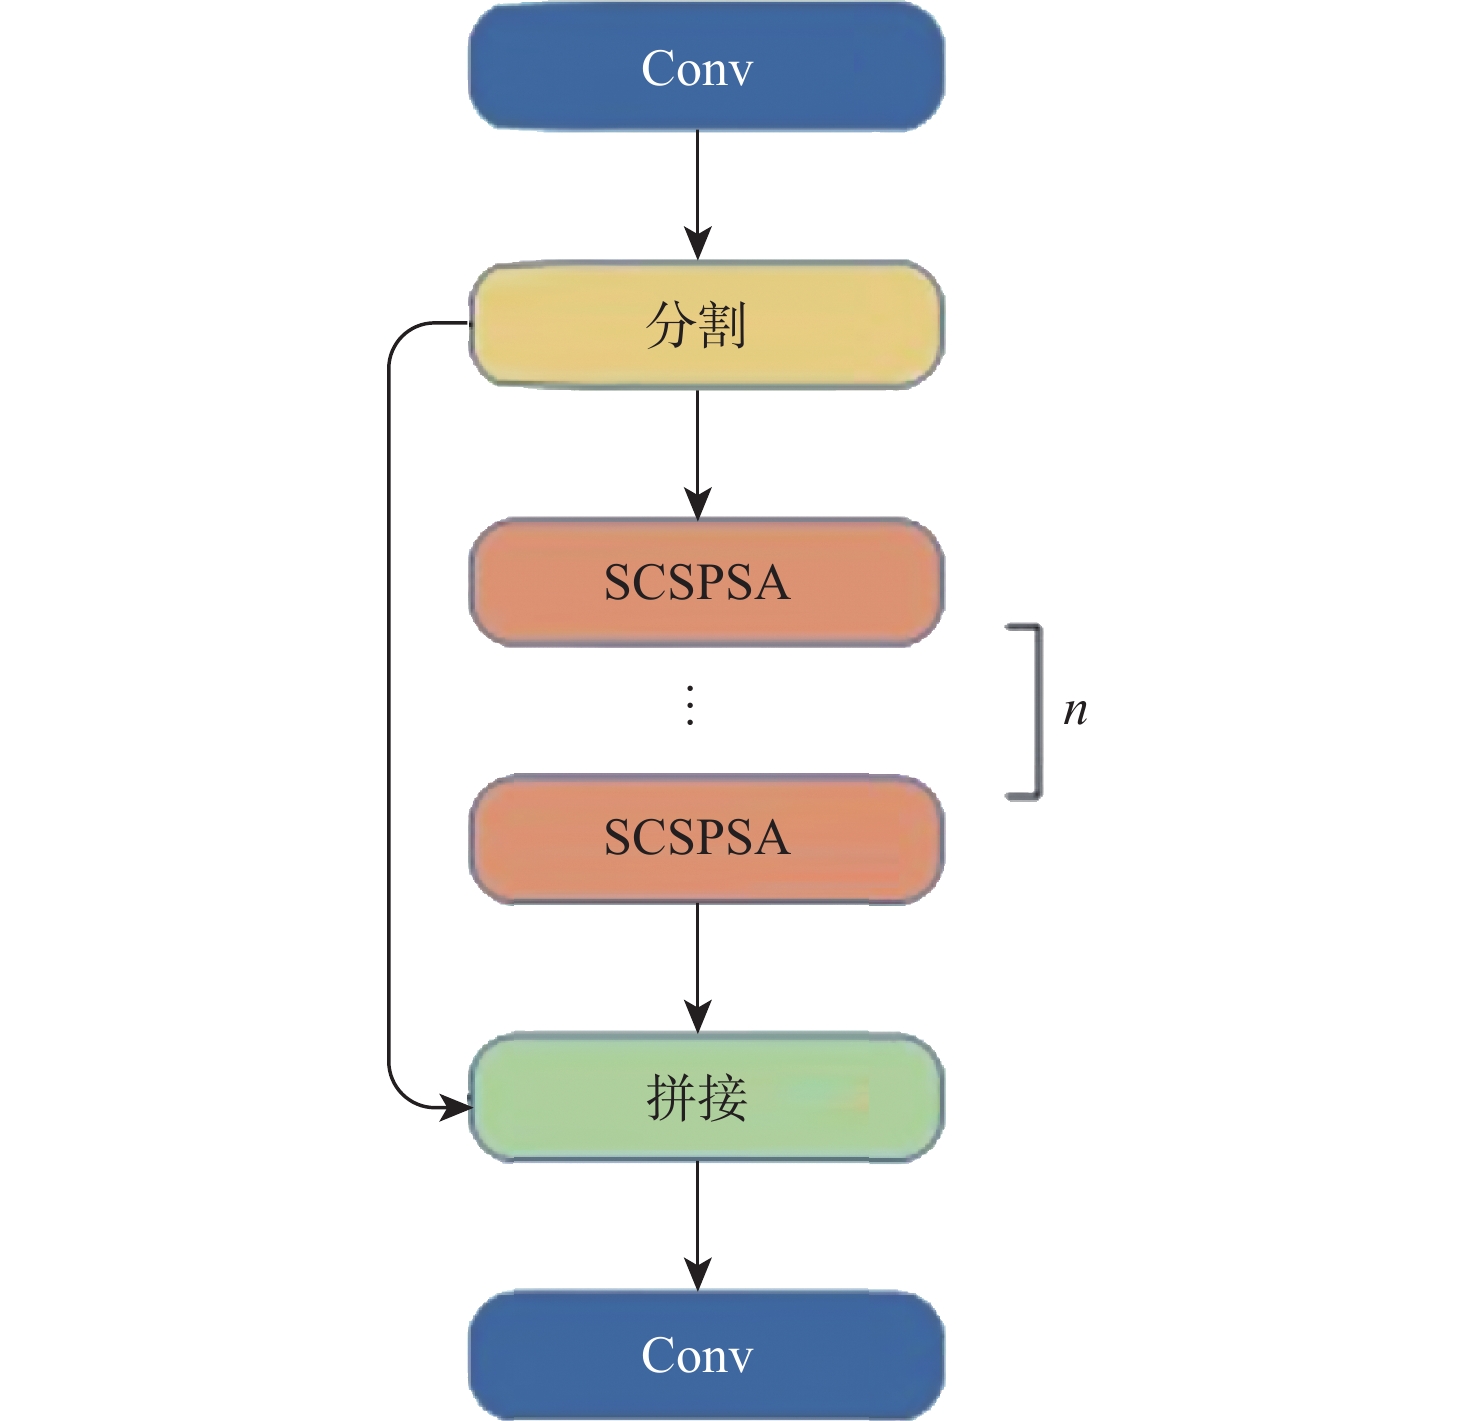
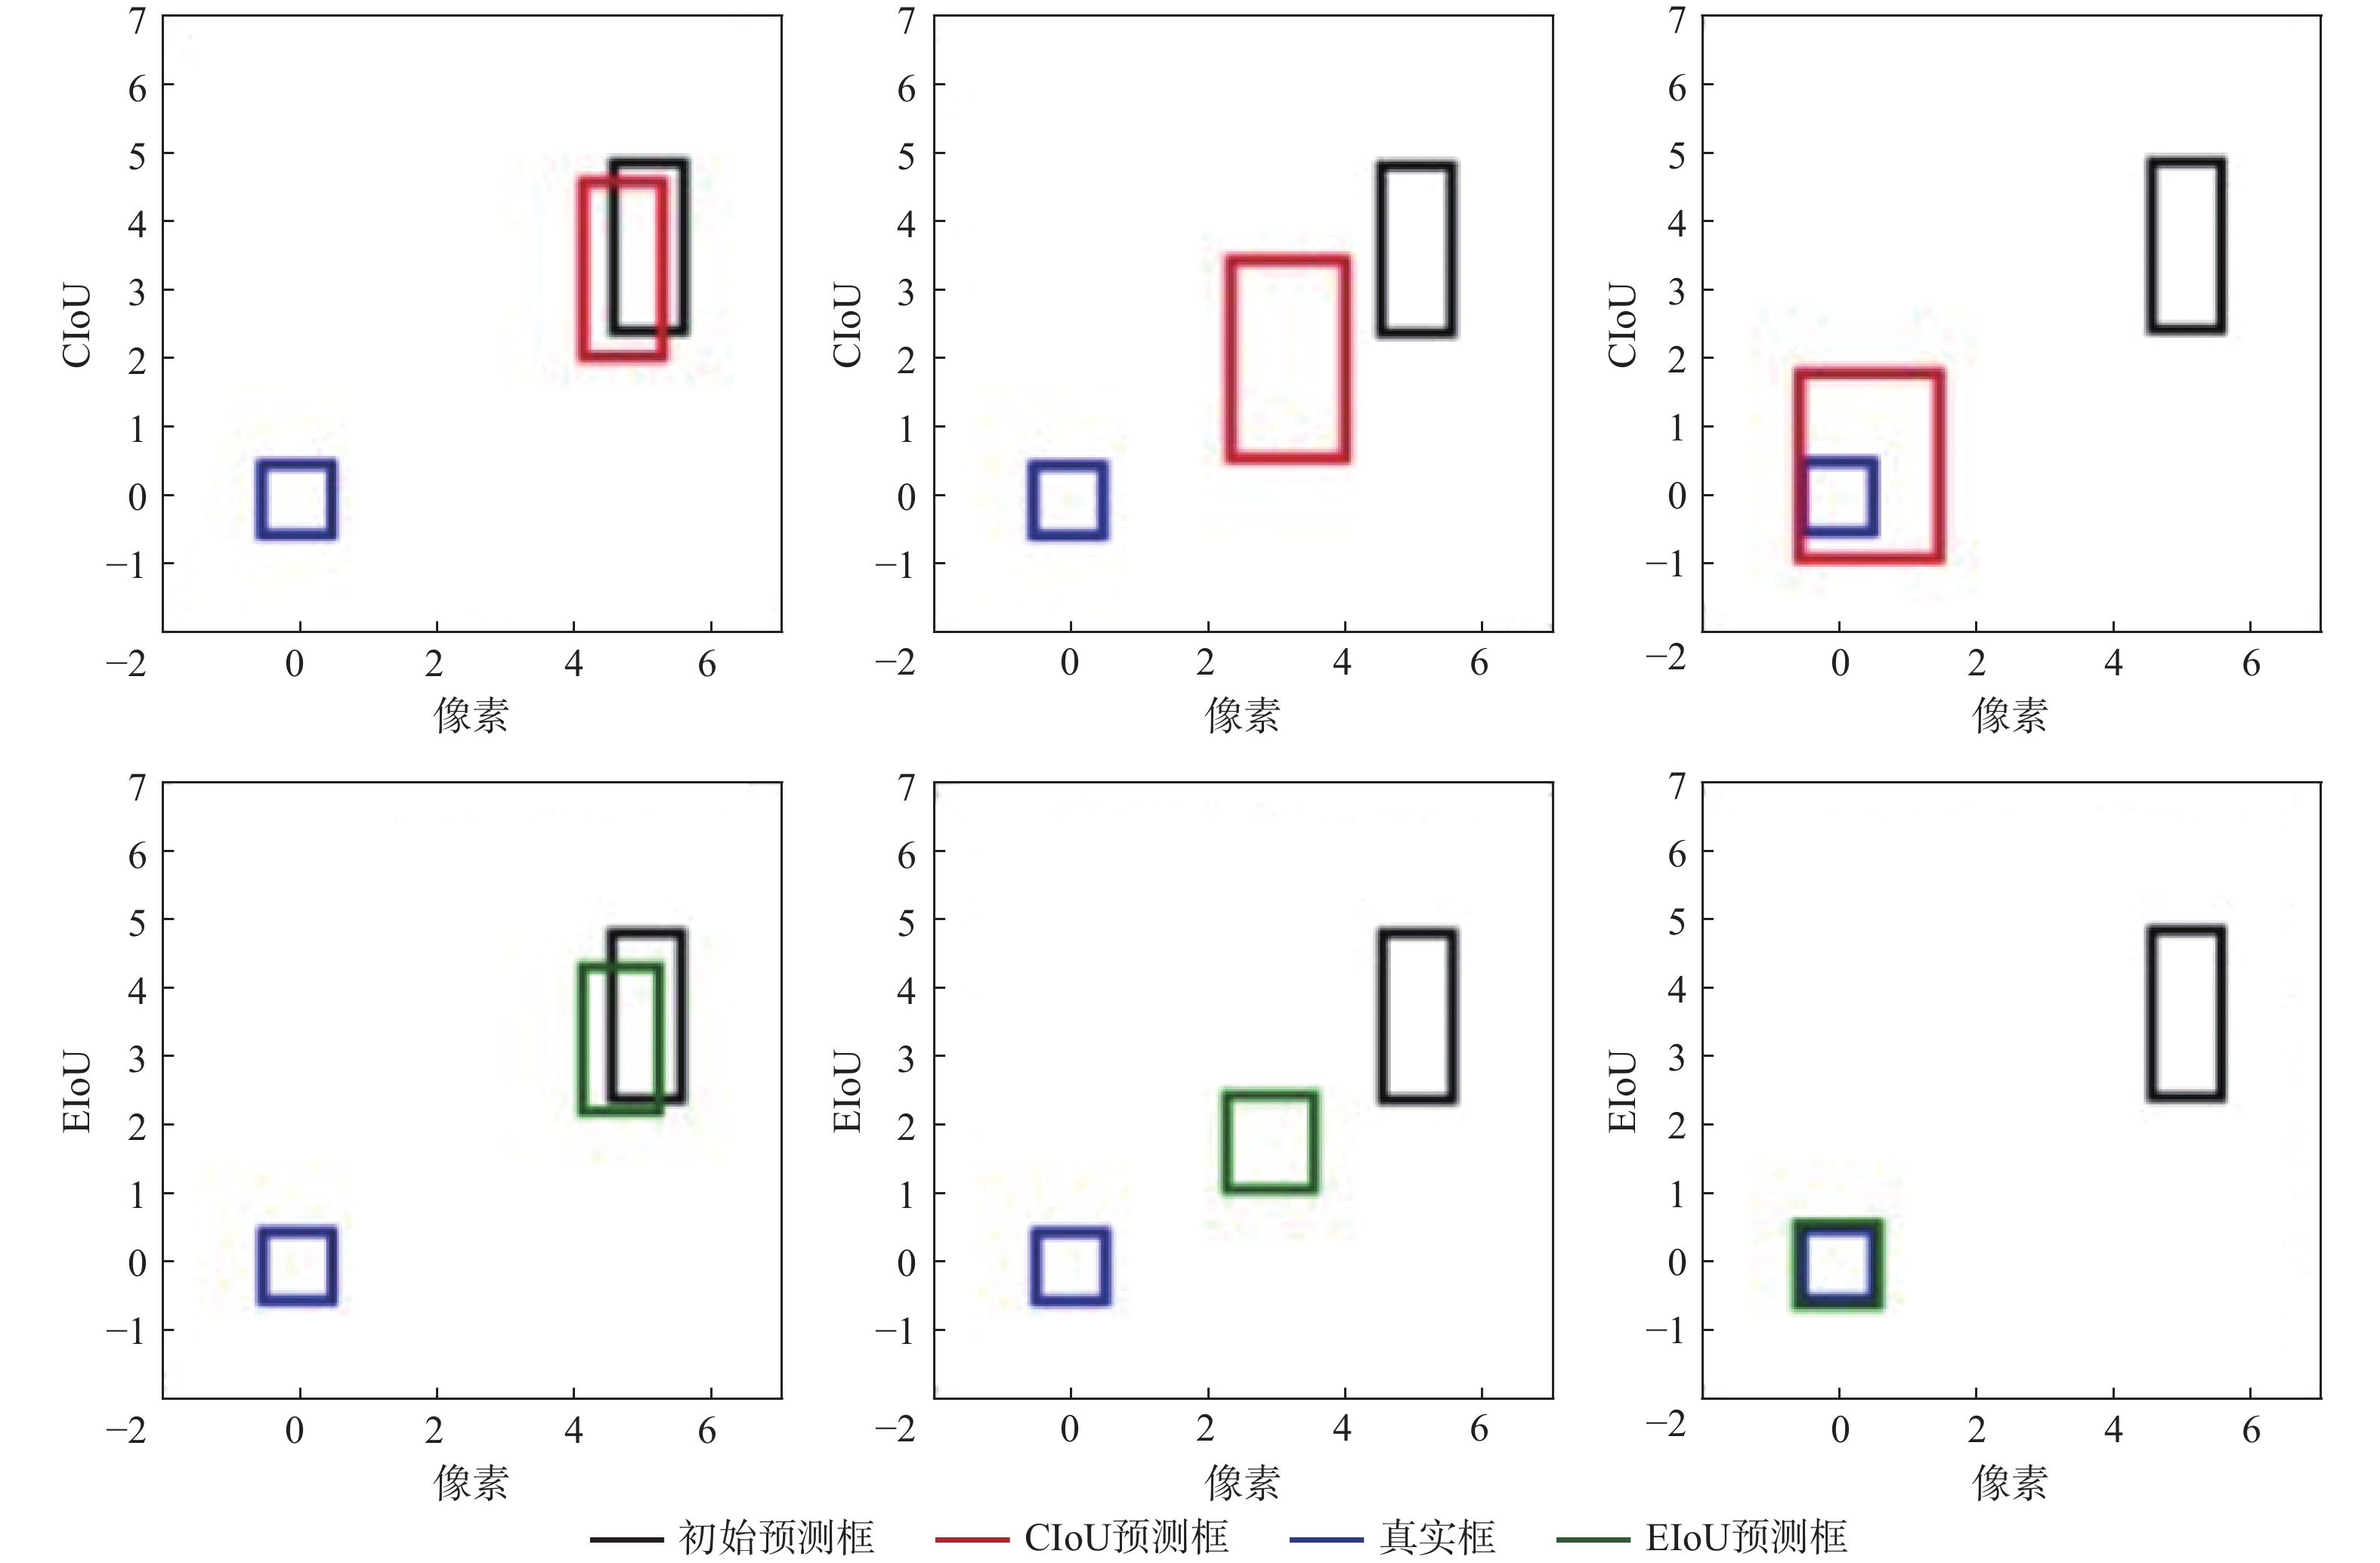
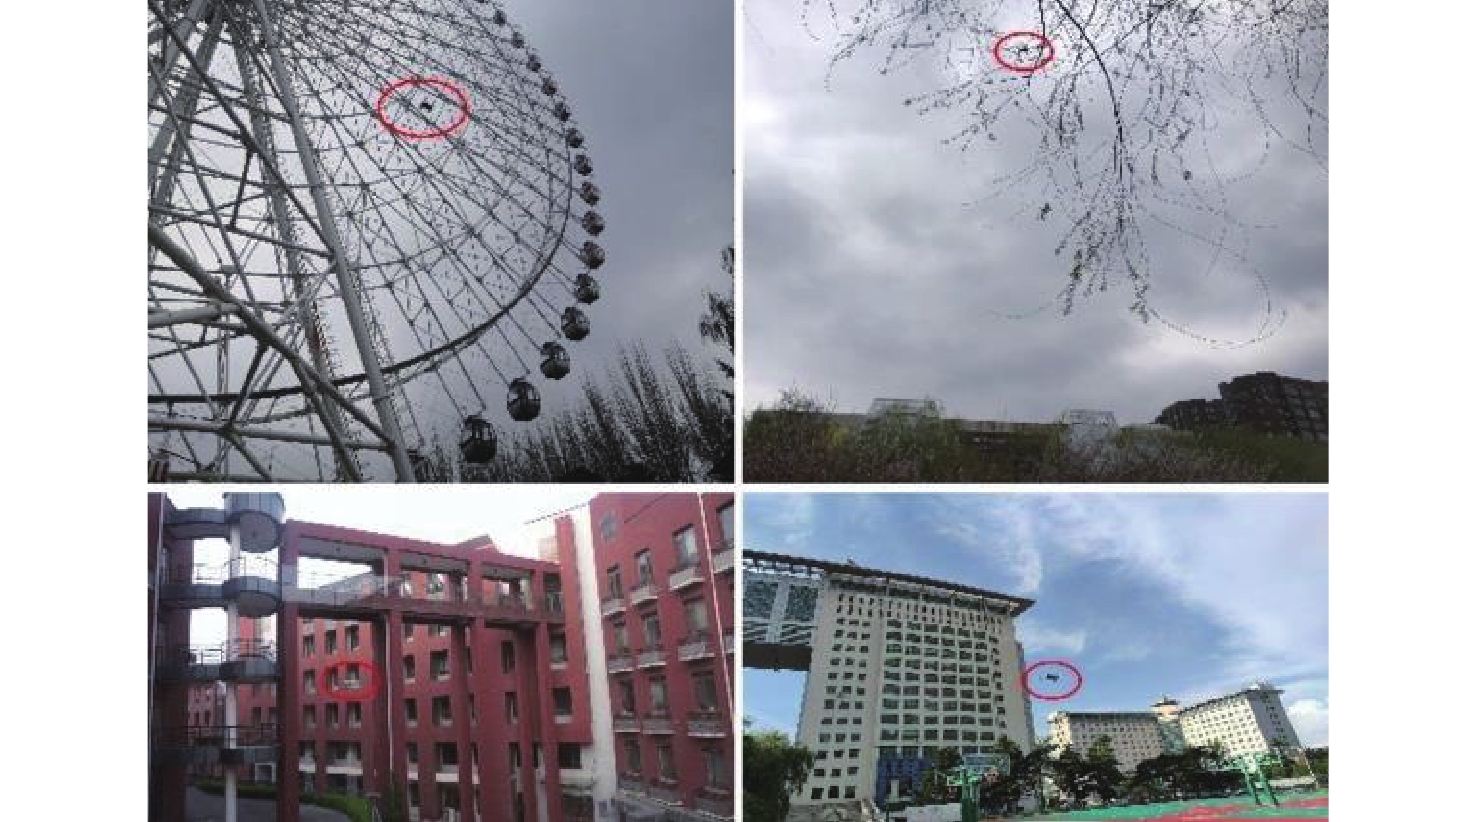
低空经济蓬勃发展的同时,无人机对大型公共场所的安全威胁逐步升级。对无人机准确、快速的目标检测成为反无人机系统的关键和首要环节。针对复杂背景下小目标无人机检测时出现的检测精度低、漏检、错检等问题,提出一种基于改进YOLOv11的反无人机系统目标检测算法YOLOv11-drone。自主构建复杂背景下小目标无人机数据集;设计部分空间通道协同注意力模块C2SCSPSA,通过结合通道注意力及空间注意力提高模型对无人机特征的提取能力;提出一种针对小目标的多层次特征金字塔网络(STFPN),通过浅层语义的充分运用,极大减少了模型参数量,并提高了模型对小目标的关注度;将模型损失函数更换为EIoU,提高回归精度和收敛速度。在自建数据集上进行实验,结果表明:所提YOLOv11-drone算法的检测精度达到95.5%,相较原算法提高了4.1%,且参数量降低了62%,检测速度达到83帧/s,适用于复杂背景下小目标无人机的检测任务。在公共数据集VisDrone2019上进行实验验证,即使参数量只有原算法的38%,但改进算法的mAP@0.5仍提高了0.6%,验证了改进算法具有良好的适用性与泛化性。
Abstract:Amid the rapid expansion of the low-altitude economy, UAVs present escalating security threats to large-scale public spaces. Accurate and rapid target detection of drones has become the primary and critical component in anti-drone systems. To address the critical challenges of low detection accuracy, high miss rate, and false positives in small UAV detection within complex environments, this study proposes YOLOv11-drone, an optimized object detection framework based on an enhanced YOLOv11 architecture specifically designed for counter-UAV applications. First, an autonomous dataset of small-target drones in complex backgrounds was constructed. Second, to improve the model’s ability to extract features for drone targets, a partial spatial-channel cooperative attention module C2SCSPSA was created that combines channel attention with spatial attention processes. Furthermore, a small-target-oriented multi-level feature pyramid network (STFPN) was proposed. By fully leveraging shallow semantic information, this architecture significantly reduces the model’s parameter count while improving its focus on small targets. Finally, the model’s loss function was replaced with the EIoU metric, which simultaneously enhances regression accuracy and accelerates convergence speed. The proposed improved algorithm was evaluated on the self-constructed dataset. Experimental results demonstrate that the YOLOv11-drone model achieves a detection accuracy of 95.5%, representing a 4.1% improvement over the baseline algorithm. Additionally, the model reduces parameter count by 62% while attaining an inference speed of 83 frames per second. These advancements confirm its efficacy for small-target drone detection in complex backgrounds. To further evaluate generalization capability, experiments were conducted on the public VisDrone2019 benchmark. The suggested technique shows strong cross-domain applicability and generalization performance, achieving a 0.6% improvement in mAP@0.5 while using just 38% of the baseline model’s parameters.
-
Key words:
- anti-UAV /
- small object detection /
- multi-scale features /
- YOLOv11 /
- loss function
-
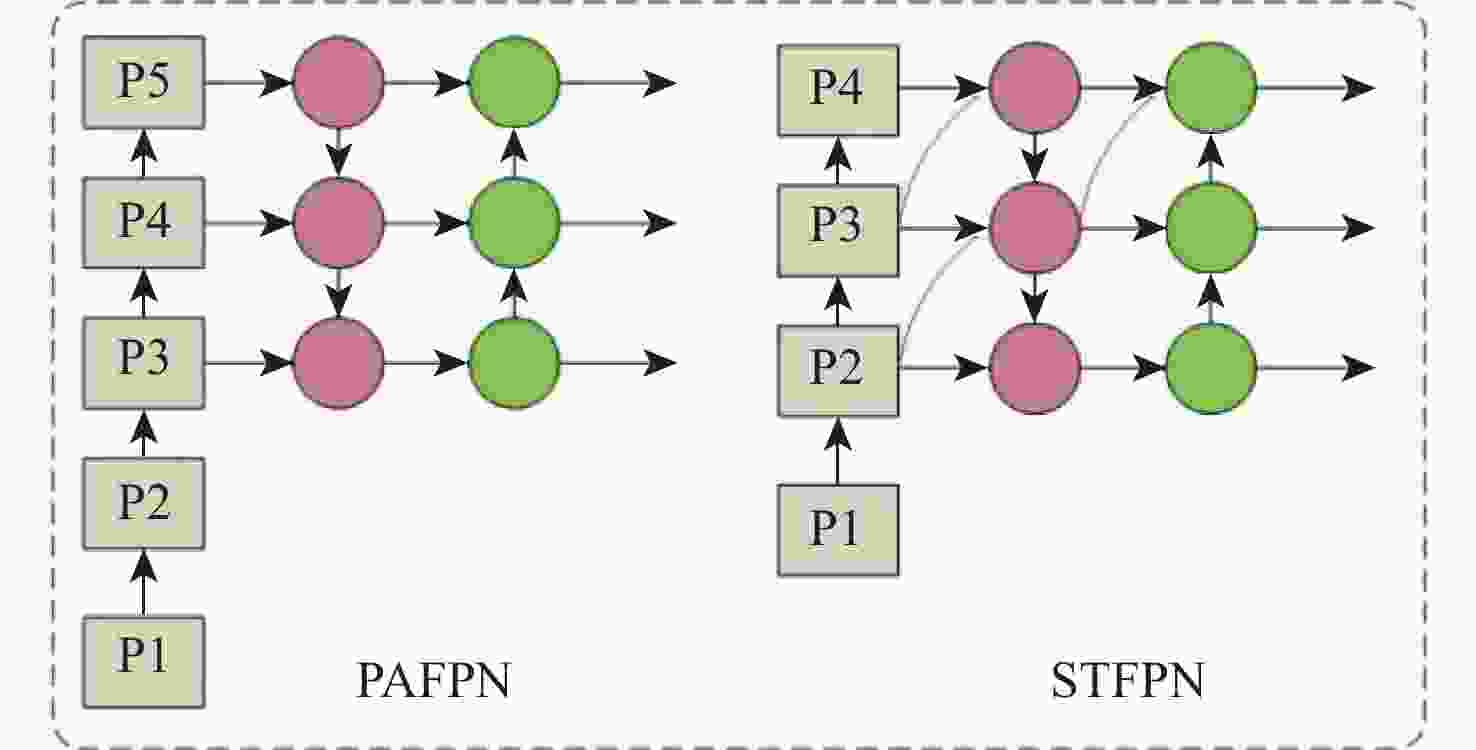
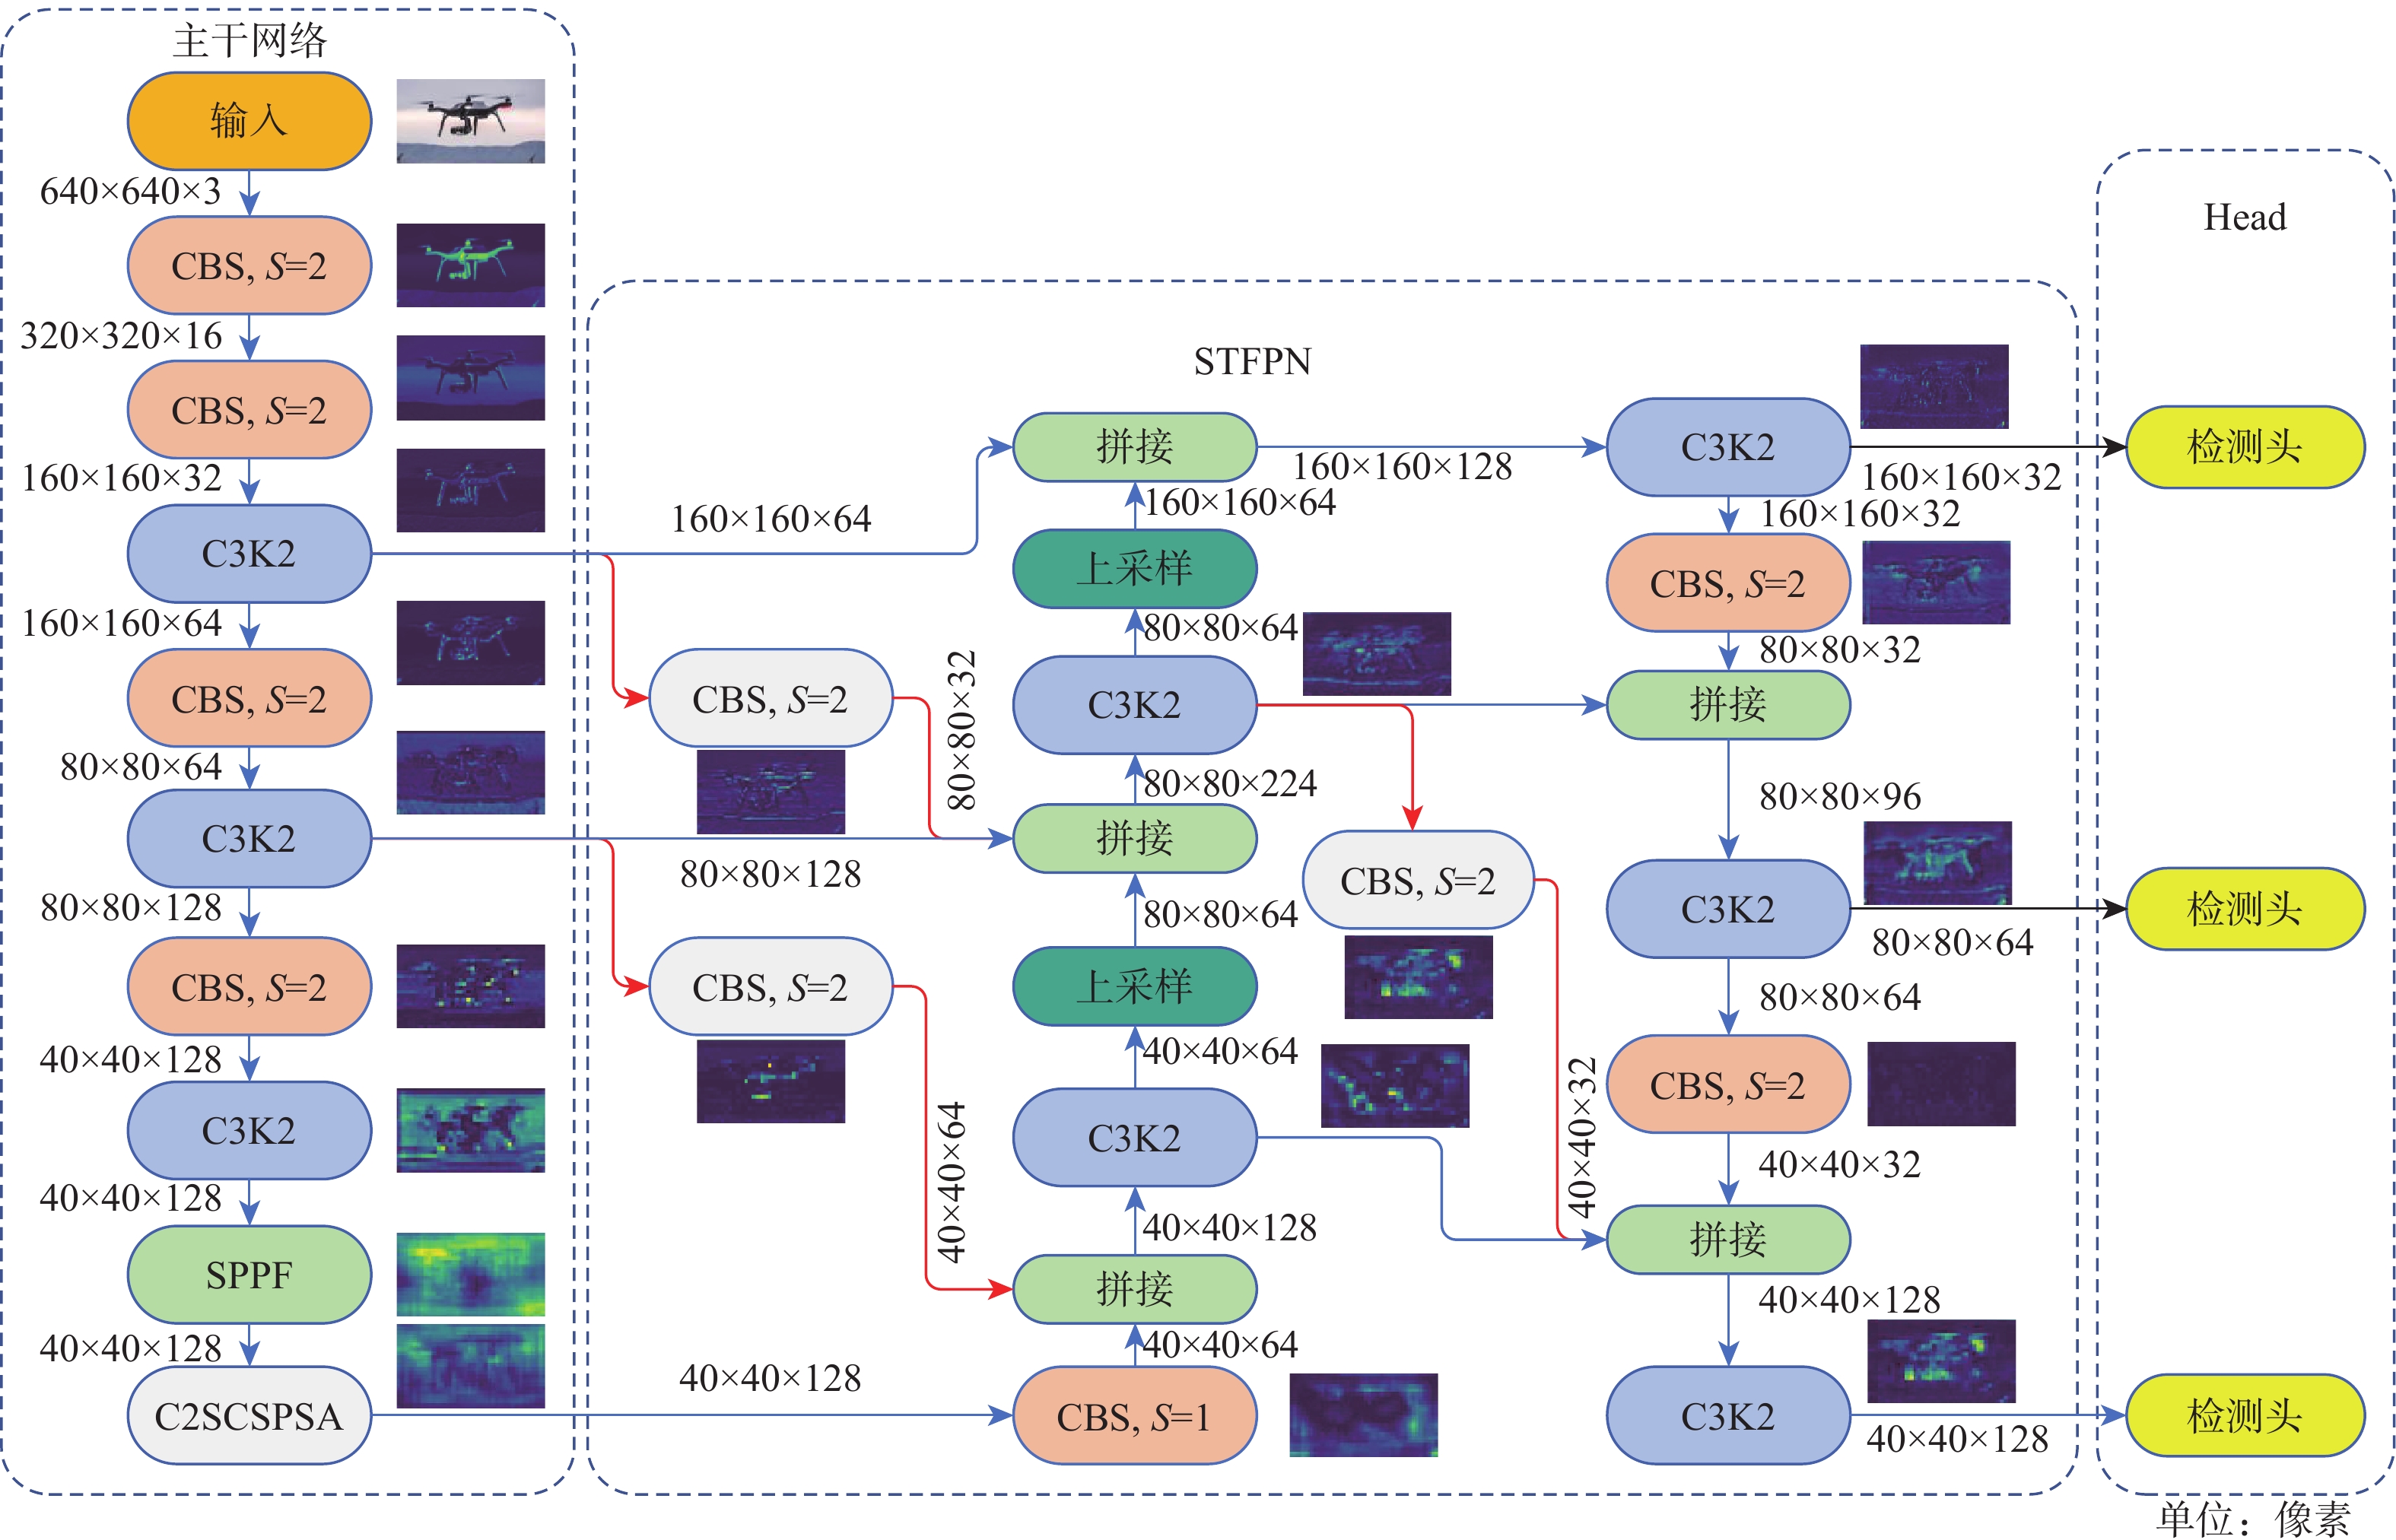
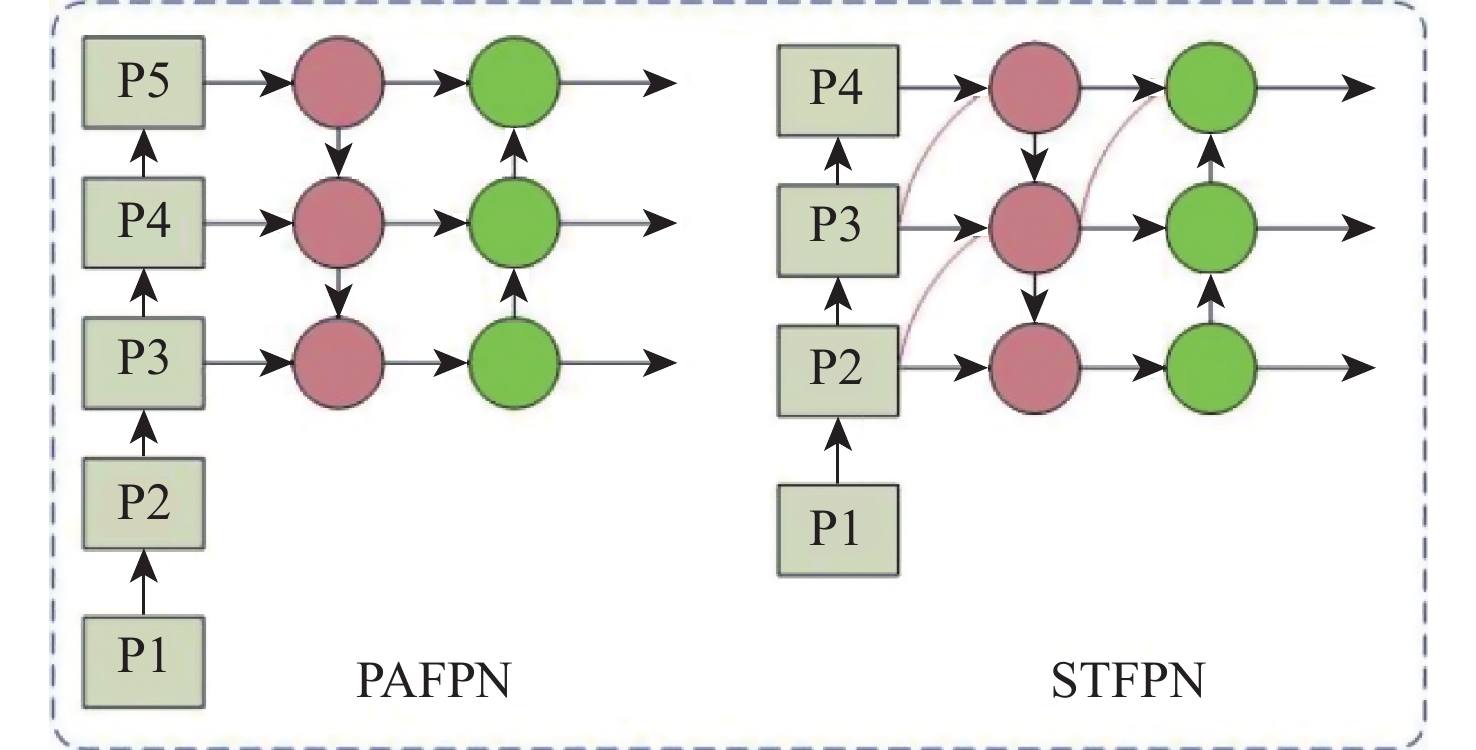
图 6 改进前后特征融合部分对比
Figure 6. Comparison of feature fusion part before and after improvement
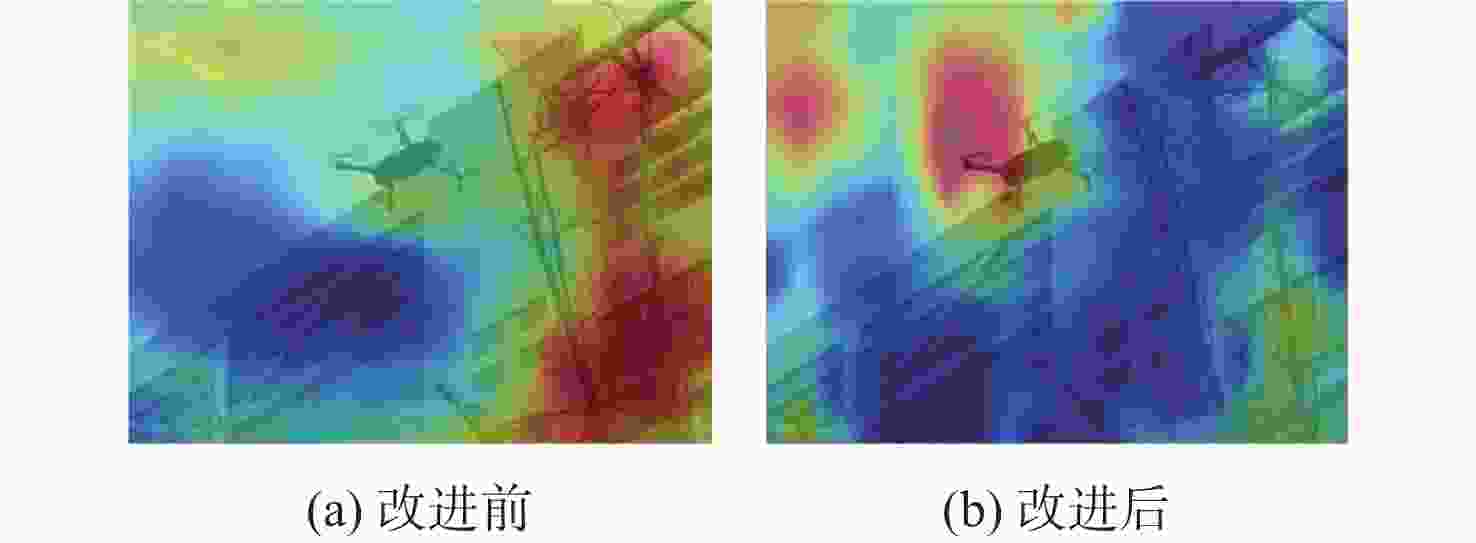
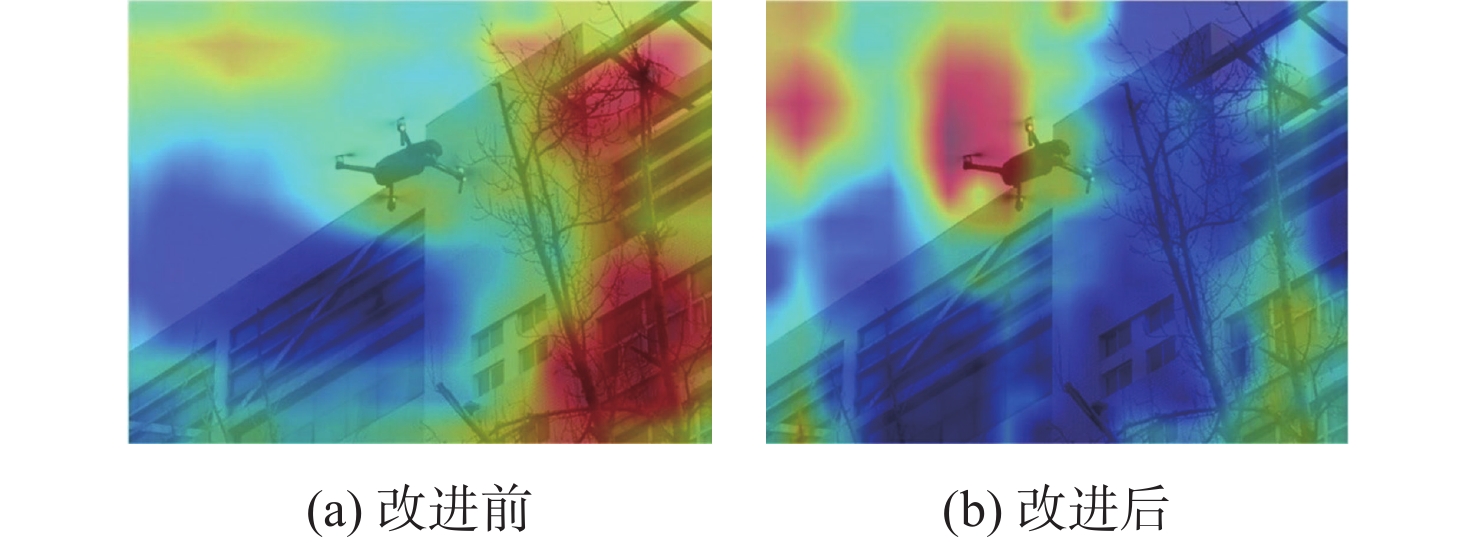
图 9 改进注意力机制前后小目标热力图对比
Figure 9. Comparison of heatmaps for small targets before and after improving attention mechanism
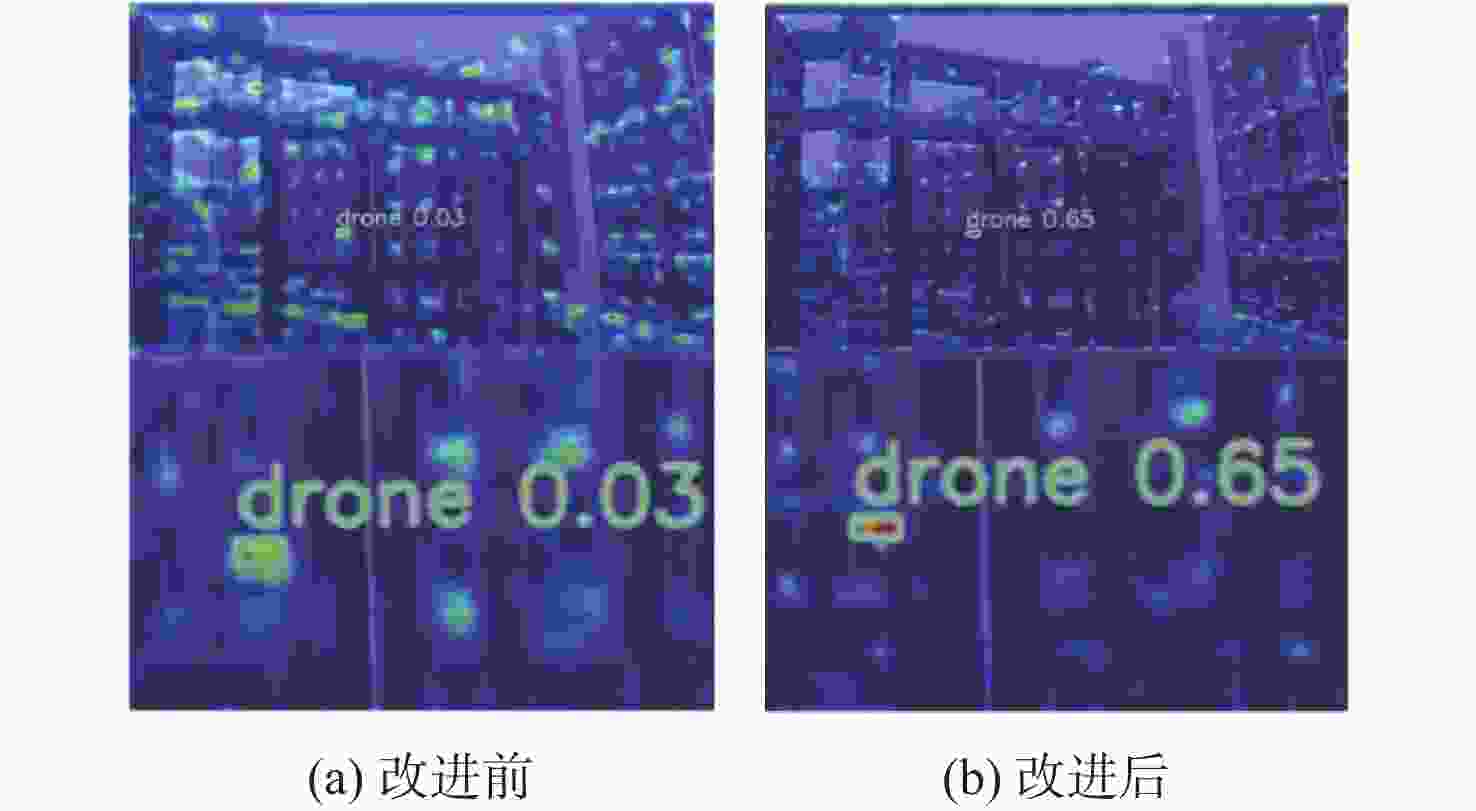
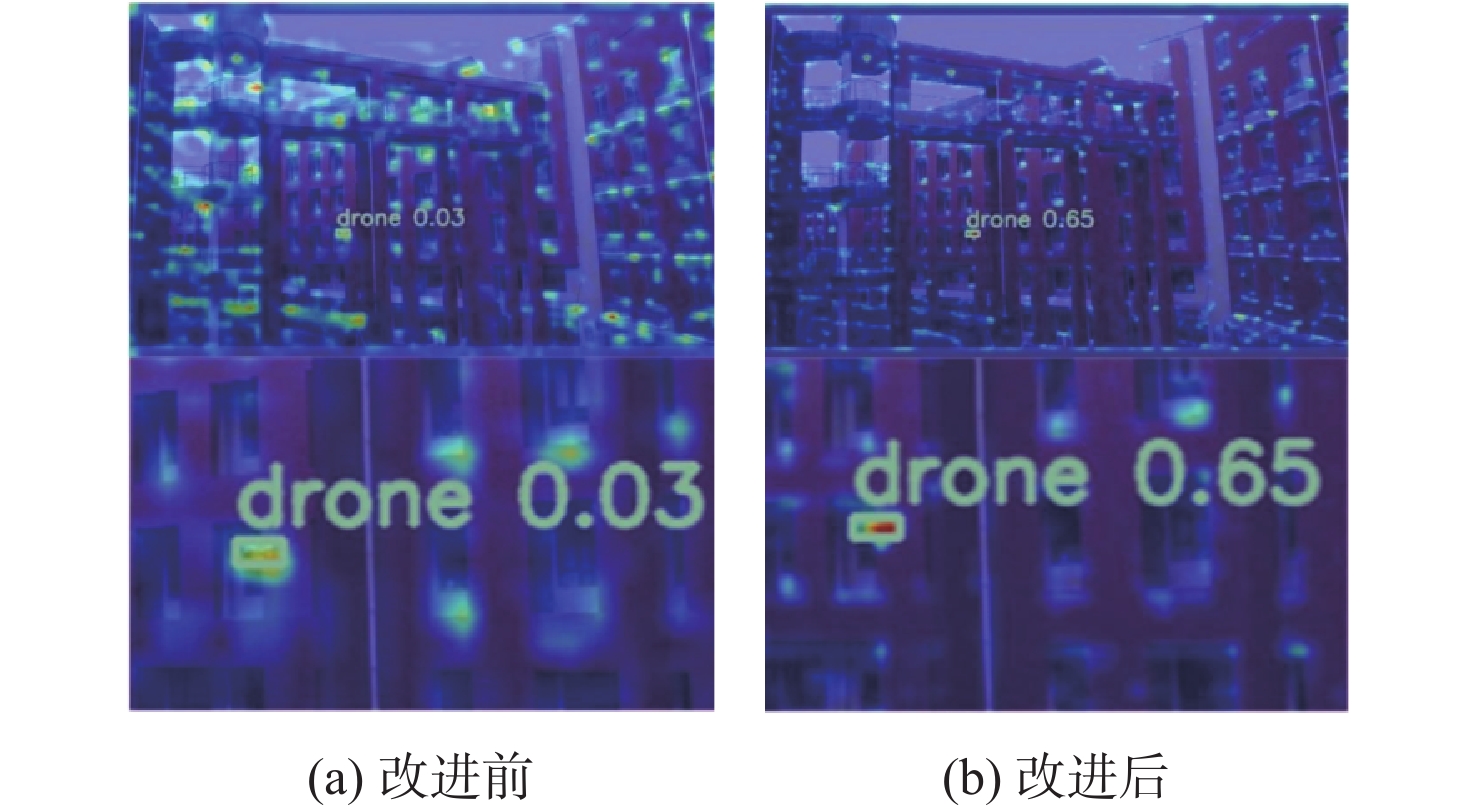
图 10 改进特征融合部分前后小目标热力图对比
Figure 10. Comparison of heatmaps of small targets before and after improving feature fusion
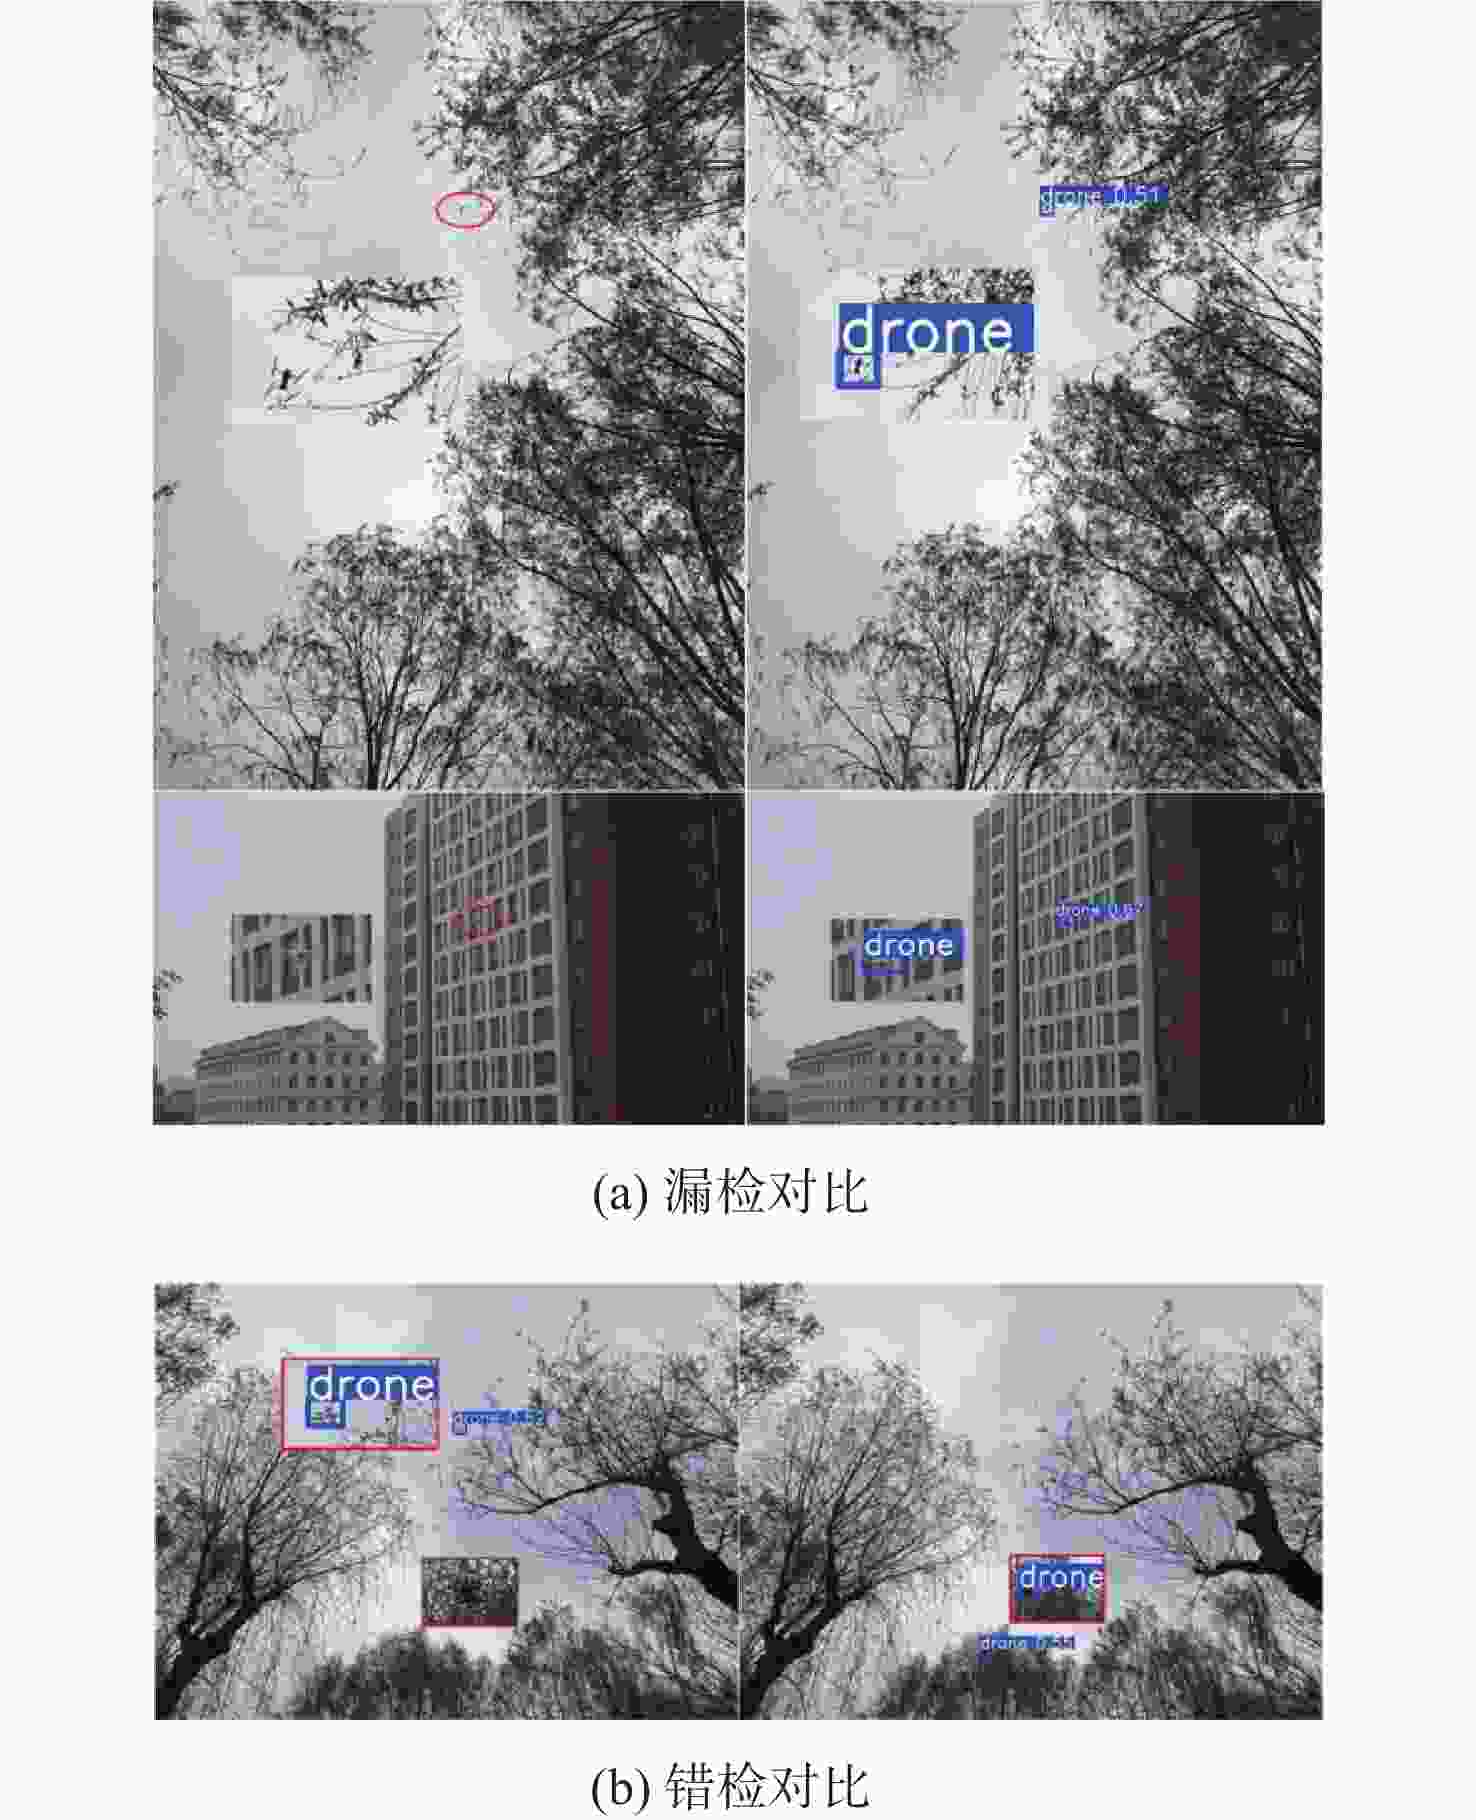
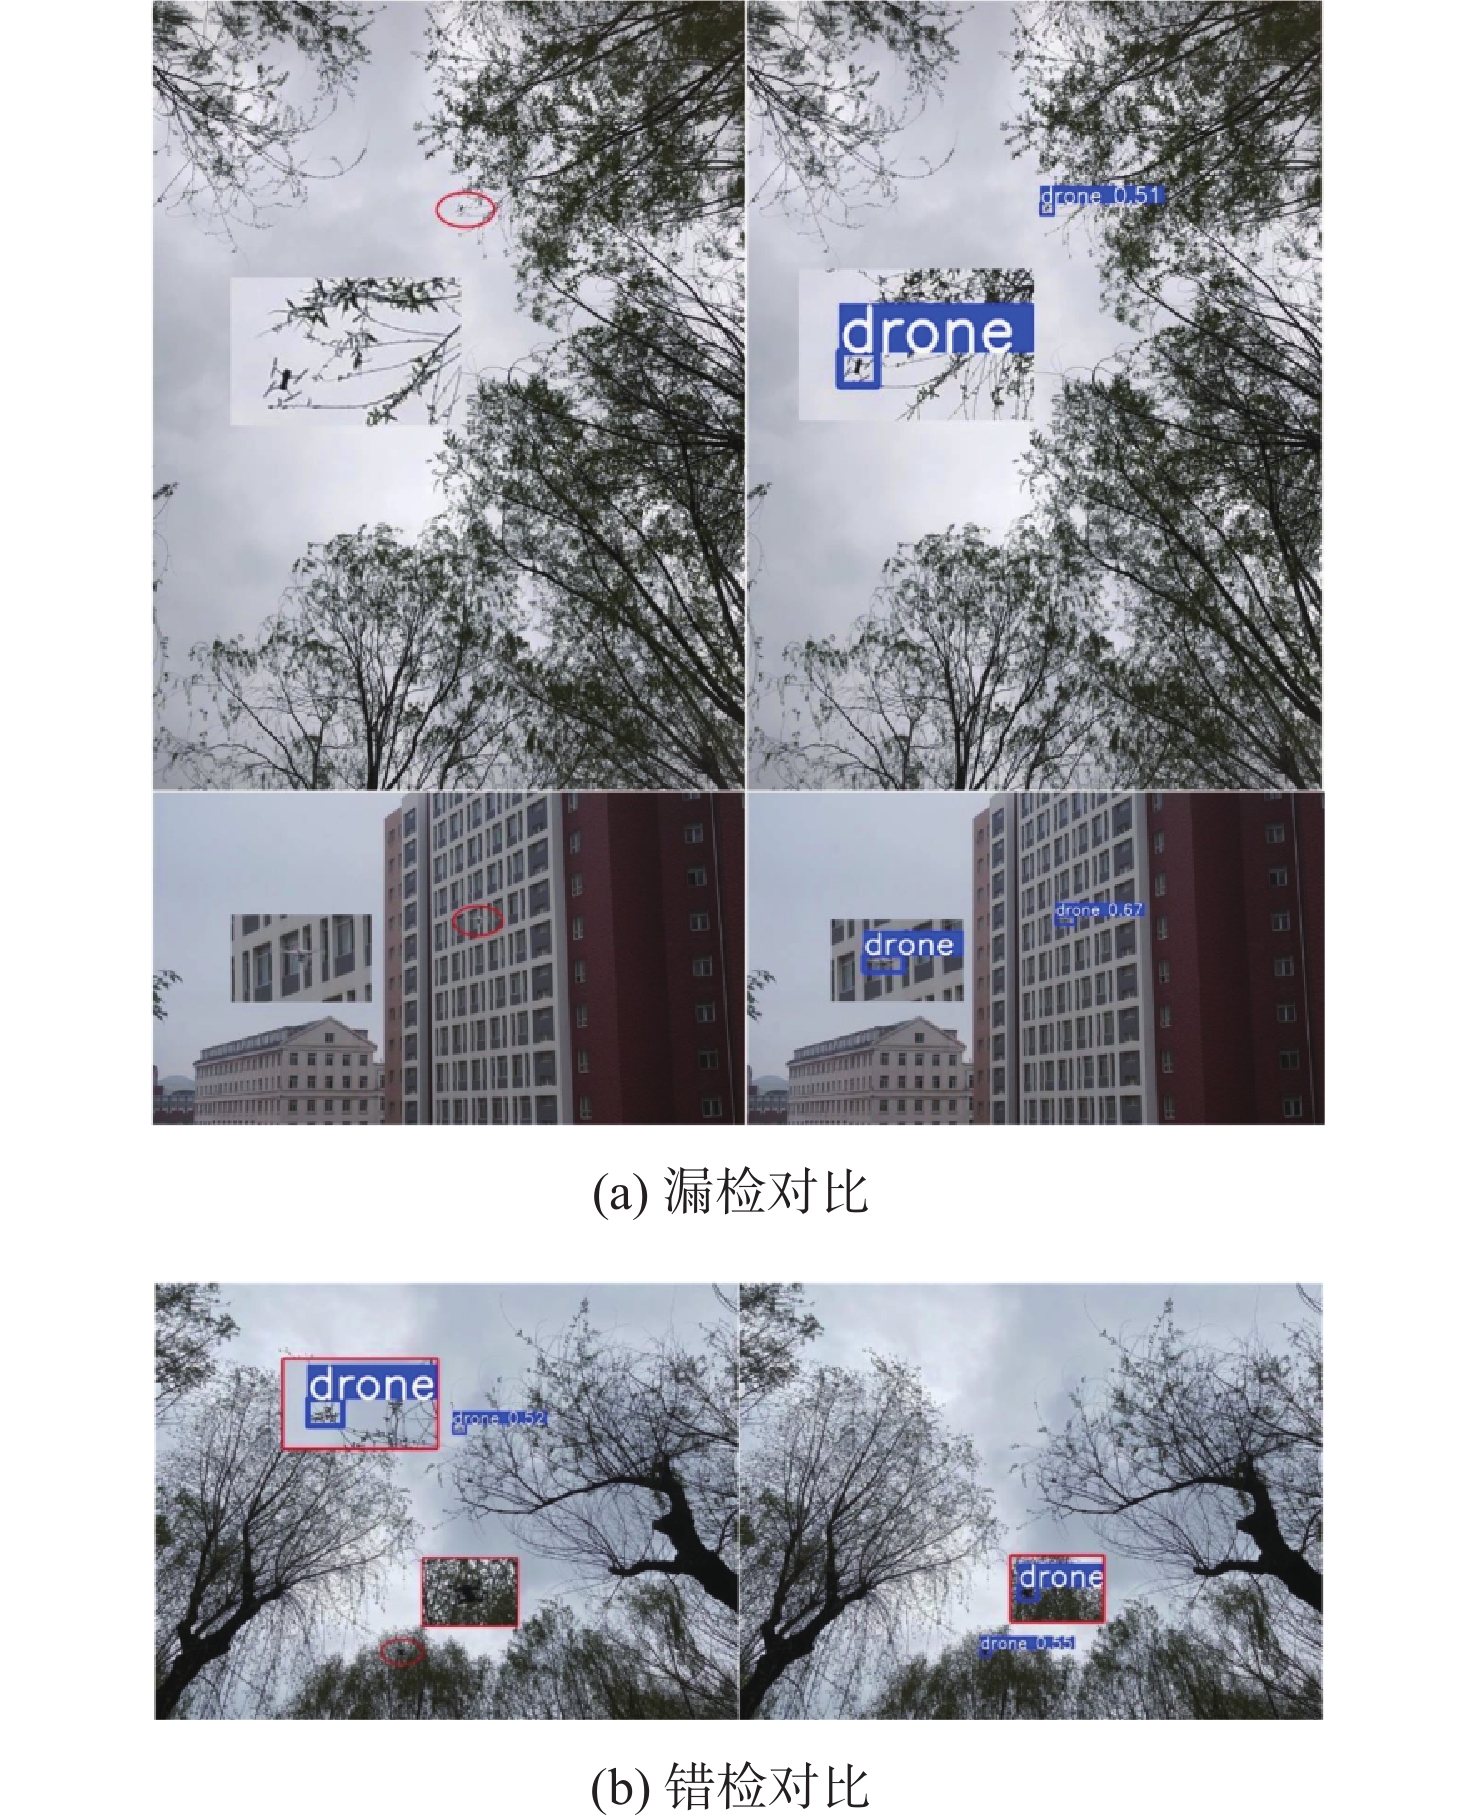
图 11 改进算法检测效果可视化对比
Figure 11. Visual comparison of detection performance of improved algorithms
表 1 实验超参数
Table 1. Experimental hyperparameters
超参数 数值 初始学习率 0.01 循环学习率 0.01 动量 0.937 批量大小 16 图片尺寸/(像素×像素) 640×640 训练轮次 100 预热学习轮数 3.0 预热训练动量 0.8 IoU训练阈值 0.7  下载: 导出CSV
表 2 消融实验结果对比
Table 2. Comparison of ablation experiment results
实验序号 C2SCSPSA STFPN EIoU 参数量 浮点运算量/次 mAP@0.5/% mAP@0.5:0.95-small/% 检测速度/(帧·s−1) 1 × × × 2.59×10⁶ 6.4×10⁹ 91.4 24.6 89 2 √ × × 2.54×10⁶ 6.4×10⁹ 92.0 25.0 88 3 √ √ × 0.99×10⁶ 9.3×10⁹ 94.6 39.6 79 4 √ √ √ 0.99×10⁶ 9.3×10⁹ 95.5 39.6 83
下载: 导出CSV
表 3 不同算法对比实验结果
Table 3. Comparison experiment results of different algorithms
算法 参数量 浮点运算量/次 mAP@0.5/% 检测速度/
(帧·s−1)YOLOv7-tiny 6.01×10⁶ 13.2×10⁹ 89.0 66 YOLOv8n 3.01×10⁶ 8.2×10⁹ 91.2 71 YOLOv9-tiny 2.65×10⁶ 11.0×10⁹ 93.0 60 YOLOv10n 2.70×10⁶ 8.3×10⁹ 91.7 65 YOLOv11n 2.59×10⁶ 6.4×10⁹ 91.4 89 YOLOv11s 9.43×10⁶ 21.5×10⁹ 94.7 65 YOLOv11-drone 0.99×10⁶ 9.3×10⁹ 95.5 83
下载: 导出CSV
表 4 VisDrone2019数据集对比结果
Table 4. Comparison results on VisDrone2019 dataset
算法 mAP@0.5/% 参数量 检测速度/(帧·s−1) YOLOv8n 30.1 3.01×10⁶ 168 YOLOv10n 29.0 2.70×10⁶ 150 YOLOv11n 30.2 2.59×10⁶ 146 YOLOv11-drone 30.8 0.99×10⁶ 112
下载: 导出CSV
-
[1] 邱小剑, 骆博雅, 付珍, 等. 国内外反无人机技术发展综述[J]. 战术导弹技术, 2024(5): 63-73.Qiu X J, Luo B Y, Fu Z, et al. An overview on development of domestic and foreign anti-UAV technology[J]. Tactical Missile Technology, 2024(5): 63-73(in Chinese). [2] 谢学立, 席建祥, 卢瑞涛, 等. 动态区域聚焦的反无人机红外长时跟踪算法[J]. 北京航空航天大学学报, 2025, 51(9): 3039-3051.Xie X L, Xi J X, Lu R T, et al. Long-term infrared object tracking algorithm based on dynamic region focusing for anti-UAV[J]. Journal of Beijing University of Aeronautics and Astronautics, 2025, 51(9): 3039-3051(in Chinese). [3] 薛珊, 张亚亮, 吕琼莹, 等. 复杂背景下的反无人机系统目标检测算法[J]. 吉林大学学报(工学版), 2023, 53(3): 891-901.Xue S, Zhang Y L, Lyu Q Y, et al. Anti-unmanned aerial vehicle system object detection algorithm under complex background[J]. Journal of Jilin University (Engineering and Technology Edition), 2023, 53(3): 891-901(in Chinese). [4] 薛珊, 卢涛, 吕琼莹, 等. 基于多尺度融合和轻量化网络的无人机目标检测算法[J]. 湖南大学学报(自然科学版), 2023, 50(8): 82-93.Xue S, Lu T, Lü Q Y, et al. Drone target detection algorithm based on multi-scale fusion and lightweight network[J]. Journal of Hunan University (Natural Sciences), 2023, 50(8): 82-93(in Chinese). [5] 薛珊, 王亚博, 吕琼莹, 等. 基于YOLOX-drone的反无人机系统抗遮挡目标检测算法[J]. 工程科学学报, 2023, 45(9): 1539-1549.Xue S, Wang Y B, Lü Q Y, et al. Anti-occlusion target detection algorithm for anti-UAV system based on YOLOX-drone[J]. Chinese Journal of Engineering, 2023, 45(9): 1539-1549(in Chinese). [6] 白宇, 周艳媛, 安胜彪. 改进YOLOv5的无人机小目标检测方法研究[J]. 计算机工程与应用, 2024, 60(10): 276-284.Bai Y, Zhou Y Y, An S B. Research on UAV small object detection method improved by YOLOv5[J]. Computer Engineering and Applications, 2024, 60(10): 276-284(in Chinese). [7] 刘玉萍, 尚翠娟, 李明明. 改进YOLOv11的无人机小目标检测算法[J]. 计算机工程与应用, 2025, 61(15): 124-131.Liu Y P, Shang C J, Li M M. Improved YOLOv11 algorithm for small target detection in UAVs[J]. Computer Engineering and Applications, 2025, 61(15): 124-131(in Chinese). [8] 李彬, 李生林. 改进YOLOv11n的无人机小目标检测算法[J]. 计算机工程与应用, 2025, 61(7): 96-104.Li B, Li S L. Improved YOLOv11n small object detection algorithm in UAV view[J]. Computer Engineering and Applications, 2025, 61(7): 96-104(in Chinese). [9] Girshick R. Fast R-CNN[C]//Proceedings of the IEEE International Conference on Computer Vision. Piscataway: IEEE Press, 2016: 1440-1448. [10] Ren S Q, He K M, Girshick R, et al. Faster R-CNN: towards real-time object detection with region proposal networks[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2017, 39(6): 1137-1149. [11] He K M, Gkioxari G, Dollár P, et al. Mask R-CNN[C]//Proceedings of the IEEE International Conference on Computer Vision. Piscataway: IEEE Press, 2017: 2980-2988. [12] Liu W, Anguelov D, Erhan D, et al. SSD: single shot MultiBox detector[C]//Proceedings of the 14th European Conference on Computer Vision. Berlin: Springer, 2016: 21-37. [13] Redmon J, Divvala S, Girshick R, et al. You only look once: unified, real-time object detection[C]//Proceedings of the 14th IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2016: 779-788. [14] Wang C Y, Bochkovskiy A, Liao H M. YOLOv7: trainable bag-of-freebies sets new state-of-the-art for real-time object detectors[C]//Proceedings of the 14th IEEE/CVF Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2023: 7464-7475. [15] 陈金林, 吴一全, 苑玉彬. 无人机视角下目标检测的YOLO系列算法研究进展[J/OL]. 北京航空航天大学学报, 2024(2024-08-26)[2025-06-20]. https://doi.org/10.13700/j.bh.1001-5965.2024.0420.Chen J L, Wu Y Q, Yuan Y B. Research progress of YOLO series algorithms for object detection from UAV perspective[J/OL]. Journal of Beijing University of Aeronautics and Astronautics, 2024(2024-08-26)[2025-06-20]. https://doi.org/10.13700/j.bh.1001-5965.2024.0420(in Chinese). [16] Si Y Z, Xu H Y, Zhu X Z, et al. SCSA: exploring the synergistic effects between spatial and channel attention[EB/OL]. (2024-11-12)[2025-06-20]. https://arxiv.org/abs/2407.05128. [17] 徐慧智, 郝东升, 徐小婷, 等. 基于深度学习的高速公路小目标检测算法[J]. 吉林大学学报(工学版), 2025, 55(6): 2003-2014.Xu H Z, Hao D S, Xu X T, et al. Expressway small object detection algorithm based on deep learning[J]. Journal of Jilin University (Engineering and Technology Edition), 2025, 55(6): 2003-2014(in Chinese). [18] Zhang Y F, Ren W Q, Zhang Z, et al. Focal and efficient IOU loss for accurate bounding box regression[J]. Neurocomputing, 2022, 506: 146-157. [19] Zhao J, Zhang J S, Li D D, et al. Vision-based anti-UAV detection and tracking[EB/OL]. (2022-05-22)[2025-06-20]. https://arxiv.org/abs/2205.10851. [20] 薛珊, 张振, 吕琼莹, 等. 基于卷积神经网络的反无人机系统图像识别方法[J]. 红外与激光工程, 2020, 49(7): 20200154.Xue S, Zhang Z, Lv Q Y, et al. Image recognition method of anti UAV system based on convolutional neural network[J]. Infrared and Laser Engineering, 2020, 49(7): 20200154(in Chinese). [21] 侯公羽, 陈钦煌, 杨振华, 等. 基于改进YOLOv5的安全帽检测算法[J]. 工程科学学报, 2024, 46(2): 329-342.Hou G Y, Chen Q H, Yang Z H, et al. Helmet detection method based on improved YOLOv5[J]. Chinese Journal of Engineering, 2024, 46(2): 329-342(in Chinese). -

 下载:

 点击查看大图
计量
- 文章访问数: 395
- HTML全文浏览量: 211
- PDF下载量: 46
- 被引次数: 0
