


High-accuracy real-time 3D multi-target detection for low-altitude security scenarios
-
摘要:
针对低空安防场景下无人机、鸟类等动态目标的精确测距需求,提出一种基于双目视觉的多目标高精度实时三维检测方法。该方法在半全局块匹配(SGBM)算法基础上,引入双边滤波、形态学操作和插值空洞填充等视差优化策略,提升弱纹理目标的匹配鲁棒性和深度图完整性。通过结合三角测量与相机标定参数,实时求解目标的三维坐标。实验表明,在0.5~2.0 m范围内,视差空洞率由
40.7004 %降至1.2781 %,平均测距相对误差为2.55%,关键点定位精度达厘米级。缩比建模进一步验证了所提方法在远距离场景中的可扩展性,理论上可将有效范围扩展至2 km,为低空防控领域提供了一种高精度三维感知方案。Abstract:A real-time 3D detection method based on binocular vision is proposed to meet the high-accuracy ranging requirements of dynamic targets in low-altitude security scenarios. The method, which is based on the semi-global block matching (SGBM) algorithm, combines morphological processing, bilateral filtering, and interpolation-based hole-filling to enhance the completeness of depth information and disparity quality in weak-texture areas. With calibrated camera parameters and the triangulation principle, target 3D coordinates are computed in real time. Experiments show that within the distance range of 0.5-2.0 m, the disparity hole rate is reduced from
40.7004 % to1.2781 %, with an average relative ranging error of 2.55% and centimeter-level positioning accuracy. The method’s scalability to2000 meters is further confirmed by scale model study. Overall, the proposed system provides an efficient and cost-effective solution for multi-target 3D perception in low-altitude surveillance.-
Key words:
- binocular vision /
- semi-global block matching /
- disparity optimization /
- depth estimation /
- 3D detection /
- scaled model
-
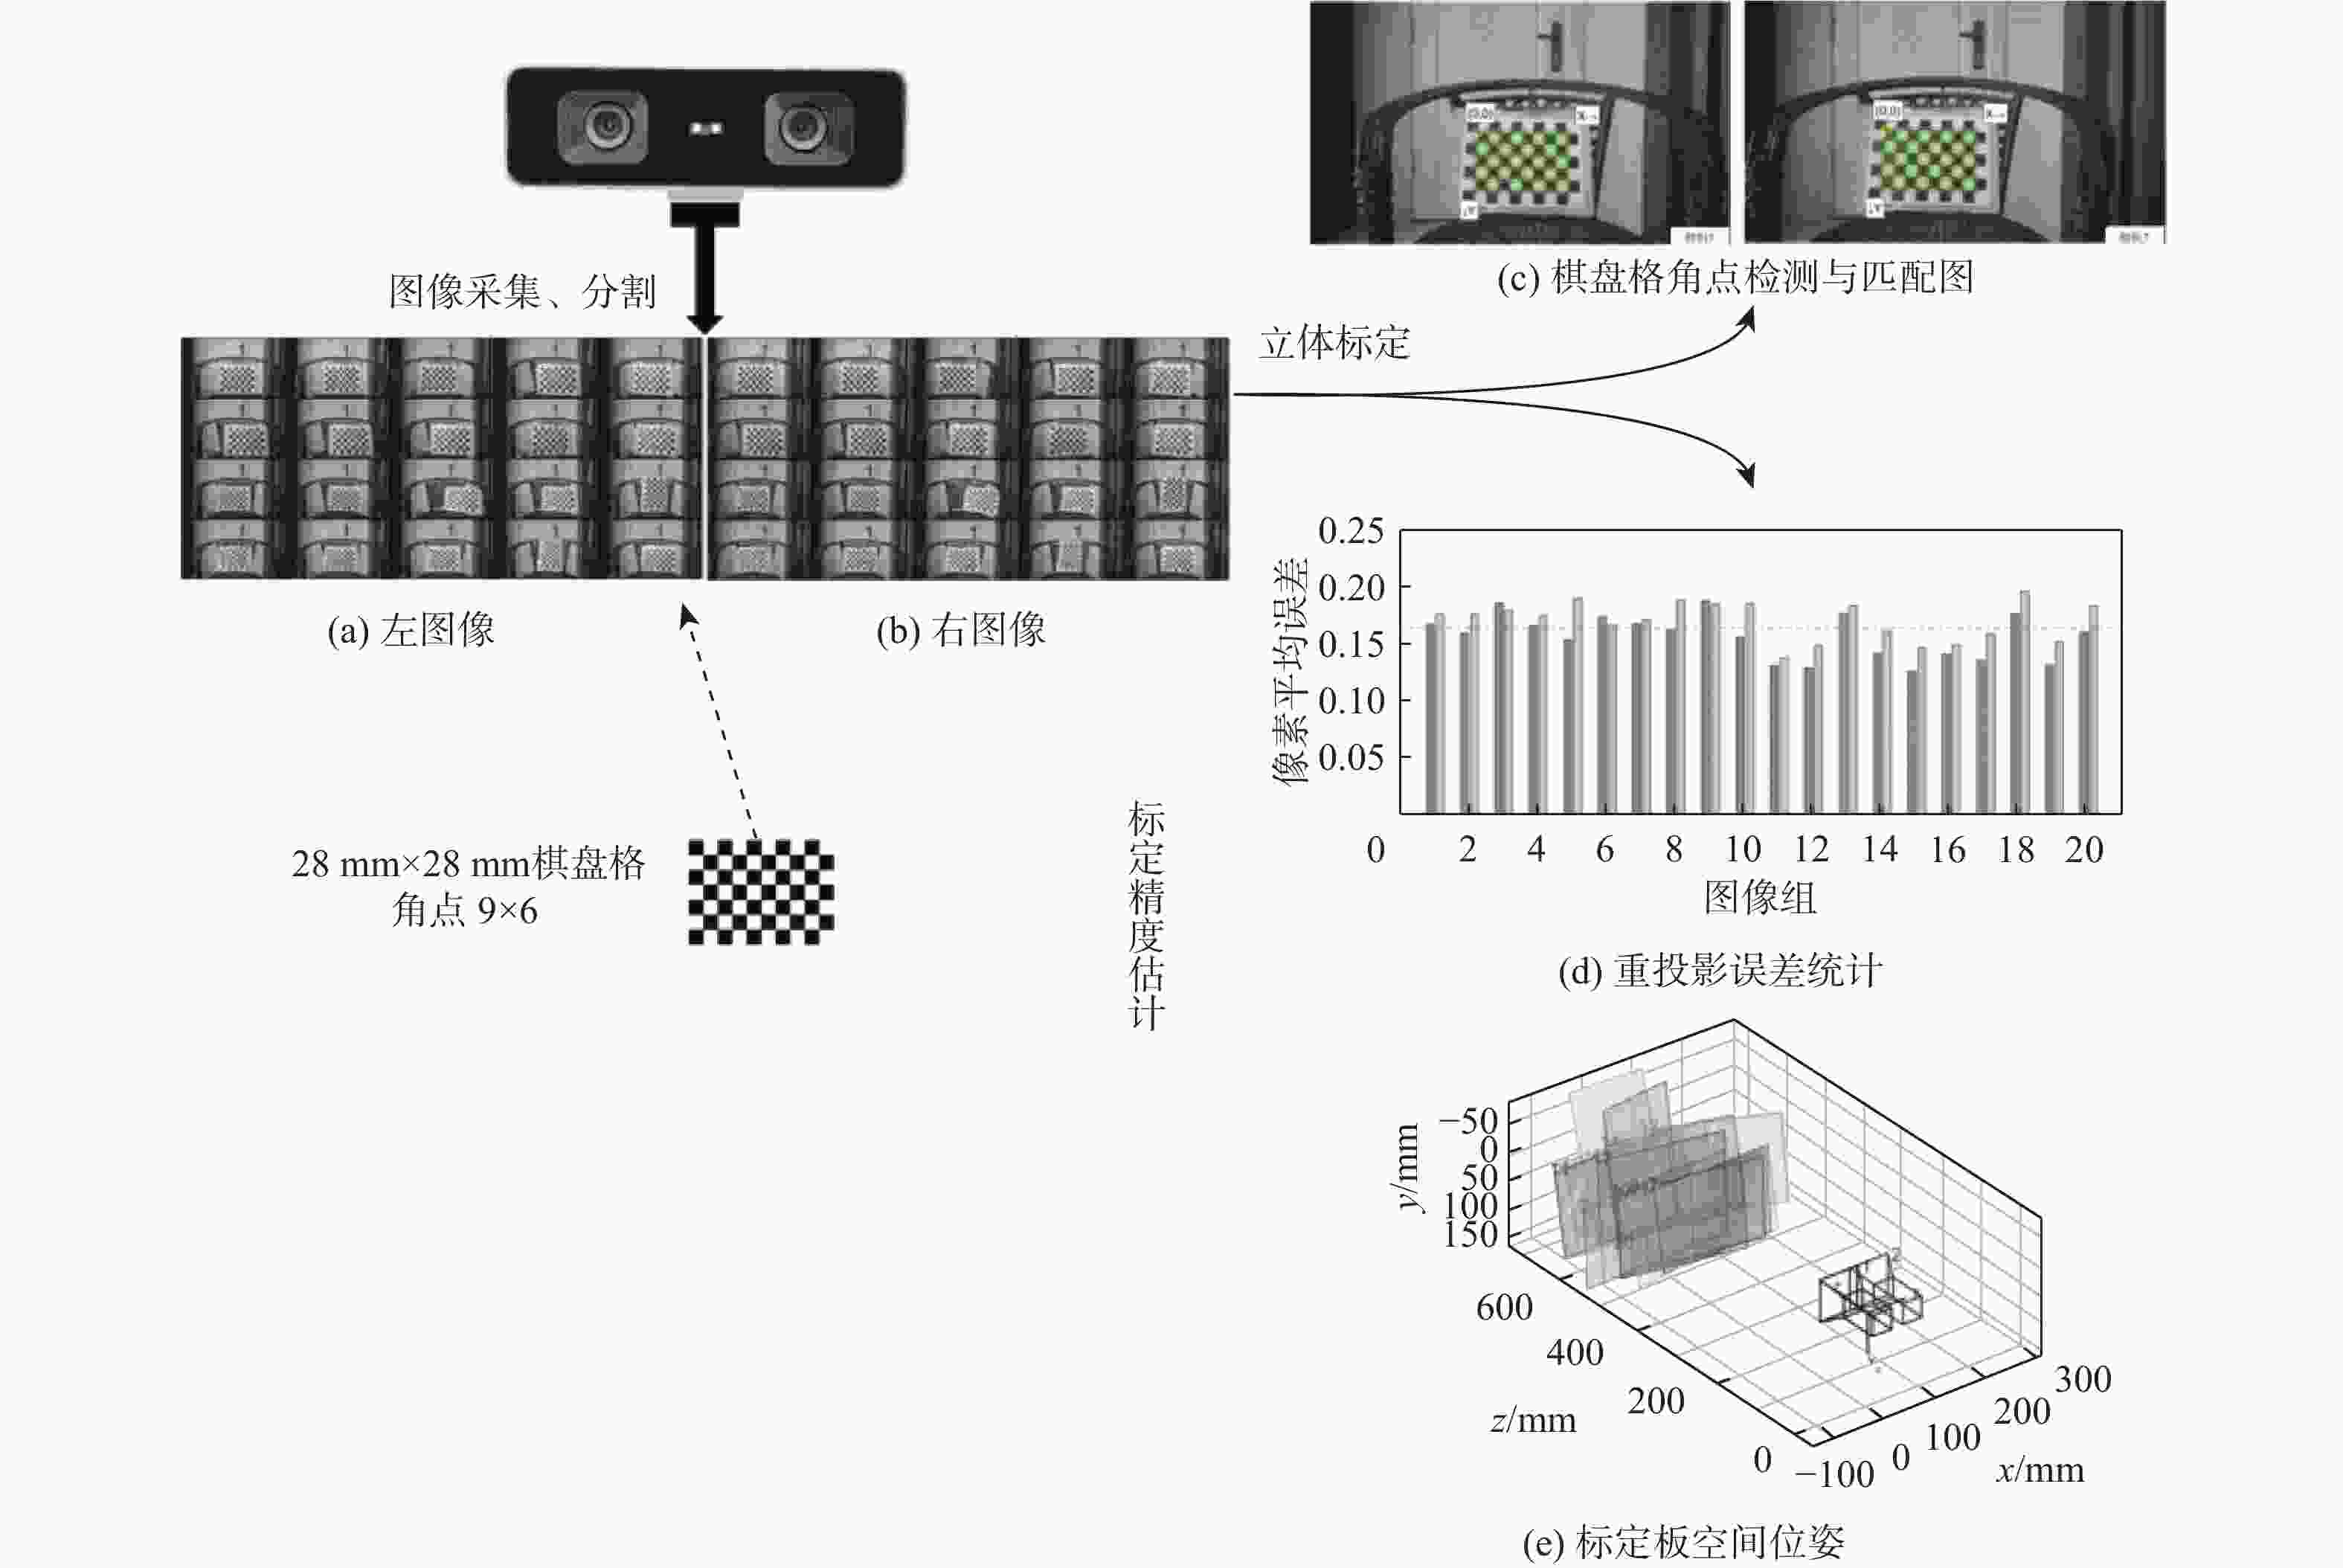
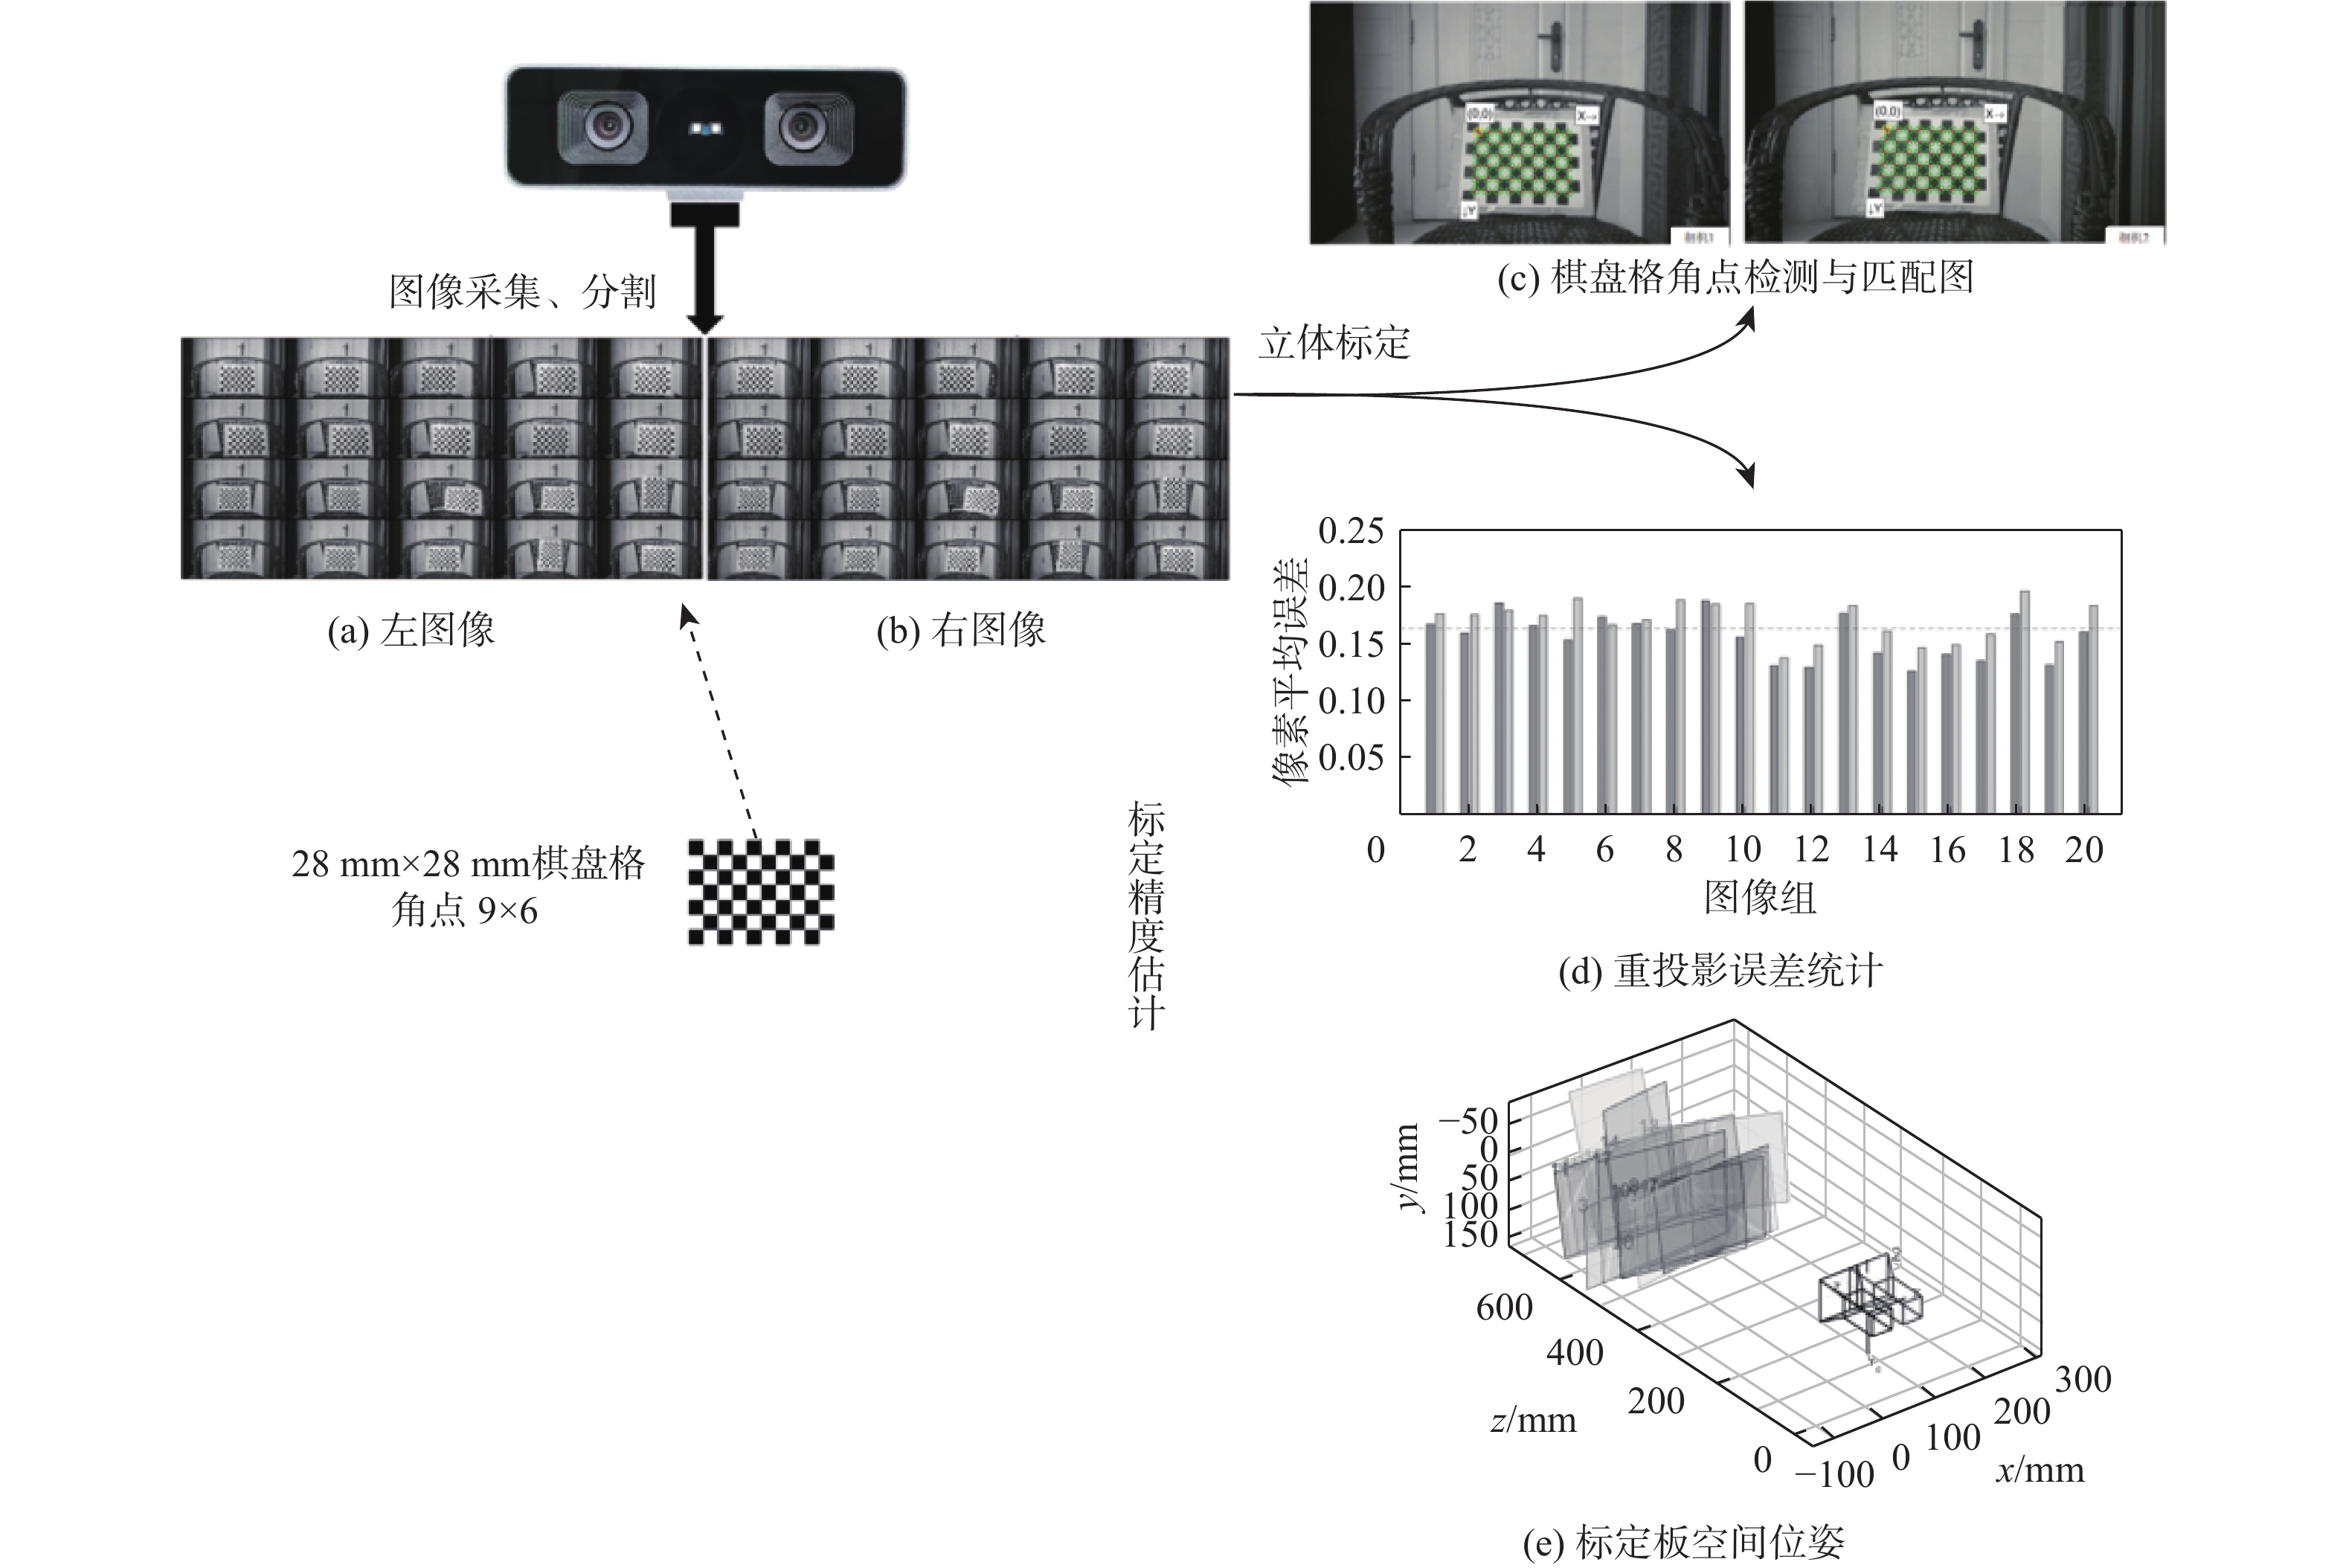
图 2 双目标定原理及标定精度估计
Figure 2. Diagram illustrating the dual-target calibration principle and accuracy estimation plots
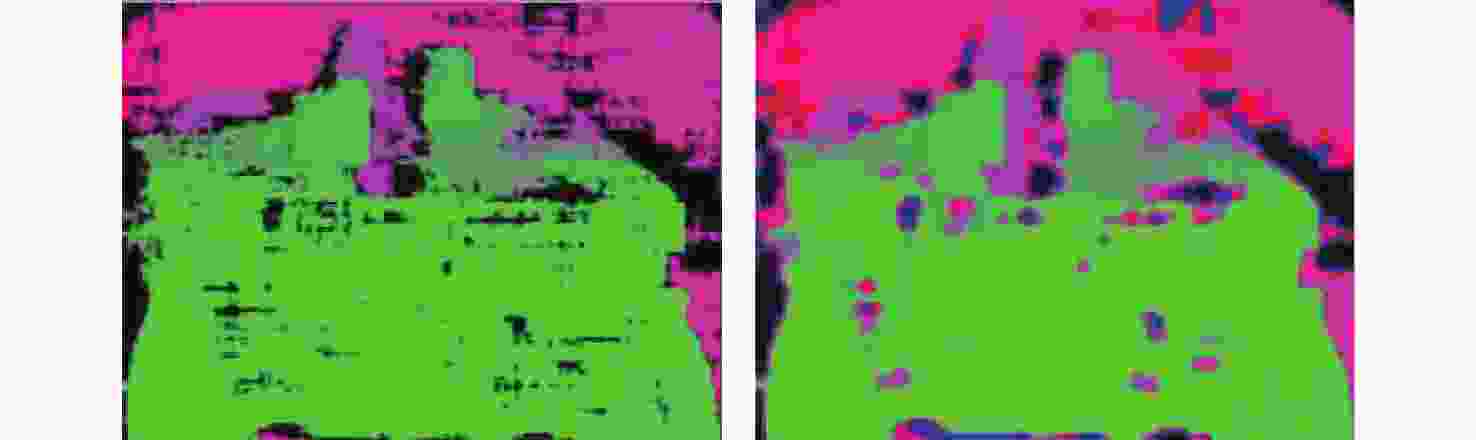
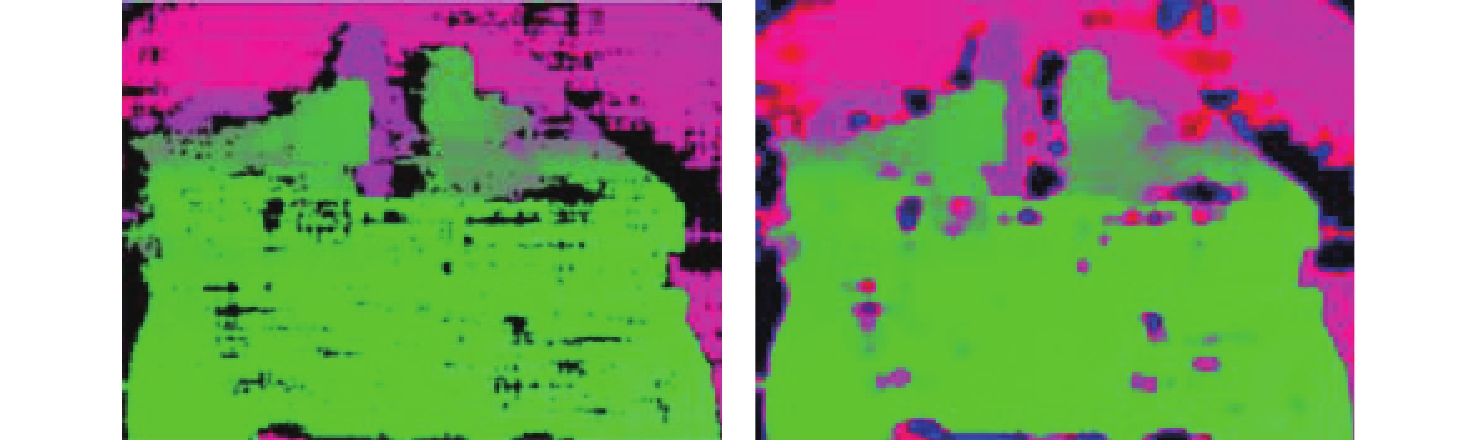
图 4 伪彩色视差图优化前后对比
Figure 4. Comparison of pseudo-color disparity maps before and after optimization
表 1 视差图评估指标
Table 1. Evaluation metrics of disparity maps
优化措施 空洞率/% 有效视差均值 有效视差标准差 有效视差最小值 有效视差最大值 无任何优化 40.700 4 105.226 0 26.795 5 2 255 添加中值滤波 40.178 2 105.171 0 26.851 2 2 255 添加双边滤波 26.332 9 85.594 9 40.453 4 1 254 添加形态学操作 24.885 6 87.183 3 39.624 7 1 242 添加基础插值 1.543 1 66.820 3 50.321 5 1 255 添加非局部均值滤波 1.278 1 66.724 3 50.388 0 1 242  下载: 导出CSV
表 2 目标关键点测距数据
Table 2. Ranging data of target key points
组别 像素坐标/像素 世界坐标/m 测量距离/m 真实距离/m 1 (485,565) (−0.056, 0.076, 0.326) 0.34 0.31 (656,525) (0.011, 0.077, 0.413) 0.42 0.40 (729,547) (0.043, 0.080, 0.379) 0.39 0.38 2 (571,460) (−0.056, 0.086, 0.787) 0.79 0.79 (626,436) (−0.007, 0.075, 0.909) 0.91 0.89 (683,443) (0.051, 0.078, 0.868) 0.87 0.87 3 (688,384) (0.077, 0.026, 1.189) 1.19 1.17 (750,376) (0.169, 0.015, 1.237) 1.25 1.28 (772,382) (0.200, 0.024, 1.231) 1.25 1.23 4 (578,456) (−0.117, 0.196, 1.865) 1.89 1.84 (605,453) (−0.063, 0.201, 1.981) 1.99 1.94 (673,493) (0.085, 0.267, 1.800) 1.82 1.82
下载: 导出CSV
表 3 目标关键点测距绝对误差统计
Table 3. Absolute error statistics of target key point ranging
m 组别 点1绝对误差 点2绝对误差 点3绝对误差 组平均绝对误差 1 0.030 0.020 0.010 0.020 2 0 0.020 0 0.007 3 0.020 −0.030 0.020 0.010 4 0.050 0.050 0 0.033 注:组平均绝对误差平均值为0.018 m。
下载: 导出CSV
表 4 目标关键点测距相对误差统计
Table 4. Relative error statistics of target key point ranging
% 组别 点1相对误差 点2相对误差 点3相对误差 组平均相对误差 1 9.68 5.00 2.63 5.77 2 0 2.25 0 0.75 3 1.71 2.34 1.63 1.89 4 2.72 2.58 0 1.77 注:组平均相对误差平均值为2.55%。
下载: 导出CSV
表 5 立体匹配方法指标对比
Table 5. Comparison of indicators for stereo matching methods
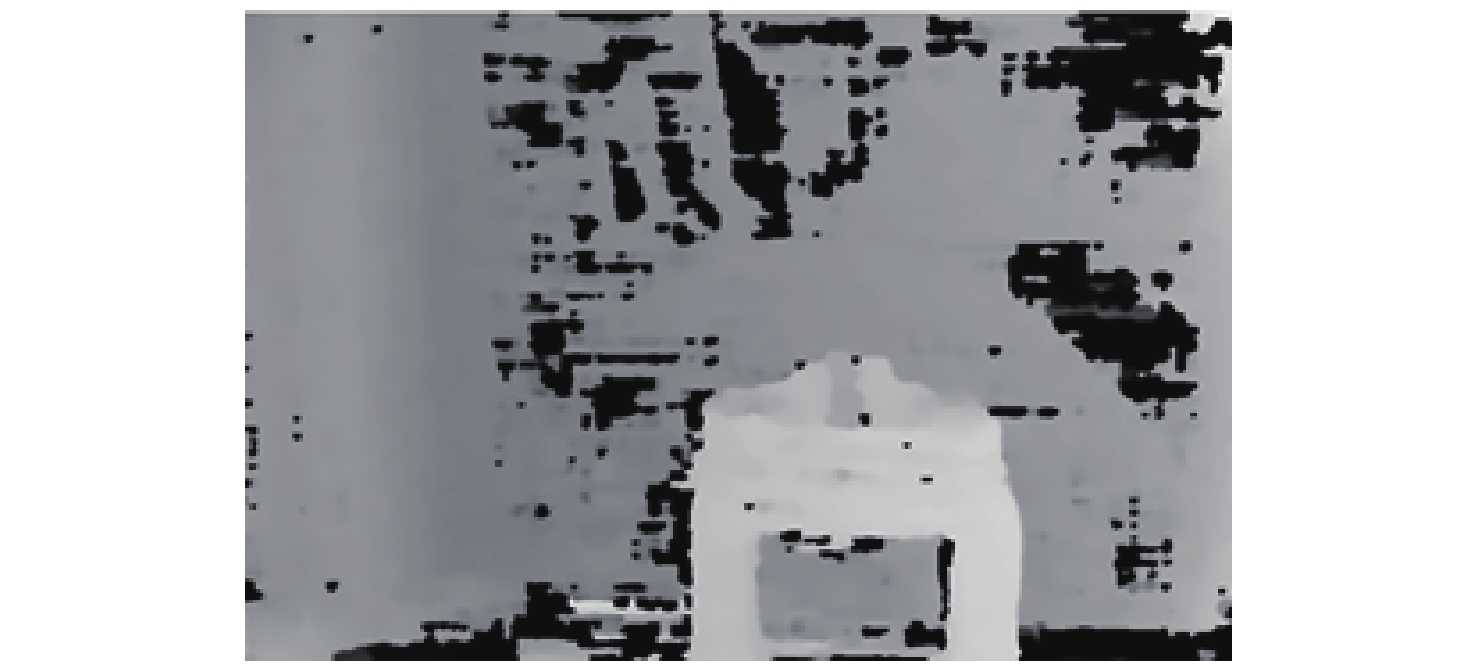
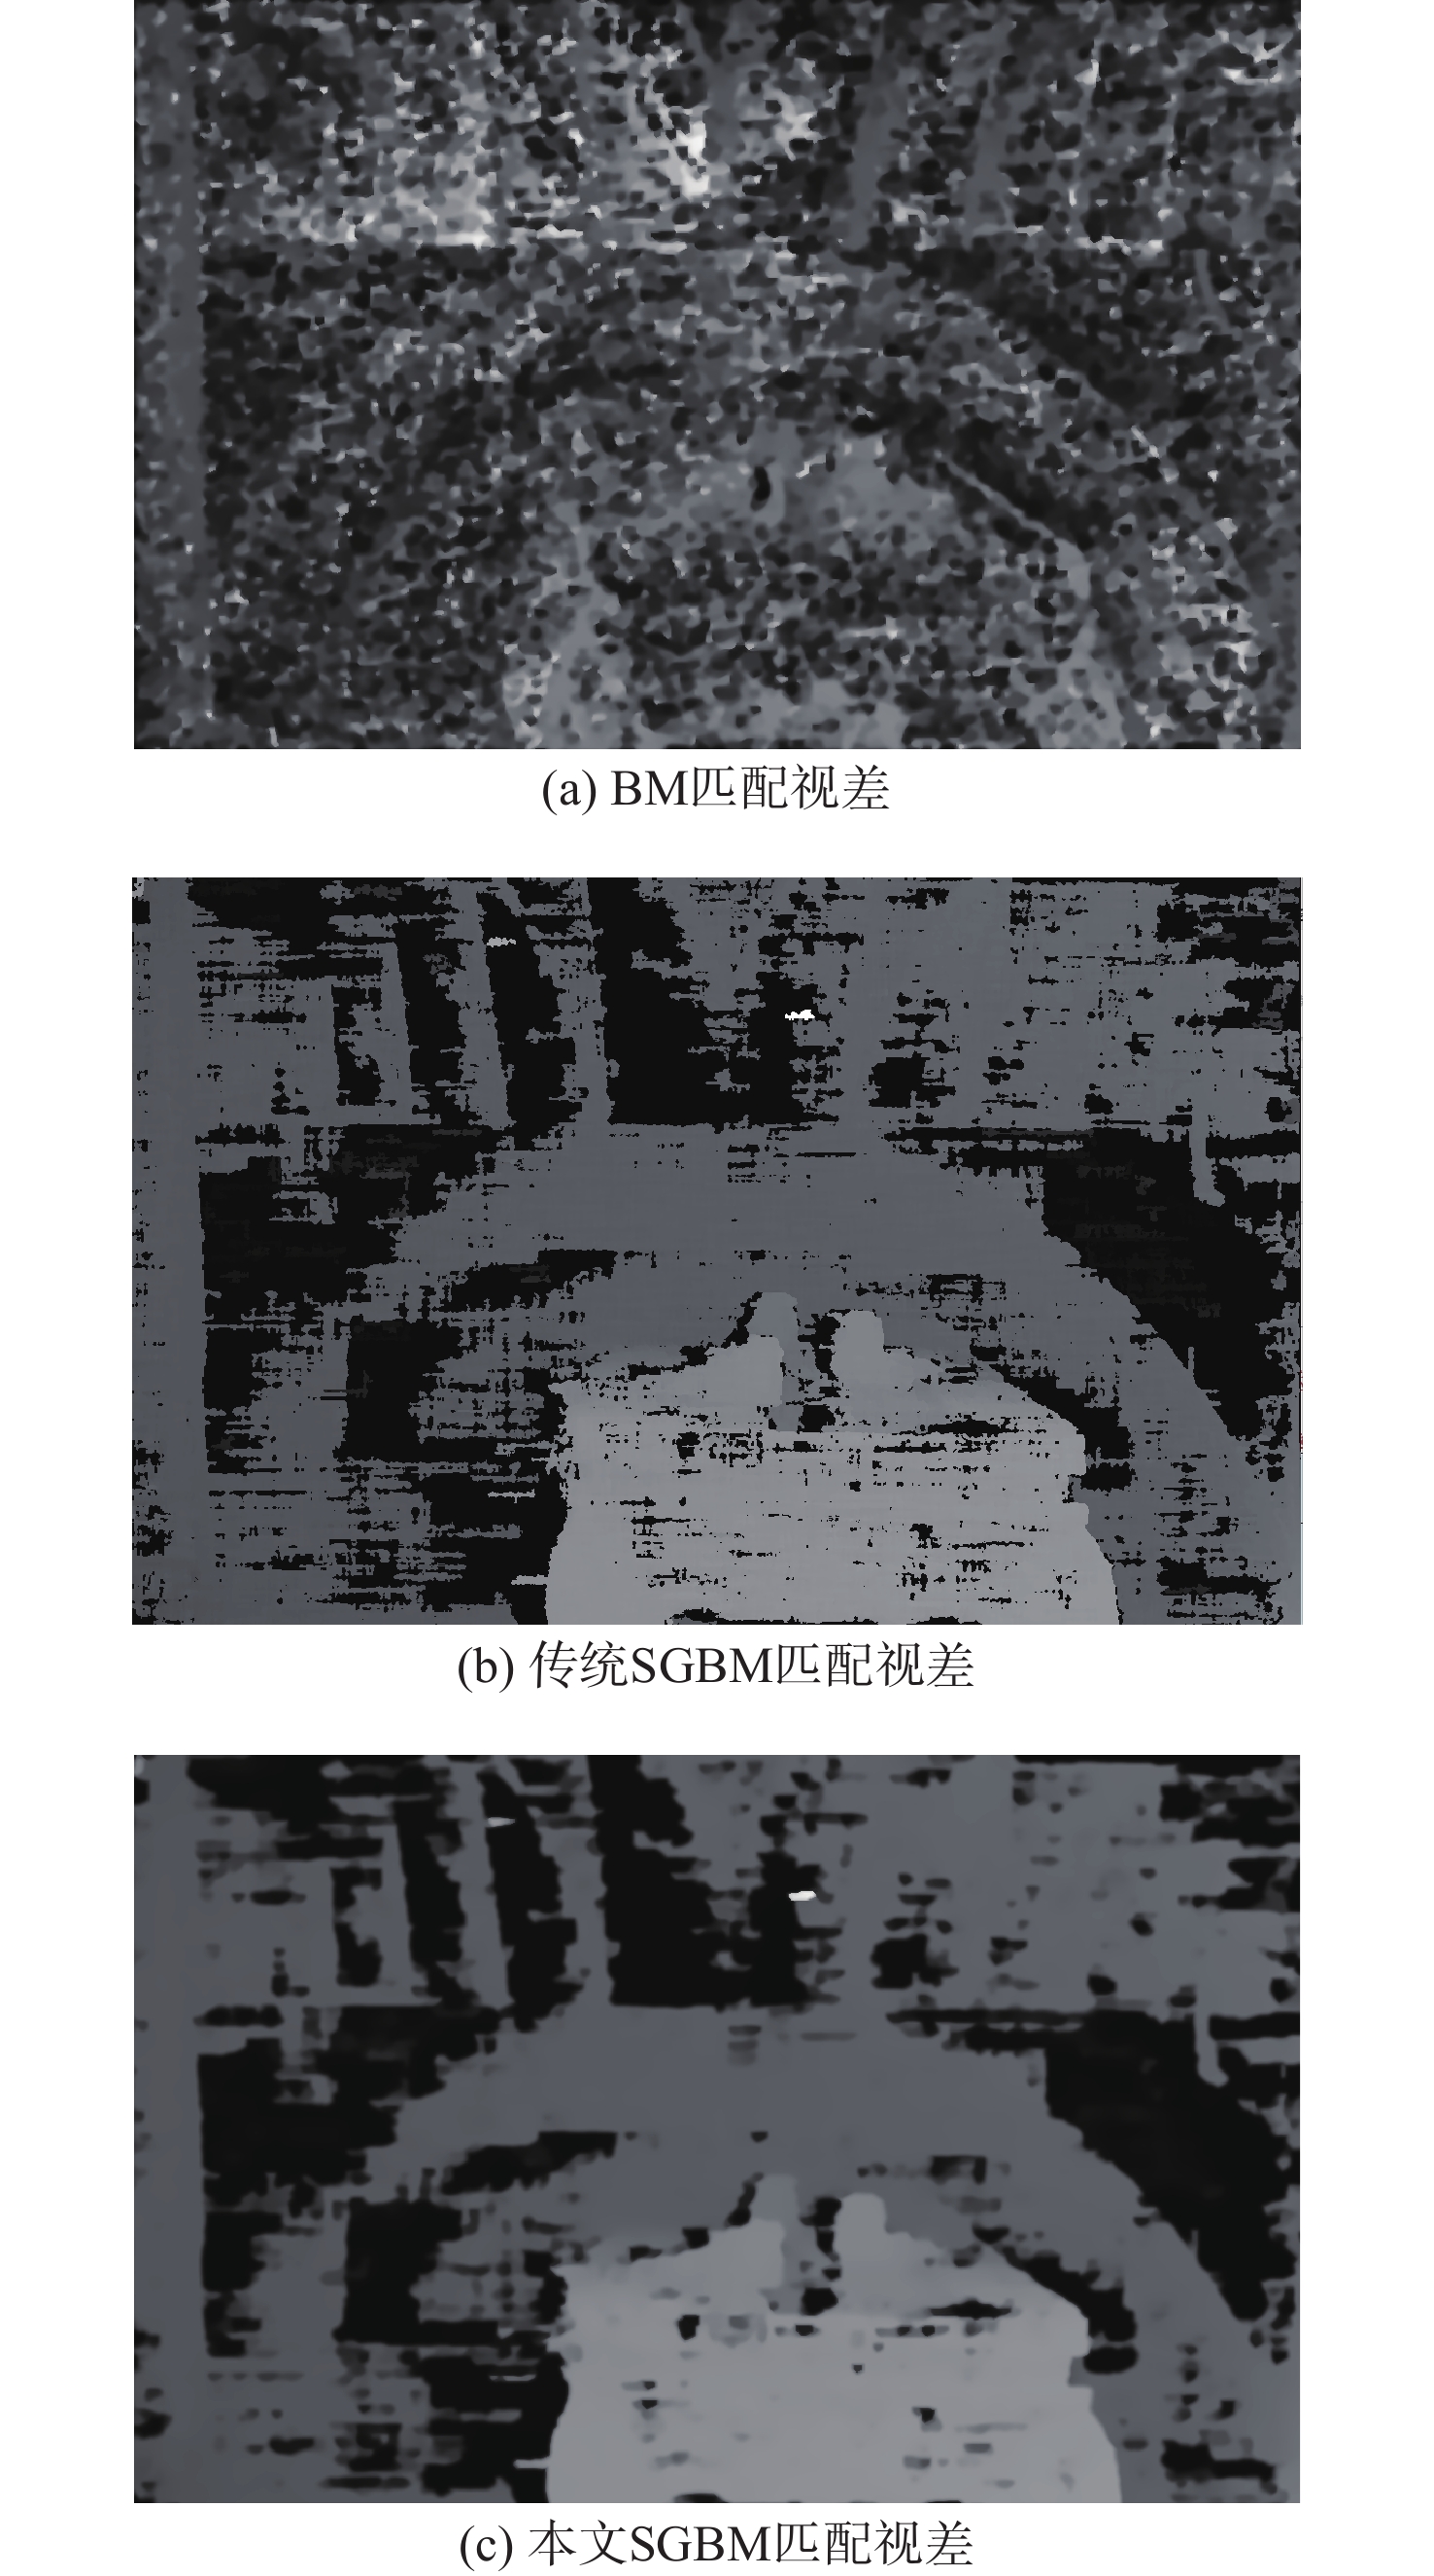
核心算法 空洞率/% 平均相对误差/% 运行时间/ms BM 1.390 0 7.20 413.90 传统SGBM 40.700 4 4.80 241.29 本文SGBM(GPU加速) 1.278 1 2.55 22~35
下载: 导出CSV
表 6 缩比参数
Table 6. Scale factors
原始测距
范围/m距离缩放
因子k扩展
焦距$ {f}_{0} $/mm扩展基
线距$ {b}_{1} $/mm扩展
距离$ {Z}_{1} $/m0.5~2.0 10 $ \begin{aligned}& 3.162 {f}_{0}= \\&10.43\end{aligned} $ $ \begin{aligned}& {3.162 b}_{0}= \\&189.72\end{aligned} $ 5.0~20.0 0.5~2.0 100 $ \begin{aligned}& 10 {f}_{0}= \\& 33.00\end{aligned} $ $ \begin{aligned}& {10 b}_{0}= \\&600.00\end{aligned} $ 50.0~200.0 0.5~2.0 1 000 $ \begin{aligned}& 31.623 {f}_{0}= \\& 104.36\end{aligned} $ $ \begin{aligned}& {31.623 b}_{0}= \\& 1\;897.38\end{aligned} $ 500.0~2 000.0
下载: 导出CSV
-
[1] 张超. 基于信息补偿和特征增强的机场低空飞鸟检测方法研究[D]. 天津: 天津理工大学, 2024.Zhang C. Research on low-altitude flying birds detection method in airport based on information compensation and feature enhancement[D]. Tianjin: Tianjin University of Technology, 2024(in Chinese). [2] Yang Z, Li N, Mao Y, et al. A review of research on safety assurance technology for UAV operation in low-altitude airspace[J]. Journal of Xihua University(Natural Science Edition), 2024, 43(1): 41-47. [3] 王皓, 曹静, 胡佳楠, 等. 基于SfM-MVS的作物三维重建: 挑战与创新[J]. 江苏农业学报, 2024, 40(9): 1768-1776.Wang H, Cao J, Hu J N, et al. Three-dimensional crop reconstruction based on structure from motion-multiple view stereo(SfM-MVS): challenges and innovations[J]. Jiangsu Journal of Agricultural Sciences, 2024, 40(9): 1768-1776(in Chinese). [4] 孙丹, 吴克伟, 孙永宣, 等. 单目图像深度结构恢复研究[J]. 计算机科学与应用, 2018, 8(4): 522-531.Sun D, Wu K W, Sun Y X, et al. Research for scene depth structure of monocular image[J]. Computer Science and Application, 2018, 8(4): 522-531. [5] Chen Z Y, Luo X Y, Dai B C. Design of obstacle avoidance system for micro-UAV based on binocular vision[C]//Proceedings of the 2017 International Conference on Industrial Informatics-Computing Technology, Intelligent Technology, Industrial Information Integration. Piscataway: IEEE Press, 2018: 67-70. [6] Cheng Y, Wu Z T, Shi X Y, et al. Research of 3D reconstruction and position estimation of 3D pieces based on binocular structured light peripheral scanning[J]. Optics and Precision Engineering, 2025, 33(2): 337-347. [7] 赵晨园, 李文新, 张庆熙. 双目视觉的立体匹配算法研究进展[J]. 计算机科学与探索, 2020, 14(7): 1104-1113.Zhao C Y, Li W X, Zhang Q X. Research and development of binocular stereo matching algorithm[J]. Journal of Frontiers of Computer Science & Technology, 2020, 14(7): 1104-1113(in Chinese). [8] 杨晓立, 徐玉华, 叶乐佳, 等. 双目立体视觉研究进展与应用[J]. 激光与光电子学进展, 2023, 60(8): 170-186.Yang X L, Xu Y H, Ye L J, et al. Research progress on binocular stereo vision applications[J]. Laser & Optoelectronics Progress, 2023, 60(8): 170-186(in Chinese). [9] 陈舒雅. 基于深度学习的立体匹配技术研究[D]. 杭州: 浙江大学, 2022.Chen S Y. Study on deep learning based stereo matching technologies[D]. Hangzhou: Zhejiang University, 2022(in Chinese). [10] 李云涛. 基于深度学习的立体匹配技术研究[D]. 成都: 西南交通大学, 2023.Li Y T. Stereo matching technique based on deep learning[D]. Chengdu: Southwest Jiaotong University, 2023(in Chinese). [11] 李明彩, 郭轩, 于毅. 基于Matlab平台的相机标定研究[J]. 数字技术与应用, 2018, 36(2): 85-87.Li M C, Guo X, Yu Y. Analysis of camera calibration based on Matlab platform[J]. Digital Technology and Application, 2018, 36(2): 85-87(in Chinese). [12] Birchfield S , Tomasi C. Depth discontinuities by pixel-to-pixel stereo[J]. International Journal of Computer Vision, 1999, 35(3): 269-293. [13] 王镭. 双边滤波中关键技术研究[D]. 哈尔滨: 哈尔滨工程大学, 2017.Wang L. Key technology research of bilateral filter[D]. Harbin: Harbin Engineering University, 2017(in Chinese). [14] 李肖成, 惠旭龙, 白春玉, 等. 民机结构坠撞性能缩比实验方法研究[J]. 爆炸与冲击, 2025, 45(7): 071411.Li X C, Hui X L, Bai C Y, et al. Research on scaled experimental method of civil aircraft crash performance[J]. Explosion and Shock Waves, 2025, 45(7): 071411(in Chinese). [15] 尹宜勇, 张伟杰, 白翰钦. 大型管道系统缩比模型模态实验平台设计[J]. 实验技术与管理, 2021, 38(8): 90-93.Yin Y Y, Zhang W J, Bai H Q. Design of modal experiment platform for scaled model of large-scale pipeline system[J]. Experimental Technology and Management, 2021, 38(8): 90-93(in Chinese). -

 下载:

 点击查看大图
计量
- 文章访问数: 335
- HTML全文浏览量: 248
- PDF下载量: 10
- 被引次数: 0
