


A safety-evaluation-driven UAV swarm collision avoidance decision-making based on pigeon-inspired optimization
-
摘要:
为提高无人机(UAV)集群在复杂环境中的避碰能力与协同效率,提出一种考虑安全性评估的无人机集群鸽群优化(PIO)避碰决策机制。通过分析无人机集群局部冲突风险与整体网络协调程度,构建多维安全性评估指标体系;利用主成分分析法对集群状态进行综合安全评估,并将避碰决策分为安全、警戒与高危3个阶段。基于综合安全性评估得分动态调节的人工势场函数,实现个体避碰控制参数的自适应调整。为进一步提升高风险状态下集群全局避碰协同效率,引入PIO算法对无人机运动方向与避碰参数进行协同优化。仿真测试结果表明:所提方法在保持集群稳定性的同时有效降低了局部冲突概率,验证了该方法的有效性与实用性。
Abstract:This research proposes an adaptive avoidance decision-making mechanism that combines safety assessment with pigeon-inspired optimization (PIO) to enhance the collision avoidance capabilities and coordination efficiency of unmanned aerial vehicle (UAV) swarms operating in complicated environments. A multidimensional safety evaluation index system is constructed by analyzing both local conflict risks and the overall coordination level of the swarm. Principal component analysis is employed to derive a comprehensive safety score, based on which a three-stage avoidance control strategy is formulated. An artificial potential field function with adaptively tuned parameters is designed according to the safety score, enabling responsive and autonomous individual-level control. Furthermore, to improve global cooperative avoidance under high-risk scenarios, the improved PIO algorithm is embedded to jointly optimize the velocity direction and avoidance parameters of swarm members. The effectiveness and resilience of the suggested strategy in dynamic contexts are validated by simulation findings, which show that it dramatically lowers the likelihood of local conflicts while preserving swarm cohesion.
-
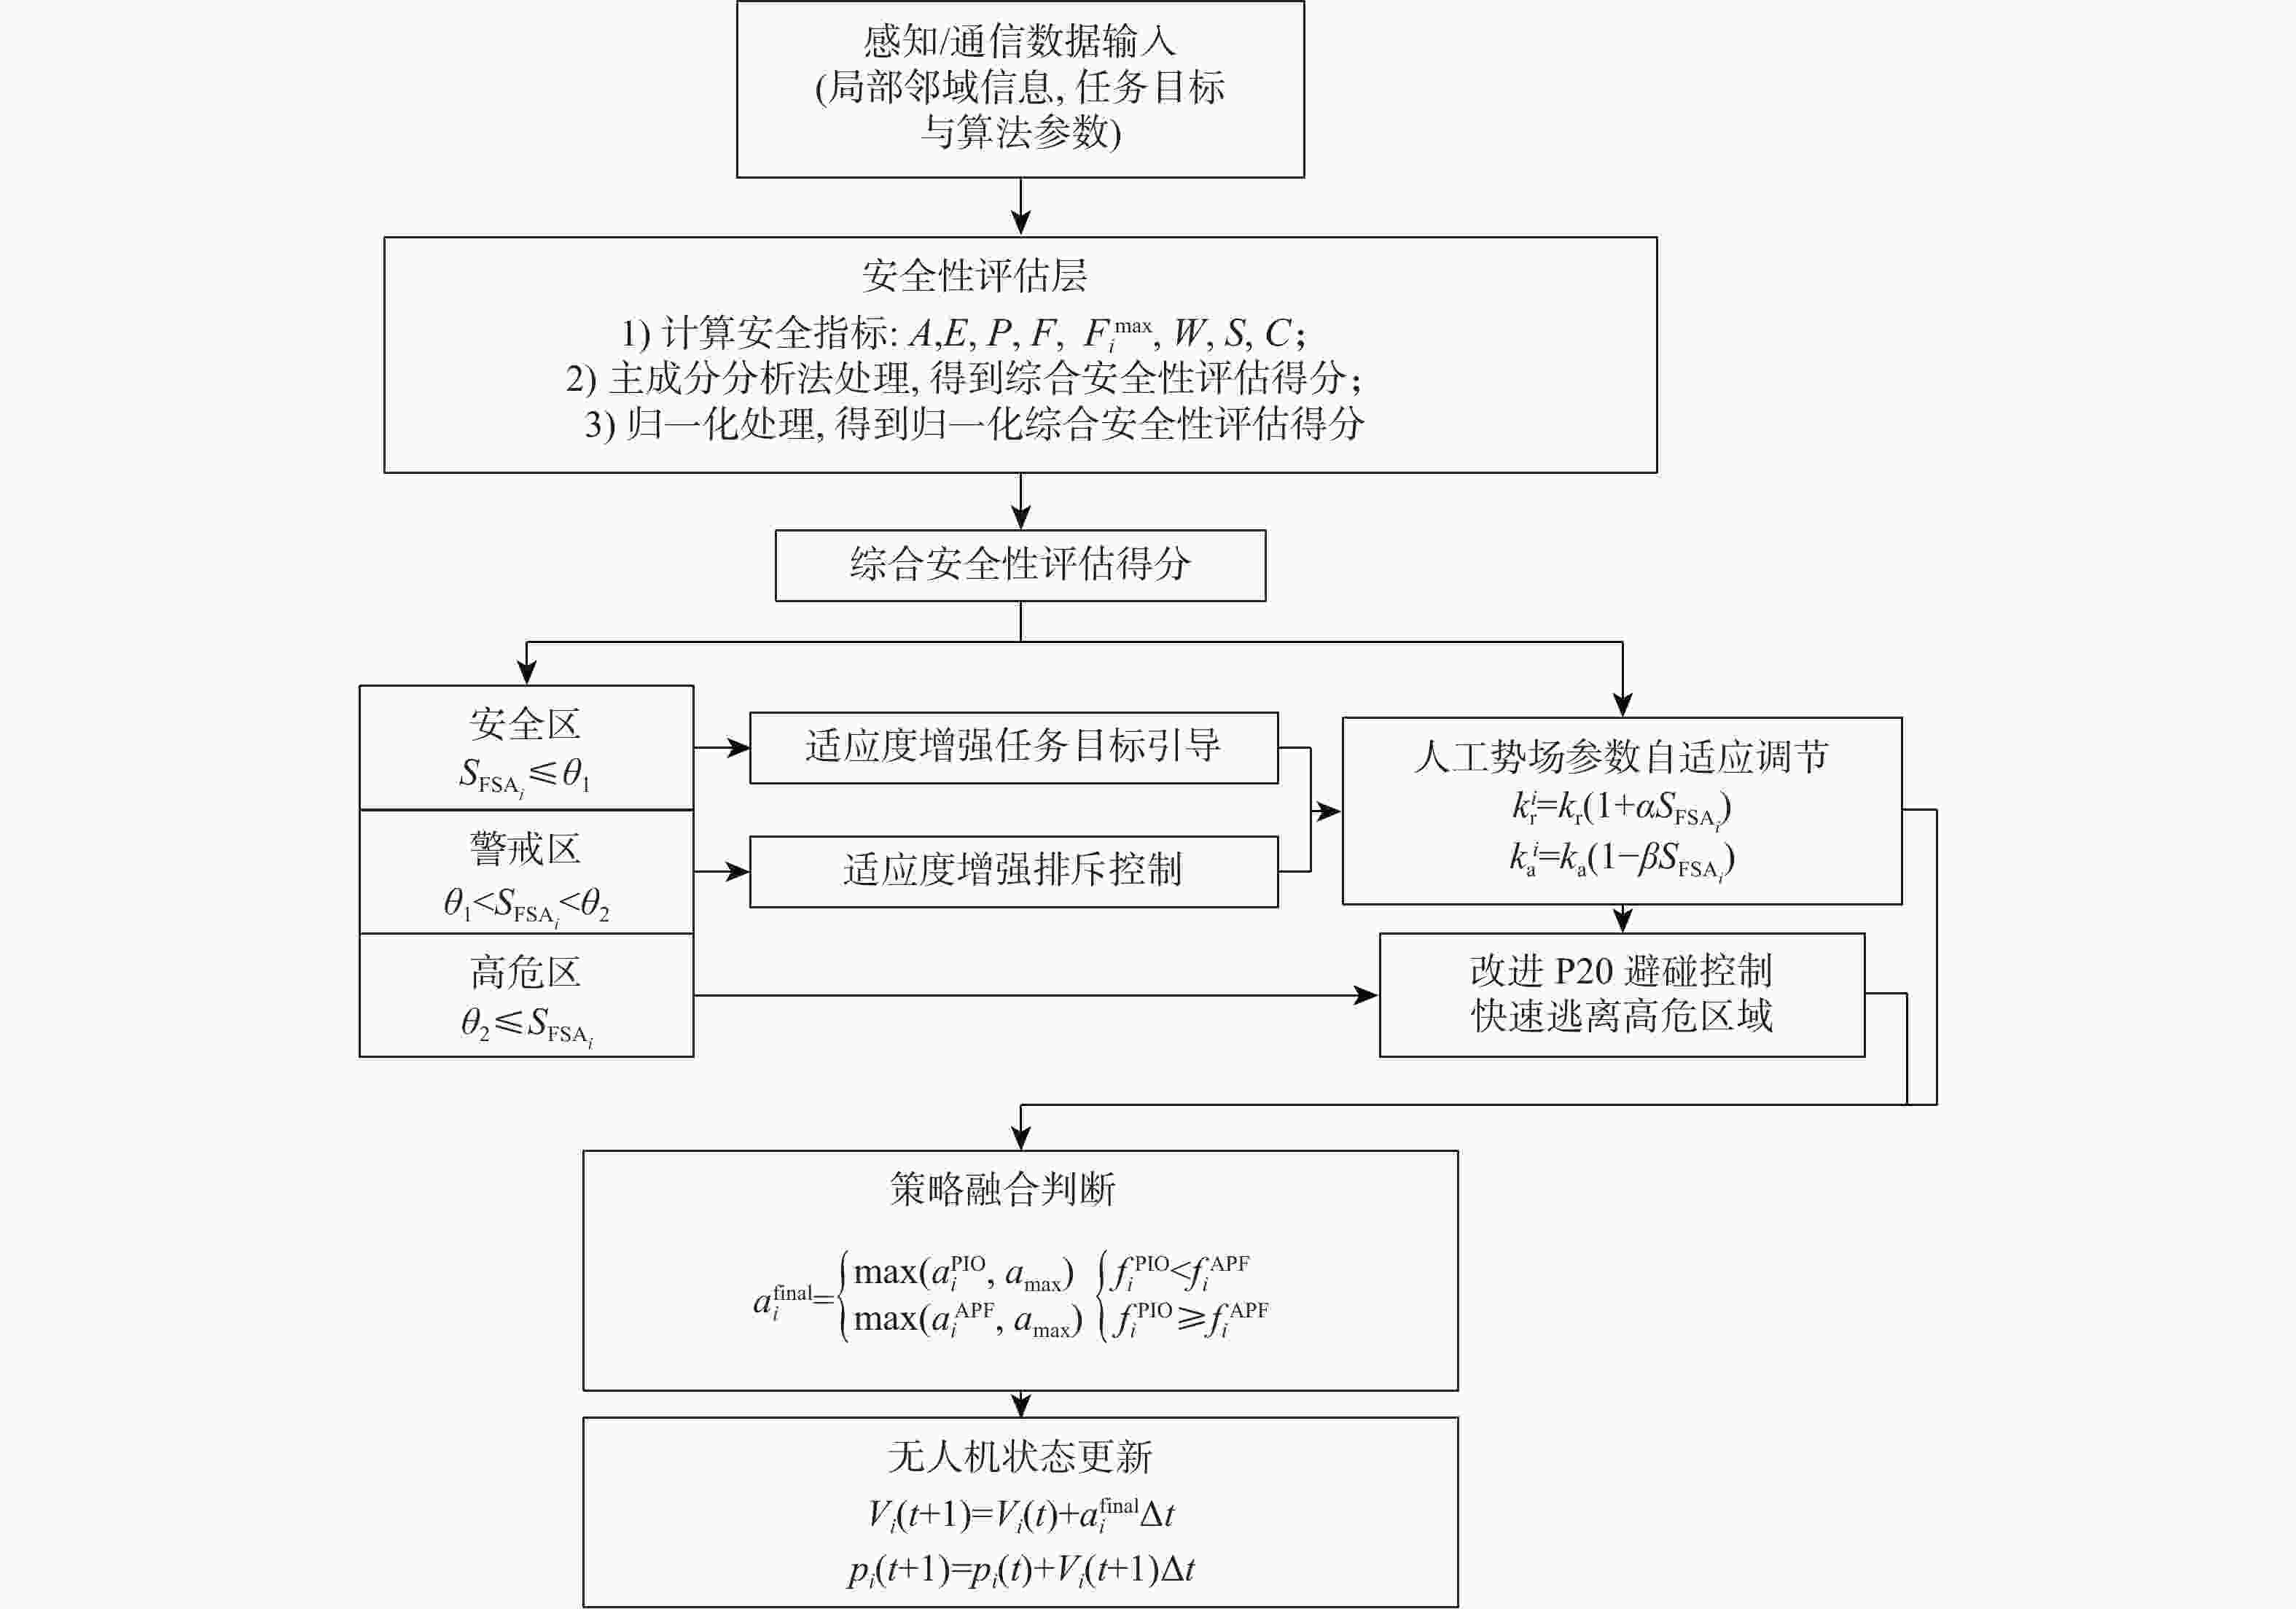
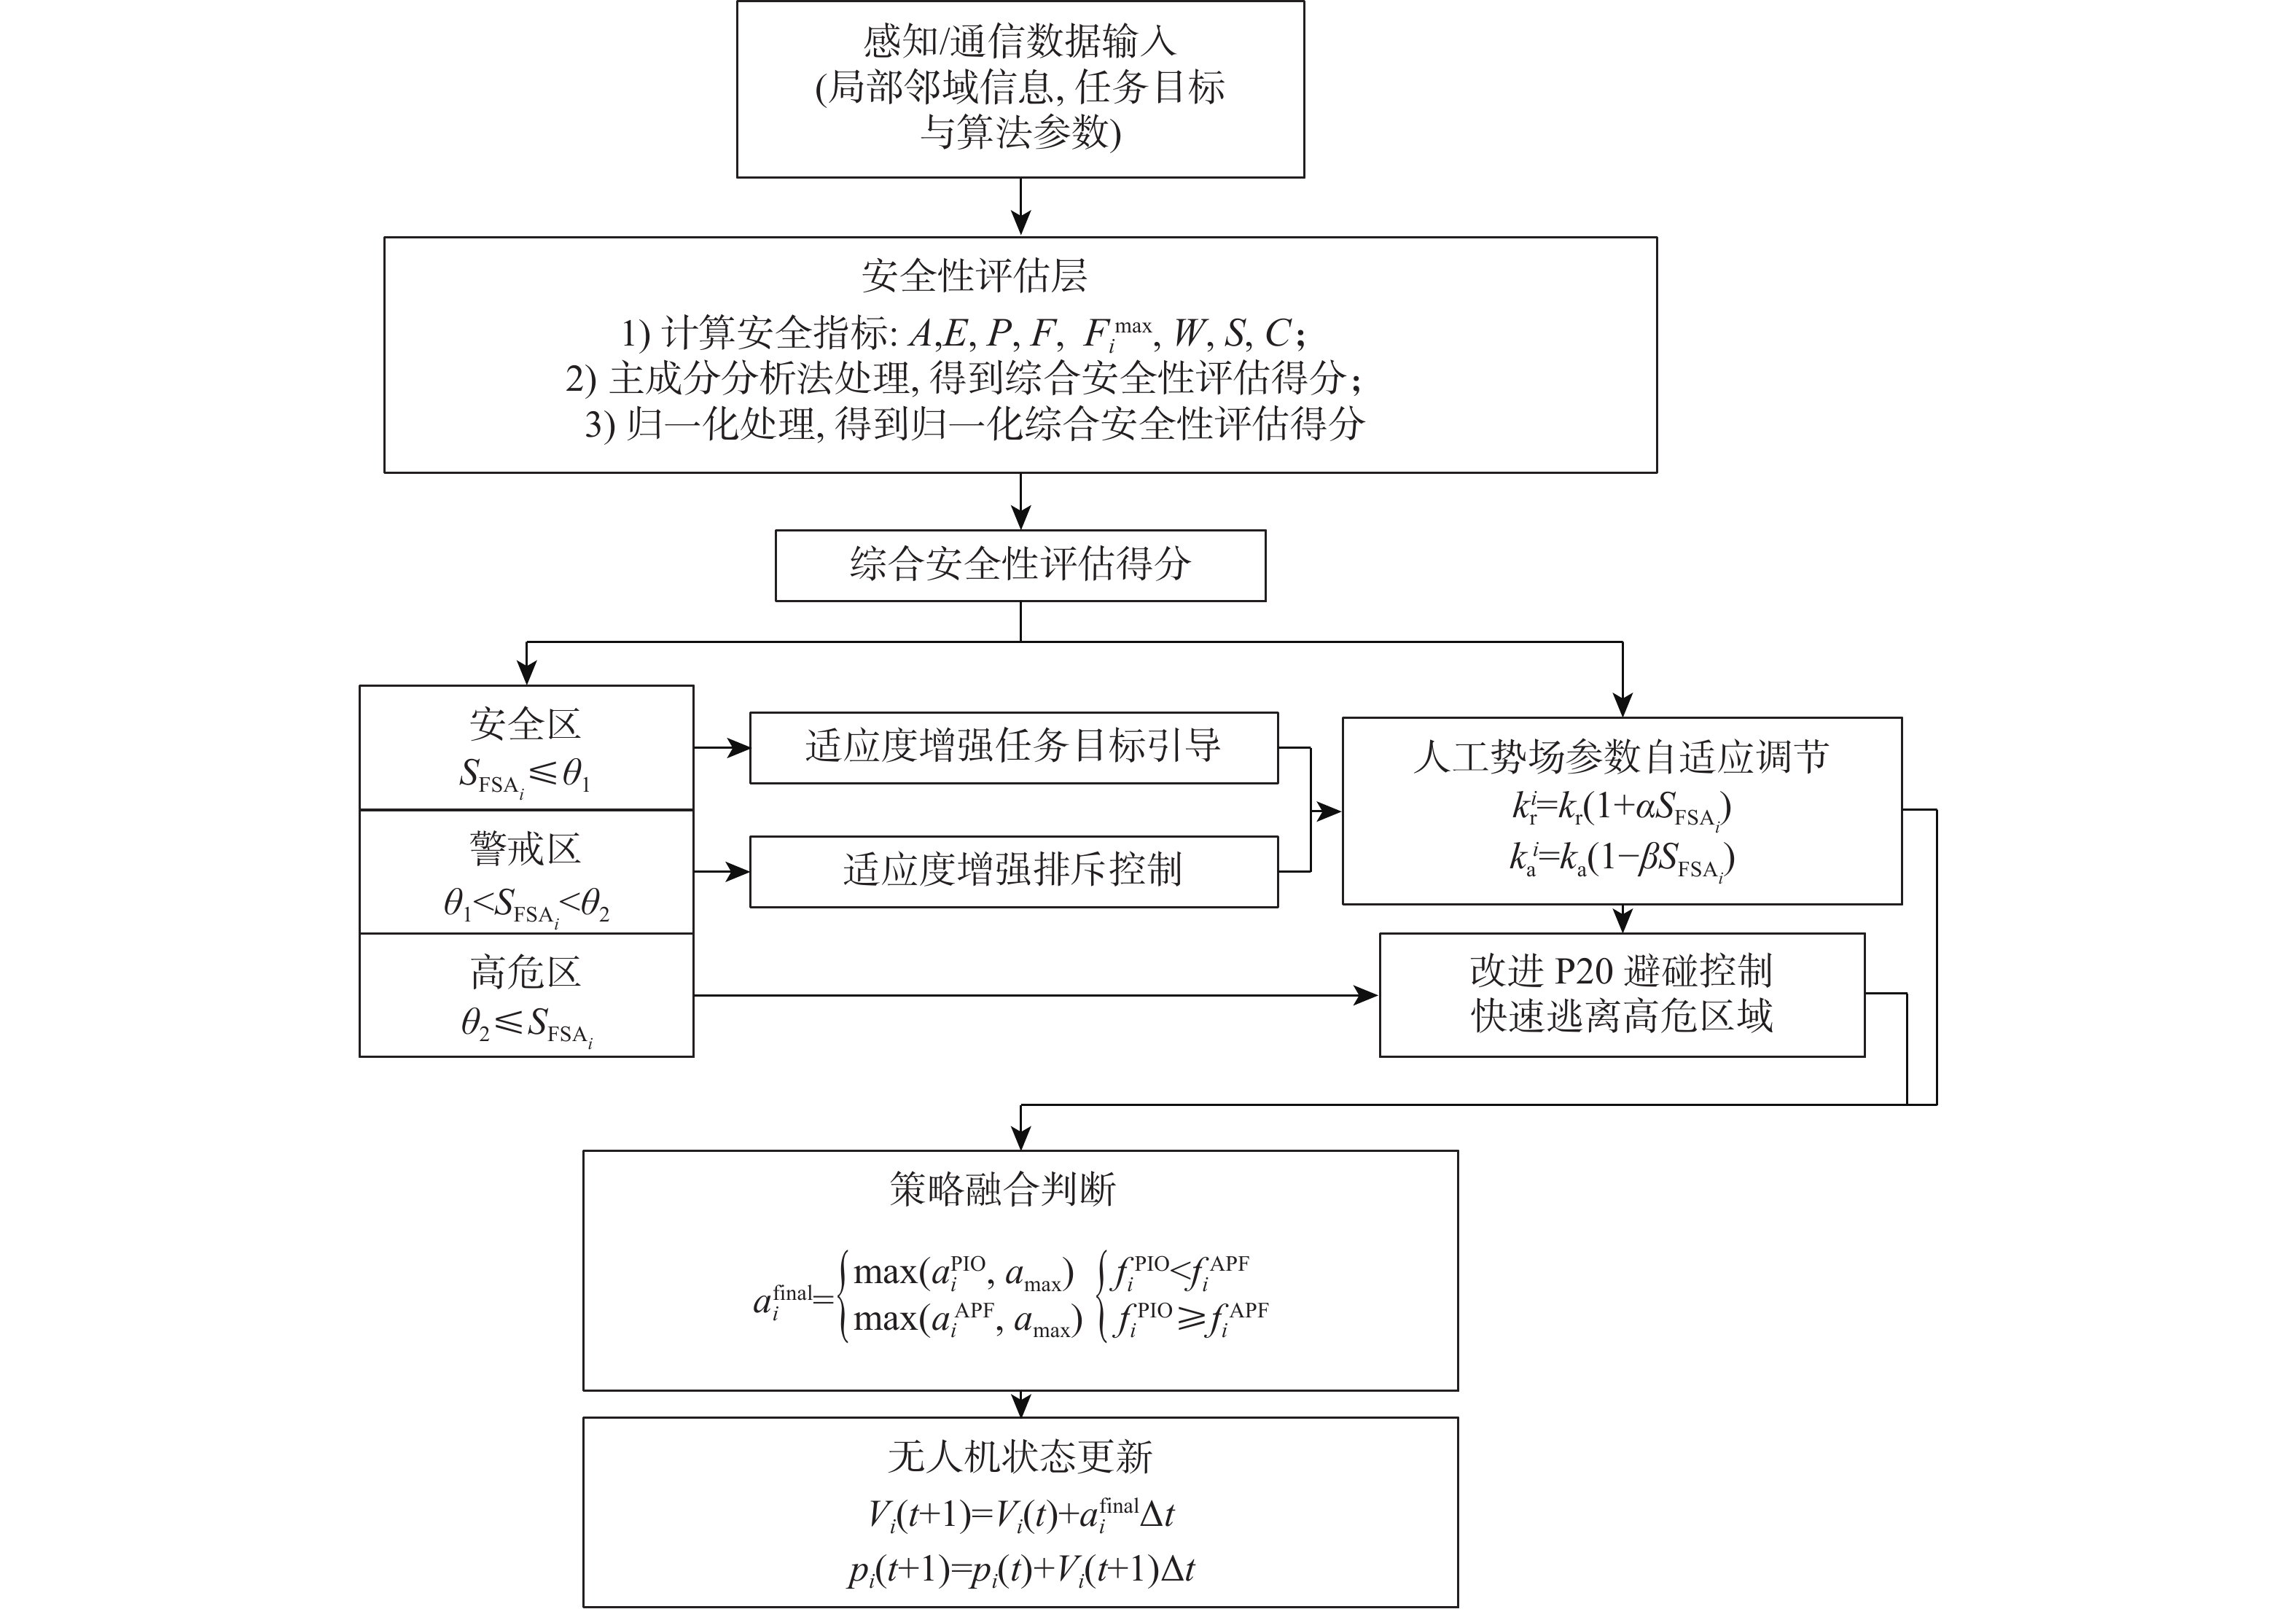
图 2 安全等级驱动避碰决策框架
Figure 2. Framework of security-level-driven collision avoidance decision
表 1 无人机集群安全等级划分
Table 1. UAV swarm security classification
等级 综合安全性评估得分 模式类型 控制策略 安全区 $ {S}_{{\mathrm{FSA}}i}\leqslant {\theta }_{1} $ 协同前进 吸引力占主导,维持队形或
目标引导警戒区 $ {\theta }_{1}< {S}_{{\mathrm{FSA}}i}< {\theta }_{2} $ 正常避碰 平衡吸引力与排斥力,
进行协调避碰高危区 $ {\theta }_{2}\leqslant {S}_{{\mathrm{FSA}}i} $ 紧急避碰 排斥权重最大化,抑制吸引力,
优化避碰注:$ {\theta }_{1} $、$ {\theta }_{2} $为策略阈值,可根据任务需求设定。  下载: 导出CSV
表 2 算法参数
Table 2. Parameters of algorithms
算法 参数 数值 APF 吸引力系数ka 5 排斥力系数kr 15 排斥力作用阈值d0/m 200 权重调节灵敏度系数α 0.75 权重调节灵敏度系数β 0.75 PIO 鸽子种群数量Np 20 地图和指南针算子迭代次数Nc1 100 地标算子迭代次数Nc2 80 地图和指南针因子r 0.02
下载: 导出CSV
表 3 安全性评估指标数据
Table 3. Data on security assessment indicators
指标 A E Fmax W S C $ {F}_{i} $ 冲突次数 APF 1.42 117.80 19.30 5.10 0.49 0.53 0.75 5.10 PSO 1.17 96.50 14.70 4.60 0.42 0.45 0.67 2.40 PIO 1.12 91.10 13.50 4.40 0.38 0.41 0.62 1.20 FSA-PIO(本文) 0.95 78.90 10.20 3.80 0.32 0.35 0.51 0.20
下载: 导出CSV
-
[1] Sharma R R, Ghose D. Collision avoidance between UAV clusters using swarm intelligence techniques[J]. International Journal of Systems Science, 2009, 40(5): 521-538. [2] Javed S, Hassan A, Ahmad R, et al. State-of-the-art and future research challenges in UAV swarms[J]. IEEE Internet of Things Journal, 2024, 11(11): 19023-19045. [3] Huang S Y, Zhang H B, Huang Z Y. E2CoPre: energy efficient and cooperative collision avoidance for UAV swarms with trajectory prediction[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(7): 6951-6963. [4] Rezaee M R, Hamid N A W A, Hussin M, et al. Comprehensive review of drones collision avoidance schemes: challenges and open issues[J]. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(7): 6397-6426. [5] Debnath D, Vanegas F, Sandino J, et al. A review of UAV path-planning algorithms and obstacle avoidance methods for remote sensing applications[J]. Remote Sensing, 2024, 16(21): 4019. [6] Roberge V, Tarbouchi M, Labonte G. Comparison of parallel genetic algorithm and particle swarm optimization for real-time UAV path planning[J]. IEEE Transactions on Industrial Informatics, 2013, 9(1): 132-141. [7] Zhou X, Zhu J C, Zhou H Y, et al. EGO-swarm: a fully autonomous and decentralized quadrotor swarm system in cluttered environments[C]//2021 IEEE International Conference on Robotics and Automation (ICRA). Piscataway: IEEE Press, 2021: 4101-4107. [8] Wu Z Y, Dong S P, Yuan M, et al. Rotate artificial potential field algorithm toward 3D real-time path planning for unmanned aerial vehicle[J]. Proceedings of the Institution of Mechanical Engineers, Part G: Journal of Aerospace Engineering, 2023, 237(4): 940-955. [9] Zhang Y X, Chen J B, Chen M, et al. Integrated the artificial potential field with the leader-follower approach for unmanned aerial vehicles cooperative obstacle avoidance[J]. Mathematics, 2024, 12(7): 954. [10] Cao L J, Wang L, Liu Y, et al. 3D trajectory planning based on the rapidly-exploring random tree-connect and artificial potential fields method for unmanned aerial vehicles[J]. International Journal of Advanced Robotic Systems, 2022, 19(5): 172988062211188. [11] 朱元军, 李妍, 张学军, 等. 基于风险约束的城市空域无人机安全路径规划[J/OL]. 北京航空航天大学学报, 2025(2025-04-29)[2025-07-01]. https://doi.org/10.13700/j.bh.1001-5965.2024.0 843.Zhu Y J, Li Y, Zhang X J, et al. Risk-constrained safe path planning for unmanned aerial vehicle in urban airspace[J/OL]. Journal of Beijing University of Aeronautics and Astronautics, 2025(2025-04-29)[2025-07-01]. https://doi.org/10.13700/j.bh.1001-5965.2024.0843(in Chinese). [12] Hao H, Xue Y, Zhai G, et al. UAV path planning based on improved artificial potential field method[J]. Aerospace, 2023, 10(6): 562. [13] Wang M, Zhong Y L, Zhang Y H, et al. Unmanned aerial vehicle formation control method based on improved artificial potential field and consensus[J]. IET Control Theory & Applications, 2024, 18(18): 2555-2567. [14] Chang X F, Jiao J Y, Li Y N, et al. Multi-consensus formation control by artificial potential field based on velocity threshold[J]. Frontiers in Neuroscience, 2024, 18: 1367248. [15] Duan H B, Qiu H X. Advancements in pigeon-inspired optimization and its variants[J]. Science China Information Sciences, 2019, 62(7): 70201. [16] Chen W K, Hai X S, Hu Y M, et al. Hierarchical decision-making framework for multi-UAV task assignment via enhanced pigeon-inspired optimization[J]. Guidance, Navigation and Control, 2023, 3(4): 2350028. [17] Hu C H, Xia Y, Zhang J G. Adaptive operator quantum-behaved pigeon-inspired optimization algorithm with application to UAV path planning[J]. Algorithms, 2019, 12(1): 3. [18] Shen Y K, Liu X N, Ma X, et al. A bionic social learning strategy pigeon-inspired optimization for multi-unmanned aerial vehicle cooperative path planning[J]. Applied Sciences, 2025, 15(2): 910. [19] Sun Y B, Chen Y, Wei C, et al. Swarm maneuver decision method based on learning-aided evolutionary pigeon-inspired optimization for UAV swarm air combat[J]. Drones, 2025, 9(3): 218. [20] Tisdale J, Kim Z, Hedrick J K. Autonomous UAV path planning and estimation[J]. IEEE Robotics & Automation Magazine, 2009, 16(2): 35-42. [21] Lei Y Q, She Z K, Quan Q. Pigeon-inspired UAV swarm control and planning within a virtual tube[J]. Drones, 2025, 9(5): 333. [22] 陈艺君, 余莎莎, 张学军. 城市低空场景下无人机运行对地风险量化评估[J]. 北京航空航天大学学报, 2025, 51(3): 806-815.Chen Y J, Yu S S, Zhang X J. Ground risk quantitative assessment for UAV operations in urban low-altitude scenarios[J]. Journal of Beijing University of Aeronautics and Astronautics, 2025, 51(3): 806-815(in Chinese). [23] Li S M, Cheng X C, Huang X D, et al. Cooperative conflict detection and resolution and safety assessment for 6G enabled unmanned aerial vehicles[J]. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(2): 2183-2198. [24] Chen E, Chen X, Jing W B, et al. Distributed tensor principal component analysis with data heterogeneity[J]. Journal of the American Statistical Association, 2025, 120(552): 2619-2631. [25] 梅艺林, 崔立堃, 胡雪岩, 等. 基于人工势场法的复杂环境下多无人车避障与编队控制[J]. 工程科学学报, 2025, 47(2): 364-373.Mei Y L, Cui L K, Hu X Y, et al. Obstacle avoidance and formation control of multiple unmanned vehicles in complex environments based on artificial potential field method[J]. Chinese Journal of Engineering, 2025, 47(2): 364-373(in Chinese). [26] Zhang Z, Jiang J, Ling K V, et al. Real-time path planning for autonomous UAVs: an event-triggered multimodal adaptive pigeon-inspired optimization approach[J]. IEEE Transactions on Aerospace and Electronic Systems, 2025, 61(4): 10972-10981. -

 下载:


 点击查看大图
计量
- 文章访问数: 255
- HTML全文浏览量: 202
- PDF下载量: 10
- 被引次数: 0
