


-
摘要:
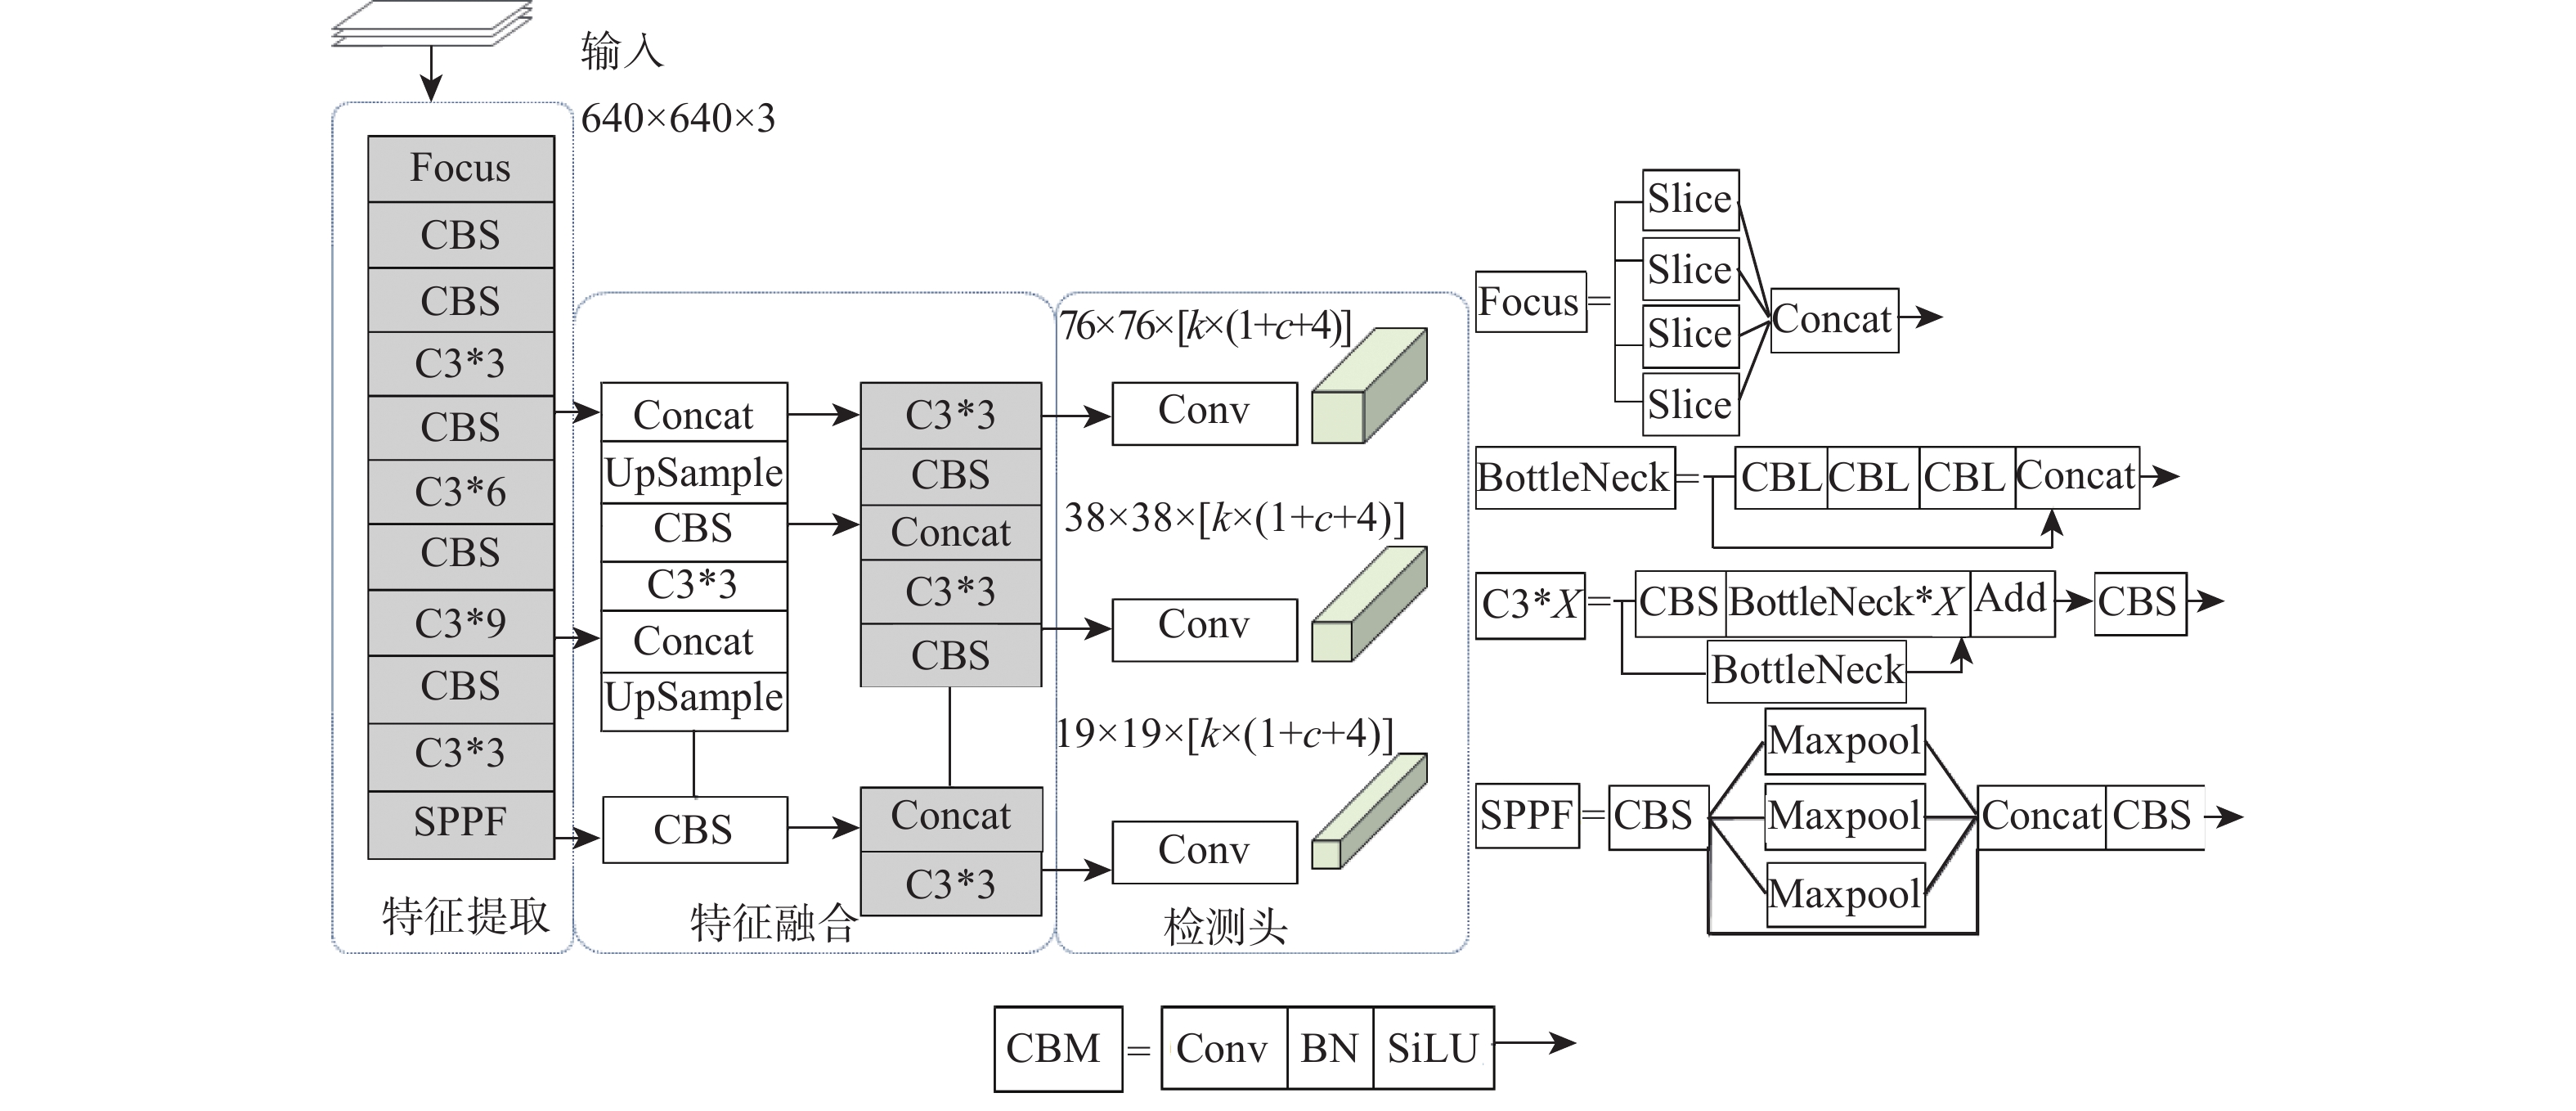
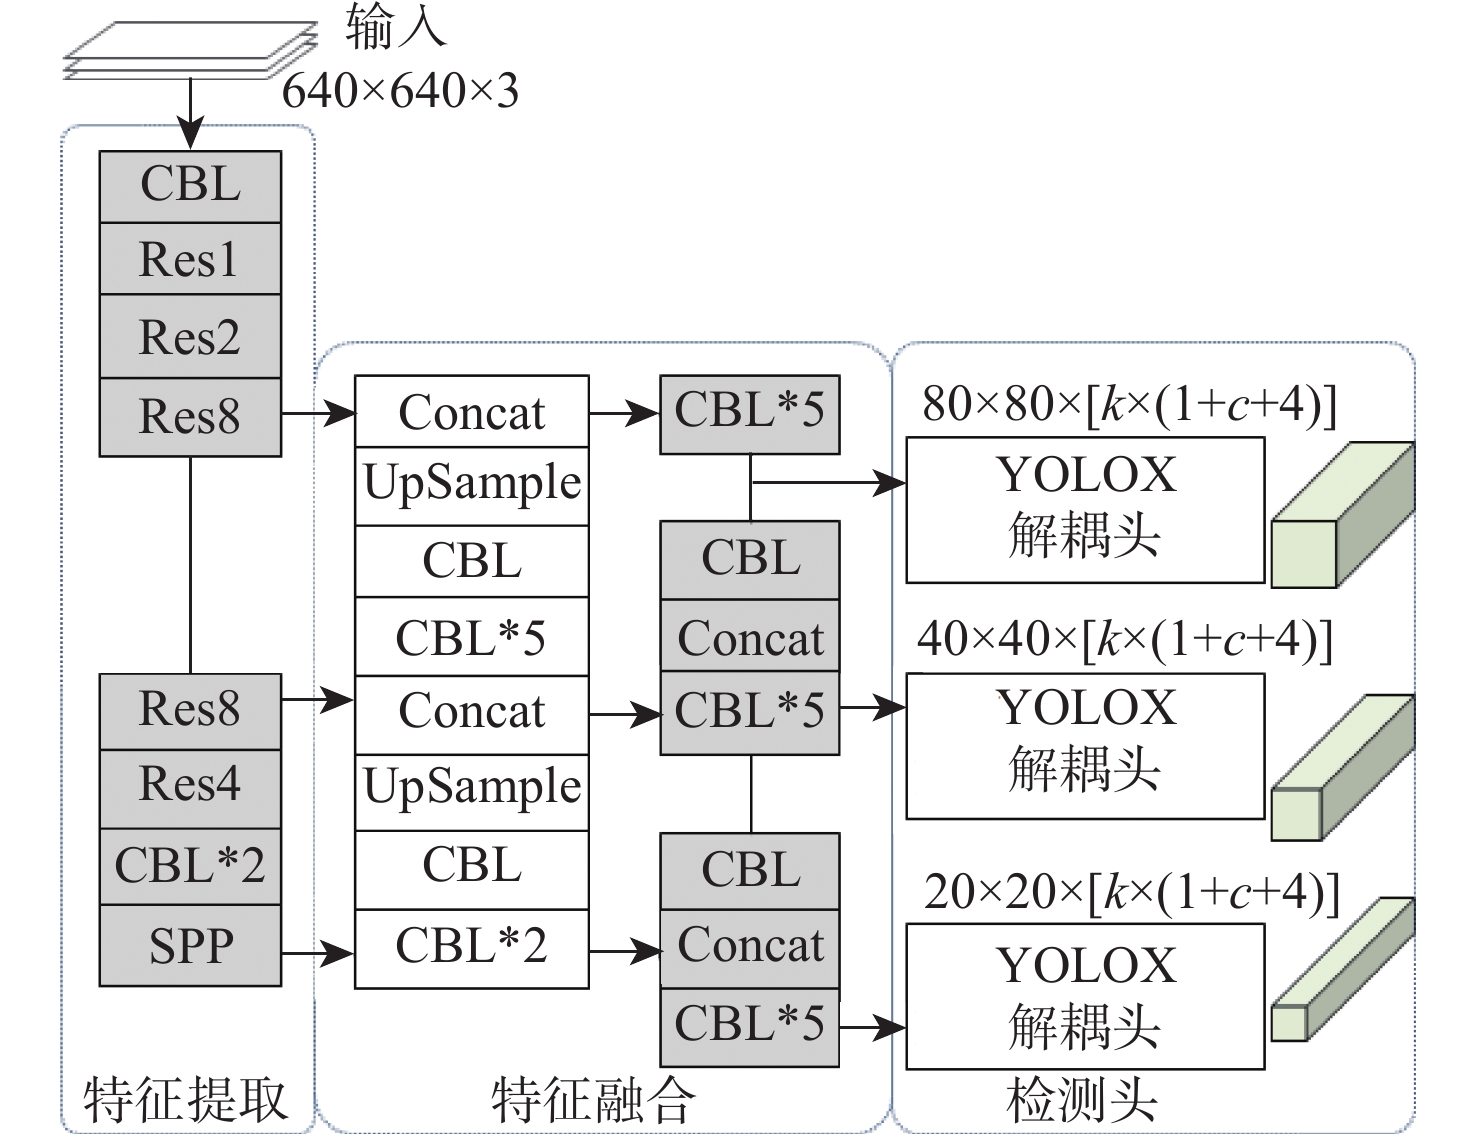
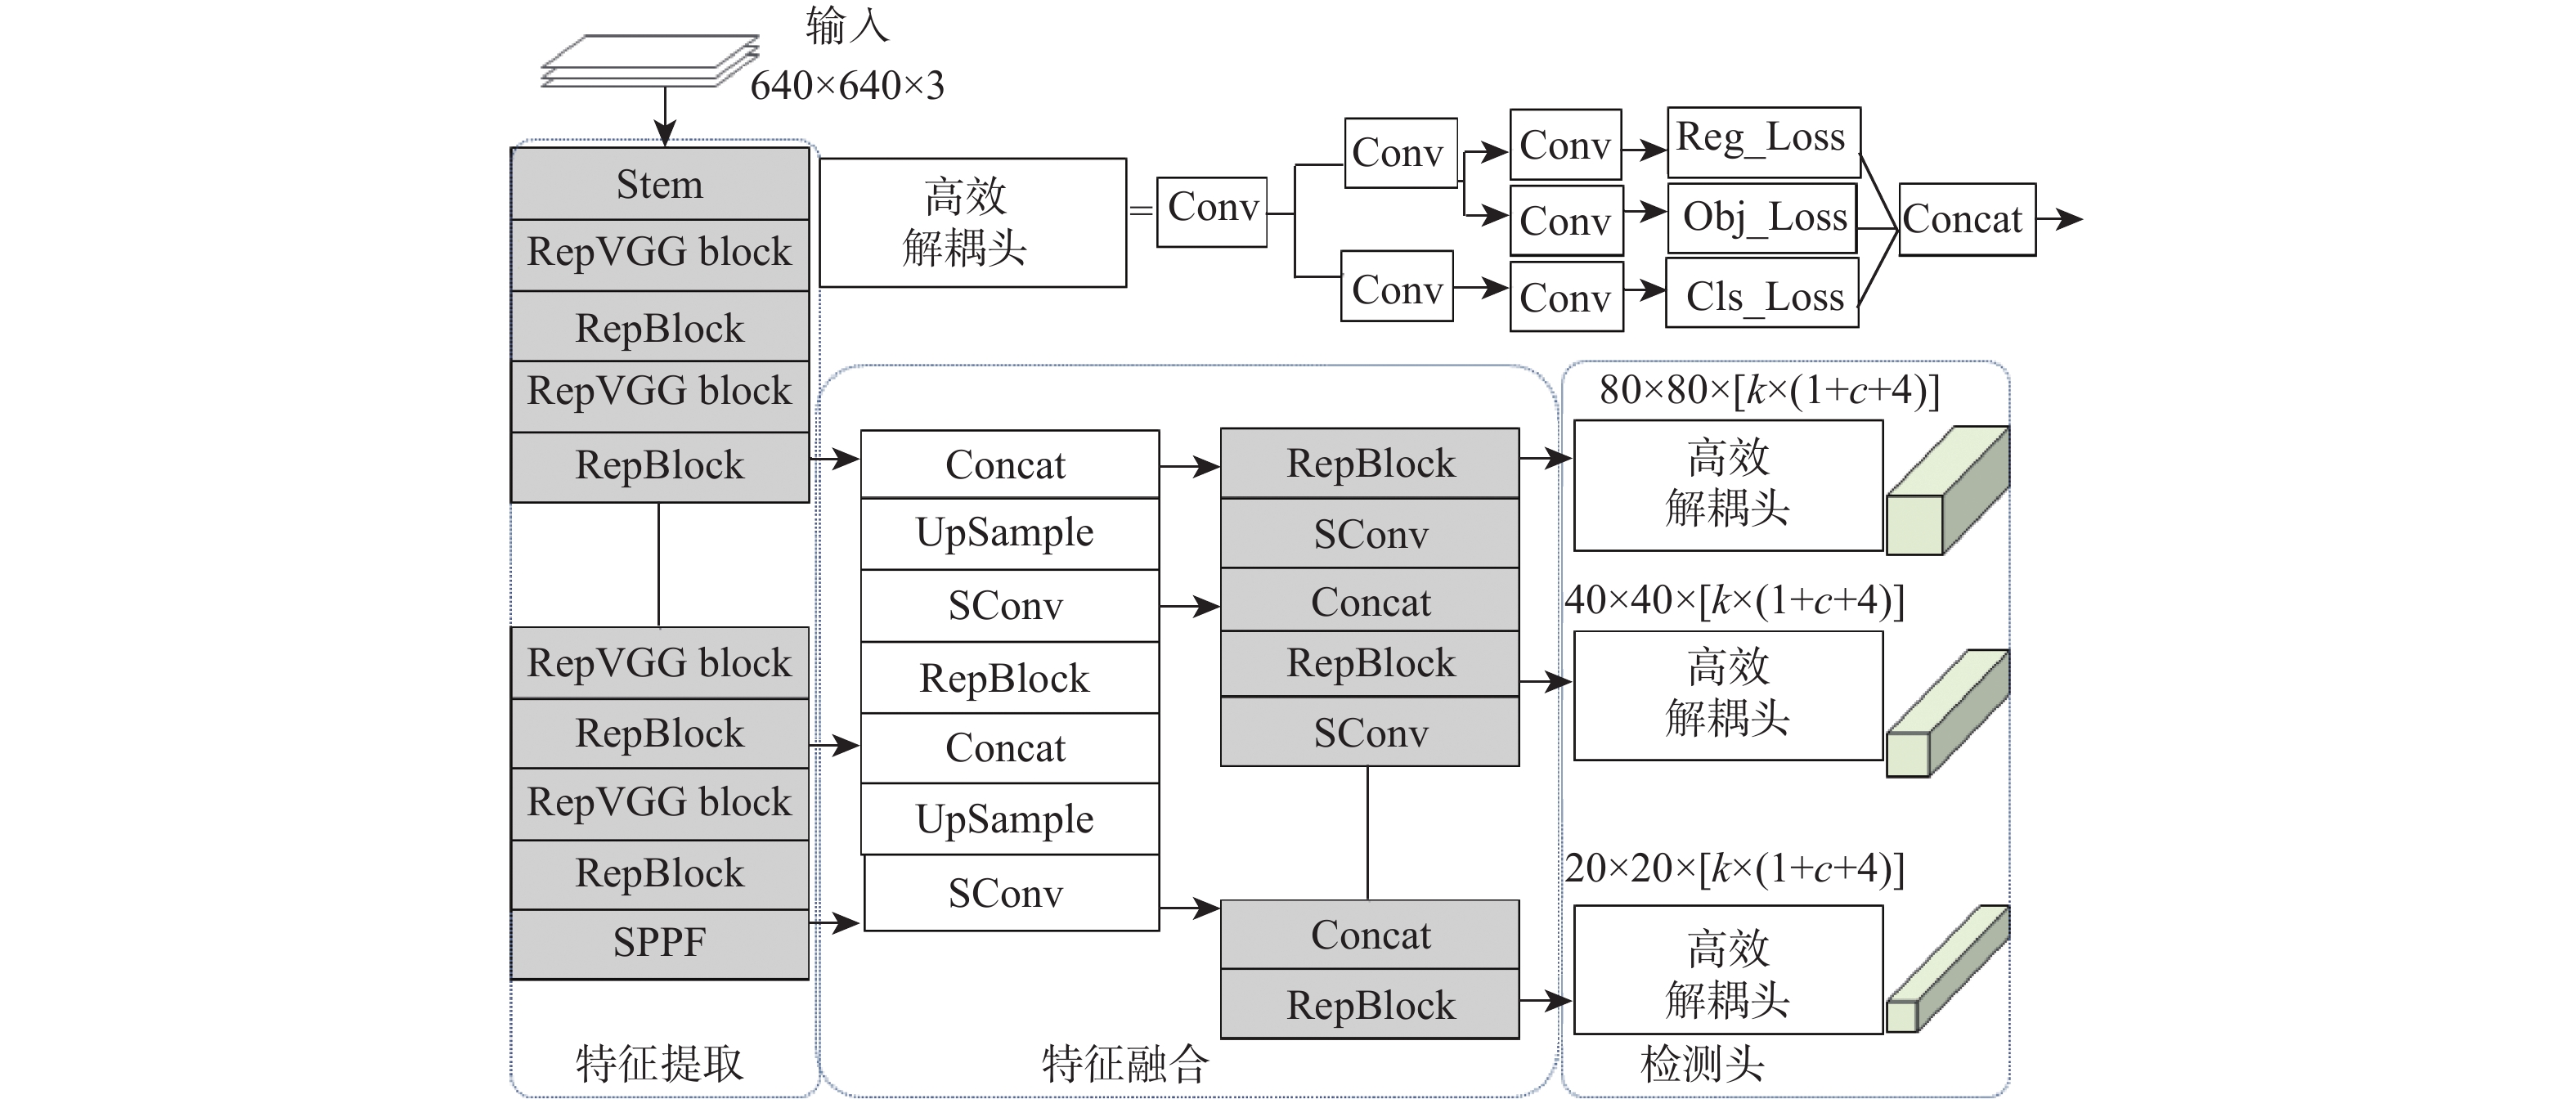
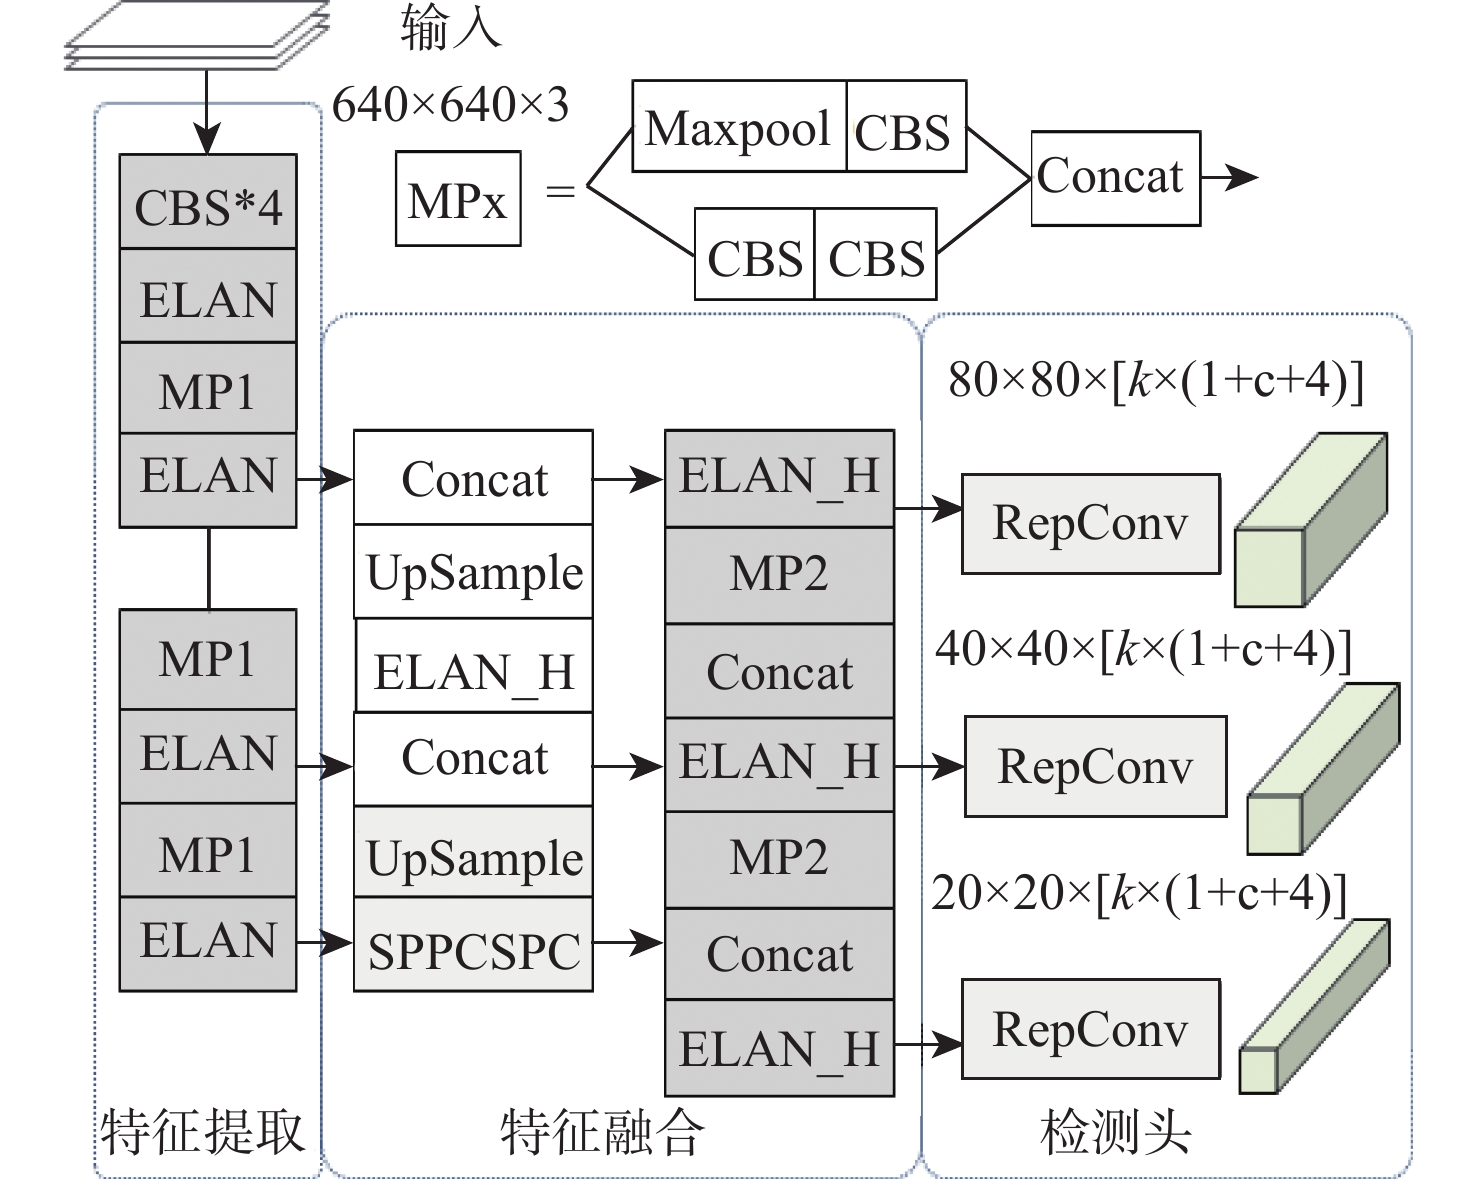
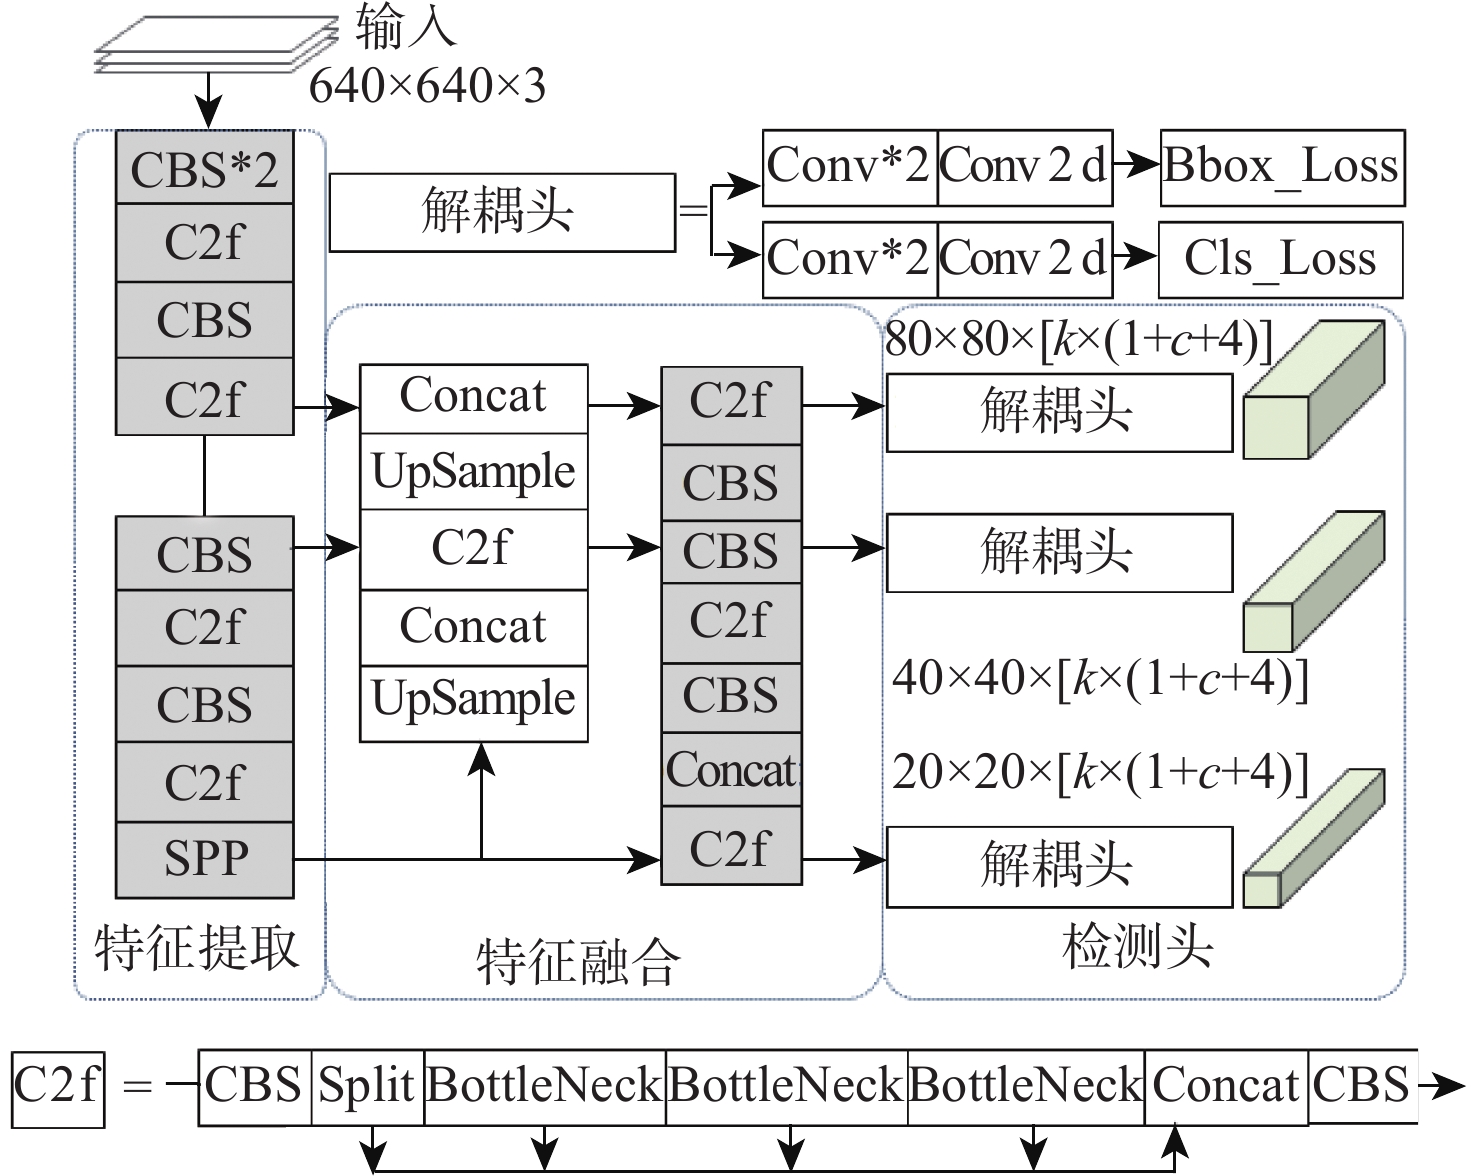
在诸多基于深度学习的目标检测算法中,YOLO系列算法因具有检测速度快、检测精度高、适应性强等优点,成为无人机(UAV)航拍图像目标检测的优先选择。UAV航拍图像与视频复杂多变的特点使该视角下YOLO系列目标检测算法成为一个具有挑战性的难题,因此,有必要将近期UAV视角下目标检测的YOLO系列算法研究与应用成果进行全面总结与分析。归纳10种YOLO基础版本的发展、联系、优化特点,重新绘制YOLO系列结构图,指出各种YOLO版本优化策略的作用与特点。综述在UAV目标检测应用领域中YOLO的优化方法数据训练前的预处理、训练与推理优化、注意力模块的应用、卷积优化、检测头及损失函数的优化;梳理UAV视角下的应用数据集及数据扩展方法。通过实验对UAV视角下数据集上YOLO系列算法的性能及卷积块注意力模块(CBAM)对YOLO不同改进的作用进行评估。指出了UAV视角下目标检测YOLO系列算法的研究还存在的一些问题与可能发展趋势。
Abstract:The you only look once (YOLO) series of deep learning-based object identification algorithms has several advantages, including great adaptability, high detection accuracy, and quick detection speed. Make it the preferred choice for object detection in drone aerial images. Due to the complex and ever-changing nature of aerial images and videos captured by drones, the YOLO series object detection algorithms from the UAV vision have become a challenging problem. Therefore, it is necessary to comprehensively summarize and analyze the recent research and application achievements of YOLO series algorithms for object detection from the UAV vision. Firstly, the YOLO structural diagram is redrawn and the development, connection, and optimization features of the 10 fundamental versions of YOLO are summarized. The roles and objectives of various YOLO optimization strategies are pointed out, indicating the direction for further theoretical research. Secondly, the optimization methods of YOLO in the application field of drone object detection are summarized. This includes preprocessing before data training, optimization of training and inference, application of attention modules, convolutional optimization, detection heads, and optimization of loss functions. At the same time, some application datasets and data expansion methods from the UAV vision are sorted out. Through studies, the effectiveness of YOLO series algorithms on the UAV vision dataset and the influence of convolutional block attention module (CBAM) on various YOLO improvements are assessed. Finally, it is pointed out that there are still some problems and challenges in the research of YOLO series algorithms for object detection from the UAV vision. This article looks forward to possible development trends and research directions in this field.
-
Key words:
- UAV system /
- object detection /
- deep learning /
- YOLO series algorithms /
- datasets /
- performance comparison
-
表 1 YOLO不同的优化方案
Table 1. YOLO different optimization schemes
YOLO 锚框机制 正负样本分配 检测头 激活函数 损失函数 Cls_Loss Obj_Loss Bbox_Loss YOLO 无锚框 Max IOU 耦合头 Leaky ReLU 均方差 均方差 IOU YOLOv2 锚框 Max IOU 耦合头 Leaky ReLU 均方差 均方差 IOU YOLOv3 锚框 Max IOU 耦合头 Leaky ReLU 2元交叉熵 2元交叉熵 IOU YOLOv4 锚框 Max IOU 耦合头 Leaky ReLU、Mish 2元交叉熵 2元交叉熵 DIOU YOLOv5 锚框 跨网格搜索 耦合头 Leaky ReLU 2元交叉熵 2元交叉熵 CIOU YOLOX 无锚框 SimOTA 解耦头 SiLU 2元交叉熵 2元交叉熵 CIOU YOLOv6 无锚框 TOOD 解耦头 SiLU 2元交叉熵 2元交叉熵 CIOU YOLOv7 无锚框 跨网格搜索 解耦头 SiLU 2元交叉熵 2元交叉熵 CIOU YOLOv8 无锚框 TOOD 解耦头 SiLU 2元交叉熵 VFL CIOU YOLOv9 无锚框 TOOD 解耦头 SiLU 2元交叉熵 VFL CIOU 注:DIOU和CIOU分别为距离交并比和完全交并比。  下载: 导出CSV
表 2 YOLO性能评价指标
Table 2. Performance evaluation indicators of YOLO
类别 指标 公式 准确性 召回率R nTP/(nTP+nFP) 精确率P nTP/(nTP+nFN) 平均精度Pk $ \displaystyle\int P(R)\text{d}R $ 平均精度均值 $ \dfrac{1}{K}\displaystyle\sum\limits_{k=1}^{K}{P}_{k} $ 速度 帧率
下载: 导出CSV
版本 框架 数据集 图像尺寸/像素 骨干网络 mAP/% 帧率/(帧·s−1) 参数量 浮点运算量/次 YOLO Darknet VOC 448 GoogLeNet 63.4 45 2.629×10⁸ 3.37×10¹⁰ YOLOv2 Darknet VOC 416 Darknet24 76.8 67 4.87×10⁷ 3.06×10¹⁰ YOLOv3 Darknet COCO 608 Darknet53 33.0 78 6.3×10⁷ 1.18×10¹¹ YOLOv4 Darknet COCO 608 CSPDarknet53 43.5 65 2.76×10⁷ 5.20×10¹⁰ YOLOv5s Pytorch COCO 640 CSPDarknet 37.4 95 7.2×10⁶ 1.65×10¹⁰ YOLOXs Pytorch COCO 640 CSPDarknet 40.5 156 9.0×10⁶ 2.68×10¹⁰ YOLOv6 Pytorch COCO 640 EfficientRep 43.1 109 1.72×10⁷ 4.42×10¹⁰ YOLOv7s Pytorch COCO 640 ELANblock 51.4 161 6.03×10⁶ 1.32×10¹⁰ YOLOv8s Pytorch COCO 640 CSPDarknet 53.0 101 1.12×10⁷ 2.86×10¹⁰ YOLOv9 Pytorch COCO 640 ELANblock 56.0 7.1×10⁶ 2.64×10¹⁰ SSD Pytorch COCO ResNet101+FPN 33.2 35.5 ConterNet Pytorch COCO Hourglass104+FPN 45.1 1.42 RetinaNet Pytorch COCO ResNet101+FPN 39.1 5.4 FCOS Pytorch COCO ResNet101+FPN 43.2 60
下载: 导出CSV
表 4 常用公共数据集
Table 4. Common public datasets
类别 大小/(像素×像素) 类别 数量 拍摄视角 VOC 300×500 20 33000 自然视角 COCO 600×800 80 330000 自然视角 DIOR 800×800 20 23463 航空视角 DOTA 800× 4000 15 11268 航空视角 VisDrone 2000 ×1500 12 10209 UAV视角 UAVDT 1080 ×5408 83000 UAV视角 UAV123 1280 ×72012 110000 UAV视角 UA-DETRAC 960×540 4 140000 UAV视角 Staford Drone 1417 ×2019 10 19000 UAV视角 AU-AIR 1920 ×1080 9 32000 UAV视角
下载: 导出CSV
表 5 YOLO检测模型在UAV视角下的实验性能
Table 5. Experimental performance of the YOLO detection model under UAV vision
算法 数据集 mAP/% YOLOv5s VisDrone2019 34.5 YOLOv5s UA-DETRAC 40.3 YOLOv5s UAVDT 57.8 YOLOv7s VisDrone2019 38.9 YOLOv7s UA-DETRAC 45.9 YOLOv7s UAVDT 60.1 YOLOv8s VisDrone2019 39.8 YOLOv8s UA-DETRAC 45.1 YOLOv8s UAVDT 65.1 YOLOv9c VisDrone2019 45.3 YOLOv9c UA-DETRAC 54.6 YOLOv9c UAVDT 66.3
下载: 导出CSV
表 6 实验运行环境
Table 6. Experimental environment configuration
云服务器 GPU 内存/GB Python CUDA https://www.mistgpu.com/ RTX3080 Ti 12 GB 30 3.8 11.3
下载: 导出CSV
表 7 UAV视角下的应用数据集
Table 7. Application datasets of UAV vision
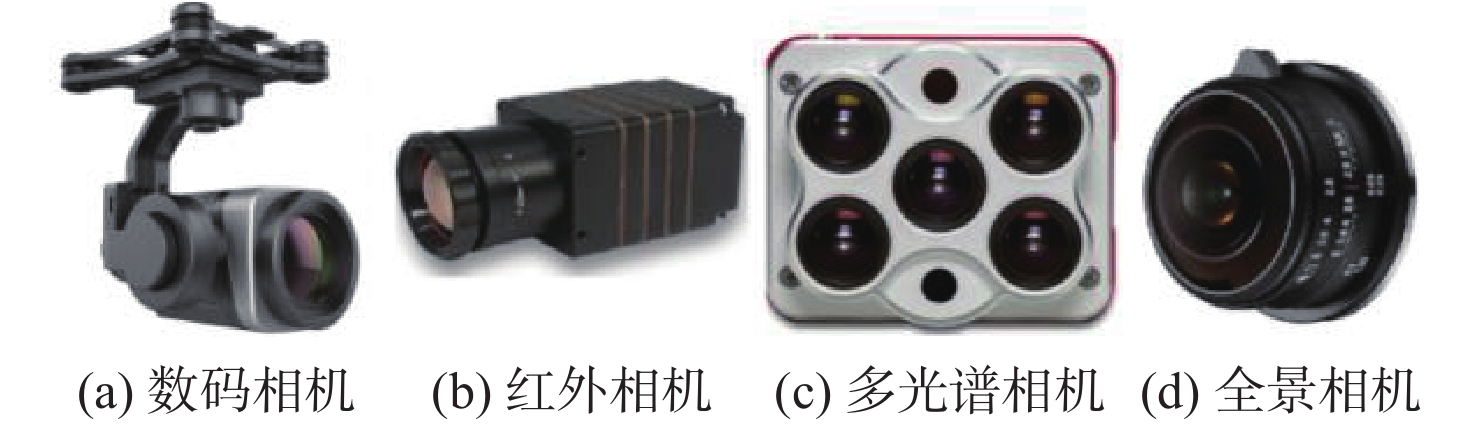
文献 图像大小/(像素×像素) 类别 数量 成像特点 UAV拍摄高度/m [41] 5472 ×3648 地面控制点 1745 可见光 40~220 [40] 5472 ×3078 钢结构裂纹 200 可见光 10~25 [42] 640×640 快速响应码 3260 可见光 <12 [42] 800×600 小麦 300 可见光 <3 [43] 4000 ×3000 输电线路 2600 可见光 50~260 [44] 1330 ×1000 枯死树 3084 可见光 75~100 [45] 500×500 松材线虫病 4208 可见光 <525 [46] 1152 ×864绝缘子 860 可见光 <100 [38] 640×512 行人、车辆 2898 红外热图 60~130 [47] 1920 ×1680 行人 8416 LED光源 15~65 [48] 960× 5184 松材线虫病 4500 多光谱图像 100~350 [49] 800×800 行人 7092 鱼眼摄像头 <6 [50] 2448 ×2048 伪装目标 2215 偏振成像 10
下载: 导出CSV
表 10 UAV视角下增加注意力机制的YOLO算法性能提升度
Table 10. Performance improvement of YOLO algorithm with an added attention mechanism from UAV vision
算法 数据集 AP提升量/% 注意力
机制位置 YOLOv4[76] 高压输电线数据集 2 DANet Backbone YOLOv4[82] 虫害数据集 3.4 SENet Backbone YOLOv5[78] VisDrone 11.5 PSAM Backbone YOLOv8[44] VisDrone 2.2 BiFormer Backbone YOLOv3[80] 幼苗数据集 0.1 SAM Neck YOLO3[89] 棕榈树数据集 1.06 CBAM Neck YOLOv5[82] 风叶缺陷 4 CBAM Neck YOLOX[36] VisDrone 5 ULSAM Neck YOLOv7[83] ODv2 7 PFAM Neck YOLOv7[84] VisDrone 9.5 CBAM Neck YOLOv5s[86] VisDrone 2 CBAM Backbone、Neck YOLOv5[87] VisDrone 7.9 SENet Backbone、Nec YOLOv5[78] VisDrone 4 SCAM Backbone、Neck YOLOv5[48] 松木数据集 5 CBAM Backbone、Neck YOLOv5[88] VisDrone 1.5 ACAM Backbone、Neck
下载: 导出CSV
表 11 CBAM对YOLO算法性能影响
Table 11. Impact of CBAM on the performance of YOLO algorithm
算法 位置 置入方式 mAP/% YOLOv5s Backbone+Neck 替换C3 31.6 YOLOv5s Backbone 替换C3 32.4 YOLOv5s Neck 替换C3 33.8 YOLOv5s Backbone 增加 37.6 YOLOv7s Backbone+Neck 替换ELAN 32.7 YOLOv7s Backbone 替换ELAN 37.9 YOLOv7s Neck 替换ELAN 39.0 YOLOv7s Backbone 增加 39.8 YOLOv8s Backbone+Neck 替换C2f 33.8 YOLOv8s Backbone 替换C2f 34.9 YOLOv8s Neck 替换C2f 38.6 YOLOv8s Backbone 增加 40.1
下载: 导出CSV
表 14 UAV视角下YOLO目标检测模型的实验性能
Table 14. Experimental performance of YOLO object detection model from UAV vision
模型 数据集 mAP/% mAP0.5/% 参数量 epoch 动量 WD ILR 设备 帧率/(帧·s−1) YOLOv4[38] COCO 48 66 500 0.9 0.0005 0.001 RTX2080Ti 19.4 YOLOv5[34] COCO 45 65 2.48×10⁷ 300 0.9 0.0005 0.01 TX1080Ti 82.2 YOLOX[95] COCO 43 61 1.45×10⁶ 300 0.9 0.0005 0.01 RTX3090 27.7 YOLOv3[103] VisDrone 27 6.15×10⁷ 300 0.9 0.0005 0.0025 GTX1080Ti 139.7 YOLOv4[94] VisDrone 32 65 6.17×10⁶ 300 0.9 0.0005 0.01 2070Super 18.0 YOLOv5[74] VisDrone 35 1.08×108 RTX3060 146.0 YOLOv7[78] VisDrone 36 53 7.97×10⁷ 400 0.9 0.0005 0.01 TESLA P100 YOLOv3[101] 行人 91 2.28×10⁸ 500 0.9 0.0005 0.001 GTX1660Ti 51.5 YOLOv3[36] 棕榈树 92 8.13×10⁷ 100 0.9 0.0005 0.001 GTX1060 26.9 YOLOv4[76] 输电线路 90 300 0.949 0.0005 0.001 RTX3090 50.0 YOLOv4[84] 松树病虫害 96 2.01×10⁸ 175 0.9 0.1 0.005 i7_10750H 4.2 YOLOv4[113] 钢裂纹 97 1.16×10⁷ 500 0.9 0.0005 0.001 RTX1080Ti 8.4 YOLOv5[82] 风电叶片 95 3.78×10⁷ 300 0.9 0.0005 0.0032 GTX1650 41.3 YOLOv5[49] 松线虫树 98 98 4.67×10⁷ 500 0.9 0.0005 0.01 RTX3060 67.0 YOLOv5[35] 枣椰树 92 90 300 0.9 0.0005 0.001 RTX2080Ti 11.3 YOLOv8[106] 烟雾 92 85 200 0.9 0.0005 0.001 GTX1080Ti 167.0
下载: 导出CSV
-
[1] 蔡志浩, 陈文军, 赵江, 等. 基于动态视觉传感器的无人机目标检测与避障[J]. 北京航空航天大学学报, 2024, 50(1): 144-153.Cai Z H, Chen W J, Zhao J, et al. Object detection and obstacle avoidance based on dynamic vision sensor for UAV[J]. Journal of Beijing University of Aeronautics and Astronautics, 2024, 50(1): 144-153(in Chinese). [2] 薛康, 刘琨, 江俊峰, 等. 基于YOLOv5s模型的光纤振动传感事件精准检测研究[J]. 光学学报, 2023, 43(2): 0228001.Xue K, Liu K, Jiang J F, et al. Optical fiber vibration sensing detection with high accuracy based on YOLOv5s model[J]. Acta Optica Sinica, 2023, 43(2): 0228001(in Chinese). [3] 刘莉, 曹潇, 张晓辉, 等. 轻小型太阳能/氢能无人机发展综述[J]. 航空学报, 2020, 41(3): 1-28.Liu L, Cao X, Zhang X H, et al. Review of development of light and small scale solar/hydrogen powered unmanned aerial vehicles[J]. Acta Aeronautica et Astronautica Sinica, 2020, 41(3): 1-28(in Chinese). [4] 张继贤, 刘飞, 王坚. 轻小型无人机测绘遥感系统研究进展[J]. 遥感学报, 2021, 25(3): 708-724.Zhang J X, Liu F, Wang J. Review of the light-weighted and small UAV system for aerial photography and remote sensing[J]. Journal of Remote Sensing, 2021, 25(3): 708-724(in Chinese). [5] 刘芳, 孙亚楠. 基于自适应融合网络的无人机目标跟踪算法[J]. 航空学报, 2022, 43(7): 359-369.Liu F, Sun Y N. UAV target tracking algorithm based on adaptive fusion network[J]. Acta Aeronautica et Astronautica Sinica, 2022, 43(7): 359-369(in Chinese). [6] 张博恒, 柴栋栋, 孟令博, 等. 基于多重检测的无人机抗遮挡目标跟踪算法[J]. 北京航空航天大学学报, 2023, 49(9): 2442-2454.Zhang B H, Chai D D, Meng L B, et al. Anti-occlusion target tracking algorithm of UAV based on multiple detection[J]. Journal of Beijing University of Aeronautics and Astronautics, 2023, 49(9): 2442-2454(in Chinese). [7] Liu J H, Wang Z P, Wu Y P, et al. An improved faster R-CNN for UAV-based catenary support device inspection[J]. International Journal of Software Engineering and Knowledge Engineering, 2020, 30(7): 941-959. [8] 刘英杰, 杨风暴, 胡鹏. 基于Cascade R-CNN的并行特征金字塔网络无人机航拍图像目标检测算法[J]. 激光与光电子学进展, 2020, 57(20): 201505.Liu Y J, Yang F B, Hu P. Parallel FPN algorithm based on Cascade R-CNN for object detection from UAV aerial images[J]. Laser & Optoelectronics Progress, 2020, 57(20): 201505(in Chinese). [9] Peng X, Zhong X G, Zhao C, et al. A UAV-based machine vision method for bridge crack recognition and width quantification through hybrid feature learning[J]. Construction and Building Materials, 2021, 299: 123896. [10] Redmon J, Divvala S, Girshick R, et al. You only look once: unified, real-time object detection[C]//Proceedings of the 2016 IEEE Conference on Computer Vision and Pattern Recognitio. Piscataway: IEEE Press, 2016: 779-788. [11] Li Y D, Dong H, Li H G, et al. Multi-block SSD based on small object detection for UAV railway scene surveillance[J]. Chinese Journal of Aeronautics, 2020, 33(6): 1747-1755. [12] Liu J, Jia R, Li W, et al. High precision detection algorithm based on improved RetinaNet for defect recognition of transmission lines[J]. Energy Reports, 2020, 6: 2430-2440. [13] Kannadaguli P. FCOS based human detection system using thermal imaging for UAV based surveillance applications[C]//Proceedings of the 2020 IEEE Bombay Section Signature Conference. Piscataway: IEEE Press, 2021: 79-83. [14] 耿创, 宋品德, 曹立佳. YOLO算法在目标检测中的研究进展[J]. 兵器装备工程学报, 2022, 43(9): 162-173.Geng C, Song P D, Cao L J. Research progress of YOLO algorithm in target detection[J]. Journal of Ordnance Equipment Engineering, 2022, 43(9): 162-173(in Chinese). [15] 邵延华, 张铎, 楚红雨, 等. 基于深度学习的YOLO目标检测综述[J]. 电子与信息学报, 2022, 44(10): 3697-3708.Shao Y H, Zhang D, Chu H Y, et al. A review of YOLO object detection based on deep learning[J]. Journal of Electronics & Information Technology, 2022, 44(10): 3697-3708(in Chinese). [16] 王琳毅, 白静, 李文静, 等. YOLO系列目标检测算法研究进展[J]. 计算机工程与应用, 2023, 59(14): 15-29.Wang L Y, Bai J, Li W J, et al. Research progress of YOLO series target detection algorithms[J]. Computer Engineering and Applications, 2023, 59(14): 15-29(in Chinese). [17] Terven J, Cordova-Esparza D. A comprehensive review of YOLO architectures in computer vision: from YOLOv1 to YOLOv8 and YOLO-NAS[EB/OL]. (2024-02-04)[2024-06-10]. https://arxiv.org/abs/2304.00501. [18] Wu X, Li W, Hong D F, et al. Deep learning for unmanned aerial vehicle-based object detection and tracking: a survey[J]. IEEE Geoscience and Remote Sensing Magazine, 2022, 10(1): 91-124. [19] 冷佳旭, 莫梦竟成, 周应华, 等. 无人机视角下的目标检测研究进展[J]. 中国图象图形学报, 2023, 28(9): 2563-2586.Leng J X, Mo M J C, Zhou Y H, et al. Recent advances in drone-view object detection[J]. Journal of Image and Graphics, 2023, 28(9): 2563-2586(in Chinese). [20] 罗旭东, 吴一全, 陈金林. 无人机航拍影像目标检测与语义分割的深度学习方法研究进展[J]. 航空学报, 2024, 45(6): 235-264.Luo X D, Wu Y Q, Chen J L. Research progress on deep learning methods for object detection and semantic segmentation in UAV aerial images[J]. Acta Aeronautica et Astronautica Sinica, 2024, 45(6): 235-264(in Chinese). [21] 苑玉彬, 吴一全, 赵朗月, 等. 基于深度学习的无人机航拍视频多目标检测与跟踪研究进展[J]. 航空学报, 2023, 44(18): 1-31.Yuan Y B, Wu Y Q, Zhao L Y, et al. Research progress of UAV aerial video multi-object detection and tracking based on deep learning[J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(18): 1-31(in Chinese). [22] 邢姗姗, 赵文龙. 基于YOLO系列算法的复杂场景下无人机目标检测研究综述[J]. 计算机应用研究, 2020, 37(增刊2): 28-30.Xing S S, Zhao W L. Review of UAV target detection in complex scenarios based on YOLO series algorithms[J]. Application Research of Computers, 2020, 37(Sup 2): 28-30(in Chinese). [23] 杨欣, 王刚, 李椋, 等. 基于深度卷积神经网络的小型民用无人机检测研究进展[J]. 红外技术, 2022, 44(11): 1119-1131.Yang X, Wang G, Li L, et al. Civil drone detection based on deep convolutional neural networks: a survey[J]. Infrared Technology, 2022, 44(11): 1119-1131(in Chinese). [24] Redmon J, Farhadi A. YOLO9000: better, faster, stronger[C]//Proceedings of the 2017 IEEE Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2017: 6517-6525. [25] Redmon J, Farhadi A. YOLOv3: an incremental improvement[EB/OL]. (2018-04-08)[2024-06-10]. https://arxiv.org/abs/1804.02767. [26] Bochkovskiy A, Wang C Y, Liao H M. YOLOv4: optimal speed and accuracy of object detection[EB/OL]. (2020-04-23)[2024-06-10]. https://arxiv.org/abs/2004.10934. [27] Wang C Y, Mark Liao H Y, Wu Y H, et al. CSPNet: a new backbone that can enhance learning capability of CNN[C]//Proceedings of the 2020 IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops. Piscataway: IEEE Press, 2020: 1571-1580. [28] 陈宇梁, 董绍江, 孙世政, 等. 改进YOLOv5s的弱光水下生物目标检测算法[J]. 北京航空航天大学学报, 2024, 50(2): 499-507.Chen Y L, Dong S J, Sun S Z, et al. Improved YOLOv5s low-light underwater biological target detection algorithm[J]. Journal of Beijing University of Aeronautics and Astronautics, 2024, 50(2): 499-507(in Chinese). [29] Ge Z, Liu S T, Wang F, et al. YOLOX: exceeding YOLO series in 2021[EB/OL]. (2021-08-06)[2024-06-10]. https://arxiv.org/abs/2107.08430. [30] Li C Y, Li L L, Jiang H L, et al. YOLOv6: a single-stage object detection framework for industrial applications[EB/OL]. (2022-09-07)[2024-06-10]. https://arxiv.org/abs/2209.02976. [31] Wang C Y, Bochkovskiy A, Liao H M. YOLOv7: trainable bag-of-freebies sets new state-of-the-art for real-time object detectors[EB/OL]. (2022-07-06][2024-06-10]. https://arxiv.org/abs/2207.02696. [32] Wang C Y, Yeh I H, Liao H M. YOLOv9: learning what you want to learn using programmable gradient information[EB/OL]. (2024-02-29)[2024-06-10]. https://arxiv.org/abs/2402.13616. [33] 纪守领, 杜天宇, 邓水光, 等. 深度学习模型鲁棒性研究综述[J]. 计算机学报, 2022, 45(1): 190-206.Ji S L, Du T Y, Deng S G, et al. Robustness certification research on deep learning models: a survey[J]. Chinese Journal of Computers, 2022, 45(1): 190-206(in Chinese). [34] Wang C X, Wang H R. Cascaded feature fusion with multi-level self-attention mechanism for object detection[J]. Pattern Recognition, 2023, 138: 109377. [35] Tian G Y, Liu J R, Yang W Y. A dual neural network for object detection in UAV images[J]. Neurocomputing, 2021, 443: 292-301. [36] Wang X, He N, Hong C, et al. Improved YOLOX-X based UAV aerial photography object detection algorithm[J]. Image and Vision Computing, 2023, 135: 104697. [37] Nepal U, Eslamiat H. Comparing YOLOv3, YOLOv4 and YOLOv5 for autonomous landing spot detection in faulty UAVs[J]. Sensors, 2022, 22(2): 1-15. [38] Suo J S, Wang T Y, Zhang X Z, et al. HIT-UAV: a high-altitude infrared thermal dataset for Unmanned Aerial Vehicle-based object detection[EB/OL]. (2023-03-31)[2024-06-10]. https://arxiv.org/abs/2204.03245. [39] Zhan W, Sun C F, Wang M C, et al. An improved YOLOv5 real-time detection method for small objects captured by UAV[J]. Soft Computing, 2022, 26(1): 361-373. [40] Han Q H, Liu X, Xu J. Detection and location of steel structure surface cracks based on unmanned aerial vehicle images[J]. Journal of Building Engineering, 2022, 50: 104098. [41] Cheng C X, Yang J, Wang C, et al. Automatic detection of aerial survey ground control points based on YOLOv5-OBB[EB/OL]. (2023-03-06)[2024-06-10]. https://arxiv.org/abs/2303.03041. [42] 鲍文霞, 谢文杰, 胡根生, 等. 基于TPH-YOLO的无人机图像麦穗计数方法[J]. 农业工程学报, 2023, 39(1): 155-161.Bao W X, Xie W J, Hu G S, et al. Wheat ear counting method in UAV images based on TPH-YOLO[J]. Transactions of the Chinese Society of Agricultural Engineering, 2023, 39(1): 155-161(in Chinese). [43] 李校林, 刘大东, 刘鑫满, 等. 改进YOLOv5的无人机航拍图像目标检测算法[J]. 计算机工程与应用, 2024, 60(11): 204-214.Li X L, Liu D D, Liu X M, et al. Target detection algorithm of UAV aerial image based on improved YOLOv5[J]. Computer Engineering and Applications, 2024, 60(11): 204-214(in Chinese). [44] Wang G, Chen Y F, An P, et al. UAV-YOLOv8: a small-object-detection model based on improved YOLOv8 for UAV aerial photography scenarios[J]. Sensors, 2023, 23(16): 7190. [45] 姜尚洁, 罗斌, 贺鹏, 等. 利用无人机多源影像检测车辆速度[J]. 测绘学报, 2018, 47(9): 1228-1237.Jiang S J, Luo B, He P, et al. Vehicle speed detection by multi-source Images from UAV[J]. Acta Geodaetica et Cartog raphica Sinica, 2018, 47(9): 1228-1237(in Chinese). [46] 罗潇, 於锋, 彭勇. 基于深度学习的无人机电网巡检缺陷检测研究[J]. 电力系统保护与控制, 2022, 50(10): 132-139.Luo X, Yu F, Peng Y. UAV power grid inspection defect detection based on deep learning[J]. Power System Protection and Control, 2022, 50(10): 132-139(in Chinese). [47] Zhu L, Xiong J H, Xiong F, et al. YOLO-Drone: airborne real-time detection of dense small objects from high-altitude perspective[EB/OL]. (2023-10-11)[2024-06-10]. https://arxiv.org/abs/2304.06925. [48] Qin B X, Sun F G, Shen W X, et al. Deep learning-based pine nematode trees’ identification using multispectral and visible UAV imagery[J]. Drones, 2023, 7(3): 183. [49] Thuan P N, Westerlund T, Queralta J P. Vision-based safe autonomous UAV docking with panoramic sensors[EB/OL]. (2023-10-06)[2024-06-10]. https://arxiv.org/abs/2305.16008. [50] Zhang J C, Shao J B, Chen J L, et al. Polarization image fusion with self-learned fusion strategy[J]. Pattern Recognition, 2021, 118: 108045. [51] Andrew W, Greatwood C, Burghardt T. Aerial animal biometrics: individual Friesian cattle recovery and visual identification via an autonomous UAV with onboard deep inference[C]//Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems. Piscataway: IEEE Press, 2020: 237-243. [52] Luo X, Tian X Y, Zhang H J, et al. Fast automatic vehicle detection in UAV images using convolutional neural networks[J]. Remote Sensing, 2020, 12(12): 1994. [53] Hinzmann T, Stegemann T, Cadena C, et al. Deep learning-based human detection for UAVs with optical and infrared cameras: system and experiments[EB/OL]. (2020-08-10)[2024-06-10]. https://arxiv.org/abs/2008.04197. [54] Mokayed H, Nayebiastaneh A, De K, et al. Nordic vehicle dataset (NVD): performance of vehicle detectors using newly captured NVD from UAV in different snowy weather conditions[EB/OL]. (2023-04-27)[2024-06-10]. https://arxiv.org/abs/2304.14466. [55] 沈英, 刘贤财, 王舒, 等. 基于偏振编码图像的低空伪装目标实时检测[J]. 兵工学报, 2024, 45(5): 1374-1383.Shen Y, Liu X C, Wang S, et al. Real-time detection of low-altitude camouflaged targets based on polarization encoded images[J]. Acta Armamentarii, 2024, 45(5): 1374-1383(in Chinese). [56] 赵爽, 黄怀玉, 胡一鸣, 等. 基于深度学习的无人机航拍车辆检测[J]. 计算机应用, 2019, 39(S2): 91-96.Zhao S, Huang H Y, Hu Y M, et al. Vehicle detection in satellite imagery based on deep learning[J]. Journal of Computer Applications, 2019, 39(S2): 91-96(in Chinese). [57] Sun J, Yang Y, He X F, et al. Northern maize leaf blight detection under complex field environment based on deep learning[J]. IEEE Access, 2020, 8: 33679-33688. [58] Wang C Q, Luo D, Liu Y, et al. Near-surface pedestrian detection method based on deep learning for UAVs in low illumination environments[J]. Optical Engineering, 2022, 61(2): 023103. [59] Cui Q Q, Liu M, Huang X Y, et al. Coarse-to-fine visual autonomous unmanned aerial vehicle landing on a moving platform[J]. Biomimetic Intelligence and Robotics, 2023, 3(1): 100088. [60] Chen Z W, Cao L J, Wang Q H. YOLOv5-based vehicle detection method for high-resolution UAV images[J]. Mobile Information Systems, 2022, 2022(1): 1828848. [61] Coletta A, Giorgi F, Maselli G, et al. A2-UAV: application-aware content and network optimization of edge-assisted UAV systems[EB/OL]. (2023-07-24)[2024-06-10]. https://arxiv.org/abs/2301.06363. [62] Koh P W, Sagawa S, Marklund H, et al. WILDS: a benchmark of in-the-wild distribution shifts[EB/OL]. (2021-07-16)[2024-06-10]. https://arxiv.org/abs/2012.07421. [63] 陈蕊, 郑华飞, 蒋鸿宇, 等. 结合仿真迁移学习和自适应融合的无人机小目标检测[J]. 小型微型计算机系统, 2023, 44(8): 1743-1749.Chen R, Zheng H F, Jiang H Y, et al. Combination of simulation-based transfer learning and adaptive fusion for UAV small object detection[J]. Journal of Chinese Computer Systems, 2023, 44(8): 1743-1749(in Chinese). [64] Singh B, Davis L S. An analysis of scale invariance in object detection-SNIP[C]//Proceedings of the 2018 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2018: 3578-3587. [65] Rančić K, Blagojević B, Bezdan A, et al. Animal detection and counting from UAV images using convolutional neural networks[J]. Drones, 2023, 7(3): 179. [66] 魏湧明, 全吉成, 侯宇青阳. 基于YOLOv2的无人机航拍图像定位研究[J]. 激光与光电子学进展, 2017, 54(11): 111002.1-111002.10.Wei Y M, Quan J C, Hou Y Q Y. Aerial image location of unmanned aerial vehicle based on YOLOv2[J]. Laser & Optoelectronics Progress, 2017, 54(11): 111002.1-111002.10(in Chinese). [67] Keles M C, Salmanoglu B, Guzel M S, et al. Evaluation of YOLO models with sliced inference for small object detection[EB/OL]. (2022-03-09)[2024-06-10]. https://arxiv.org/abs/2203.04799. [68] Afifi M, Ali Y, Amer K, et al. Robust real-time pedestrian detection in aerial imagery on jetson TX2[EB/OL]. (2019-05-16)[2024-06-10]. https://arxiv.org/abs/1905.06653. [69] Yavariabdi A, Kusetogullari H, Celik T, et al. FastUAV-NET: a multi-UAV detection algorithm for embedded platforms[J]. Electronics, 2021, 10(6): 1-9. [70] Misbah M, Khan M U, Yang Z H, et al. TF-net: deep learning empowered tiny feature network for night-time UAV detection[EB/OL]. (2022-11-29)[2024-06-10]. https://arxiv.org/abs/2211.16317. [71] 王兆魁, 方青云, 韩大鹏. 成像卫星在轨智能处理技术研究进展[J]. 宇航学报, 2022, 43(3): 259-270.Wang Z K, Fang Q Y, Han D P. Research progress of on-orbit artificial intelligence technology for imaging satellite[J]. Journal of Astronautics, 2022, 43(3): 259-270(in Chinese). [72] Liu H Y, Duan X H, Lou H T, et al. Improved GBS-YOLOv5 algorithm based on YOLOv5 applied to UAV intelligent traffic[J]. Scientific Reports, 2023, 13: 9577. [73] 陈范凯, 李士心. 改进YOLOv5的无人机目标检测算法[J]. 计算机工程与应用, 2023, 59(18): 218-225.Chen F K, Li S X. UAV target detection algorithm with improved YOLOv5[J]. Computer Engineering and Applications, 2023, 59(18): 218-225(in Chinese). [74] 冒国韬, 邓天民, 于楠晶. 基于多尺度分割注意力的无人机航拍图像目标检测算法[J]. 航空学报, 2023, 44(5): 268-278.Mao G T, Deng T M, Yu N J. Object detection in UAV images based on multi-scale split attention[J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(5): 268-278(in Chinese). [75] 祁宣豪, 智敏. 图像处理中注意力机制综述[J]. 计算机科学与探索, 2024, 18(2): 345-362.Qi X H, Zhi M. Review of attention mechanisms in image processing[J]. Journal of Frontiers of Computer Science & Technology, 2024, 18(2): 345-362(in Chinese). [76] Yang Z, Xu X F, Wang K K, et al. Multitarget detection of transmission lines based on DANet and YOLOv4[J]. Scientific Programming, 2021, 2021(1): 6235452. [77] Han K, Wang Y H, Xu C, et al. GhostNets on heterogeneous devices via cheap operations[J]. International Journal of Computer Vision, 2022, 130(4): 1050-1069. [78] 奉志强, 谢志军, 包正伟, 等. 基于改进YOLOv5的无人机实时密集小物体检测算法[J]. 航空学报, 2023, 44(7): 246-260.Feng Z Q, Xie Z J, Bao Z W, et al. Real-time dense small object detection algorithm for UAV based on improved YOLOv5[J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(7): 246-260(in Chinese). [79] Zhu L, Wang X J, Ke Z H, et al. BiFormer: vision transformer with bi-level routing attention[EB/OL]. (2023-03-15)[2024-06-10]. https://arxiv.org/abs/2303.08810. [80] 张宏鸣, 付振宇, 韩文霆, 等. 基于改进YOLO的玉米幼苗株数获取方法[J]. 农业机械学报, 2021, 52(4): 221-229.Zhang H M, Fu Z Y, Han W T, et al. Detection method of maize seedlings number based on improved YOLO[J]. Transactions of the Chinese Society for Agricultural Machinery, 2021, 52(4): 221-229(in Chinese). [81] 林文树, 张金生, 何乃磊. 基于改进YOLOv4的落叶松毛虫侵害树木实时检测方法[J]. 农业机械学报, 2023, 54(4): 304-312.Lin W S, Zhang J S, He N L. Real-time detection method of dendrolimus superans-infested Larix gmelinii trees based on improved YOLOv4[J]. Transactions of the Chinese Society for Agricultural Machinery, 2023, 54(4): 304-312(in Chinese). [82] Zhang R, Wen C B. SOD-YOLO: a small target defect detection algorithm for wind turbine blades based on improved YOLOv5[J]. Advanced Theory and Simulations, 2022, 5(7): 2100631. [83] Zhao H Y, Zhang H P, Zhao Y Y. YOLOv7-sea: object detection of maritime UAV images based on improved YOLOv7[C]//Proceedings of the 2023 IEEE/CVF Winter Conference on Applications of Computer Vision Workshops. Piscataway: IEEE Press, 2023: 233-238. [84] Zhao L L, Zhu M L. MS-YOLOv7: YOLOv7 based on multi-scale for object detection on UAV aerial photography[J]. Drones, 2023, 7(3): 171-188. [85] Liu Z, Lin Y T, Cao Y, et al. Swin Transformer: hierarchical vision Transformer using shifted windows[C]//Proceedings of the 2021 IEEE/CVF International Conference on Computer Vision. Piscataway: IEEE Press, 2021: 9992-10002. [86] 丛玉华, 何啸, 邢长达, 等. 基于无人机的轻量化小目标检测网络[J]. 弹箭与制导学报, 2022, 42(6): 6-12.Cong Y H, He X, Xing C D, et al. Lightweight small target detection network based on UAV[J]. Journal of Projectiles, Rockets, Missiles and Guidance, 2022, 42(6): 6-12(in Chinese). [87] 韩俊, 袁小平, 王准, 等. 基于YOLOv5s的无人机密集小目标检测算法[J]. 浙江大学学报(工学版), 2023, 57(6): 1224-1233.Han J, Yuan X P, Wang Z, et al. UAV dense small target detection algorithm based on YOLOv5s[J]. Journal of Zhejiang University (Engineering Science), 2023, 57(6): 1224-1233(in Chinese). [88] 李子豪, 王正平, 贺云涛. 基于自适应协同注意力机制的航拍密集小目标检测算法[J]. 航空学报, 2023, 44(13): 239-249.Li Z H, Wang Z P, He Y T. Aerial-photography dense small target detection algorithm based on adaptive cooperative attention mechanism[J]. Acta Aeronautica et Astronautica Sinica, 2023, 44(13): 239-249(in Chinese). [89] Qin Z W, Wang W S, Dammer K H, et al. A real-time low-cost artificial intelligence system for autonomous spraying in palm plantations[EB/OL]. (2021-03-06)[2024-06-10]. https://arxiv.org/abs/2103.04132. [90] Xia Y, Ye G X, Yan S S, et al. Application research of fast UAV aerial photography object detection and recognition based on improved YOLOv3[J]. Journal of Physics: Conference Series, 2020, 1550(3): 032075. [91] Liu X H, Wang C B, Liu L. Research on pedestrian detection model and compression technology for UAV images[J]. Sensors, 2022, 22(23): 9171. [92] Wu R N, Hua C C, Ding W L, et al. Flame and smoke detection algorithm for UAV based on improved YOLOv4-tiny[C]//Proceedings of the PRICAI 2021: Trends in Artificial Intelligence. Berlin: Springer, 2021: 226-238. [93] 吴明杰, 云利军, 陈载清, 等. 改进YOLOv5s的无人机视角下小目标检测算法[J]. 计算机工程与应用, 2024, 60(2): 191-199.Wu M J, Yun L J, Chen Z Q, et al. Improved YOLOv5s small object detection algorithm in UAV view[J]. Computer Engineering and Applications, 2024, 60(2): 191-199(in Chinese). [94] 陈旭, 彭冬亮, 谷雨. 基于改进YOLOv5s的无人机图像实时目标检测[J]. 光电工程, 2022, 49(3): 210372.Chen X, Peng D L, Gu Y. Real-time object detection for UAV images based on improved YOLOv5s[J]. Opto-Electronic Engineering, 2022, 49(3): 210372(in Chinese). [95] Zhou W, Min X L, Hu R, et al. FasterX: real-time object detection based on edge GPUs for UAV applications[EB/OL]. (2022-09-07)[2024-06-10]. https://arxiv.org/abs/2209.03157. [96] Zhao Z P, He C, Zhao G M, et al. RA-YOLOX: re-parameterization align decoupled head and novel label assignment scheme based on YOLOX[J]. Pattern Recognition, 2023, 140: 109579. [97] 曲优, 李文辉. 基于锚框变换的单阶段旋转目标检测方法[J]. 吉林大学学报(工学版), 2022, 52(1): 162-173.Qu Y, Li W H. Single-stage rotated object detection network based on anchor transformation[J]. Journal of Jilin University (Engineering and Technology Edition), 2022, 52(1): 162-173(in Chinese). [98] Wang M Z, Sun H X, Shi J, et al. Q-YOLO: efficient inference for real-time object detection[EB/OL]. (2023-07-01)[2024-06-10]. https://arxiv.org/abs/2307.04816. [99] Liu Z, Li J G, Shen Z Q, et al. Learning efficient convolutional networks through network slimming[C]//Proceedings of the 2017 IEEE International Conference on Computer Vision. Piscataway: IEEE Press, 2017: 2755-2763. [100] Shao Y H, Zhang X P, Chu H Y, et al. AIR-YOLOv3: aerial infrared pedestrian detection via an improved YOLOv3 with network pruning[J]. Applied Sciences, 2022, 12(7): 3627. [101] 侯鑫, 曲国远, 魏大洲, 等. 基于迭代稀疏训练的轻量化无人机目标检测算法[J]. 计算机研究与发展, 2022, 59(4): 882-893.Hou X, Qu G Y, Wei D Z, et al. A lightweight UAV object detection algorithm based on iterative sparse training[J]. Journal of Computer Research and Development, 2022, 59(4): 882-893(in Chinese). [102] Guo X J, Li S Y, Yu J K, et al. PFLD: a practical facial landmark detector[EB/OL]. (2019-03-03)[2024-06-10]. https://arxiv.org/abs/1902.10859. [103] 彭继慎, 孙礼鑫, 王凯, 等. 基于模型压缩的ED-YOLO电力巡检无人机避障目标检测算法[J]. 仪器仪表学报, 2021, 42(10): 161-170.Peng J S, Sun L X, Wang K, et al. ED-YOLO power inspection UAV obstacle avoidance target detection algorithm based on model compression[J]. Chinese Journal of Scientific Instrument, 2021, 42(10): 161-170(in Chinese). [104] Sharma V K, Dhiman P, Rout R K. Improved traffic sign recognition algorithm based on YOLOv4-tiny[J]. Journal of Visual Communication and Image Representation, 2023, 91: 103774. [105] 陈卫彪, 贾小军, 朱响斌, 等. 基于DSM-YOLOv5的无人机航拍图像目标检测[J]. 计算机工程与应用, 2023, 59(18): 226-233.Chen W B, Jia X J, Zhu X B, et al. Target detection for UAV image based on DSM-YOLOv5[J]. Computer Engineering and Applications, 2023, 59(18): 226-233(in Chinese). [106] Saydirasulovich S N, Mukhiddinov M, Djuraev O, et al. An improved wildfire smoke detection based on YOLOv8 and UAV images[J]. Sensors, 2023, 23(20): 8374. [107] 张可, 乐全明, 黄文礼, 等. 联合剪枝和知识蒸馏的PCSA-YOLOs防振锤缺陷检测算法[J]. 电工电能新技术, 2022, 41(11): 59-69.Zhang K, Le Q M, Huang W L, et al. PCSA-YOLOs vibration damper defect detection algorithm combined with pruning and knowledge distillation[J]. Advanced Technology of Electrical Engineering and Energy, 2022, 41(11): 59-69(in Chinese). [108] Howard A, Sandler M, Chen B, et al. Searching for MobileNetV3[C]//Proceedings of the 2019 IEEE/CVF International Conference on Computer Vision. Piscataway: IEEE Press, 2019: 1314-1324. [109] 黄丽明, 王懿祥, 徐琪, 等. 采用YOLO算法和无人机影像的松材线虫病异常变色木识别[J]. 农业工程学报, 2021, 37(14): 197-203.Huang L M, Wang Y X, Xu Q, et al. Recognition of abnormally discolored trees caused by pine wilt disease using YOLO algorithm and UAV images[J]. Transactions of the Chinese Society of Agricultural Engineering, 2021, 37(14): 197-203(in Chinese). [110] Sandler M, Howard A, Zhu M L, et al. MobileNetV2: inverted residuals and linear bottlenecks[C]//Proceedings of the 2018 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2018: 4510-4520. [111] 甄然, 刘雨涵, 孟凡华, 等. 基于改进YOLOv7的低空飞行物目标检测方法[J]. 无线电工程, 2024, 54(3): 633-643.Zhen R, Liu Y H, Meng F H, et al. Low altitude flying target detection method based on improved YOLOv7[J]. Radio Engineering, 2024, 54(3): 633-643(in Chinese). [112] Liu Z, Mao H Z, Wu C Y, et al. A ConvNet for the 2020s[C]//Proceedings of the 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Piscataway: IEEE Press, 2022: 11966-11976. [113] Yu Z W, Shen Y G, Shen C K. A real-time detection approach for bridge cracks based on YOLOv4-FPM[J]. Automation in Construction, 2021, 122: 103514. [114] 张上, 张岳, 王恒涛, 等. 轻量化无人机遥感图像小目标检测算法[J]. 无线电工程, 2023, 53(10): 2329-2336.Zhang S, Zhang Y, Wang H T, et al. Lightweight small target detection algorithm in UAV remote sensing image[J]. Radio Engineering, 2023, 53(10): 2329-2336(in Chinese). [115] 谢椿辉, 吴金明, 徐怀宇. 改进YOLOv5的无人机影像小目标检测算法[J]. 计算机工程与应用, 2023, 59(9): 198-206.Xie C H, Wu J M, Xu H Y. Small object detection algorithm based on improved YOLOv5 in UAV image[J]. Computer Engineering and Applications, 2023, 59(9): 198-206(in Chinese). [116] He J B, Erfani S, Ma X J, et al. Alpha-IoU: a family of power intersection over union losses for bounding box regression[EB/OL]. (2022-06-22)[2024-06-10]. https://arxiv.org/abs/2110.13675. [117] Elfwing S, Uchibe E, Doya K. Sigmoid-weighted linear units for neural network function approximation in reinforcement learning[J]. Neural Networks, 2018, 107: 3-11. -

 下载:







 点击查看大图
计量
- 文章访问数: 2332
- HTML全文浏览量: 332
- PDF下载量: 256
- 被引次数: 0
