


-
摘要:
在星光折射间接敏感地平定位方法中,传统固定视轴观星方案导致折射星数量少,且分布不均匀,进而影响星光折射定位的精度和可靠性。为此,提出了一种高精度的星光折射天文导航观星方案。根据平流层大气所形成的折射环带与星敏感器视场(FOV)之间的几何关系,建立了星敏感器视场对折射环带的覆盖面积与视轴高度角之间的关系模型,通过折射环带的覆盖面积最大化,结合飞行器的飞行参数,确定星敏感器视轴的最佳高度角,以提高可观测折射星数量;通过推导构建折射星空间构型与定位精度之间的定量关系模型,基于最小定位精度因子(PDOP)准则,确定折射星最佳空间几何构型,进而得到星敏感器视轴的最佳方位角,从而借助星光折射间接敏感地平定位方法实现对折射星连续、均匀的观测,以提高天文导航的定位精度。仿真验证结果表明,与传统观测方案相比,所提观测方案的位置与速度估计误差分别提升了75.7%和66.7%。
Abstract:The traditional fixed optical axis observation approach reduces positioning accuracy and reliability in the starlight refraction indirect horizon-sensing positioning method by producing a small number of refracted stars with an uneven distribution. Therefore, a high-precision starlight refraction celestial navigation observation method is proposed. Based on the geometric relationship between the stratospheric refraction band and the star sensor’s field of view (FOV), a relation model is established between the FOV coverage area of the refraction band and the star sensor’s elevation angle. By maximizing the FOV coverage area and combining the flight parameters, the optimal elevation angle is determined to increase the observable refracted stars. Additionally, a quantitative relationship model is developed between positioning precision and the spatial arrangement of refracted stars. Based on the minimum position dilution of precision (PDOP) criterion, the optimal spatial geometric configuration of refracted stars is derived, thereby obtaining the optimal azimuth angle of the optical axis. This enables continuous and uniform observation for refracted starlight, so as to improve the positioning accuracy of celestial navigation. Simulation results demonstrate that compared with the conventional method, the proposed method achieves 75.7% and 66.7% improvements in position and velocity estimation accuracy, respectively.
-
Key words:
- aerospace vehicle /
- starlight refraction /
- geometric configuration /
- star sensor /
- celestial navigation
-
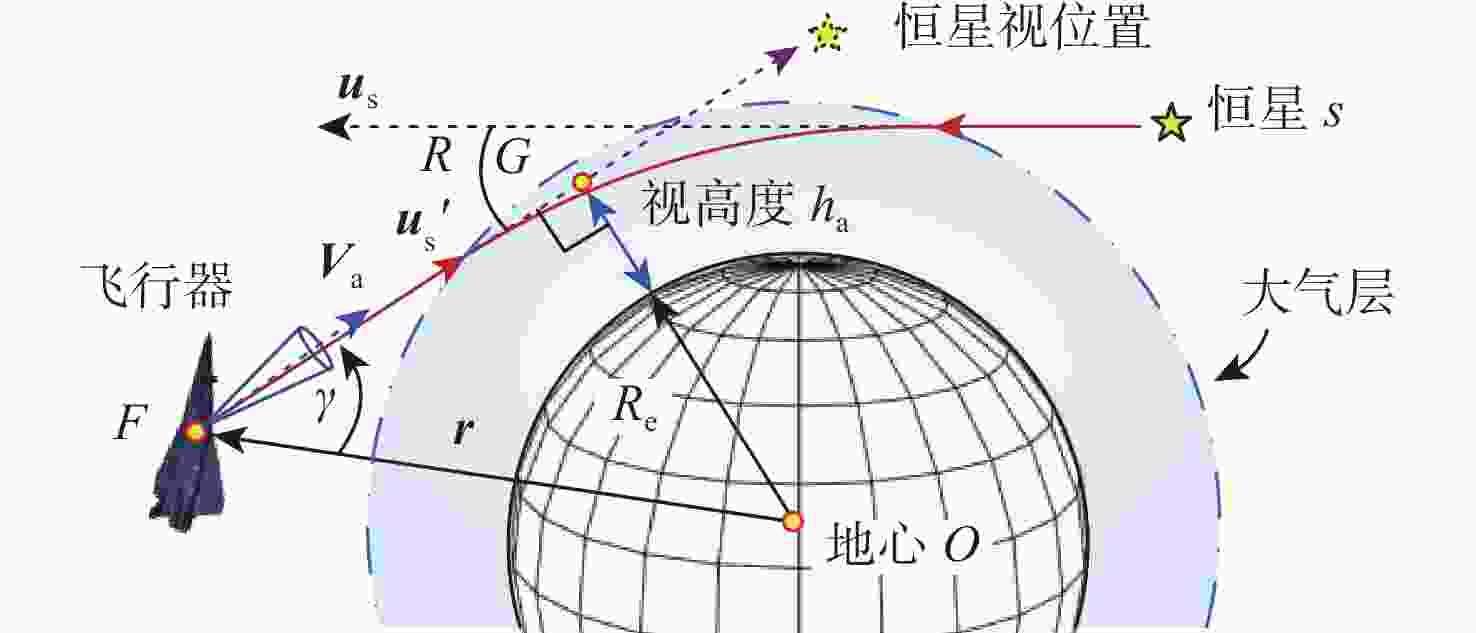
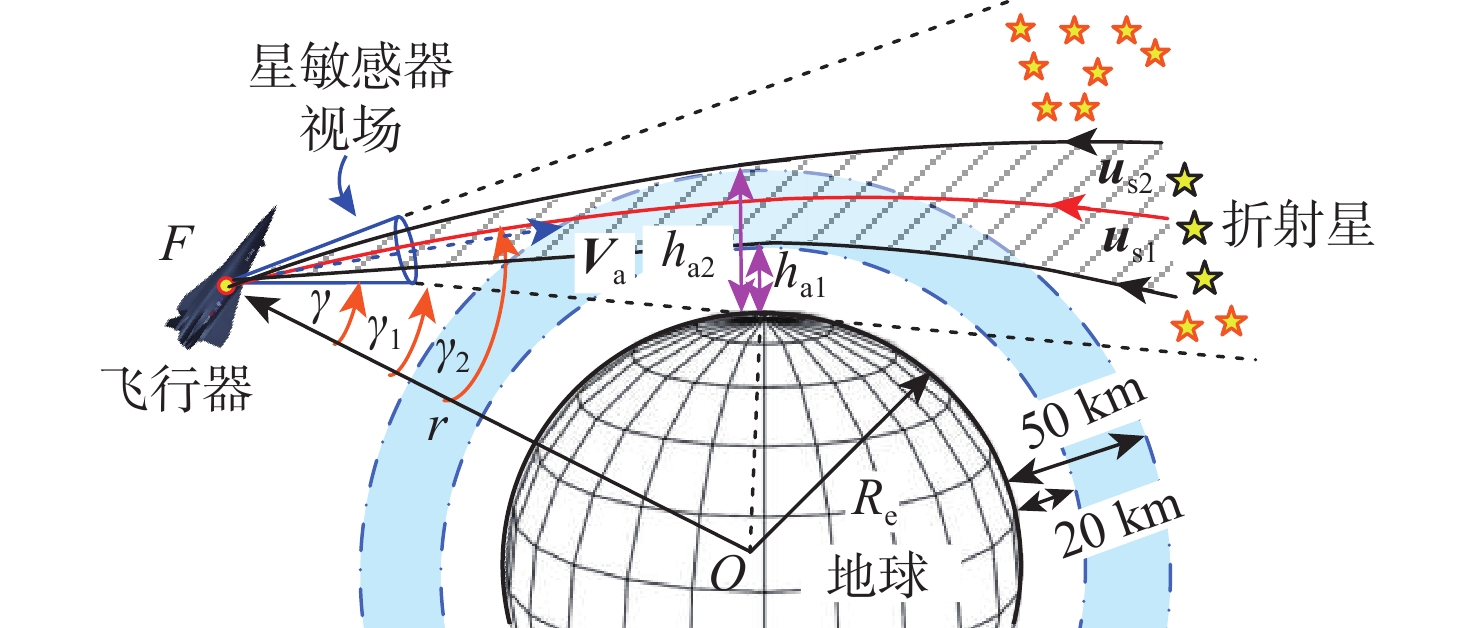
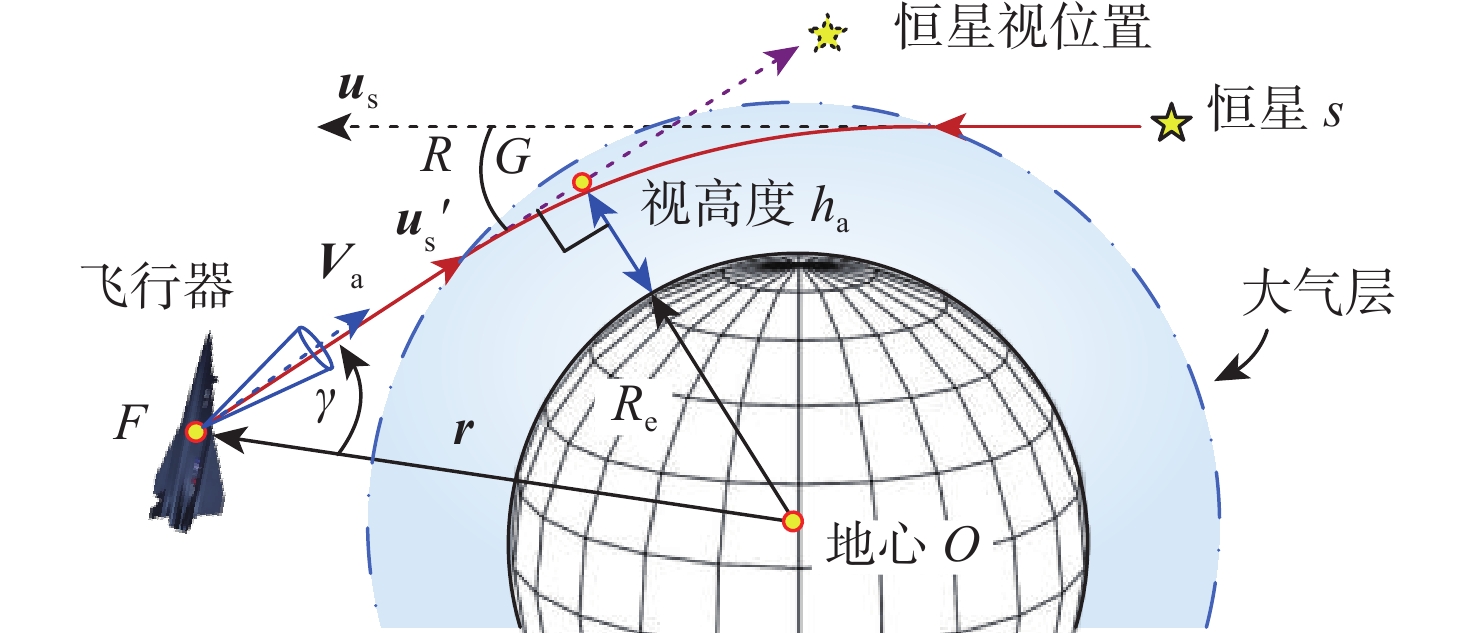
图 1 星光折射间接敏感地平定位原理
Figure 1. Principle of starlight refraction indirect horizon-sensing positioning
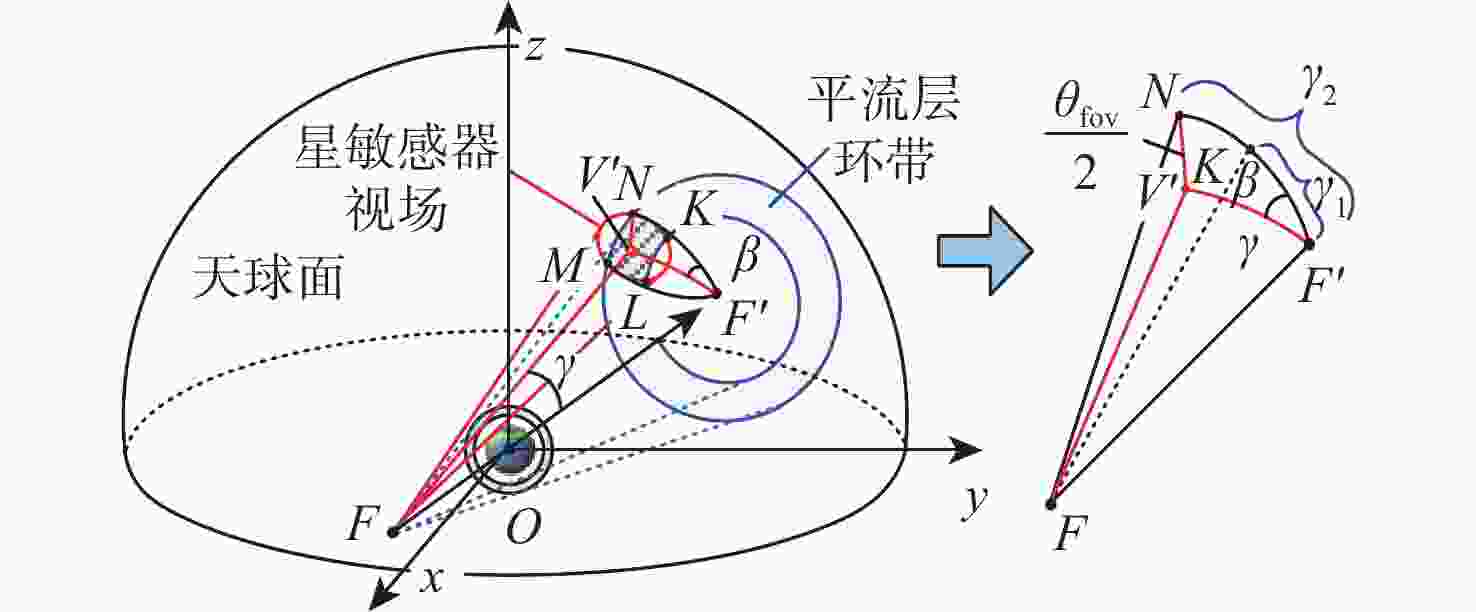
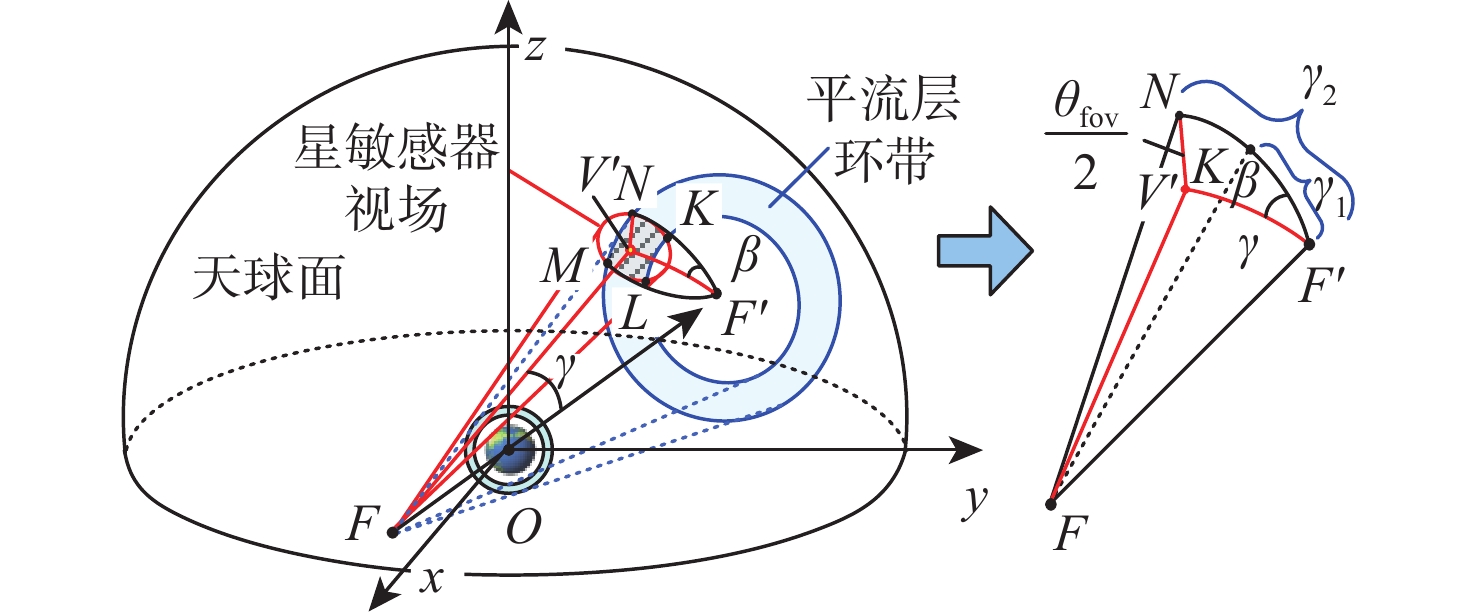
图 3 天球坐标系下星敏感器视轴指向示意图
Figure 3. Schematic diagram showing the line of sight of a star sensor in celestial coordinate system
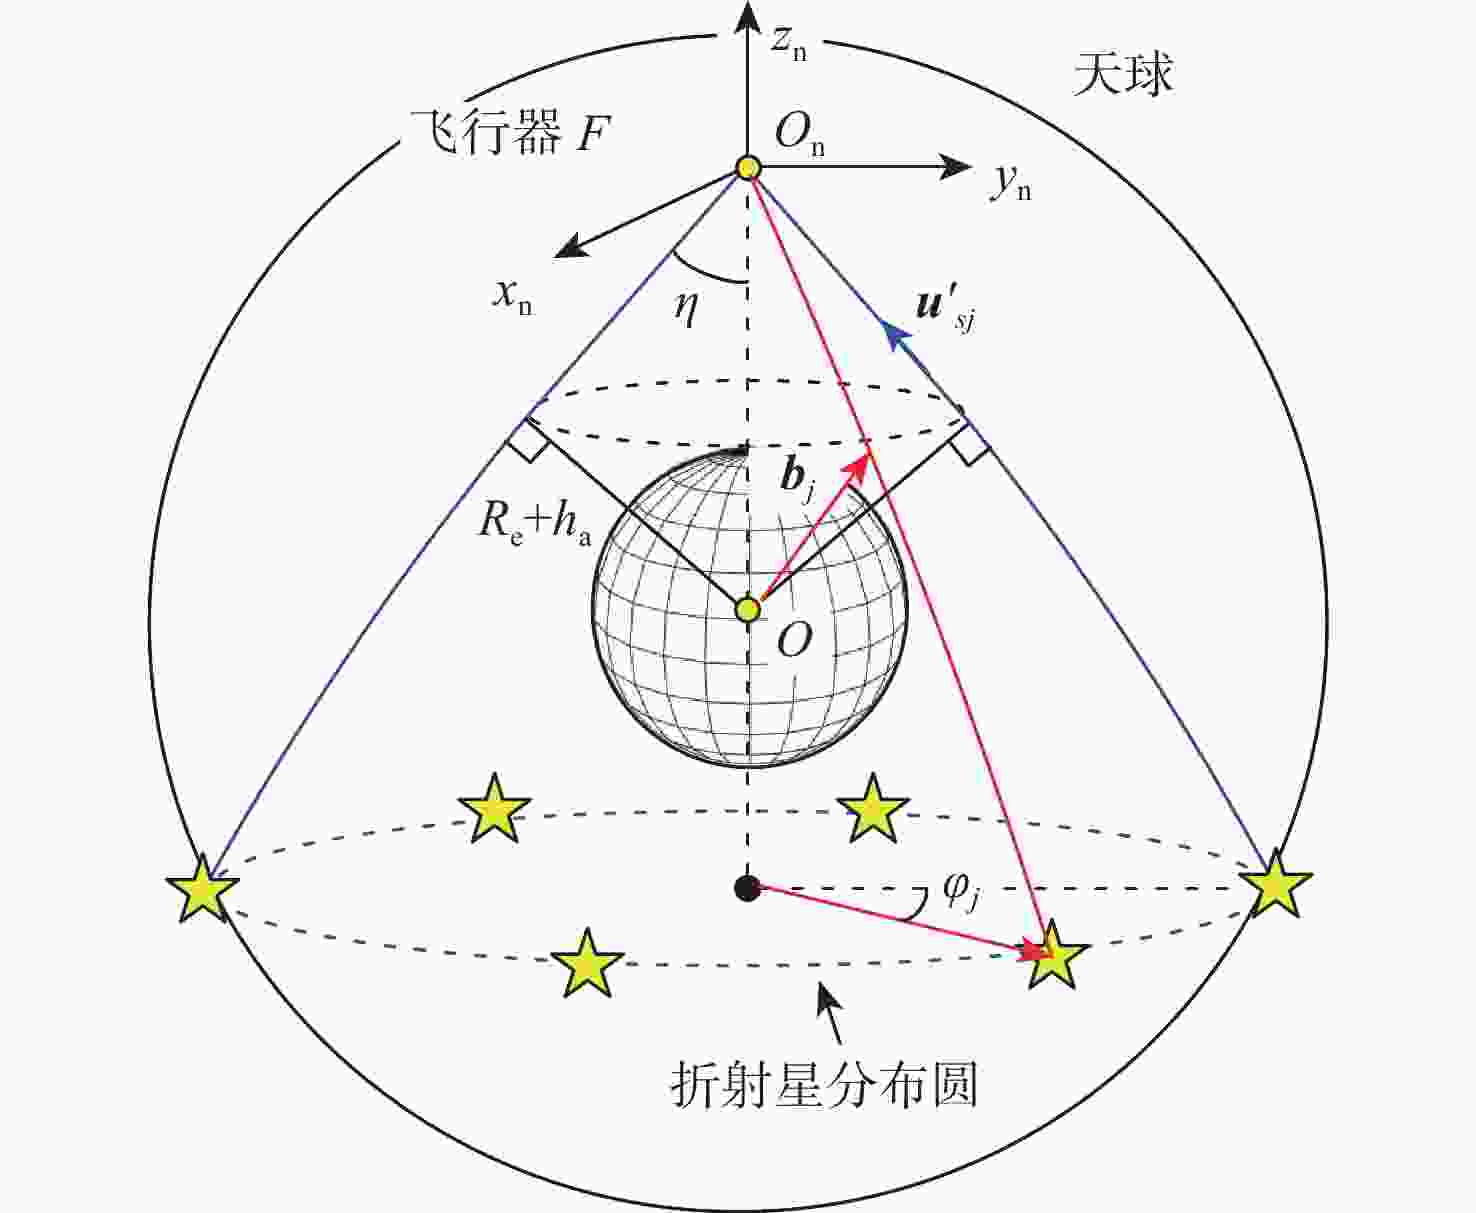
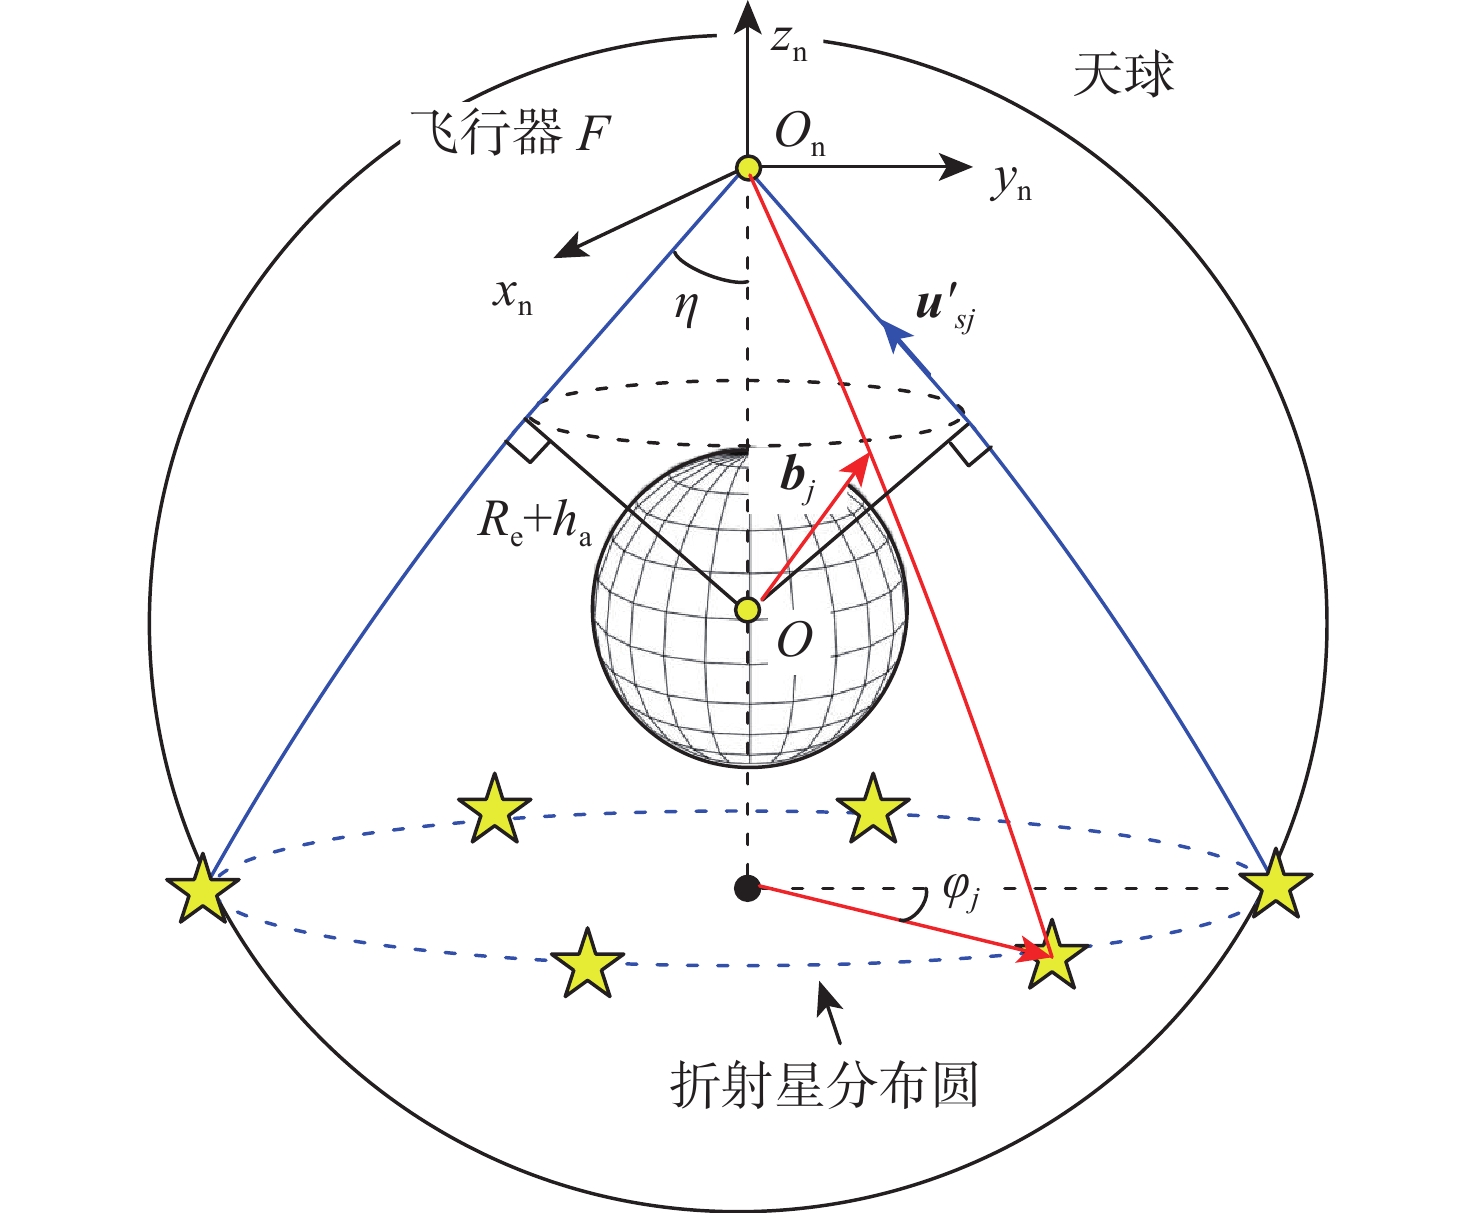
图 4 折射星地心法向矢量的几何分布示意图
Figure 4. Distribution of refracted star geocentric normal vector between the star and the Earth

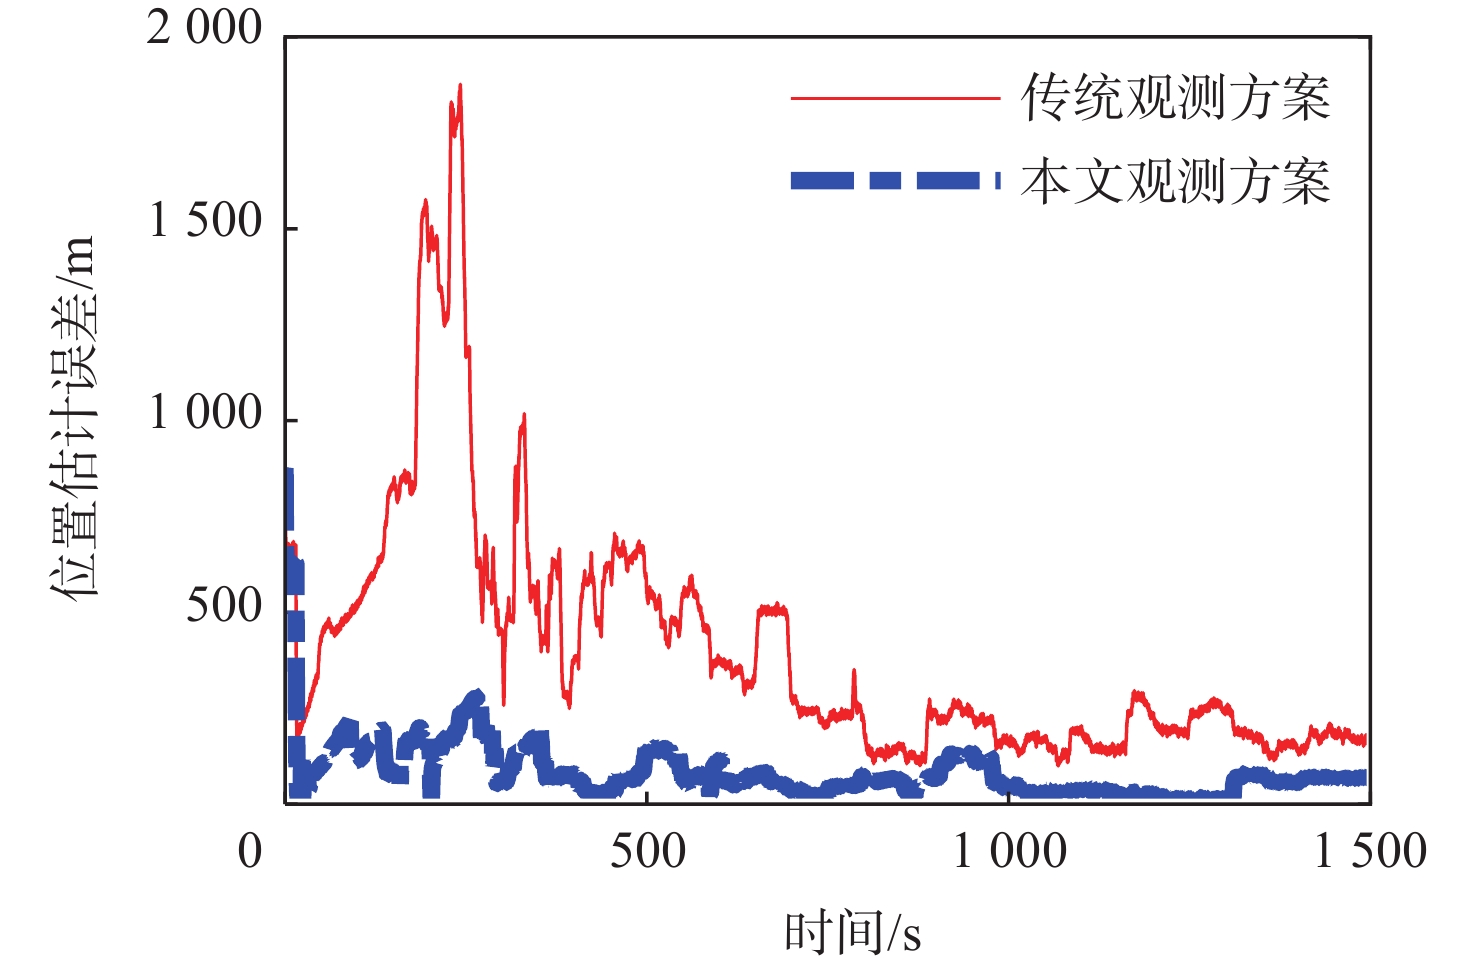
图 8 不同折射星观测方案的位置估计误差
Figure 8. Position errors of different refracted star observation schemes
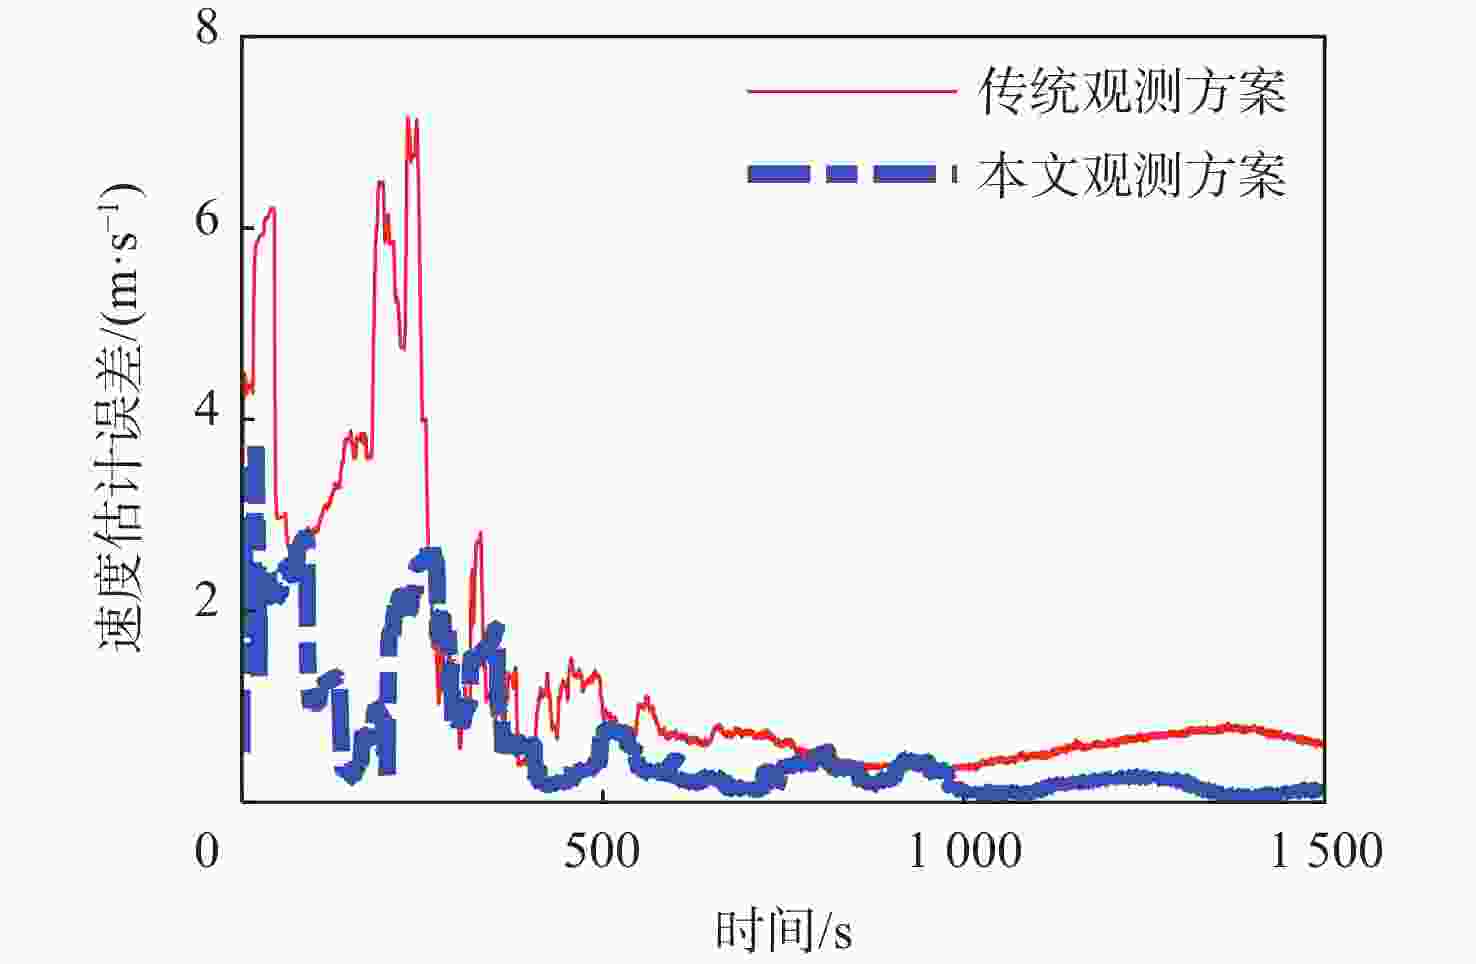
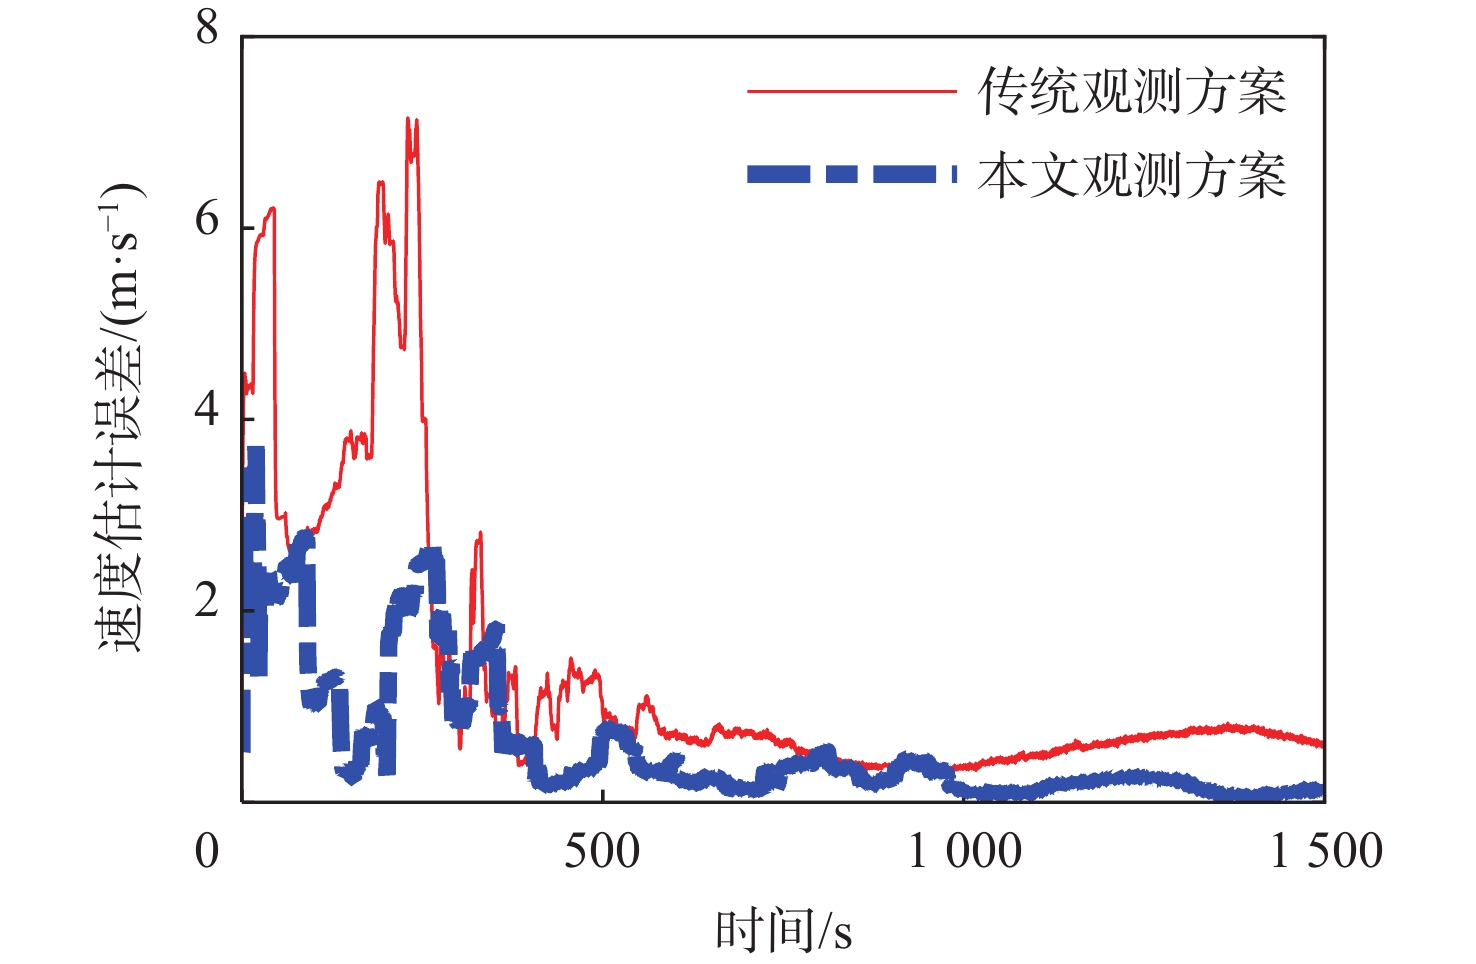
图 9 不同折射星观测方案的速度估计误差
Figure 9. Velocity errors of different refracted star observation schemes
表 1 不同折射星观测方案的导航精度对比
Table 1. Comparison of navigation accuracy by different refracted star observation schemes
折射星光
观测方案位置估计误差/m 速度估计误差/(m·s−1) 均值 均方差 均值 均方差 传统方案 100.28 143.85 0.34 0.51 本文观测方案 45.48 34.95 0.06 0.17  下载: 导出CSV
表 2 不同观测方位角的导航精度对比
Table 2. Comparison of navigation accuracy of different observation azimuths
观测方位角
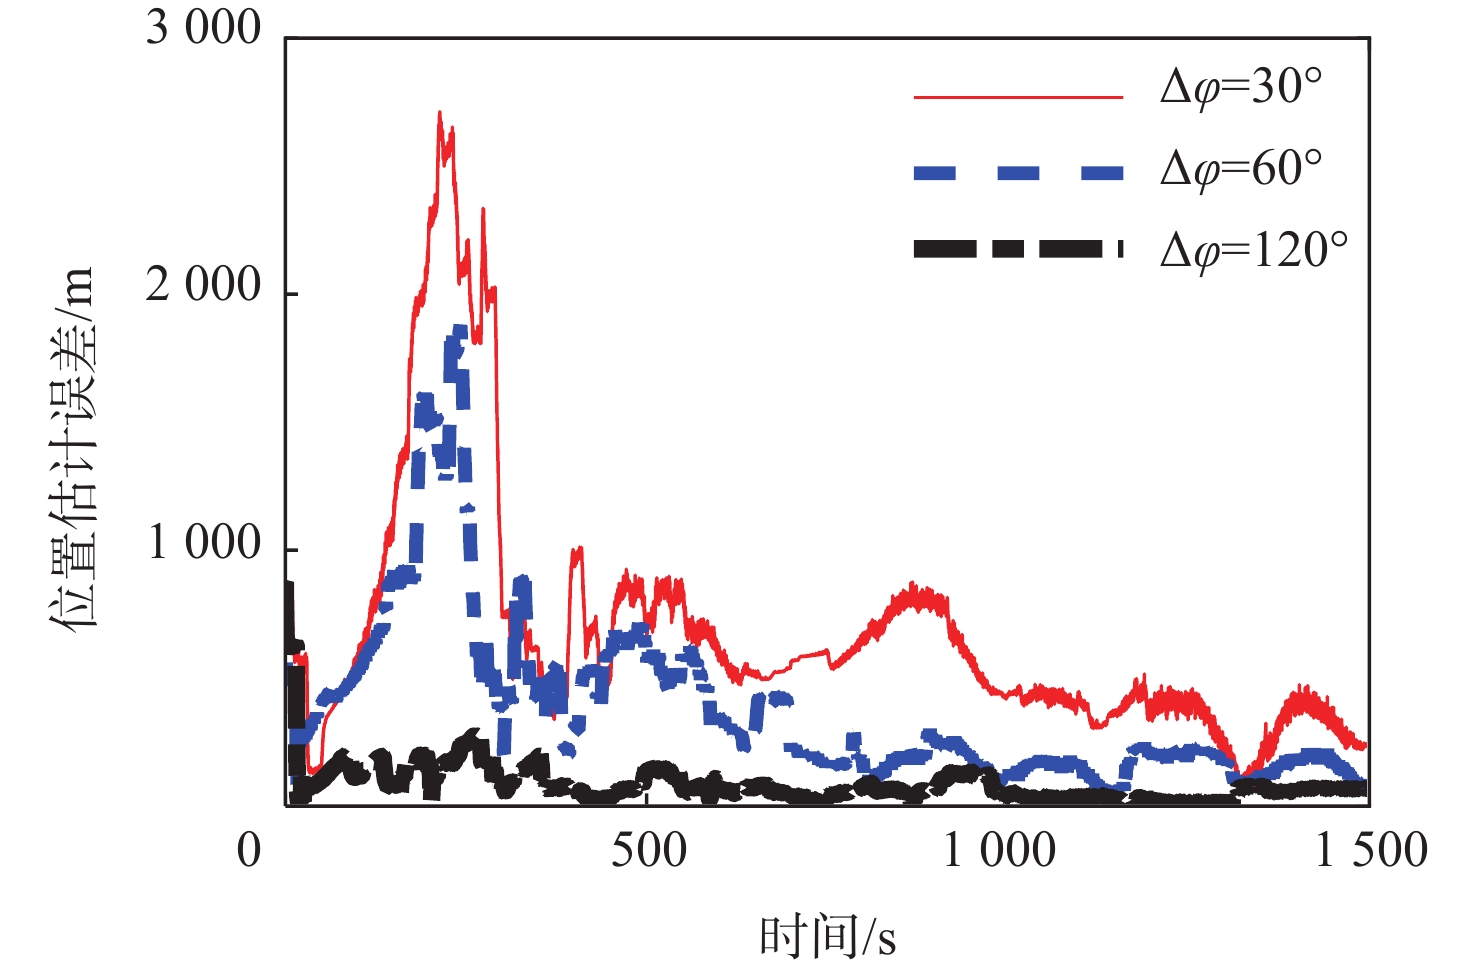
之差/(°)位置估计误差/m 速度估计误差/(m·s−1) 均值 均方差 均值 均方差 30 186.22 349.77 0.81 0.86 60 103.72 125.74 0.24 0.59 120 45.48 34.95 0.06 0.17
下载: 导出CSV
表 3 不同飞行高度的导航精度对比
Table 3. Comparison of navigation accuracy at different flight heights
飞行高度/km 位置估计误差/m 速度估计误差/(m·s−1) 均值 均方差 均值 均方差 500 45.48 34.95 0.06 0.17 1000 86.97 75.74 0.33 0.28 2000 163.76 112.40 0.56 0.53
下载: 导出CSV
-
[1] 魏昊, 蔡光斌, 凡永华, 等. 高超声速飞行器再入滑翔段在线制导[J]. 北京航空航天大学学报, 2025, 51(1): 183-192.Wei H, Cai G B, Fan Y H, et al. Online guidance for hypersonic vehicles in glide-reentry segment[J]. Journal of Beijing University of Aeronautics and Astronautics, 2025, 51(1): 183-192(in Chinese). [2] Song G X, Yang Y Q, Ning X L, et al. A new SINS/RCNS integrated navigation method based on star pixel coordinates[J]. Science China Information Sciences, 2023, 66(9): 199201. [3] 王鼎杰, 吕汉峰, 吴杰, 等. 星光折射辅助惯性/天文紧组合高精度导航方法[J]. 中国惯性技术学报, 2020, 28(1): 74-81.Wang D J, Lv H F, Wu J, et al. Stellar refraction-aided SINS/CNS tightly-integrated navigation method[J]. Journal of Chinese Inertial Technology, 2020, 28(1): 74-81(in Chinese). [4] Ning X L, Sun X H, Fang J C, et al. Satellite stellar refraction navigation using star pixel coordinates[J]. Navigation, 2019, 66(1): 129-138. [5] Zhu J F, Wang X L, Li H N, et al. A high-accuracy SINS/CNS integrated navigation scheme based on overall optimal correction[J]. Journal of Navigation, 2018, 71(6): 1567-1588. [6] Zhao Y, Wang D J, Zhang H B, et al. A novel tightly-coupled SINS/RCNS integrated navigation method considering atmospheric density error[J]. IEEE Transactions on Instrumentation and Measurement, 2023, 72: 8503011. [7] Ning X L, Sun X H, Chao W. Integration of star pixel coordinates and their time differential measurement in satellite stellar refraction navigation[J]. Acta Astronautica, 2019, 159: 286-293. [8] Yang H, Wang D J, Zhang H B, et al. Autonomous strapdown inertial/refractive celestial integrated navigation using dual-band stellar refraction observations[J]. IEEE Transactions on Aerospace and Electronic Systems, 2025, 62: 2900-2912. [9] Zhan X J, Wang X L, Hu X D, et al. A new method for high-precision starlight refraction indirect horizon-sensing positioning of atmospheric flight vehicles[J]. Advances in Space Research, 2024, 73(8): 3884-3895. [10] 宋峰, 张奕群. 星光大气折射观测导航方法可观性研究[J]. 现代防御技术, 2012, 40(2): 65-70.Song F, Zhang Y Q. Research on observability of navigation approach using starlight refraction measurements[J]. Modern Defence Technology, 2012, 40(2): 65-70(in Chinese). [11] 宁晓琳, 王龙华, 白鑫贝, 等. 一种星光折射卫星自主导航系统方案设计[J]. 宇航学报, 2012, 33(11): 1601-1610.Ning X L, Wang L H, Bai X B, et al. A scheme design of satellite autonomous navigation system based on stellar refraction[J]. Journal of Astronautics, 2012, 33(11): 1601-1610(in Chinese). [12] Qian H M, Sun L, Cai J N, et al. A starlight refraction scheme with single star sensor used in autonomous satellite navigation system[J]. Acta Astronautica, 2014, 96: 45-52. [13] Wang H Y, Gao Z Q, Wang T F, et al. Study on command attitude law for refracted starlight observation in SINS/RCNS integrated navigation[J]. Advances in Space Research, 2018, 62(3): 721-731. [14] 魏诗卉, 杨春伟, 刘炳琪, 等. 星光折射连续修正方法及制导规划[J]. 航空学报, 2020, 41(8): 54-63.Wei S H, Yang C W, Liu B Q, et al. Stellar refraction: continuous correction and guidance planning[J]. Acta Aeronauticaet Astronautica Sinica, 2020, 41(8): 54-63(in Chinese). [15] Ning X L, Wang F, Fang J C. Implicit UKF and its observability analysis of satellite stellar refraction navigation system[J]. Aerospace Science and Technology, 2016, 54: 49-58. -

 下载:




 点击查看大图
计量
- 文章访问数: 308
- HTML全文浏览量: 202
- PDF下载量: 6
- 被引次数: 0
